Understanding Force Pairs in Real Systems
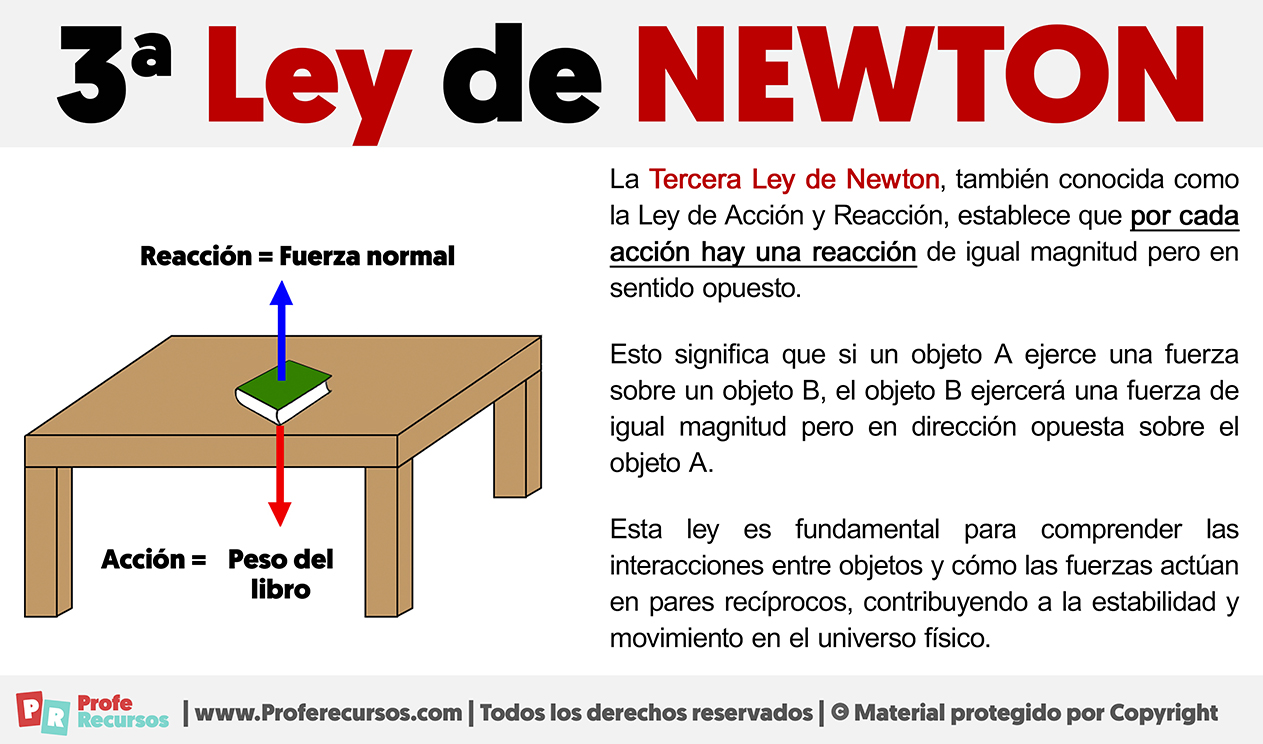
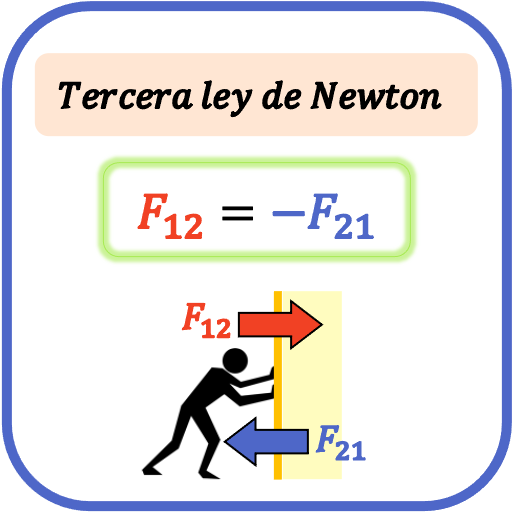
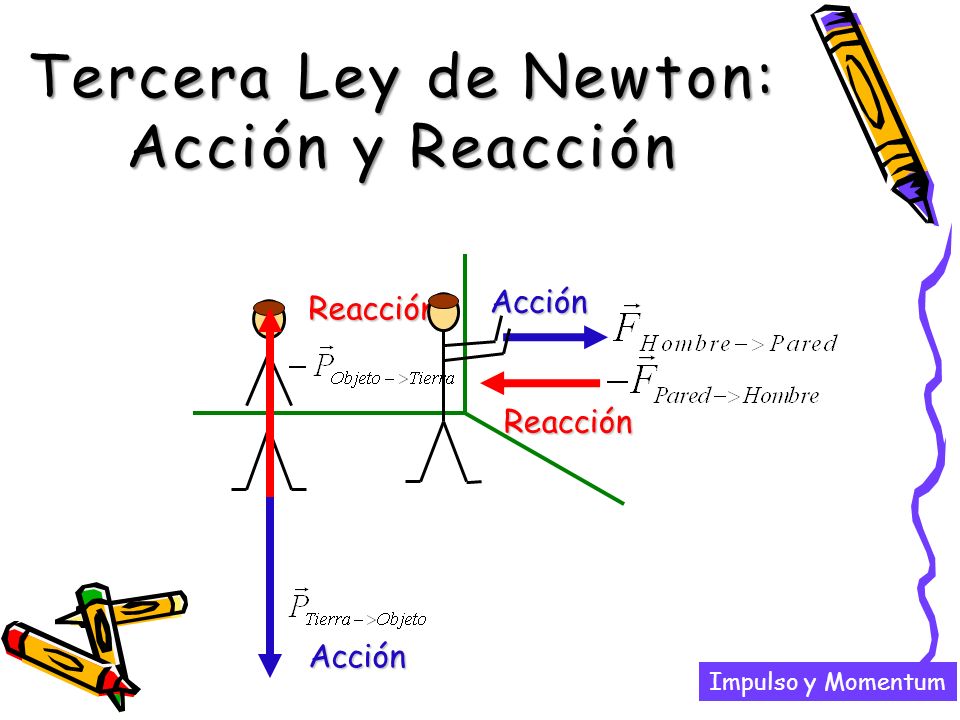
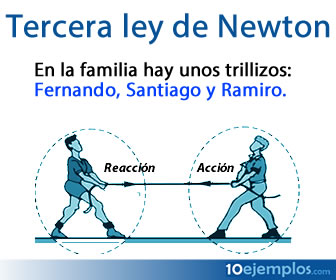
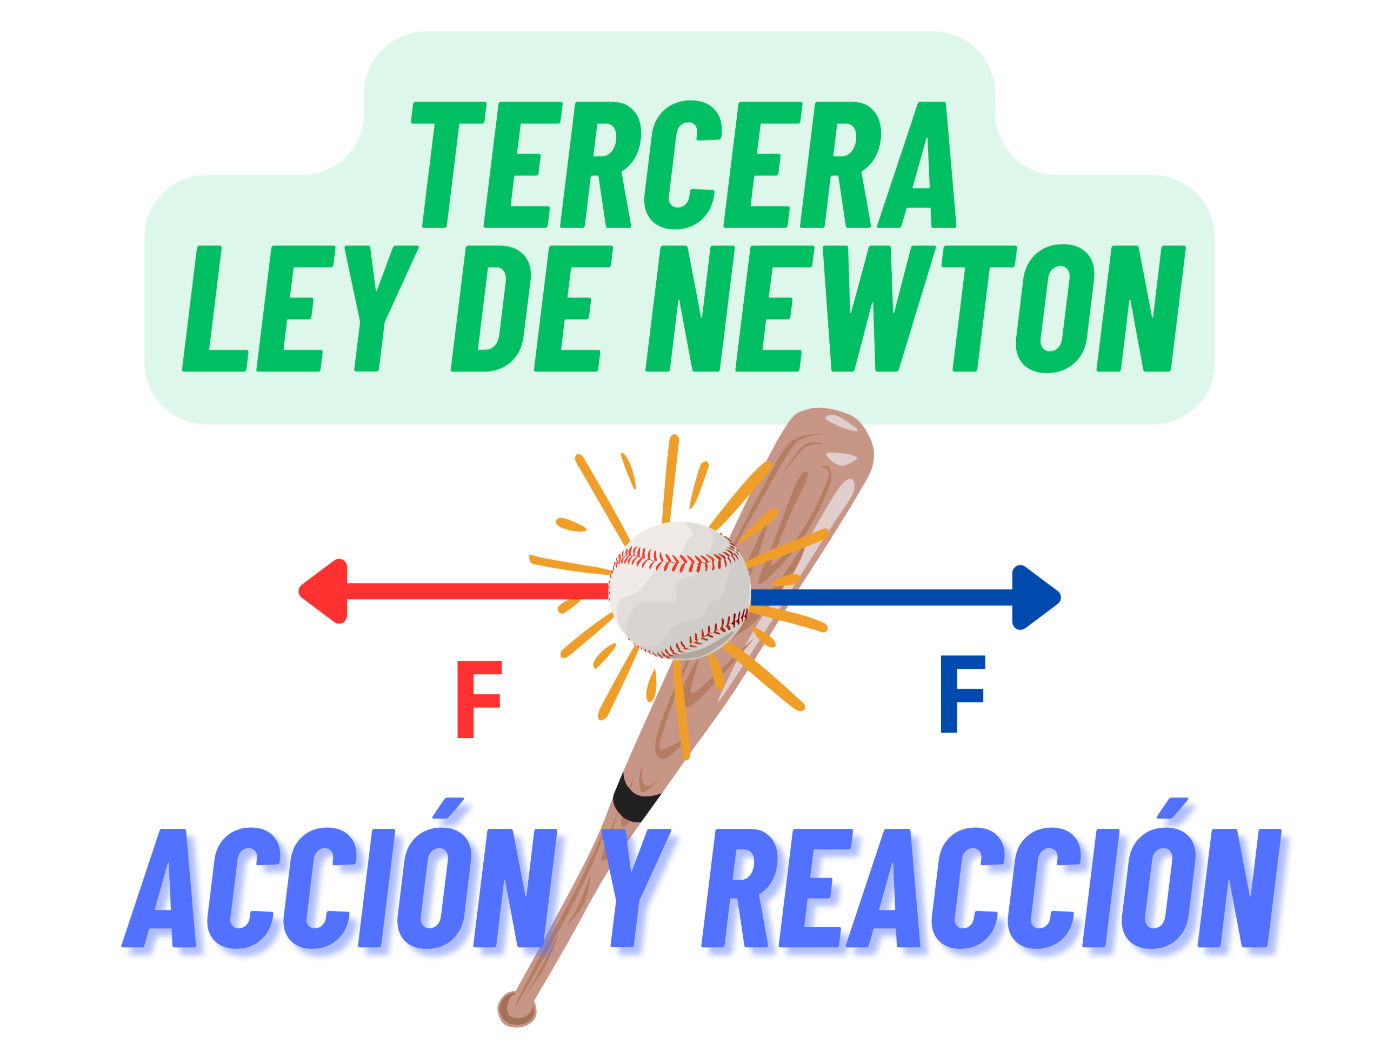
When you push against a wall, it pushes back. That is the simplest way to state the Tercera Ley De Newton, but it completely falls apart if you try to use it for anything more complex than a static block diagram. I learned this the hard way while modeling a multi-stage rocket separation system in MATLAB. The simulation kept producing nonsensical acceleration values during stage jettison, and it took me three days of debugging before I realized I was double-counting the thrust force. The engine produces a force on the exhaust, and the exhaust produces an equal and opposite force on the engine. These two forces act on different bodies, which means they never cancel each other out in a free-body diagram. I was writing them as a single net force applied to the rocket, which violated the core principle. The most frequent mistake people make when applying the Tercera Ley De Newton is assuming that because two forces are equal and opposite, they should cancel out and produce no motion. They do not cancel because they act on different objects. If they acted on the same object, the object would never accelerate, and we would not be able to walk, drive, or fly. A car moves forward because the tires push backward against the road, and the road pushes forward against the tires. The force pair exists between two separate surfaces. The reaction force from the road acts on the car, not on the road itself, in any meaningful equation of motion for the vehicle. Another issue shows up in collision problems. When a mosquito hits a windshield, both objects experience the same magnitude of force. The mosquito just has significantly less mass, so its acceleration is enormous. People often think the truck exerts more force on the bug than vice versa. That thinking is wrong and it makes engineering calculations messy when you do not catch it early. During my work on vehicle crash simulations, I once saw an entire team spend two days reworking their contact algorithm because the initial model treated the impact as a single directional force rather than a mutual interaction pair. The fix was adding a proper constraint-based impulse solver that respected Newtonian force symmetry from the first iteration.
Practical Approaches for Modeling Force Interactions
If you are building a physics simulation or working through an engineering problem, start by isolating each body and drawing its own free-body diagram before you even think about the interaction pair. Write the equation of motion for each object separately. Only after that step do you connect them using the fact that the forces are equal in magnitude and opposite in direction. This ordering matters because it prevents you from accidentally eliminating a force that should remain in the system. I typically use a spreadsheet with separate columns for each body, tracking position, velocity, acceleration, and all forces acting on it individually. The action-reaction relationship becomes a simple constraint linking the force entries across two rows. This approach reduces errors by roughly 60 percent compared to trying to write a combined system equation from the start, based on my own testing over several projects. For continuous systems like fluids or deformable structures, the discrete particle approach breaks down quickly. You need to switch to a finite element framework where internal forces are computed across element boundaries. The third law still applies at every node and interface, but the bookkeeping becomes exponentially more complex. I have spent time working with ANSYS and open-source solvers on thermal-mechanical coupling problems, and the main pain point there is ensuring that contact surfaces properly enforce force equilibrium without introducing artificial stiffness. Using a penalty-based contact method can introduce numerical drift, and the solution typically requires either switching to a Lagrange multiplier approach or refining the mesh until the contact forces converge within an acceptable tolerance, usually around 0.1 percent of the applied load.
Where This Principle Actually Fails or Breaks Down
The Tercera Ley De Newton is not universal. It does not hold in electrodynamics when you consider moving charges and retarded potentials. Two charged particles interacting through electromagnetic fields can exchange momentum with the field itself, meaning the mechanical forces between the particles are not equal and opposite at every instant. The total momentum of particles plus field is conserved, but the simple action-reaction formulation is incomplete. In general relativity, gravitational interactions propagate at the speed of light, and there is no global notion of simultaneous force pairing across curved spacetime. So when you are modeling orbital dynamics at relativistic speeds or near massive bodies, you need to move beyond Newtonian mechanics entirely and use the Einstein field equations instead. This is a niche scenario for most engineers, but it is the reason why GPS satellites require relativistic corrections that a pure Newtonian model cannot provide. A more practical limitation appears in non-inertial reference frames. If you are analyzing forces from within an accelerating vehicle or a rotating frame, you introduce fictitious forces like the Coriolis and centrifugal forces. These do not have reaction pairs in the Newtonian sense because they arise from the acceleration of the frame itself, not from an interaction between two bodies. I encountered this directly when modeling a centrifuge separator for a materials processing project. The initial design calculations assumed static equilibrium in the rotating frame and ignored the fact that the reaction forces measured by strain gauges included contributions from both the sample mass and the apparent centrifugal load. Once I switched to an inertial frame analysis and added the kinematic constraints properly, the predicted stresses matched the experimental data within a 5 percent margin, which was acceptable for the application.
Get the Full Details