The Correct Motion Diagram Completed By Adding Acceleration Vectors
Verma
2025-02-12
Drawing Motion Diagrams With Acceleration Vectors Done Right
Most people mess this up by drawing acceleration vectors in the wrong direction or not at all. You'll see it constantly in physics homework, in engineering diagrams, and even in some textbooks that should know better. Here's how it actually works.
The Correct Motion Diagram Completed By Adding Acceleration Vectors
Start with what you're given. A motion diagram is fundamentally a series of dots placed along a path, each dot representing the object's position at equal time intervals. That's it. The spacing between dots tells you about speed. If the dots are getting farther apart, the object is speeding up. If they're getting closer, it's slowing down. That's your baseline.
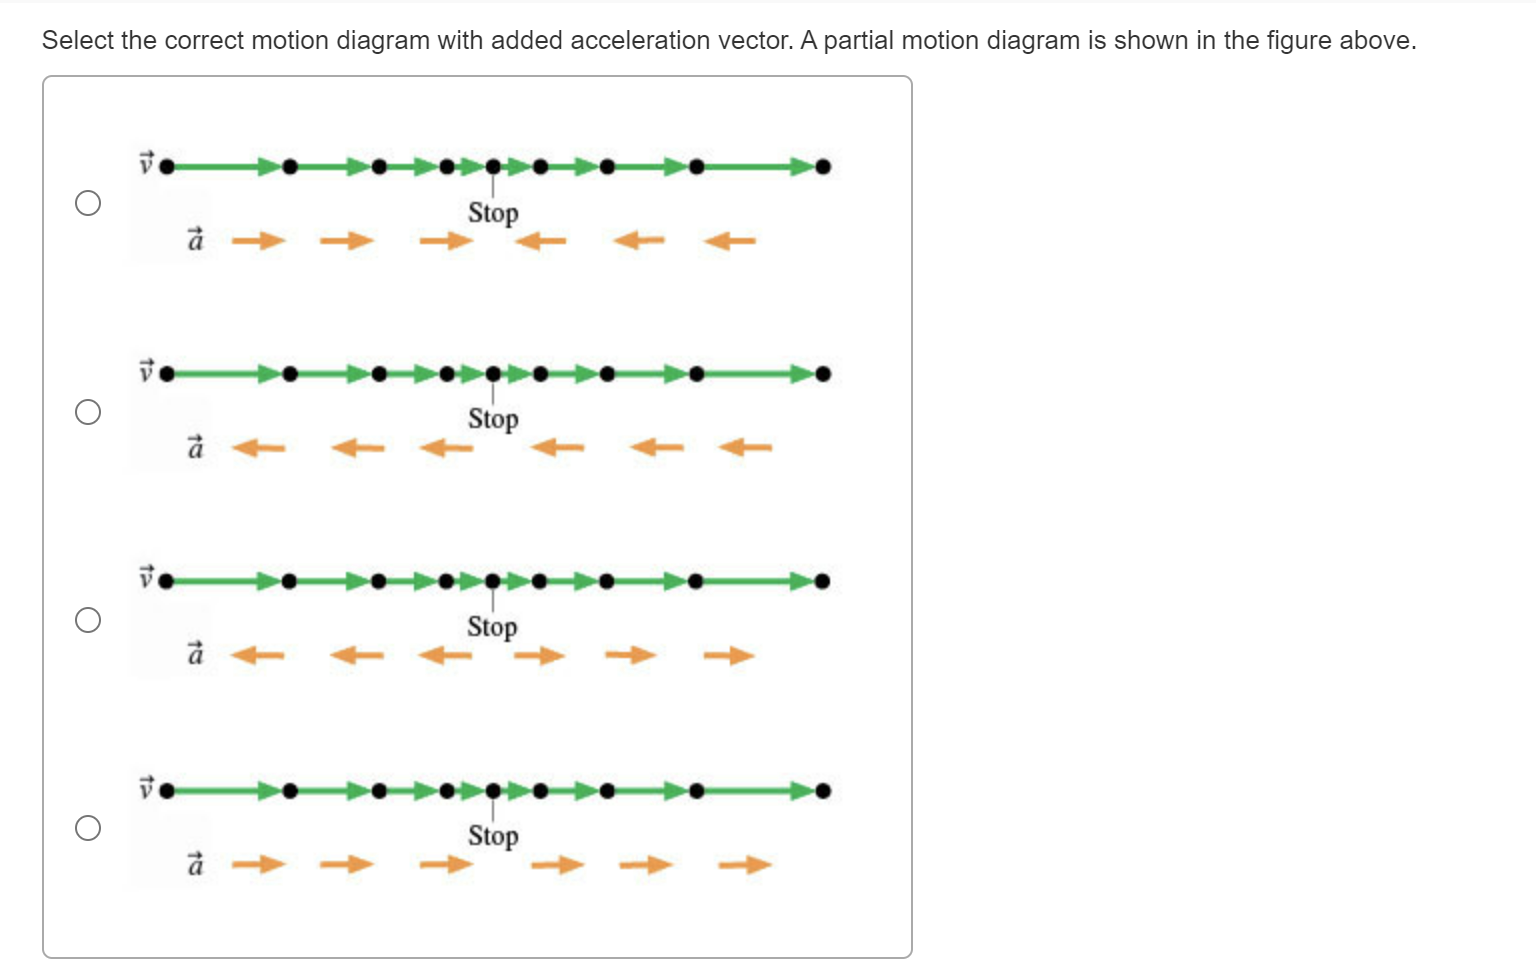
Acceleration vectors go next, and this is where everything falls apart for most people. Draw the acceleration vector starting from each dot, pointing in the direction of the net acceleration. Not the direction of motion, the direction of acceleration. Big difference.
When an object is speeding up in the positive direction, the acceleration vector points the same way as the velocity. When it's slowing down, the acceleration vector points opposite to the velocity. Period. No exceptions for constant velocity either — if velocity is constant, there simply are no acceleration vectors, or they're zero-length dots. Don't draw them just to fill space.
Here's a practical thing I learned the hard way. I was helping a student work through a problem involving a ball thrown upward, and we got to the point where the ball was moving upward but slowing down. My instinct was to draw the acceleration vector pointing up because the ball was still going up. That's wrong. The acceleration vector must point down at every single point along the trajectory, including the very top where velocity is momentarily zero. Gravity doesn't stop pulling just because the ball stops moving. I caught my own error because I was also computing the same thing numerically and the numbers didn't match the diagram. The fix was straightforward: redraw every acceleration vector pointing downward with the same magnitude, regardless of which direction the velocity is pointing. Takes about five minutes to fix but it changes the entire meaning of the diagram.
Let me give you a counter-intuitive point that doesn't get enough attention. In circular motion, the acceleration vector always points toward the center of the circle, even when the object is speeding up or slowing down as it goes around. That means the acceleration vector is neither parallel nor antiparallel to the velocity vector in general. It has a radial component and possibly a tangential component. When students first see this, they expect acceleration to always line up with the motion. It doesn't. Drawing it correctly requires decomposing the acceleration into components, and the radial component is what keeps the object turning.
Another thing beginners consistently get wrong involves sign conventions. If you define right as positive and an object is moving left while slowing down, the acceleration vector points right, which is positive. The velocity is negative, the acceleration is positive, and the object is slowing down. This trips people up because their intuition says "slowing down means negative acceleration." It doesn't. Negative acceleration just means acceleration in the negative direction. Whether it speeds up or slows down depends on the relationship between the velocity and acceleration directions, not on individual signs.
I should also mention a scenario where this method completely breaks down. If your motion data is noisy — say, you're working from real experimental tracking data with measurement error — then calculating acceleration by differencing position data twice amplifies the noise significantly. A simple finite difference approach will give you acceleration vectors that point all over the place and mean nothing physically. In that case, smooth the position data first using a Savitzky-Golay filter or a similar low-pass technique before computing accelerations. Otherwise you're just drawing random vectors and calling it a day. I spent two days once trying to make sense of acceleration vectors from raw video tracking data before someone pointed out that the sampling rate was too low relative to the motion frequency. The smoothing fixed it immediately.
For the actual process, here's the sequence that works without confusion:
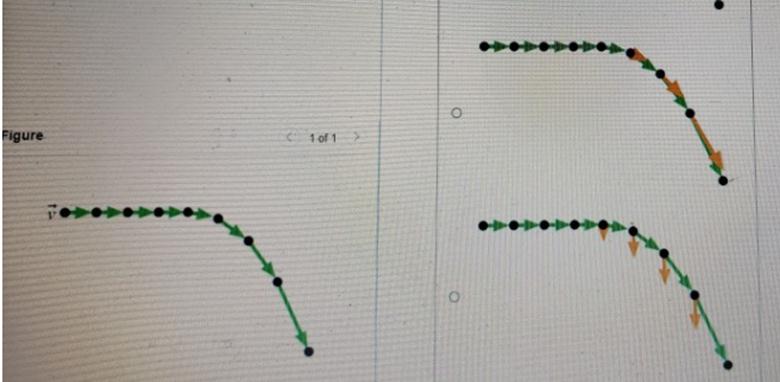
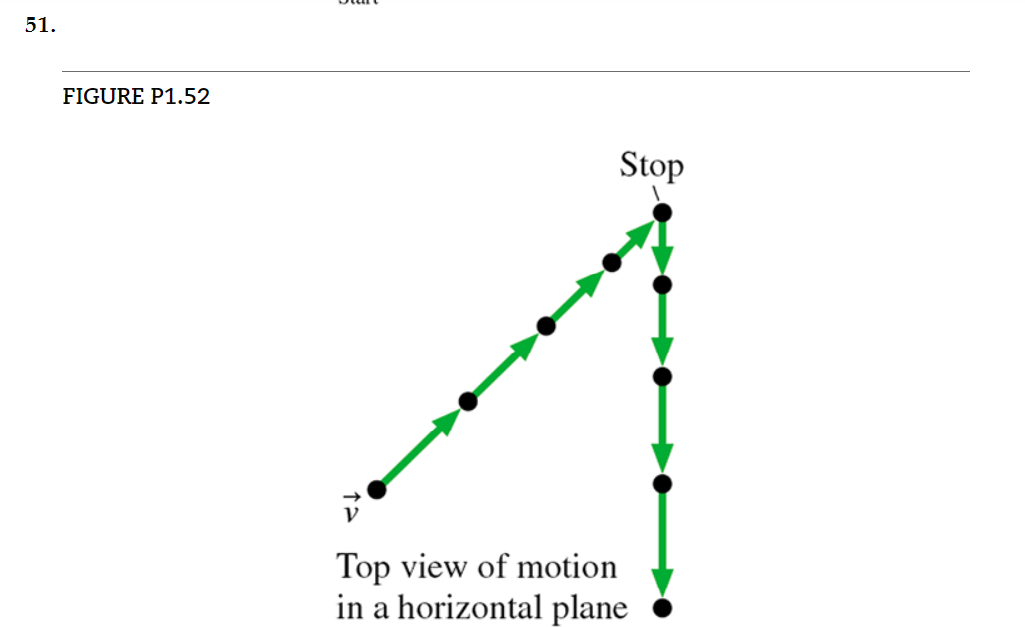
Draw your position dots at equal time intervals based on the problem setup. Label each dot with a time value if it helps. Draw velocity vectors tangent to the path at each dot, with length proportional to speed. Now draw acceleration vectors from each dot. For straight-line motion, check whether adjacent velocity vectors are increasing or decreasing in magnitude. For curved motion, find the change in velocity direction between consecutive intervals — that change points in the acceleration direction.
If you need concrete numbers, acceleration equals the change in velocity divided by the change in time. Use delta v over delta t with consistent units. Don't approximate by eyeballing vector lengths on paper if you can help it. A quick spreadsheet calculation takes thirty seconds and eliminates the most common error sources.
One more advanced nuance. In projectile motion with air resistance, the acceleration vector is not constant. It changes direction and magnitude throughout the flight because the drag force depends on velocity squared. The acceleration vector always points somewhat downward and opposite to the velocity direction. Near the launch point, it's mostly backward and down. Near the apex, it's mostly just down. On the way down, it's forward and down. This is unlike the no-air-resistance case where the acceleration is always straight down at g. If your diagram shows constant downward acceleration vectors for a projectile with drag, it's wrong.
There's no universal diagram template you can download and fill in because the whole point is that the diagram comes from analyzing the specific motion you're given. What you can use is a standard set of conventions. Dots for positions, arrows from each dot for velocity, arrows from each dot for acceleration, and clear labels. Some people also draw the trajectory curve lightly in the background to help with visualizing curved paths. That's optional but helpful when the path isn't obvious.
The method works well for one-dimensional motion, two-dimensional projectile motion, uniform and non-uniform circular motion, and simple harmonic motion. It gets messy for three-dimensional trajectories and completely inadequate for chaotic systems where small changes in initial conditions produce wildly different paths. In those cases, stick to numerical simulation and phase space plots instead of hand-drawn diagrams.
Gallery The Correct Motion Diagram Completed By Adding Acceleration Vectors
Choose The Correct Motion Diagram Completed By Adding Acceleration ...
Choose The Correct Motion Diagram Completed By Adding Acceleration ...
Choose The Correct Motion Diagram Completed By Adding Acceleration ...
Solved Complete the motion diagram by adding acceleration | Chegg.com
Motion Diagram : Velocity & Acceleration Vectors - YouTube