Understanding the Third Law Of Dynamics in Practical Engineering
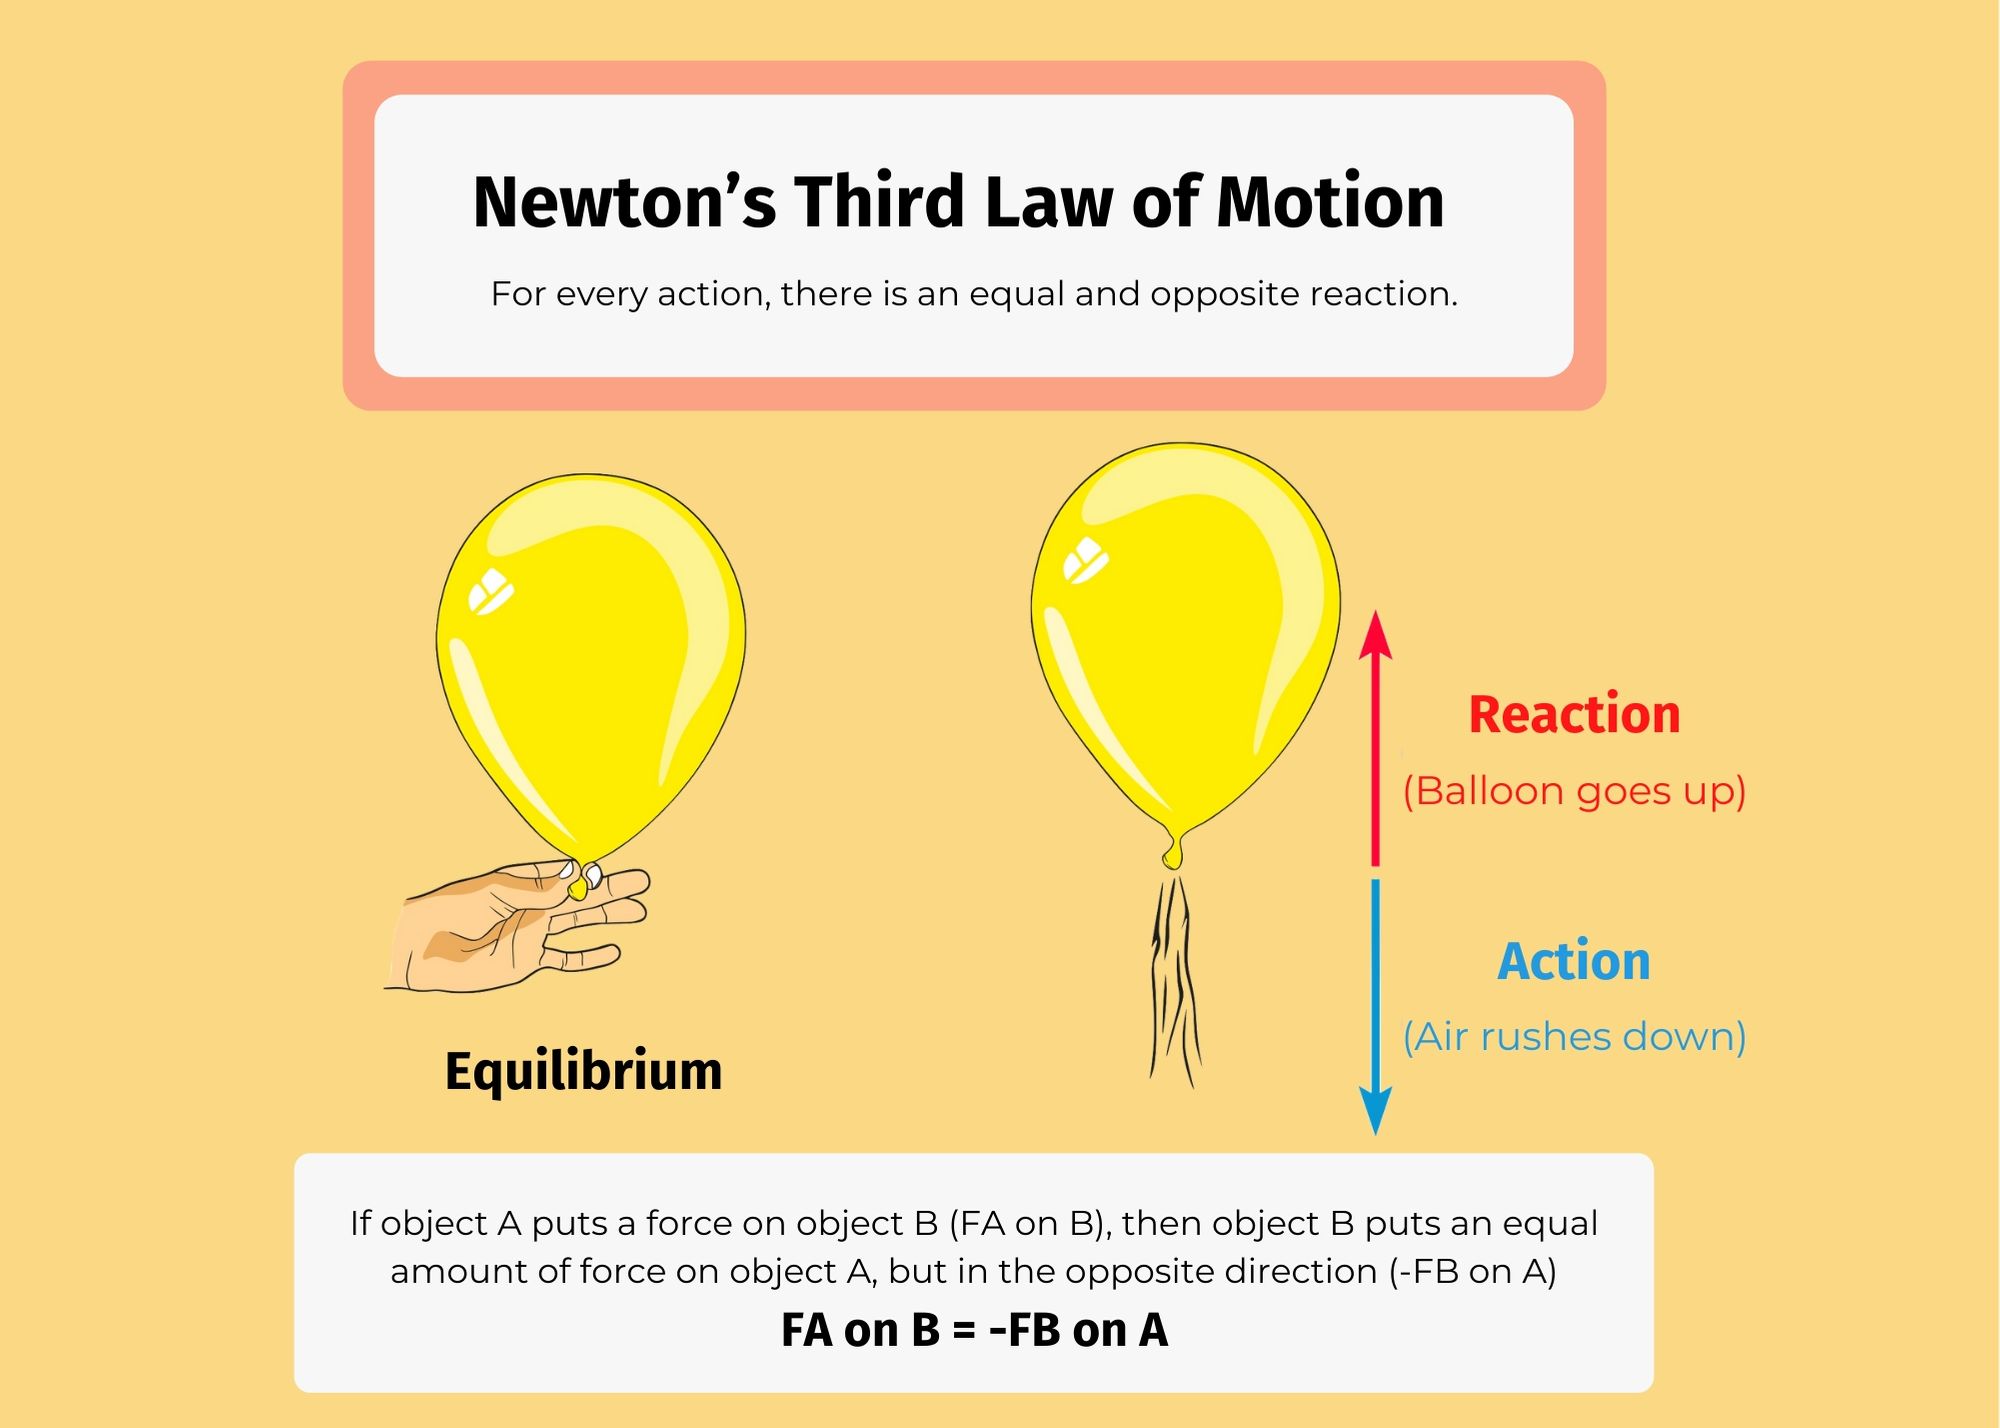
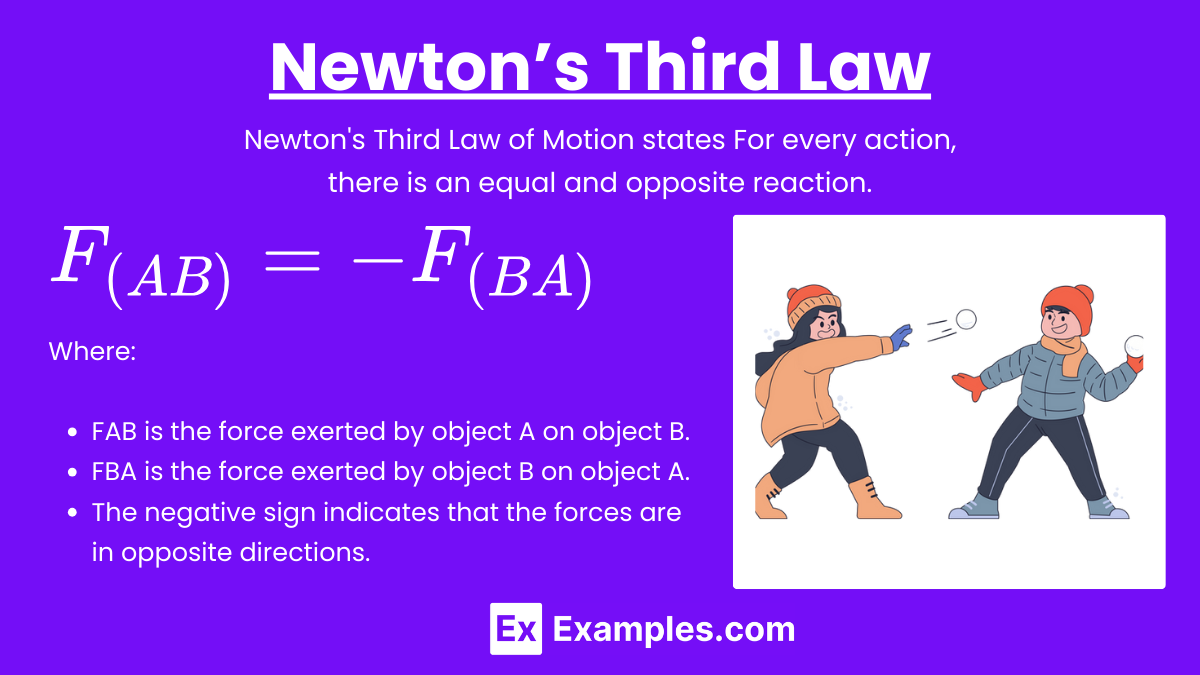
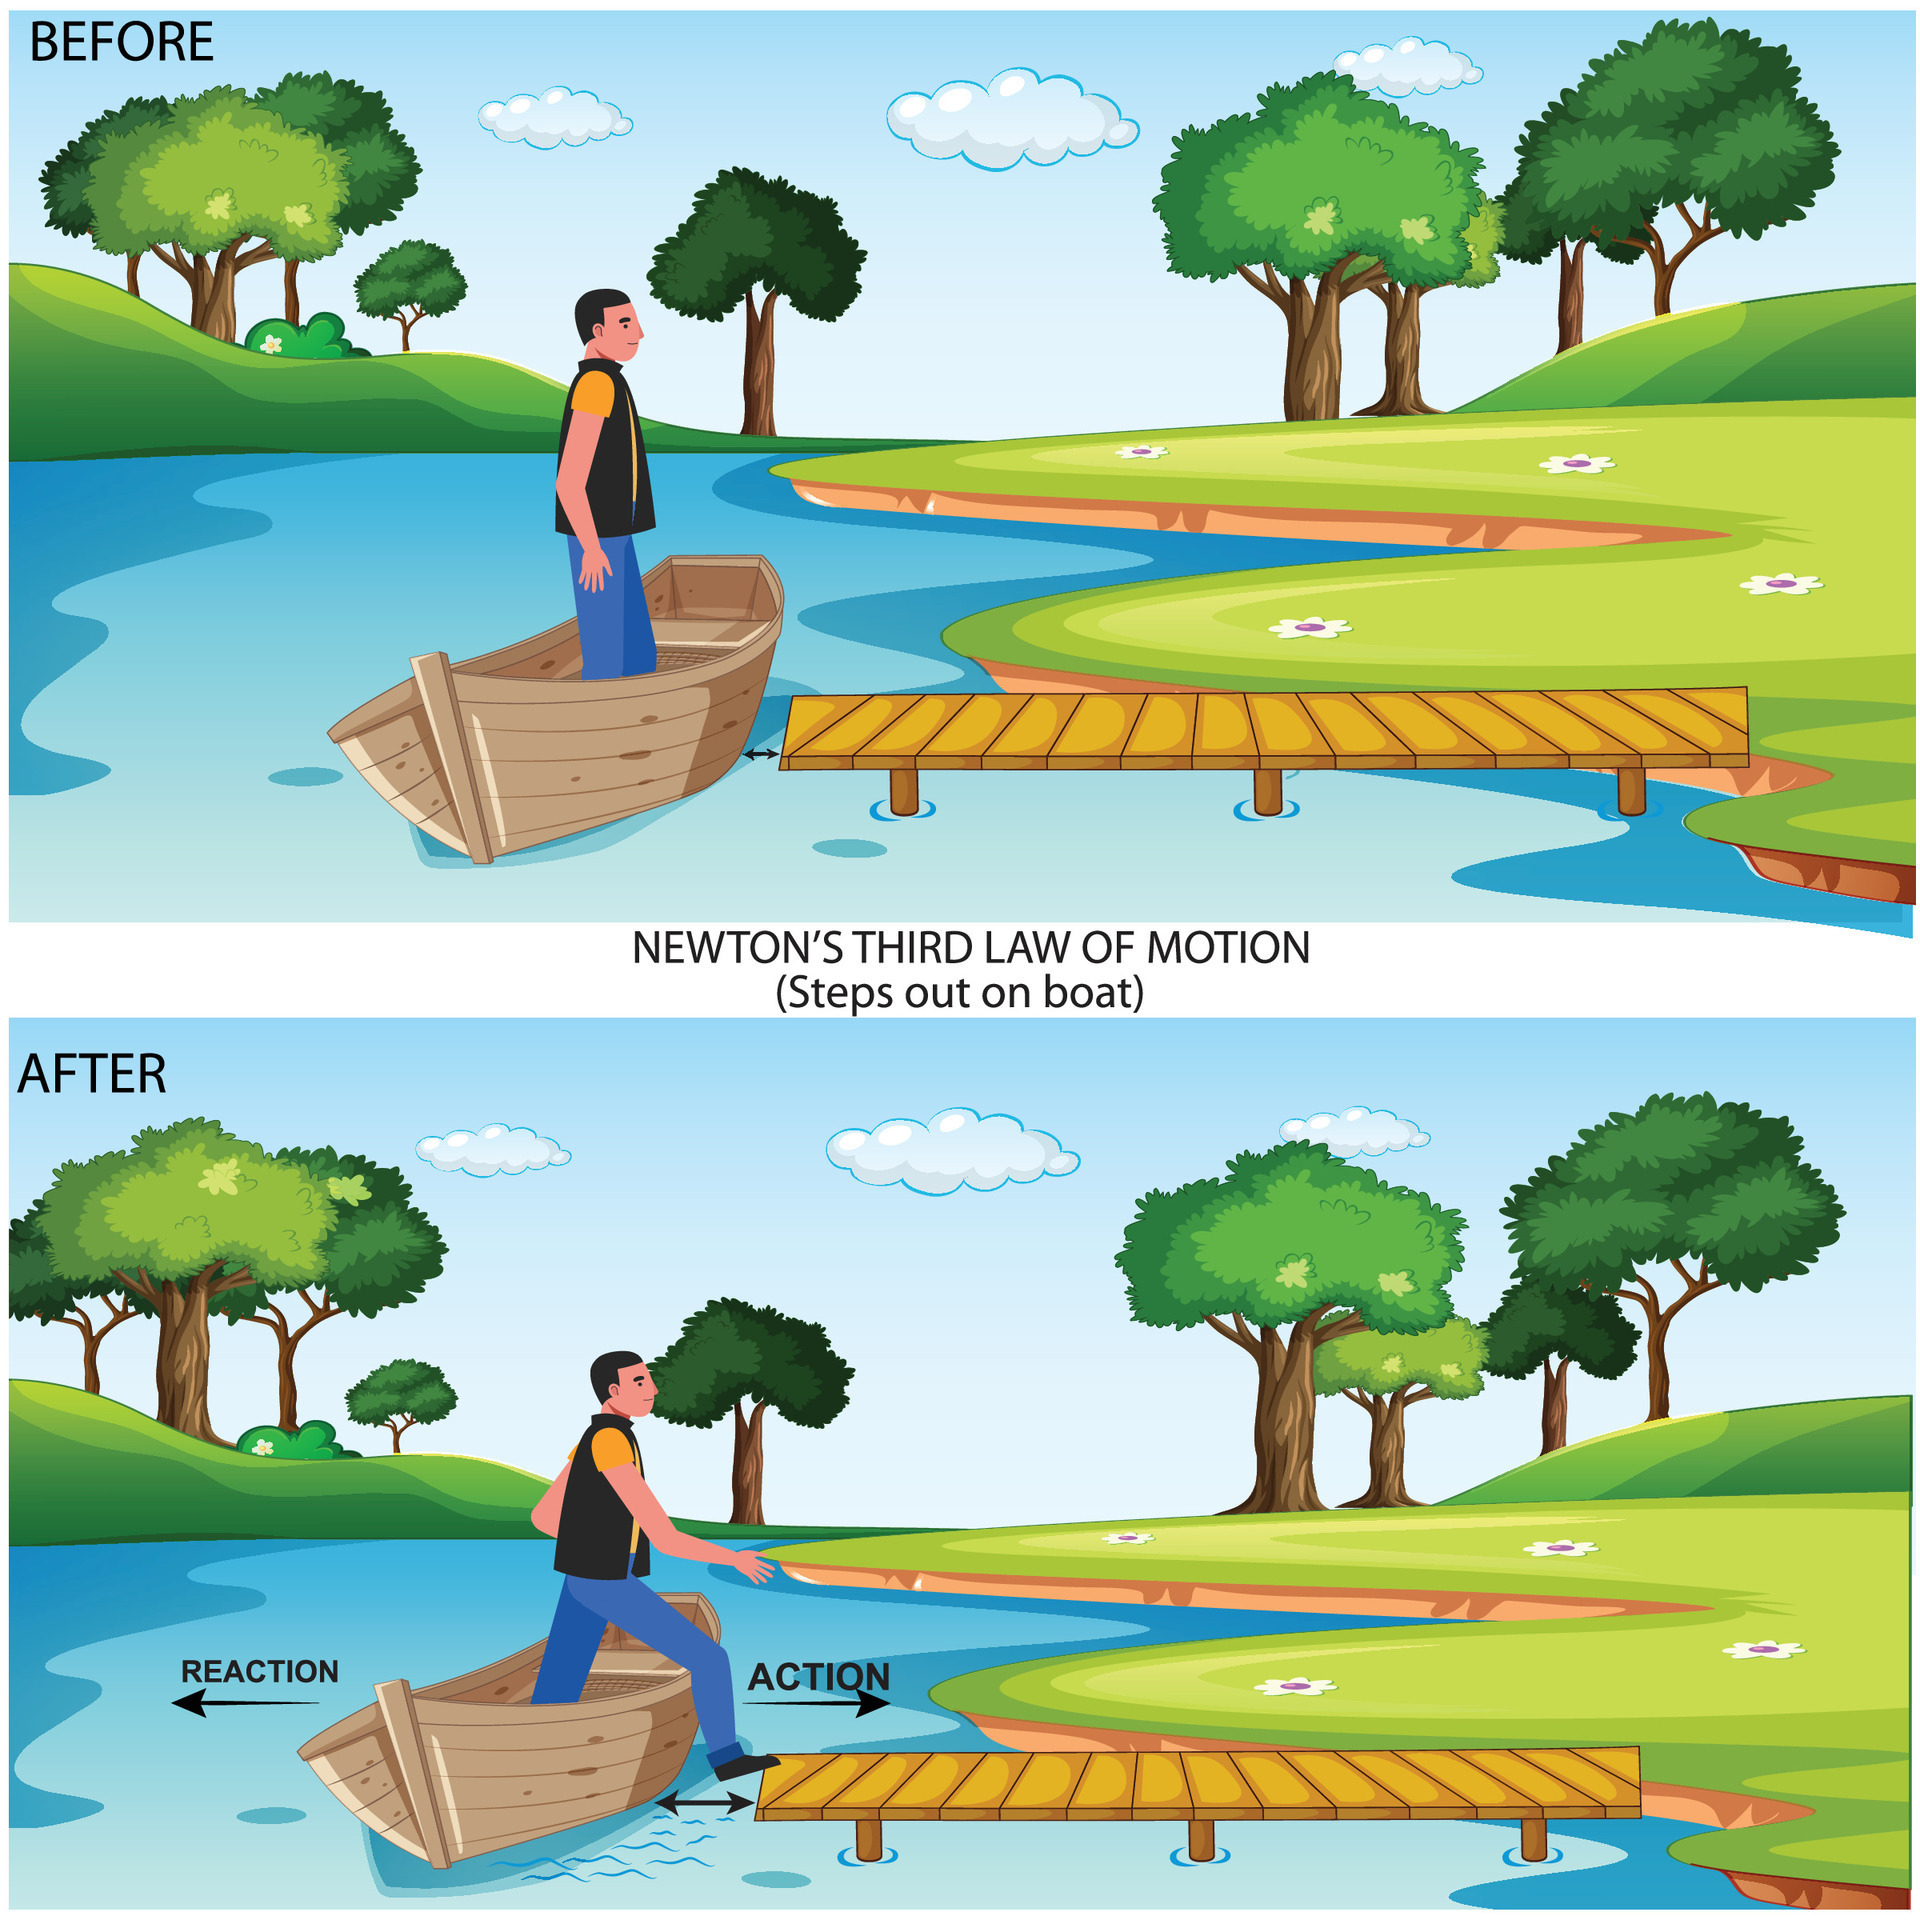
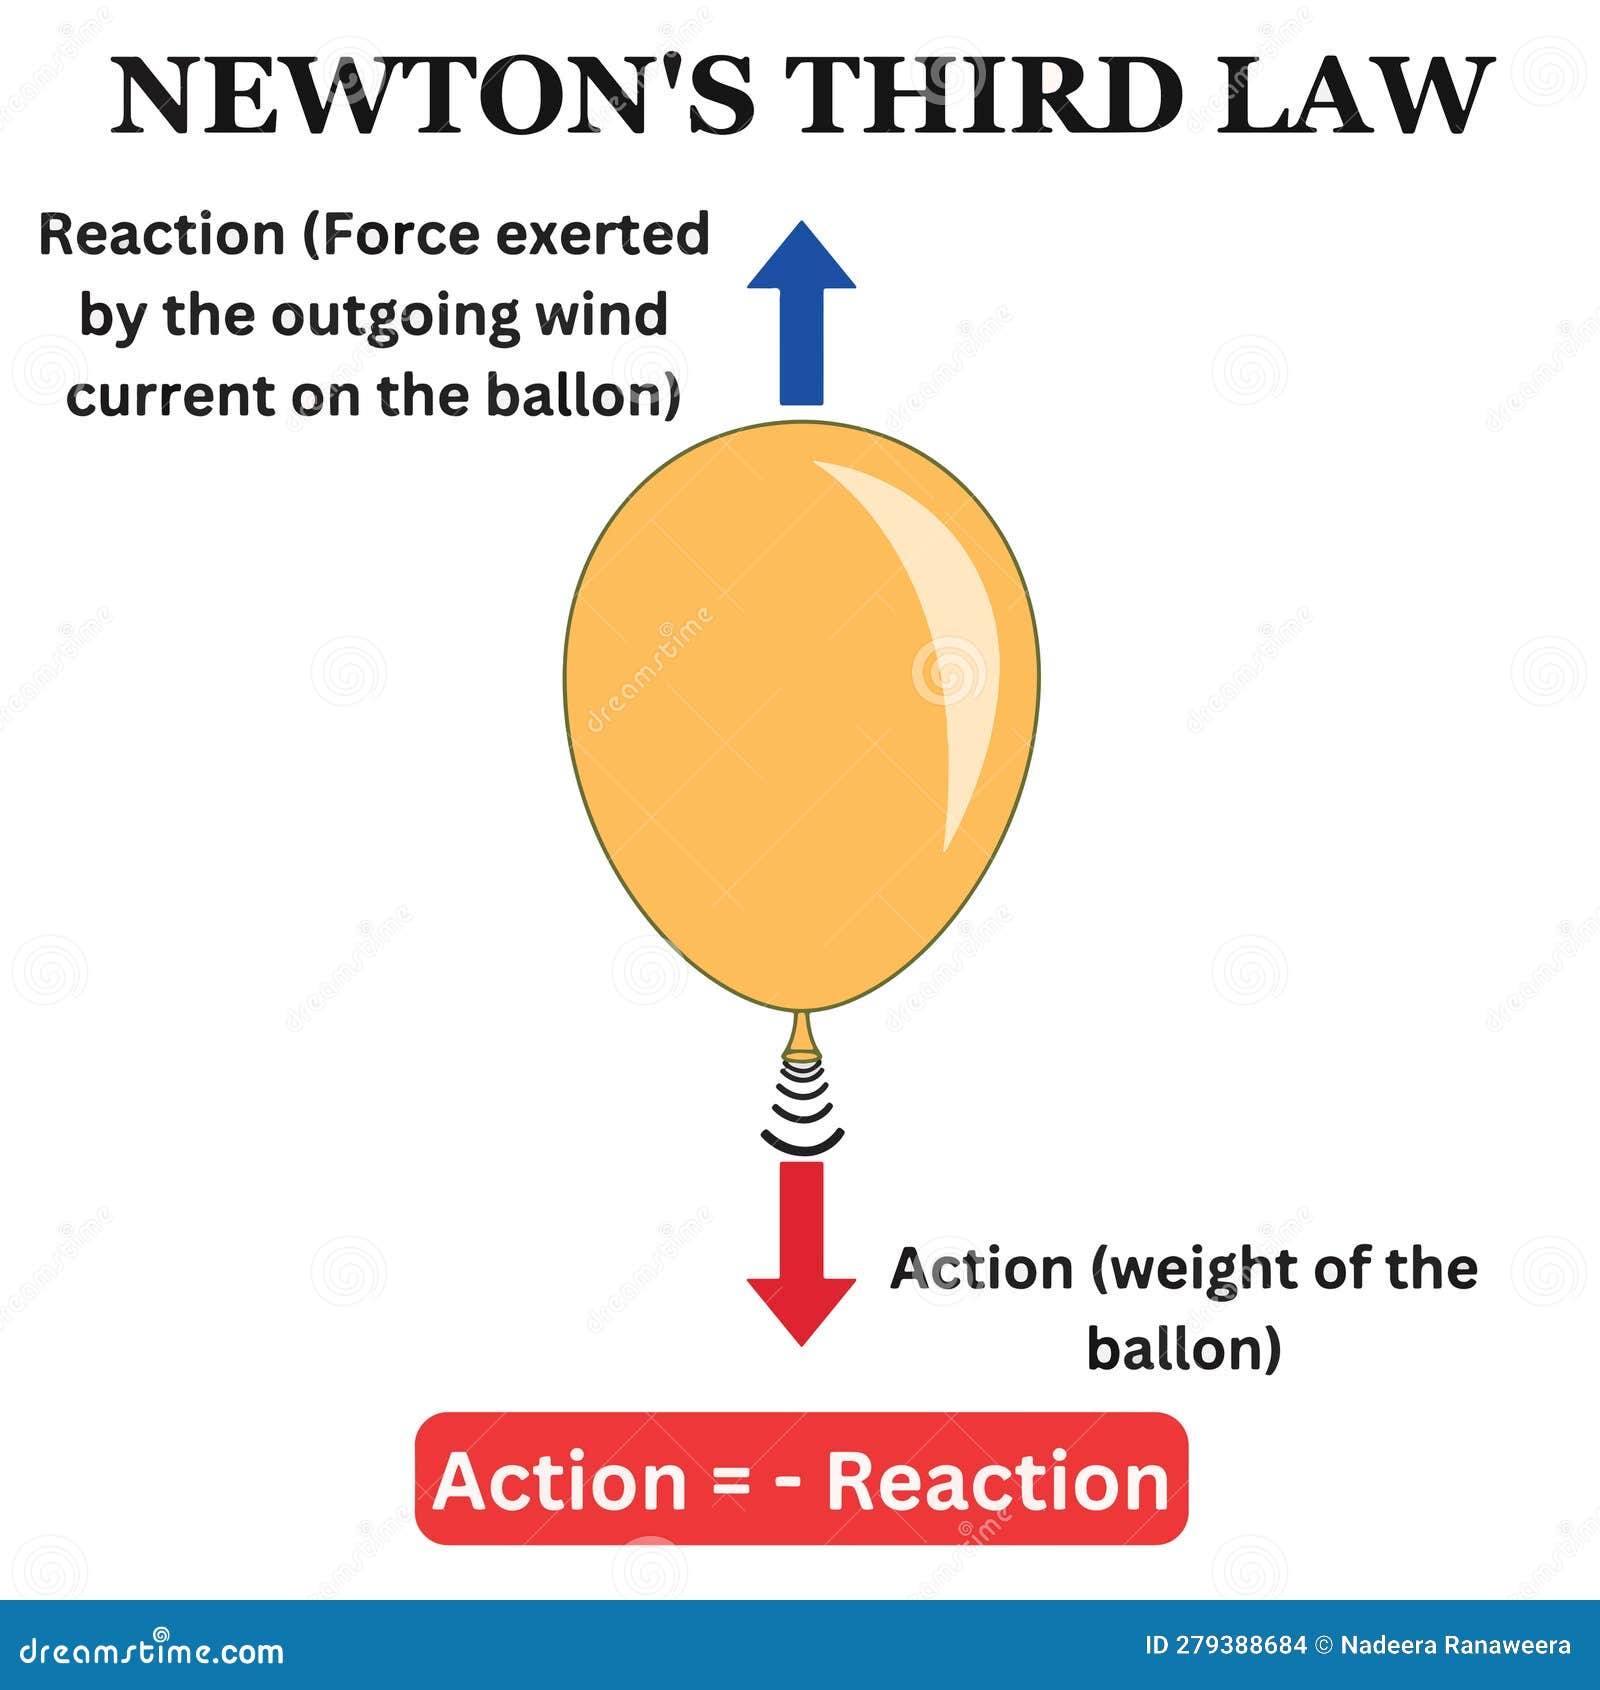
The third law of dynamics is essentially Newton's action-reaction principle applied to dynamic systems. For every force exerted, there is an equal and opposite force. That's the textbook version. In practice, it means your simulation, your structure, or your robot arm is never just doing one thing — every input has a reaction that propagates through the system in ways you can't always ignore. I've spent years working with multi-body dynamics simulations and control systems, and the third law is where most things fall apart if you're not careful. Not because the physics is wrong — it's perfectly sound — but because the computational and modeling implications are easy to miss until your model produces garbage results.
How the Third Law Of Dynamics Actually Works in Simulation
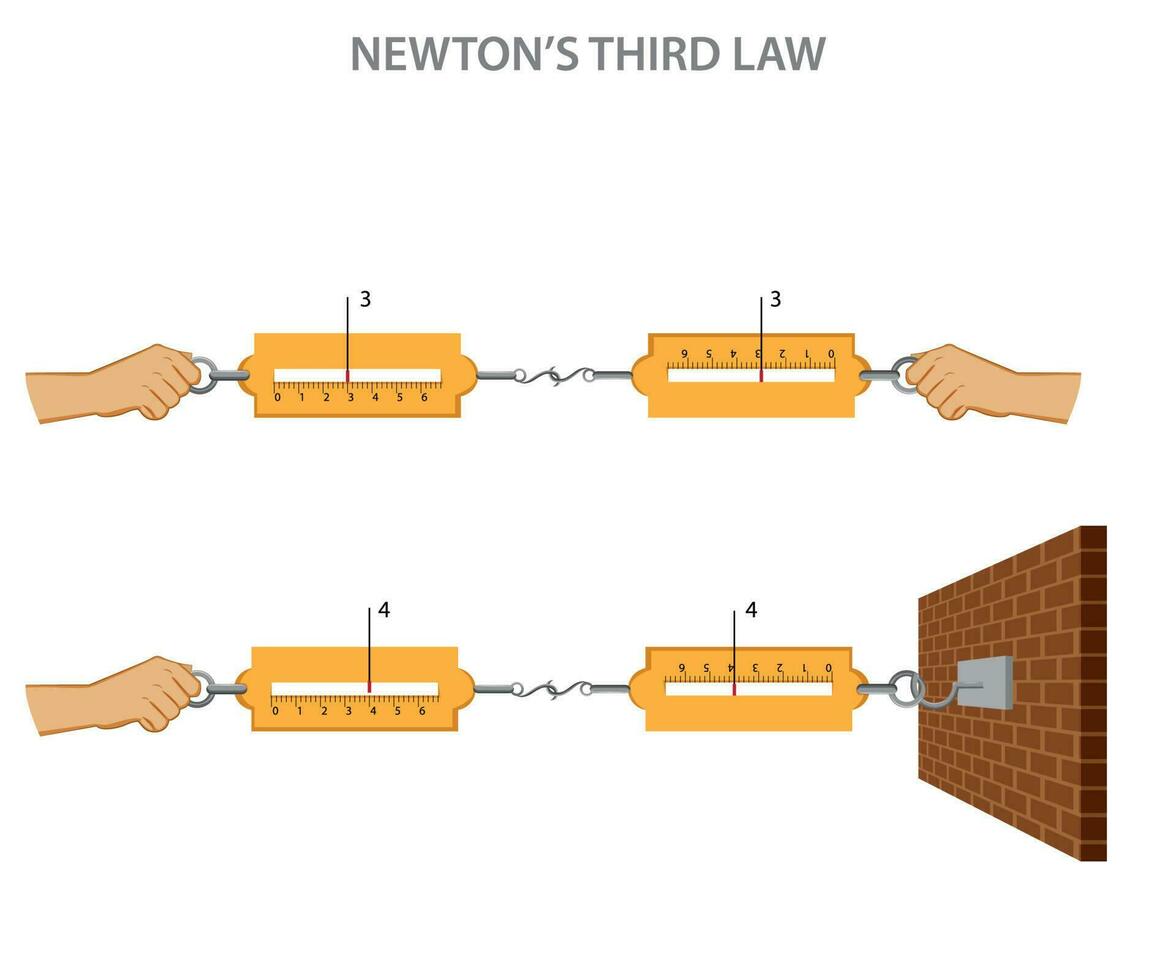
When you model any dynamic system — whether it's a robotic manipulator, a vehicle suspension, or a rigid body in a game engine — forces don't exist in isolation. If joint A exerts 50 newtons on link B, link B is simultaneously exerting 50 newtons back on joint A. Your solver has to track both. Most beginners set up their equations of motion using only the forward direction of force and skip the reaction side, which works fine for simple static cases but falls apart the moment you introduce constraints, contact, or feedback loops. Here's a concrete scenario I ran into last year. I was modeling a six-degree-of-freedom robotic arm interacting with a variable-stiffness end effector. The forward dynamics simulation looked correct for open-loop trajectories. But as soon as I closed the loop with impedance control and the arm made contact with a surface, the system became unstable. The simulation diverged after about 40 milliseconds. I spent three days tracking down the issue, and the root cause was that the contact forces from the end effector were being applied to the tip but the reaction forces weren't being propagated back through the kinematic chain to the base joints. The solver was essentially letting momentum leak out of the system. The fix was to make sure every contact impulse was dual-applied — both the action force at the point of contact and the equal reaction force distributed back through the Jacobian to every upstream joint. Once I did that, the simulation stabilized immediately. This kind of issue doesn't show up in any tutorial. You learn about it when your model blows up at 2 AM before a demo.
Setting Up a Dynamics Model That Respects the Third Law
Start with your equations of motion in the standard form: M(q)q_double_dot + C(q, q_dot)q_dot + G(q) = tau + J_transpose(q) * F_external. The key term here is J_transpose(q) * F_external. That transposed Jacobian multiplied by external forces is where the action-reaction pair lives. If you're computing external forces — contact, gravity perturbations, interaction forces — you need to make sure they enter through this term and that the reaction is felt throughout the system, not just at the point of application. For people building simulations from scratch, I'd recommend using a validated physics library rather than writing your own dynamics solver. PyBullet, MuJoCo, or Drake all handle the third-law propagation internally. If you're rolling your own using Lagrangian mechanics, double-check that your constraint forces satisfy both action and reaction at every timestep. A quick sanity test: run a free-fall simulation with no external forces except gravity. If your center of mass doesn't follow a clean parabolic trajectory, your reaction forces are wrong somewhere.
Get the Full Details

Common Pitfalls That Nobody Warns You About
One major issue is numerical drift in constraint enforcement. When you model contacts and joints as hard constraints, the solver enforces them using Lagrange multipliers. Over time, small numerical errors accumulate, and the action-reaction pairs become slightly unbalanced. In a short simulation this doesn't matter. Run it for 10 seconds or more and your object might start accelerating on its own or vibrating uncontrollably. The workaround is to use Baumgarte stabilization or position-level constraint correction rather than relying purely on velocity-level enforcement. It adds a small computational overhead but keeps things stable over long horizons. Another pitfall is treating the third law as purely local. In flexible-body dynamics or soft robotics, the reaction force doesn't just go to the adjacent link — it propagates through the entire deformable structure. If you're modeling a soft gripper or a compliant mechanism, you need to use finite element methods or modal reduction techniques that capture the distributed reaction. Simplifying it as a rigid-body reaction will give you qualitatively wrong behavior, especially around resonance frequencies. The third law of dynamics also breaks down in non-inertial reference frames if you're not careful. If you're computing dynamics from the perspective of a moving base — like a drone carrying a manipulator arm — you need to include the fictitious forces (Coriolis, centrifugal, Euler) explicitly. These aren't "real" forces in the Newtonian sense, but they're necessary for the equations to balance in that frame. Miss them and your controller will fight against forces that don't exist in the inertial frame, leading to poor tracking performance or instability.
When the Third Law Of Dynamics Doesn't Help You
There are legitimate cases where applying the classical third law literally leads you astray. Electromagnetic systems with retarded potentials don't satisfy action-reaction in the simple form because the field itself carries momentum. If you're modeling electromagnetic actuators or maglev systems, you need to account for field momentum separately. Same thing with relativistic systems — the simple equal-and-opposite force picture doesn't hold at significant fractions of the speed of light. In discrete element simulations with frictional contact, the third law is satisfied globally but can appear violated locally at individual contact points due to numerical approximations in the contact solver. This is especially noticeable in granular material simulations where hundreds or thousands of contacts are resolved per timestep. The overall momentum is conserved, but individual force pairs can be off by a few percent depending on your contact tolerance settings. If you need high accuracy at individual contacts, tighten your solver tolerances or switch to a more rigorous contact model like smooth convex optimization instead of penalty-based methods. For most practical engineering work — robotics, vehicle dynamics, structural analysis, mechanical design — the third law of dynamics is exactly as described and properly accounting for it separates models that run from models that don't. The trick is remembering that every force you put into the system has a counterpart you didn't think about, and ignoring that counterpart is usually why your results look wrong.