Working With Newton's Third Law in Real Problems
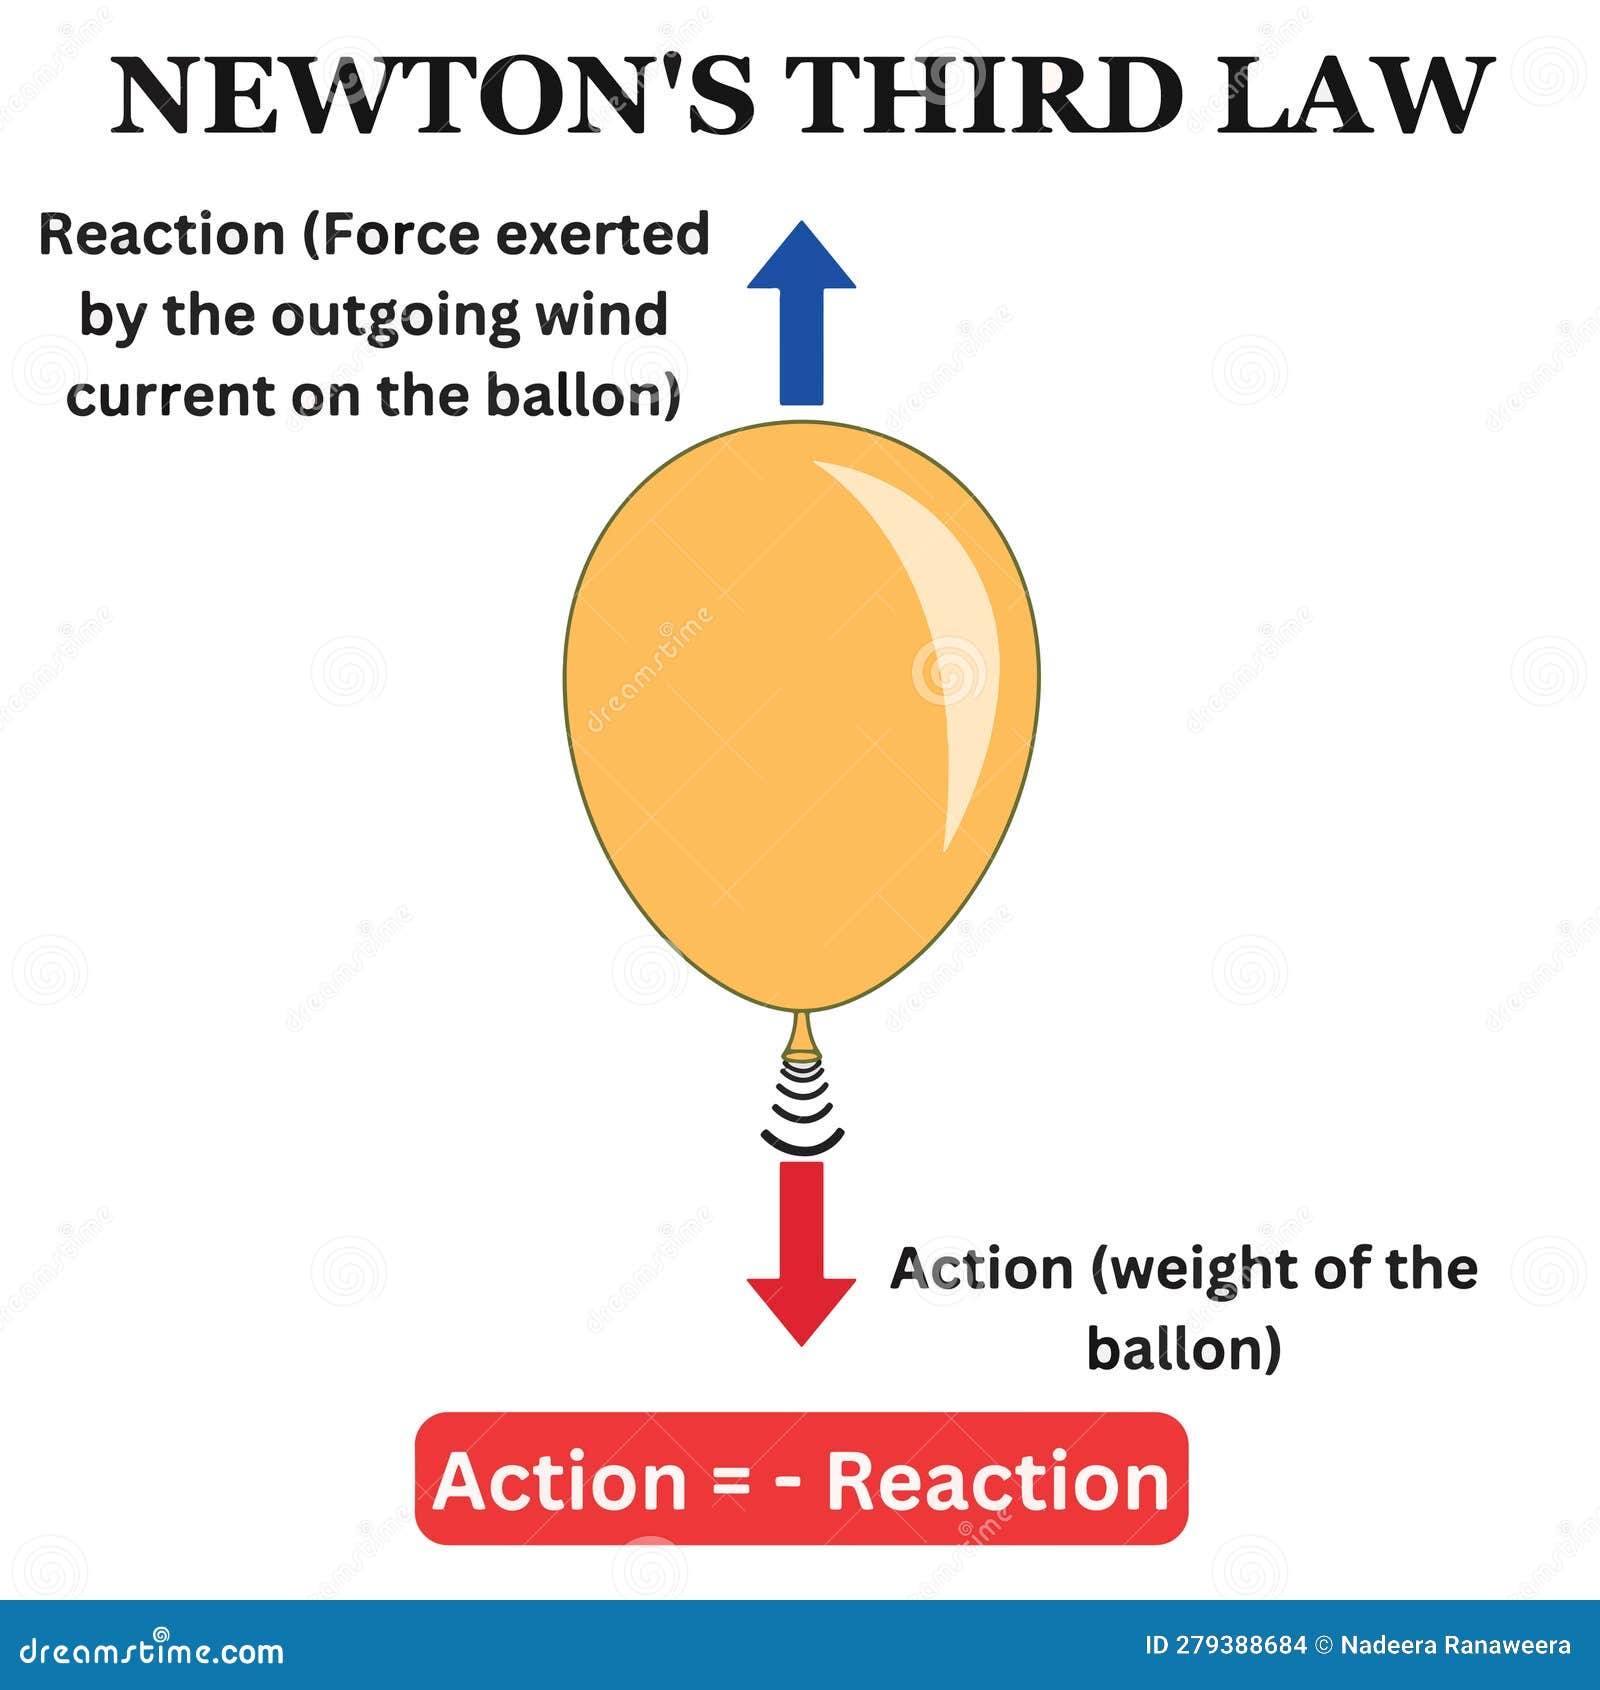
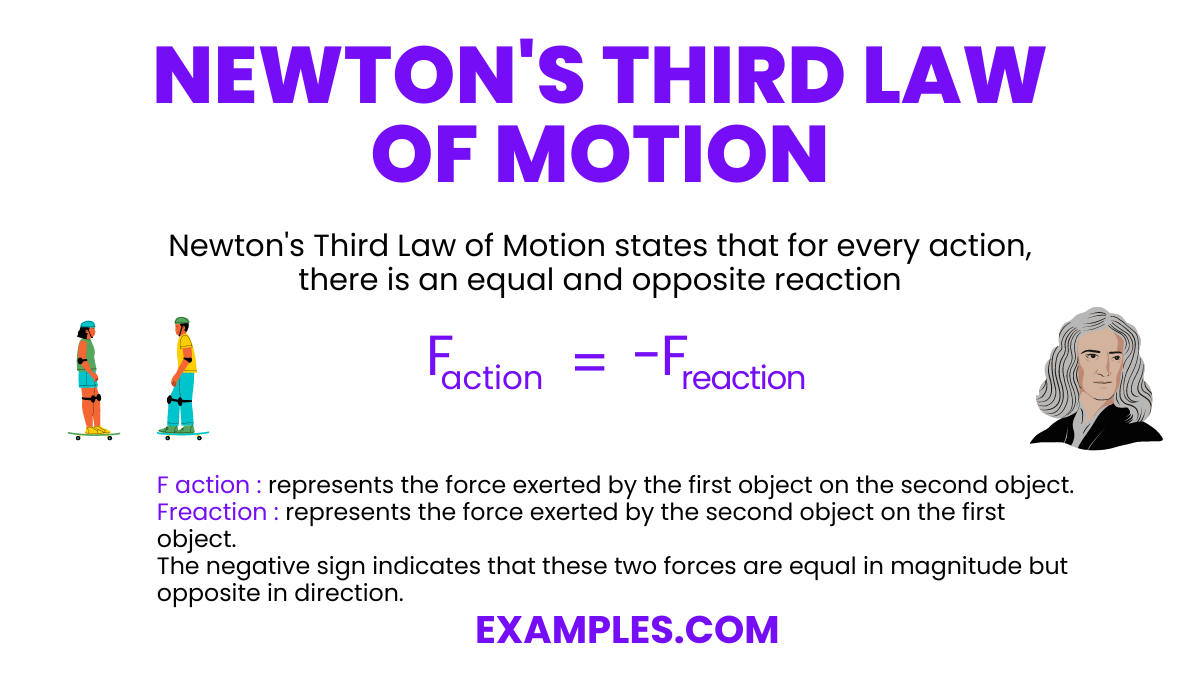
The formula itself is not complicated. Force A on B equals negative force B on A. Written out it looks like F_AB = -F_BA. That single line tells you two things: the magnitude is identical, and the direction is opposite. Everything after that is just making sure you apply it correctly when the problems get messy. I used to see students treat this law as a magic eliminator for free-body diagrams, and that gets you wrong answers fast. The law only guarantees equal and opposite forces between two interacting objects. It does not cancel forces on a single body. That mistake alone accounts for most of the errors I see in introductory mechanics courses.
Third Law Of Newton Formula Basics
Let me walk through how I actually solve these problems instead of reciting a definition. Start by identifying the interaction pair. Pick two objects, label them clearly, and draw the force each exerts on the other. Then assign directions carefully. If object A pushes object B to the right with a force of 50 newtons, object B pushes object A to the left with 50 newtons. Same number, opposite direction, different objects entirely. Here is a concrete example I use almost every time I need to build intuition quickly. Two blocks, block A sitting on top of block B, both on a frictionless table. You push block B horizontally with 30 newtons. Block A moves along with it without sliding because static friction between them provides the acceleration. The third law pair here involves the friction force on block A pointing forward and the friction force on block B pointing backward. Both have magnitude mu_s times m_A times g, assuming no slipping. You solve for the acceleration of the system using the total mass first, then back-calculate the friction force. That friction force is simultaneously the force accelerating block A forward and the force resisting block B's motion. I once worked on a project involving a robotic arm with multiple serial joints where a colleague tried to treat the reaction forces at each joint as internal and discard them from the dynamic equations. That approach failed because the arm was not in equilibrium and the internal joints had accelerations relative to each other. The workaround was to cut the model at each joint, draw separate free-body diagrams for each link, and explicitly include the action-reaction pair at every cut. It added maybe twenty minutes to the setup but prevented a cascade of errors that would have been far more painful to debug later.
One counter-intuitive point that beginners consistently miss involves normal forces. When you stand on a scale in an accelerating elevator, the scale reads your apparent weight, which is m times g plus m times the elevator's acceleration. The third law pair here is the force of your feet pushing down on the scale and the scale pushing up on your feet. These are equal at every instant regardless of acceleration. The reading changes because the normal force itself changes, not because the third law is violated. Another nuance that matters in practice is that the third law applies instantaneously. There is no delay between action and reaction. Some people confuse this with signal propagation limits in real materials, but Newtonian mechanics assumes rigid interactions for the purpose of these calculations. If you are working in a regime where wave propagation through the material takes a meaningful fraction of the problem timescale, you are already past the point where the simple third law formulation is sufficient and need to move into continuum mechanics or finite element analysis. The formula works cleanly for contact forces. Tension in a massless string is another pair. If a rope pulls a box to the right with tension T, the box pulls the rope to the left with tension T. The complication comes when the rope has mass or when friction exists along its length. Then the tension is not uniform, and you have to integrate or set up a differential equation. The third law still holds at every infinitesimal segment, but the simple constant-tension shortcut breaks down.
Get the Full Details
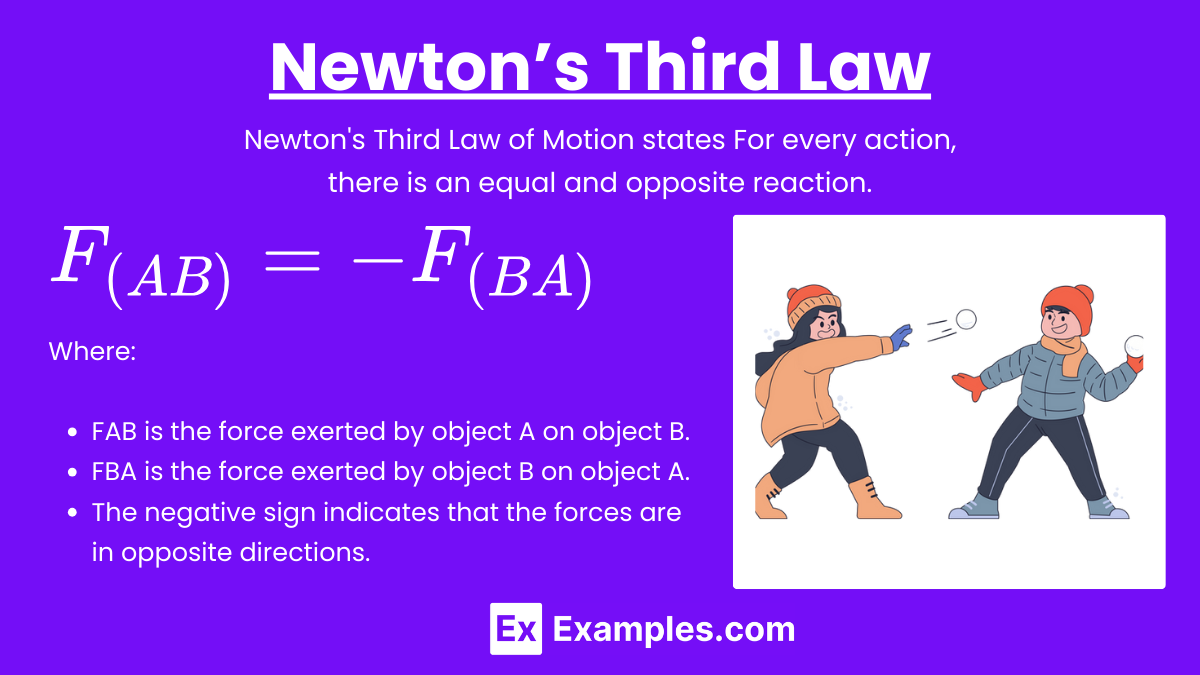
Where this law completely fails as a standalone tool is in non-inertial reference frames. If you attach yourself to an accelerating platform and try to apply F_AB = -F_BA without introducing pseudo-forces, your equations will not balance. The third law is frame-independent in the sense that the interaction pair is real, but solving the problem requires you to work in an inertial frame or correctly account for the fictitious forces. This is not a limitation of the law itself, but it is a very common source of error. I also want to flag a practical issue with measuring these forces experimentally. Force sensors have bandwidth limits and mounting compliance. When I tested impact forces between two steel spheres using piezoelectric load cells, the raw data showed oscillations that were artifacts of the sensor's natural frequency being excited by the impact. The third law held, but confirming it required filtering the signal and cross-checking with high-speed video tracking. Without that validation step, you could easily conclude the forces were unequal when the discrepancy was purely instrumental. The calculation process for typical textbook problems follows a pattern that becomes automatic with repetition. Identify all interaction pairs. Draw separate free-body diagrams. Assign consistent sign conventions. Write Newton's second law for each object independently. Substitute the third law relationships where forces connect the objects. Solve the resulting system of equations.
For a two-object collision problem, the third law pair is the contact force during impact. If you know the coefficient of restitution and the masses, you can find the post-collision velocities without ever calculating the contact force explicitly. The third law still underlies the momentum exchange, but including it in the algebra is unnecessary work. That is a judgment call that separates efficient problem solvers from people who just plug everything in mechanically. Here is the formula one more time in its most common forms so you have it written down. F_on_A_by_B equals negative F_on_B_by_A. The vector form makes the direction explicit. The scalar form works when you have already chosen a coordinate axis and assigned signs accordingly. Use the vector form when the geometry is complex. Use the scalar form when everything lies along a single line. If you are building simulations rather than solving paper problems, the third law gives you a free consistency check. In any multi-body dynamics code, the sum of internal forces should be zero at every timestep. If your numerical integrator is producing a drift in total momentum without external forces, something is wrong with your force implementation. I have seen this catch bugs that would have been invisible if you only checked individual force magnitudes.