Setting Up the Problem
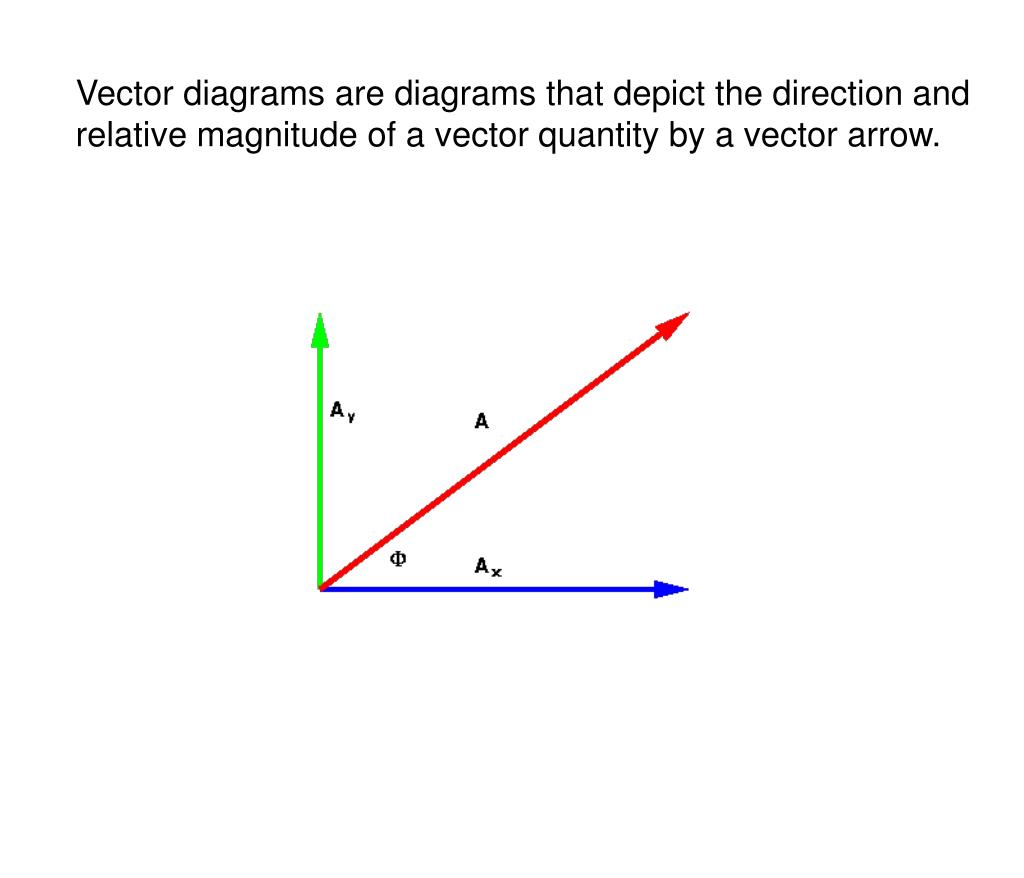
The way most people approach two-dimensional motion is backwards. They memorize kinematic equations for constant acceleration, then try to stuff every problem into that framework. It works until it doesn't, usually right around the point where air resistance enters the picture or someone asks you to work in polar coordinates. I learned this the hard way during my second year dealing with projectile problems where the launch angle and landing elevation weren't aligned with the standard textbook setup. What actually matters first is decomposing the problem into independent components along perpendicular axes. You treat x and y as separate one-dimensional problems that happen to share the same time variable. That's the core insight. Everything else flows from there.
Working Through Two Dimensional Motion And Vectors Properly
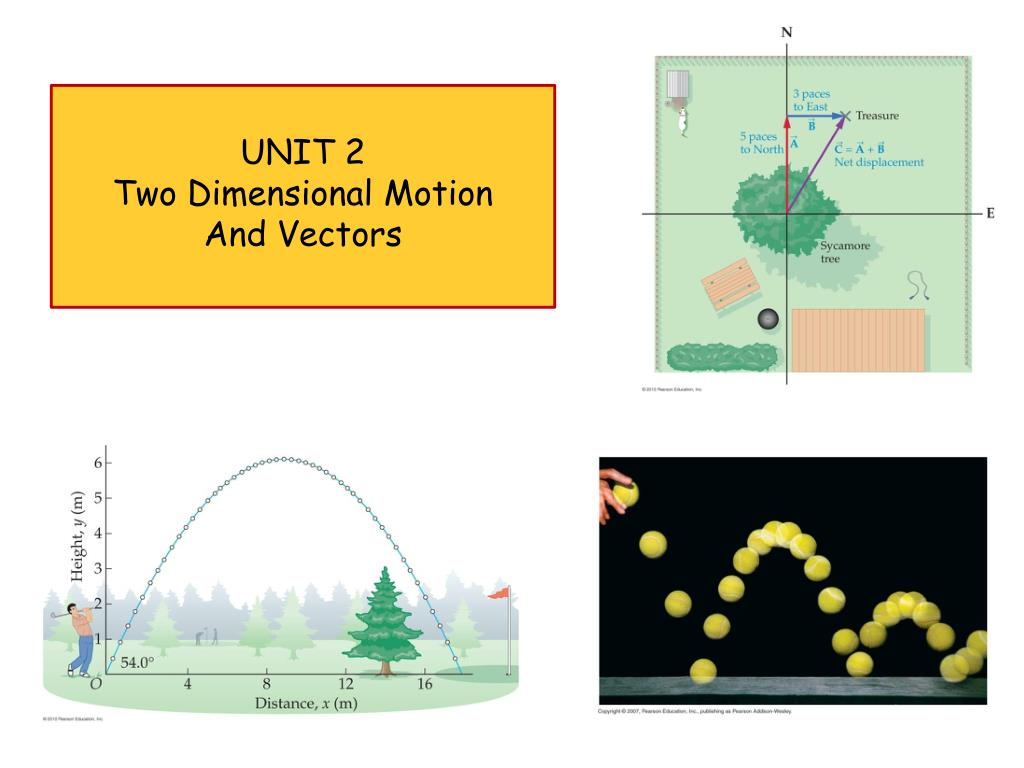
Here's the method I use now instead of jumping straight to equations. You write down what you know as vectors. Position, velocity, acceleration — all of it goes in component form before you touch a single formula. If a ball is launched at 30 meters per second at an angle of 40 degrees above horizontal, you immediately write vx = 30·cos(40°) and vy = 30·sin(40°). You don't plug numbers into a range equation. You establish the components and work from there. The reason this approach survives when the textbook ones break down is that it handles arbitrary initial conditions without modification. Change the launch point elevation. Add a constant wind acceleration in the x-direction. The component method still works because you've already separated the physics along each axis. I ran into a specific issue last year when modeling a particle moving under gravity and a drag force proportional to the square of velocity. The equations couple together — acceleration in x depends on the total speed, which depends on both vx and vy simultaneously. Standard kinematic formulas are useless here because acceleration isn't constant. What I ended up doing was stepping through numerically. I divided the trajectory into tiny time intervals, computed the velocity and acceleration at each step, and updated position incrementally. The code itself was about twelve lines. It solved in under a second and gave me results the analytical approach couldn't touch.
The Vector Component System
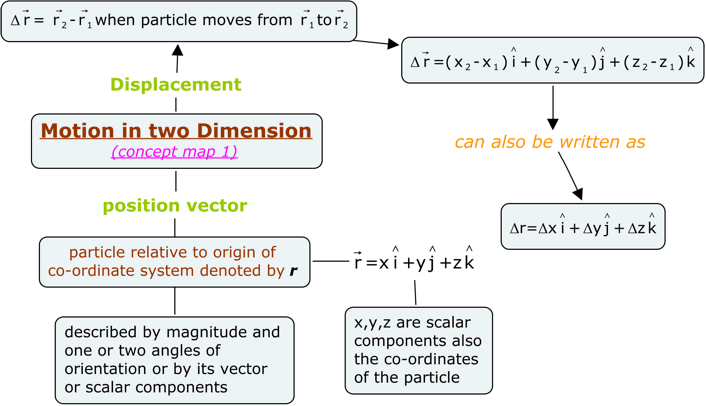
Vectors in two dimensions live naturally as ordered pairs. A displacement vector r = (rx, ry) tells you how far and in what direction something moved from a starting point. Velocity is just displacement per unit time, so it follows the same structure. Acceleration, if it varies, still fits — you just evaluate it at each moment rather than assuming it's fixed. Dot products and cross products matter when you need to project motion onto arbitrary axes or compute work and torque, but for pure kinematics you mostly use the components. The magnitude of a vector v = (vx, vy) is |v| = (vx² + vy²). The direction angle relative to the positive x-axis is = arctan(vy/vx), adjusted for the correct quadrant. Those two operations cover most of what you actually need. One thing beginners consistently mess up is the angle convention. Your calculator returns arctan(vy/vx) in the range negative ninety to positive ninety degrees. If your vector points into the second or third quadrant, the calculator gives you the wrong answer and you have to add or subtract 180 degrees yourself. I've seen this error propagate through entire problem sets before anyone caught it.
Get the Full Details
Common Pitfalls and What Actually Fails
The biggest trap is treating two-dimensional problems as if they require new physics. They don't. The equations of motion in two dimensions are exactly the same as in one dimension, applied independently along each axis. If someone tells you there's a special "projectile motion formula," recognize that it's just the kinematic equations with constant gravitational acceleration in y and zero acceleration in x, combined algebraically to eliminate time. Another failure mode is ignoring reference frames. If you're solving a problem where the ground itself is accelerating — say, a cart with a pendulum on it — your vector components in the lab frame and the cart frame will differ. Galilean transformation handles this cleanly: you subtract or add the relative velocity vector depending on which frame you're working in. For relativistic speeds, you'd need Lorentz transformations instead, but that's a different problem entirely. The component method breaks down when forces depend on the direction of motion in a way that couples the axes strongly and analytically. Quadratic drag is the standard example. The equations become differential equations that generally require numerical integration. I tried solving one analytically once using a substitution that turned out to be elliptic integral territory. Spent three hours only to realize the numerical approach would have taken twenty minutes. I switched to a simple Euler method with a time step of 0.01 seconds and got convergence within acceptable tolerance for the application I needed.
Practical Setup for Analysis
When you're working through a problem by hand, draw the vector diagram first. Mark the known magnitudes and directions. Resolve everything into components. Label the time variable t explicitly — it's the bridge between x and y. Then apply the appropriate kinematic relation along each axis: For constant acceleration in each direction, position as a function of time is r(t) = r + vt + ½a t² applied component-wise. Velocity is v(t) = v + at. These are vector equations written in scalar component form. You never combine x and y into a single expression unless you're computing a magnitude or dot product at the end. If acceleration isn't constant — which happens more often than textbooks suggest — you move to calculus-based methods or numerical approaches. The component decomposition stays the same. Only the time-integration step changes.
I usually keep a reference sheet with the standard forms handy, but I rarely use it during the actual problem-solving. The sheet exists for verification after I've worked through the setup. The real work is in correctly identifying what quantities are known, what's unknown, and which components are coupled. Get that right and the rest is mechanical. The limitation worth noting is that two-dimensional kinematics with constant acceleration only applies when forces are uniform across the domain you're analyzing. Near Earth's surface over short distances, gravity is approximately constant and this works well. Over long ranges or high altitudes, the variation in gravitational direction and magnitude becomes significant. In those cases, you'd model the trajectory as part of an orbital problem using central force equations instead, which is a completely different framework. Knowing when to switch models is more important than knowing either model by heart. For everyday engineering calculations — ballistics over moderate ranges, projectile trajectories in sports, basic vehicle dynamics on flat terrain — the component method with constant acceleration assumptions gives results within a few percent of measured values. When you need better accuracy, you add corrections one at a time. Air resistance, curvature of the Earth, the Coriolis effect. Each correction is a perturbation you layer onto the base solution rather than rebuilding everything from scratch.