How the Scripting System Actually Works on UR Arms
The scripting environment for Universal Robots is built around a language that sits somewhere between Python and C, shaped specifically for real-time robot control. It is called URScript, and it runs inside the robot controller alongside the graphical teach pendant interface. Most people never look under the hood because the point-and-click programming covers 80% of what a standard cell needs, but the moments that require something custom are exactly where the system shows its teeth. The primary syntax lives in .urp files and is interpreted at runtime by the robot's controller. You do not compile it into machine code beforehand, which is a design choice that makes sense for safety but has consequences for performance. The interpreter processes each line sequentially as the robot executes the program, and certain operations carry more runtime cost than you might expect from a desktop scripting language. Here is a basic structure most people will recognize if they have written any Python or C-style code before:
def main():
    set_digital_out(1, True)
    speedl([0.5, 0.5, 0.5, 0.5, 0.5, 0.5], 0.1, 0.01)
    movej([0, -pi/4, 0, -pi/2, 0, 0], a=1.5, v=1.2)
    set_digital_out(1, False)
end
The language is functionally oriented, but it borrows from structured programming. That distinction matters because error handling is limited. You get try-catch blocks in newer firmware versions, but they are narrow in scope and do not cover everything. I spent three days on a project a while back trying to write a continuous picking loop where parts arrived on a conveyor at irregular intervals. The obvious approach was a pure URScript polling loop reading the encoder feedback from the conveyor. The controller would stall the program thread on the read calls, and the motion smoothness degraded enough that the pick accuracy dropped below acceptable tolerances. What actually worked was offloading the conveyor synchronization to a separate PLC or a secondary microcontroller and using only digital handshake signals between them. The UR arm received a trigger, moved to a pre-positioned pick point, then awaited the next trigger. It reduced setup time to under two hours and eliminated the stuttering during continuous operation. That pattern comes up more often than people expect. The URScript interpreter is not designed for tight real-time loops over network or I/O operations. It handles motion well because motion instructions are prioritized by the controller's internal scheduler, but anything involving communication overhead will introduce unpredictable delays into your cycle time.
Practical Details Most Guides Skip
The floating point precision in URScript is single-precision (32-bit float), which means you can hit rounding errors when doing repeated kinematic calculations or when positioning to sub-millimeter tolerances over long paths. This is not a problem for most assembly work, but it becomes noticeable if you are doing precision insertion or adhesive dispensing where cumulative drift matters. Another thing that trips people up is the difference between movej, movel, and speedl. movej plans a joint-space trajectory, which is the fastest way to get from point A to point B but gives you no guarantee about the tool path through space. movel does Cartesian linear interpolation. speedl is a blended-motion directive you can insert between other moves to control velocity without triggering a full re-planning event. Blending is where a lot of cycle time gets saved, and it is also where a lot of people accidentally create violent motion spikes by setting the blend radius too aggressively. The blend radius parameter is measured in millimeters for Cartesian moves and in radians for joint moves. Confusing those two units in the same program will not throw an error. The robot will just execute something completely different from what you intended, and diagnosing why the arm is moving the way it does after a blend mismatch can take considerable time.
Get the Full Details

Variable scoping follows a simple rule: variables declared outside a function are global to the program, and variables declared inside a function are local unless you prefix them with the global keyword. There is no module-level namespace protection, so naming collisions between scripts are easy to create and equally easy to miss until runtime behavior looks wrong.
Where the Language Falls Short
It does not support object-oriented constructs, classes, or inheritance. You cannot define custom data types beyond what the built-in types offer, which are essentially floats, ints, booleans, strings, and the special Pose type for position and orientation pairs. You also cannot define your own exception types. Debugging complex logic becomes tedious because stack traces are minimal. The language has no built-in support for asynchronous multitasking. You can call scripts from scripts, but everything runs on a single thread within the controller's interpreter. If your program needs to wait for a sensor, a vision system, or a PLC handshake, you either poll with delays or structure your logic around state machines implemented manually through conditional branching. For heavy computation or complex logic, URScript is the wrong tool. The controller is not a general-purpose computer. It is a real-time motion controller first, and the scripting layer is deliberately constrained to keep execution predictable. Attempting to push it past that design intent usually results in programs that run fine in simulation and fail in production because timing behaves differently on actual hardware.
If your application demands substantial logic, state management, or communication orchestration, the practical solution is to keep the robot script thin. Use it only for motion primitives and I/O signaling, and put the decision-making layer on an external system. That is not a criticism of the language itself. It is recognizing what the platform was built for.
How to Write and Deploy Programs
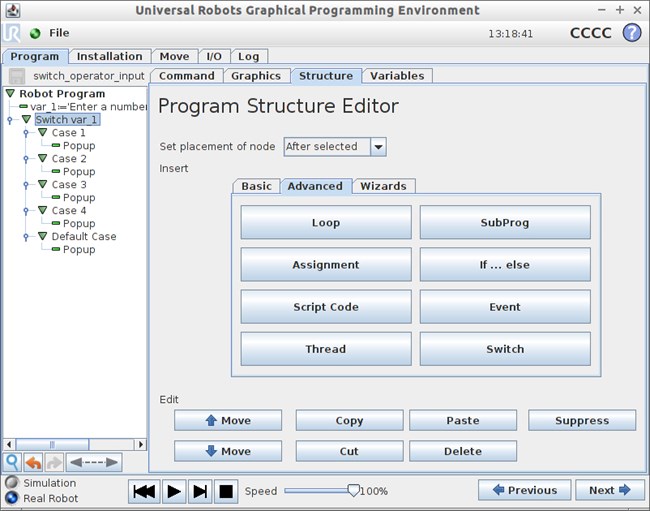
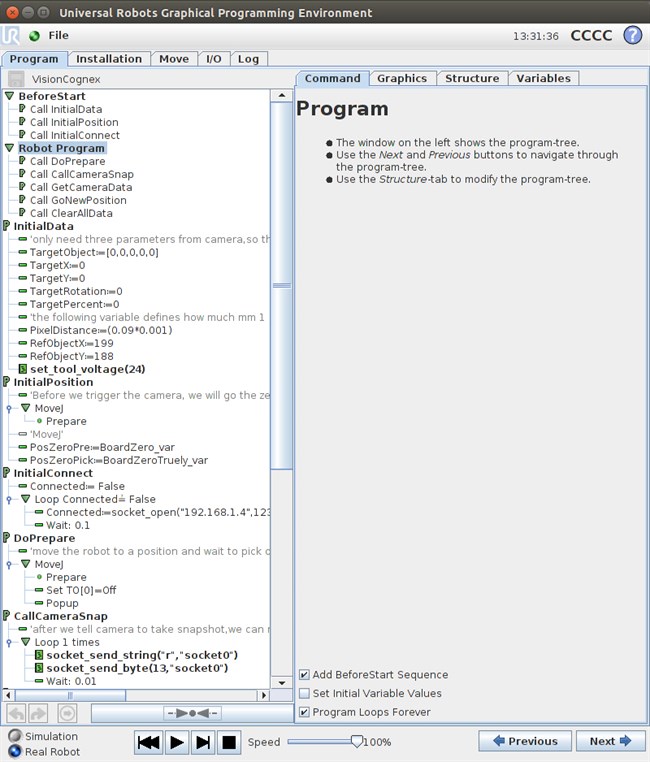
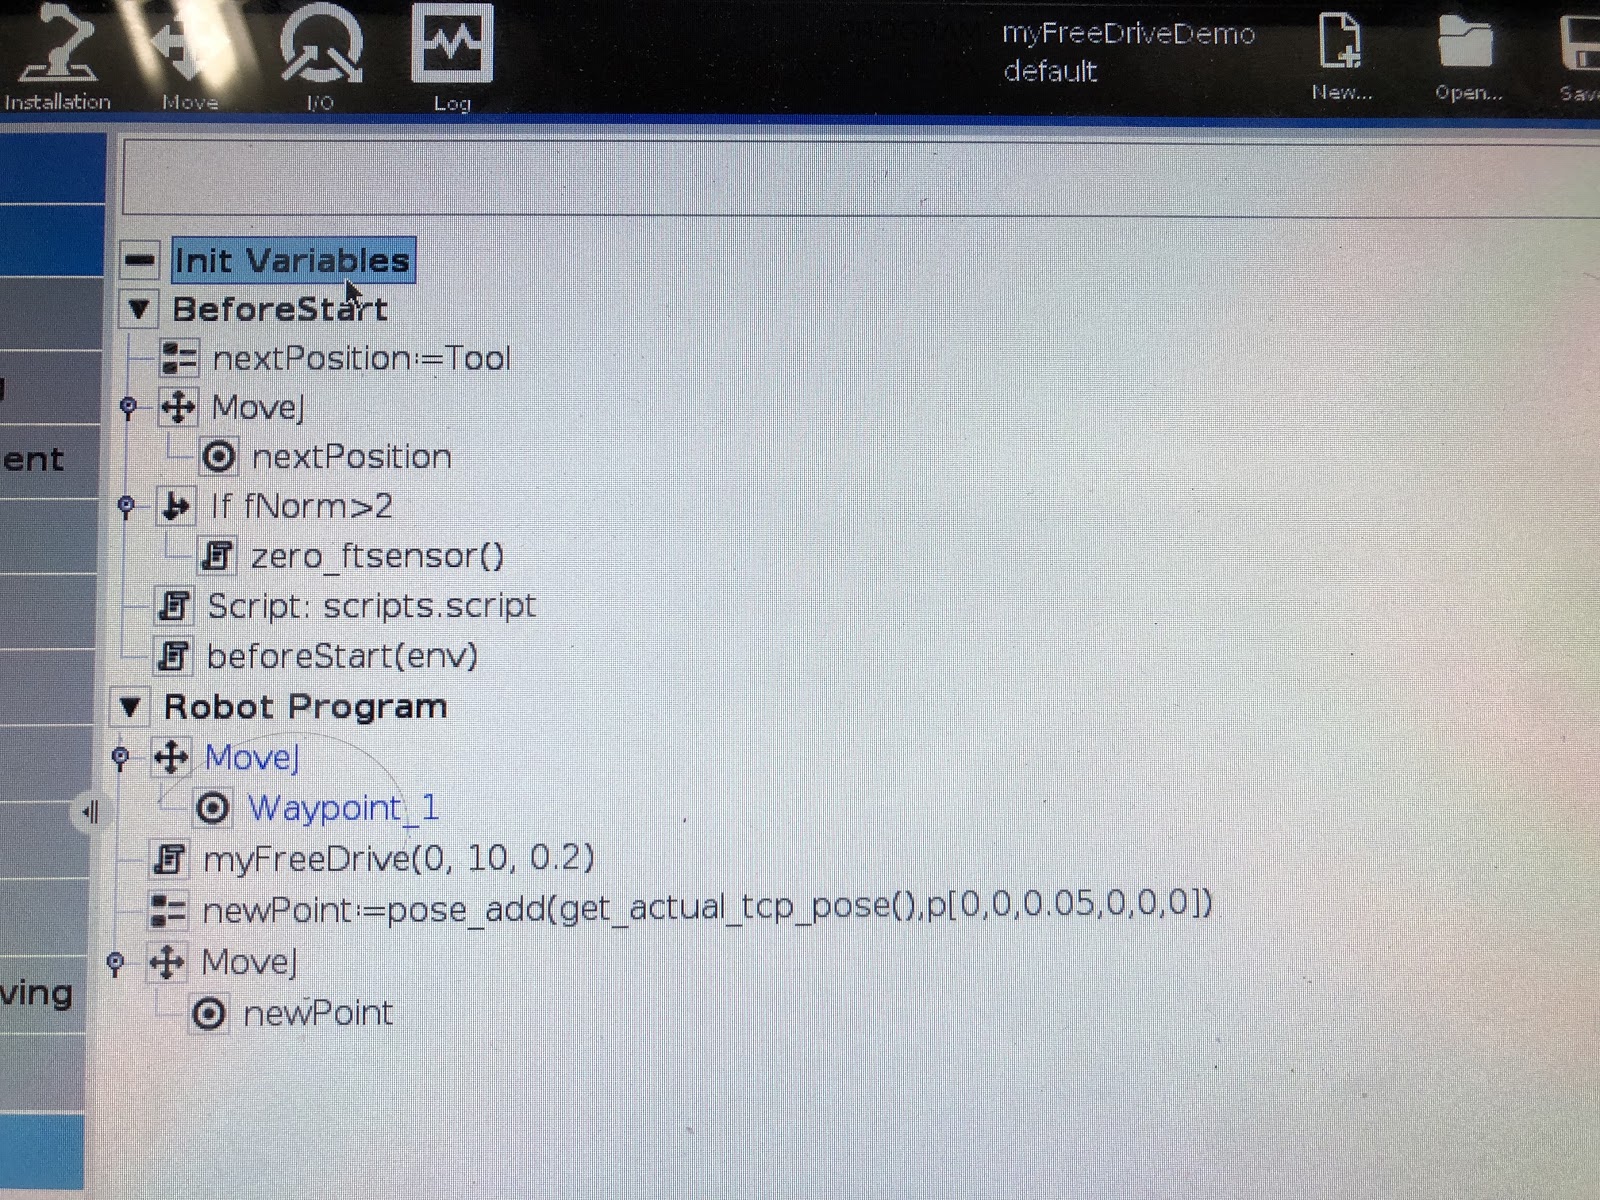
You write programs in the URScript editor inside the robot's web interface or thePolyscope teach pendant. The editor supports basic syntax highlighting and has a built-in interpreter that will catch some errors before you run the program, but it will not catch everything. Type mismatches, undefined functions, and logic errors often surface only at runtime. To deploy, you export the .urp file and load it onto the robot through the interface. The file contains both the program structure and the inline URScript. You can also reference external .urscript files from within a program, which helps with organization but introduces a dependency that can break if the referenced file is missing or has been modified on another machine. Version control is an exercise in frustration because URScript does not integrate with Git natively. People who need proper versioning typically export their programs as text, store them in a repository, and use a script or manual process to redeploy updates. It works, but it adds friction to any team that treats the robot code as a serious engineering asset rather than a disposable configuration.
If you are starting fresh and want to practice, the Universal Robots Programming Language documentation is available through the manufacturer's website, and the e-Series firmware update notes include the latest syntax changes. The simulator provided with the software package lets you run URScript without a physical robot, which is useful for validating logic before loading it onto hardware. The community forums and third-party wikis contain a lot of accumulated know-how, but the documentation quality varies. The official reference manual covers the built-in functions exhaustively, but it does not explain the runtime behavior in depth. You learn that stuff from running into the same boundaries other people have already run into.