So You Need to Pick Between Welding Vs Robot Welding
I spent about twelve years under an arc before ever touching a cell, and another eight setting one up and babysitting it. The decision between the two isn't really philosophical. It's usually just math, tolerances, and how much trouble you want to have tomorrow. Manual welding is exactly what it sounds like. A person holds a torch, feeds wire or rod, controls puddle dynamics by eye and instinct. Robot welding is a multi-axis arm following programmed paths with sensors or vision systems watching the joint. The gap between them has narrowed in some areas and widened in others over the last decade.
Where Welding Vs Robot Welding Actually Matters
Here is the thing most people gloss over. Robot welding is not automatically better. It is better at repeatable geometry at volume. Manual welding is better at anything that changes every thirty seconds or requires judgment on a marginal joint fit-up. Those are not opinions. That is physical reality. I once had a job with five hundred identical brackets to weld in eighteen hours. We set up a six-axis robot with a laser seam tracker and a contact tip sensing routine. The parts came in on a simple flip-over fixture. We ran it for fourteen hours straight. The first shift turned out about eighty good parts an hour once the parameters settled. A human would have been at best twenty-five parts per hour, and by hour four they were tired enough that quality drifted. The robot did not get tired. It did get a clogged contact tip once. We cleaned it in three minutes and kept going. The opposite happened with a custom exhaust fabrication shop. They wanted to automate their piping runs. The joints were always slightly different because the tube bending varied by a few degrees per piece. The robot kept missing the seam by up to two millimeters on the first pass. Laser tracking helped but the parts were not consistent enough for the system to recompute reliably without slowing everything down. We went back to manual MIG with a pulse setting for thin-wall tubing. It took longer but the rejection rate dropped to near zero.
So the basic split is repeatability and volume versus variability and adaptability. Anything below roughly two hundred identical units and manual welding usually wins on cost-per-part because the setup time for a robot cell eats the savings before you make them.
Get the Full Details

How Robot Welding Actually Works On a Shop Floor
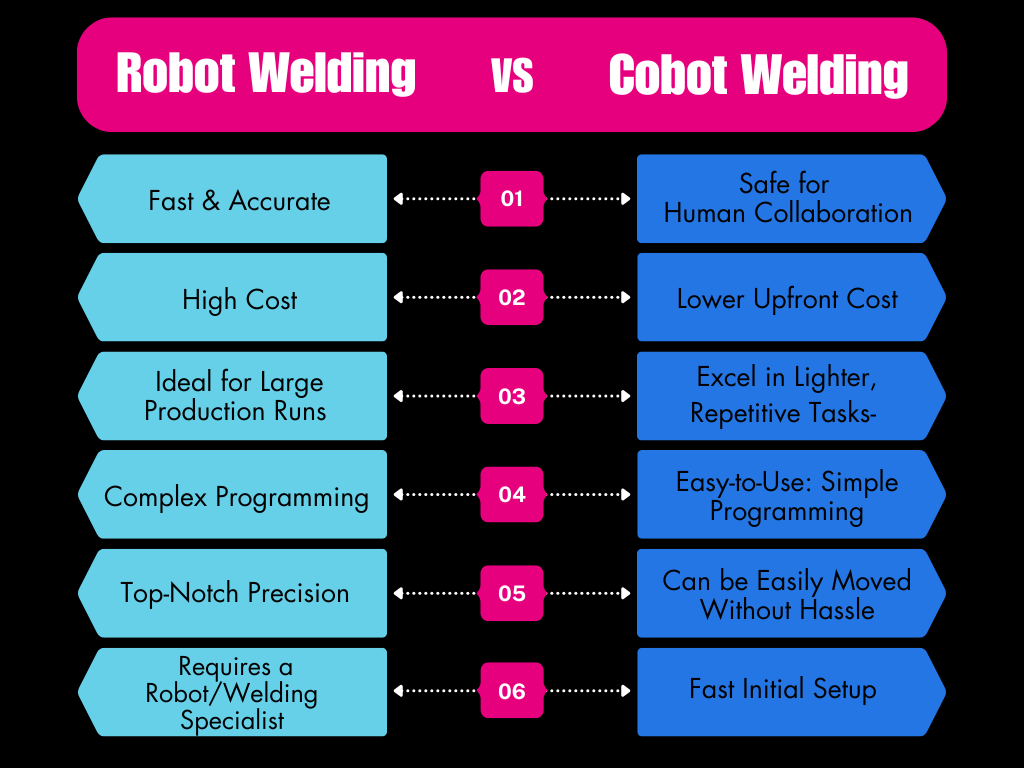
A robot cell is not just a robotic arm and a welder. It is a system. The arm, the controller, the power source, the wire feeder, the fixture, the safety fencing, the vision or laser tracker, and the programming interface all have to talk to each other correctly. If any link in that chain is sloppy, your welds will be sloppy. The robot does not fix bad inputs. You program the weld path by lead-through teaching or offline programming. Lead-through is when you physically guide the arm point by point while the controller records positions. Offline programming is when you build the trajectory in software from a CAD model and download it to the robot. Both methods have tradeoffs. Lead-through is faster for small programs and lets you feel the reach envelope. Offline programming is better for complex paths and avoids taking the cell offline while you teach. The weld parameters live in the power source, not the robot arm. The robot controls travel angle, work angle, travel speed, and oscillation. The wire feed speed and voltage come from the welder. You have to sync them or the arc length drifts and your penetrations become inconsistent. Most modern systems use a communication protocol like DeviceNet or Profinet to link the controller to the power source. If your integration is old and uses analog signals instead, you will fight drift constantly.
Seam tracking is the biggest upgrade you can add if your parts have fit-up variation. Laser triangulation scanners scan the joint ahead of the torch and shift the path in real time. Without it, you are betting that your fixtures hold parts within the robot positional tolerance, which is usually around plus or minus one millimeter over a short span. Most real-world fabrications do not hold that tight consistently. Even with laser tracking, you still need decent fit-up because the scanner can only compensate so much before the weld pool goes somewhere you do not want it.
What Manual Welding Still Does Better
Position flexibility is the obvious one. A human can weld overhead, vertical up, inside a tight corner, or on a part that cannot be rotated into a comfortable position. Robots prefer flat and horizontal positions. A six-axis arm can reach somewhat into overhead territory but the wire feed mechanics, contact tip geometry, and shielding gas coverage all degrade outside the horizontal range. You will see more porosity and poor bead appearance if you ask a robot to weld overhead regularly. Joint variety matters too. If your weld schedule includes TIG on stainless, oxy-acetylene brazing, and MIG on carbon steel in the same shift, a robot cell is not the right answer. Robots are specialized. You can swap end-of-arm tooling, but every change costs downtime and requalification. A welder can pick up a different machine and keep going within minutes. I dealt with a case where a shop tried to run thin-gauge aluminum sheet with a standard robot MIG setup. The heat input was too high and the parts warped. They moved to a pulsed MIG power source with a syncronic feeder and added a thermocouple loop to limit cumulative heat. It worked better but the cycle time nearly doubled. A skilled manual TIG operator could have done the same parts in less time with less distortion. Sometimes the human hand is the sensor the machine cannot replicate.
Another thing people forget is repair work. You cannot program a robot to go find a crack on a structural beam in the field and weld it. Manual welding covers maintenance, rework, and one-off fixes that never repeat exactly.
Common Pitfalls in Both Approaches
With manual welding, the pitfall is usually inconsistency across shifts. Operator A might run at twenty-four inches per minute with eighteen volts. Operator B will run different parameters on the same joint and produce a different profile. Certification testing levels this somewhat, but production reality rarely matches test conditions. Your QA process needs to catch that drift before it becomes scrap. With robot welding, the pitfall is usually overconfidence in the program. A robot will happily follow a bad path as fast as a good one. If the joint gap is inconsistent and you do not have seam tracking, the robot will arc strike in the gap or dig into the root on the first pass and refuse to recover. I once saw a cell run for two hours producing porosity because the operator changed the shielding gas mix to save money without updating the wire feed schedule. The robot kept running at the old parameters. The welder did not notice because the arc looked fine. The X-ray showed it later. Always verify parameters after any material or gas change. A five-minute check saves a lot of rework. Another pitfall is fixture wear. The robot repeats perfectly. If the fixture is worn, the robot repeats the bad position perfectly. Inspect fixture locators weekly if you run high volume. It takes ten minutes and prevents batches of bad parts.
The Economics of Welding Vs Robot Welding
Manual welding labor costs dominate. In the US, a competent MIG welder costs roughly twenty-five to forty-five dollars per hour fully loaded with benefits and overhead. Productivity varies widely but ten to twenty inches of deposited weld per minute is a sane production range for most structural work. A robot cell has a much higher upfront cost. A basic six-axis arm with a MIG package, fixture, and fencing runs about sixty thousand to one hundred twenty thousand dollars installed. Programming and integration can add another fifteen to thirty thousand depending on complexity. The payback period depends entirely on volume. At two hundred identical parts per week, a well-tuned cell can pay for itself in eight to fourteen months. At fifty parts per week, you are paying for the robot for years and still spending more per part than a manual welder. Running costs for a robot cell include contact tips, nozzles, wire, gas, and occasional maintenance contracts on the arm. A typical cell might consume two thousand to five thousand dollars in consumables per year at moderate volume. Labor drops to one operator monitoring three or four cells instead of welding directly. That operator costs less per hour than a full-time welder and handles more runtime.
Down time is where robots hurt. If the cell goes down, the whole line stops. A manual welder can keep working on another part while someone else fixes the equipment. For small shops with one or two machines, that single point of failure is real. For large lines with redundancy, it matters less.
When to Choose What
Choose manual welding when the part count is low, the joint geometry varies, the material is thin or sensitive to heat input, the position is awkward, or the work is field-based. Choose robot welding when you have high repeat volume, consistent part fit-up, flat or horizontal weld positions, and enough throughput to absorb the setup cost. Hybrid is also common. Some shops robot-weld the repetitive structural seams and hand-finish the critical detail joints. The line between the two keeps shifting as sensors improve and programming gets easier. But the physics has not changed. Robots repeat. Humans adapt. Know which one your job actually needs before you buy anything.