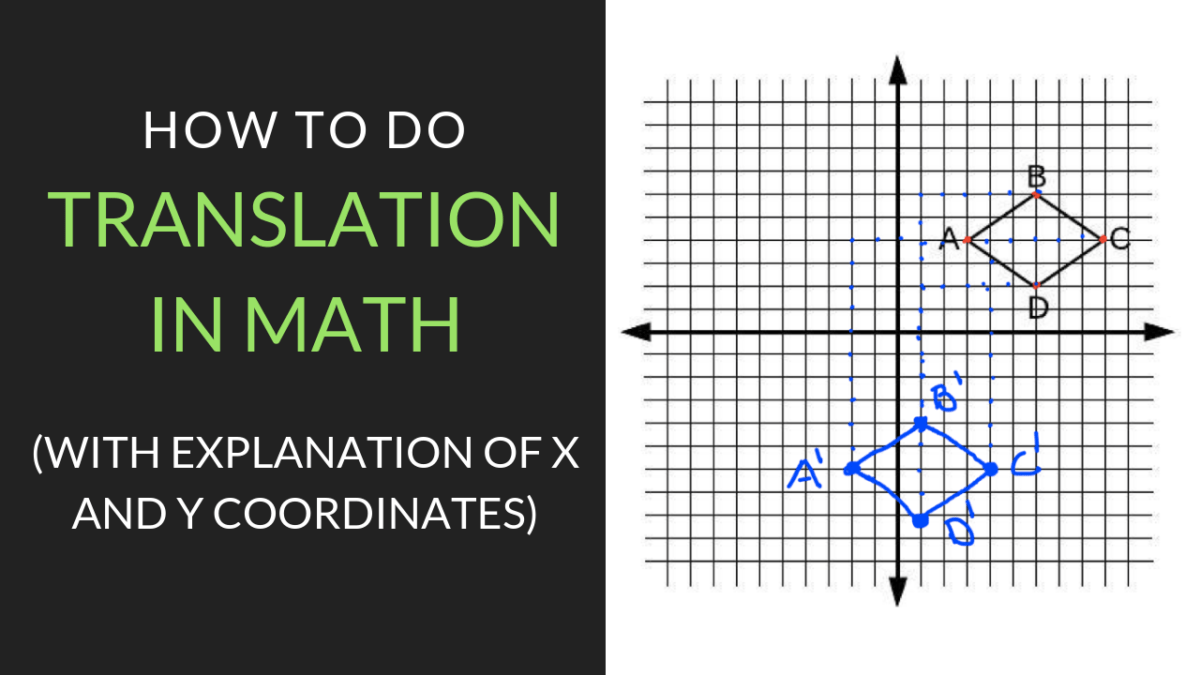
Let's Talk About Translation in Math
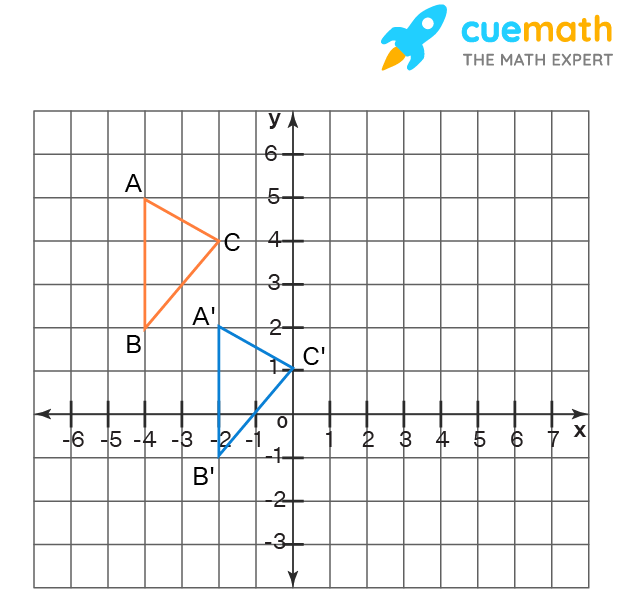
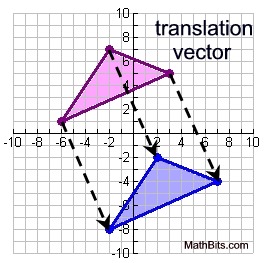
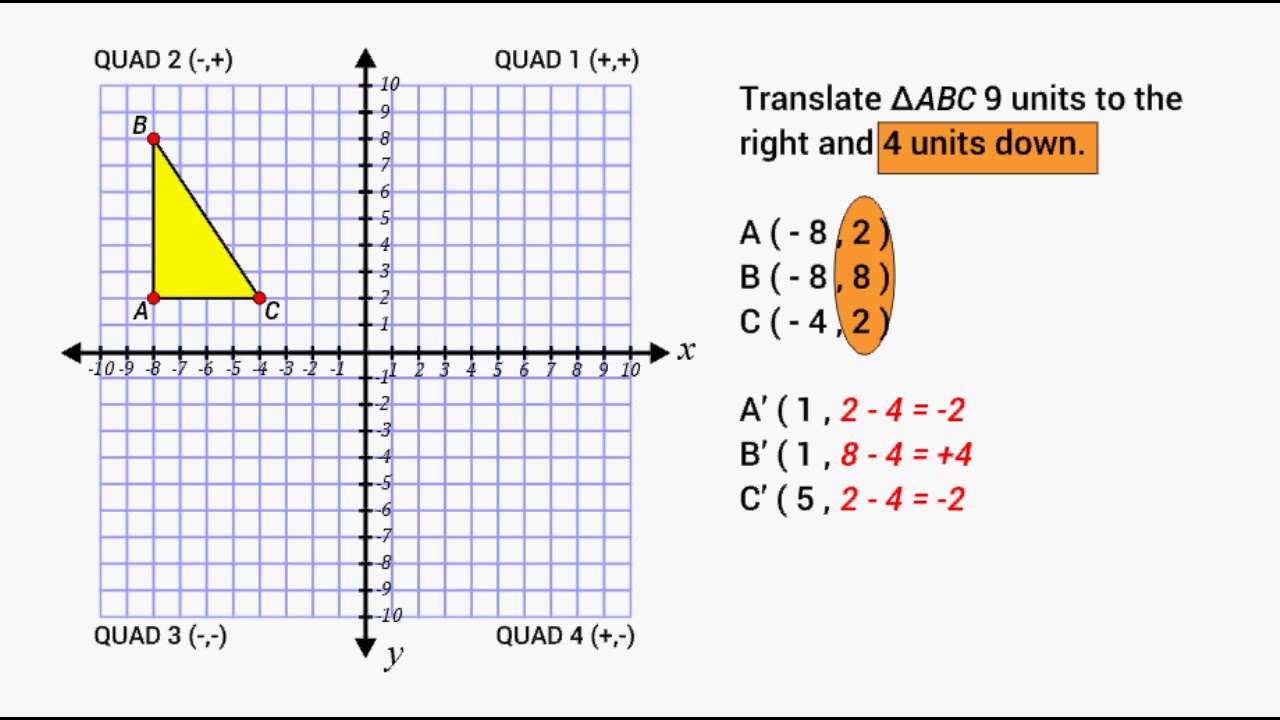
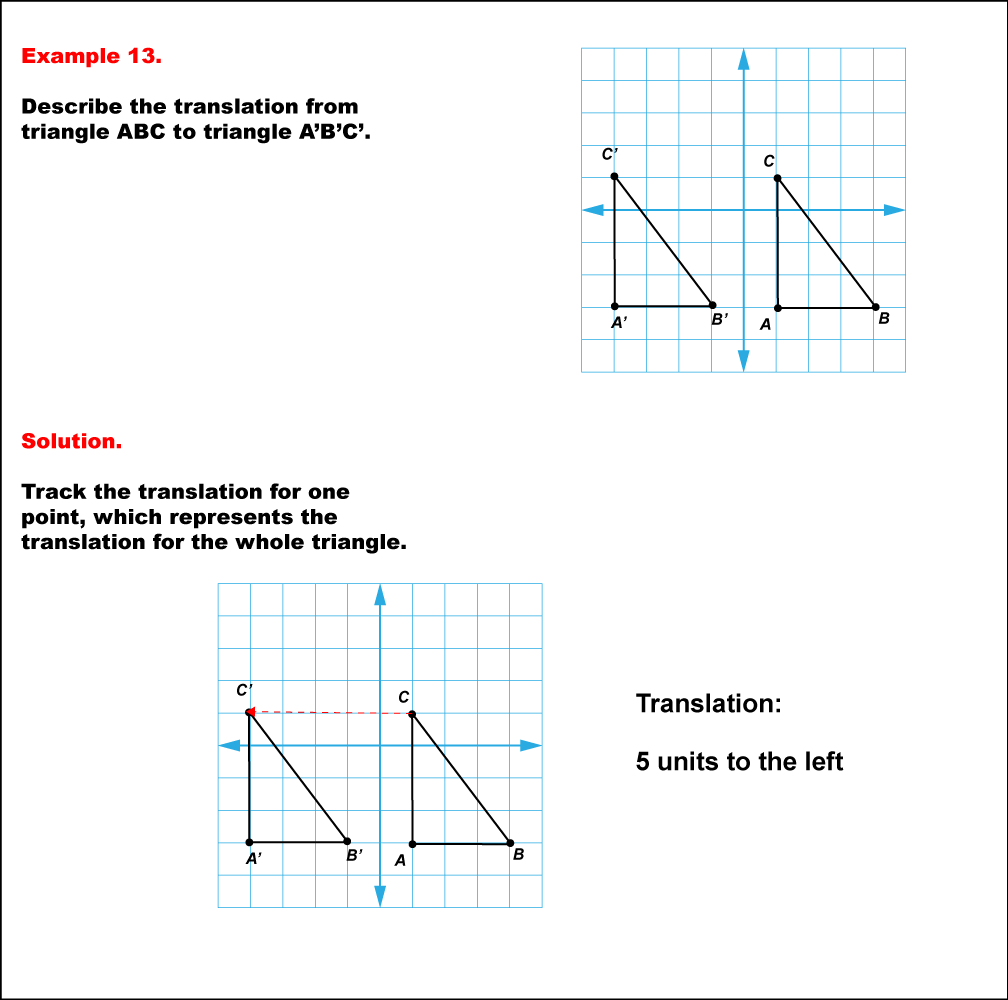
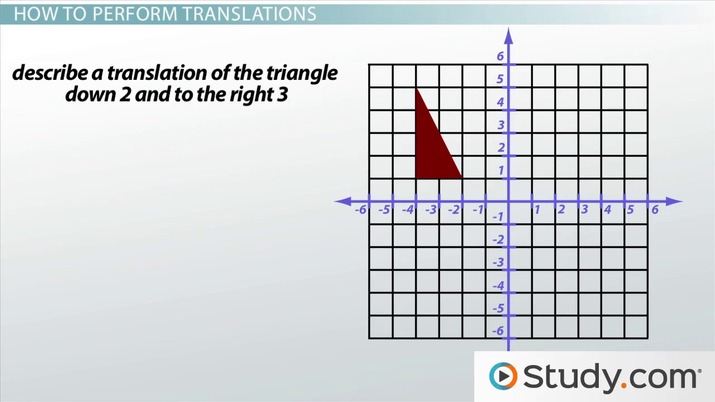
Translation in math refers to a geometric transformation that moves every point of a shape or figure by the same distance in the same direction. It does not rotate the shape, flip it, or resize it. The resulting figure is called the image, and it remains congruent to the original figure, meaning all side lengths and angle measurements stay exactly the same.When students encounter this concept, the first thing they learn is that translation operates like a simple slide across the coordinate plane. You pick a vector, apply it to every vertex, and you are done. The vector tells you how far to move horizontally and how far to move vertically. If the vector is (3, -2), every point moves three units to the right and two units down. That is the entire mechanism. The formal definition involves function notation. If you have a point P(x, y) and a translation vector T = (a, b), the image P' has coordinates (x + a, y + b). This is typically introduced in middle school geometry, but the mechanics extend into linear algebra and computer graphics where translation is represented using homogeneous coordinates and 3x3 matrices. In standard Cartesian coordinates, translation is not a linear transformation because it does not preserve the origin. The origin always moves unless the translation vector is zero. This is a detail that trips people up later when they encounter affine transformations versus linear transformations in college-level courses. I worked with a student a few years ago who was trying to translate a triangle with vertices at (-4, 7), (1, 3), and (6, 8) by a vector of (-3, 5). She kept getting the third coordinate wrong, producing (6, 13) instead of (3, 13). The issue was that she was adding the y-component of the vector to the original y-coordinate instead of replacing it. She was doing 8 + 5 = 13 and writing it as the y-value without also adjusting the x-coordinate. The correct result is (3, 13). I had her redraw the triangle on graph paper and physically slide it by the vector. The visual correction fixed the problem faster than any amount of re-explaining the formula. This happens more often than you would expect, especially when students are rushing through worksheets.
Translation preserves orientation. This is important and not always obvious to beginners. If you walk around the perimeter of the original figure clockwise, you will walk around the translated figure clockwise as well. Reflections reverse orientation. Rotations preserve it. Translation sits in the same camp as rotations and dilations in that regard. Confusing translation with reflection is one of the most common mistakes on standardized tests. A reflection across the line y = x, for example, takes a point (x, y) and turns it into (y, x). Translation just adds constants. The two operations look completely different in their algebraic form, but visually they can appear similar if a student is not paying attention to which coordinate is being swapped versus which is being shifted.
Common Pitfalls and How to Avoid Them
One issue that comes up repeatedly is the order of operations when multiple transformations are applied. Translation does not commute with rotation in general. If you translate a point and then rotate it around the origin, you get a different result than if you rotate it first and then translate. The order matters. Many textbooks present these operations in sequence without emphasizing this point clearly enough. I usually tell students to work from the inside out when compositions are written as functions, applying the rightmost transformation first. Another subtle point involves translations in the context of function graphs. If you have f(x) = x^2 and you want to shift the graph two units to the right and three units up, the new function is f(x - 2) + 3, which expands to (x - 2)^2 + 3. Students frequently write f(x + 2) + 3 when asked to shift right, because they associate the minus sign with leftward movement in their heads without tracking the actual substitution. This is a convention issue that deserves more attention than it gets. Writing the rule as "replace x with (x minus the horizontal shift)" rather than memorizing left-add-right-sub solves the problem entirely. Translations in three dimensions work the same way. You add the components of a 3D vector to each coordinate: (x, y, z) becomes (x + a, y + b, z + c). This extends directly into 3D modeling software, robotics kinematics, and any field that deals with rigid body movement in space. The mathematical structure is identical, just with an extra dimension.
Get the Full Details
Practical Applications
In computer graphics, translation is one of the most basic transformation operations. Every time a sprite moves across a screen in a video game, a translation matrix or vector is being applied to its position coordinates. The performance impact is negligible because the operation is simply addition. GPU pipelines handle this at the vertex shader level, and modern hardware can process millions of translations per frame without any noticeable overhead. In engineering and physics, translation appears in kinematics problems where an object moves from one position to another without rotating. The displacement vector is a direct application of translational motion. When analyzing forces on a rigid body, engineers often separate the motion into translational and rotational components. The translational part follows Newton's second law directly: F = ma, where a is the acceleration of the center of mass. This decomposition is standard practice in dynamics courses and is critical for solving real-world problems involving moving structures. One edge case worth noting involves translations in non-Euclidean geometries. On a sphere, for example, the concept of translating a figure by a fixed vector is not well-defined in the same way because parallel lines do not exist globally. Great circles converge. This is something that comes up in differential geometry and general relativity, but it is worth knowing early that the intuitive notion of translation breaks down outside flat space. If you are working with geographic coordinates or orbital mechanics, the standard (x, y) (x + a, y + b) rule does not apply.
A Note on Tools and Calculators
Graphing calculators and online tools can perform translations automatically, but relying on them without understanding the underlying mechanism creates gaps in reasoning. When a test asks you to find the image of a polygon under a translation and then prove that corresponding sides are parallel, a calculator gives you the vertices but not the justification. You still need to compute slopes and show that m1 = m2 for each pair of corresponding sides. This proof step is where points are lost, not in the coordinate calculation itself. For quick verification, I recommend plotting both the original and translated figures on the same grid and visually confirming that the vector connects each pre-image point to its image. This visual check catches arithmetic errors that a purely numerical approach might miss. It also reinforces the geometric intuition that translation is rigid motion.