Understanding Net Force Without the Textbook Bloat
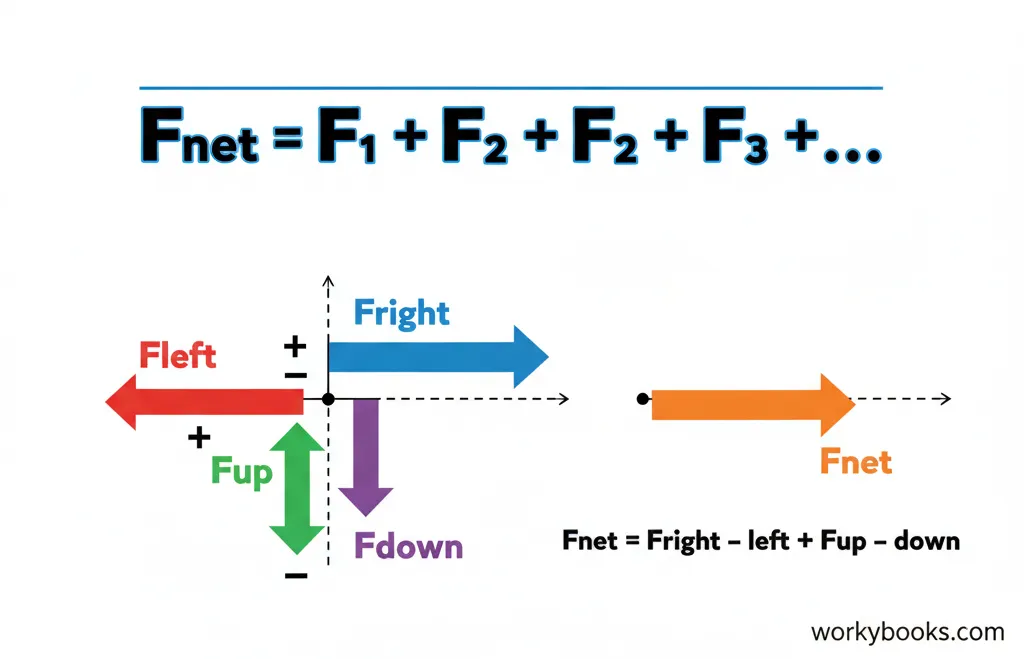
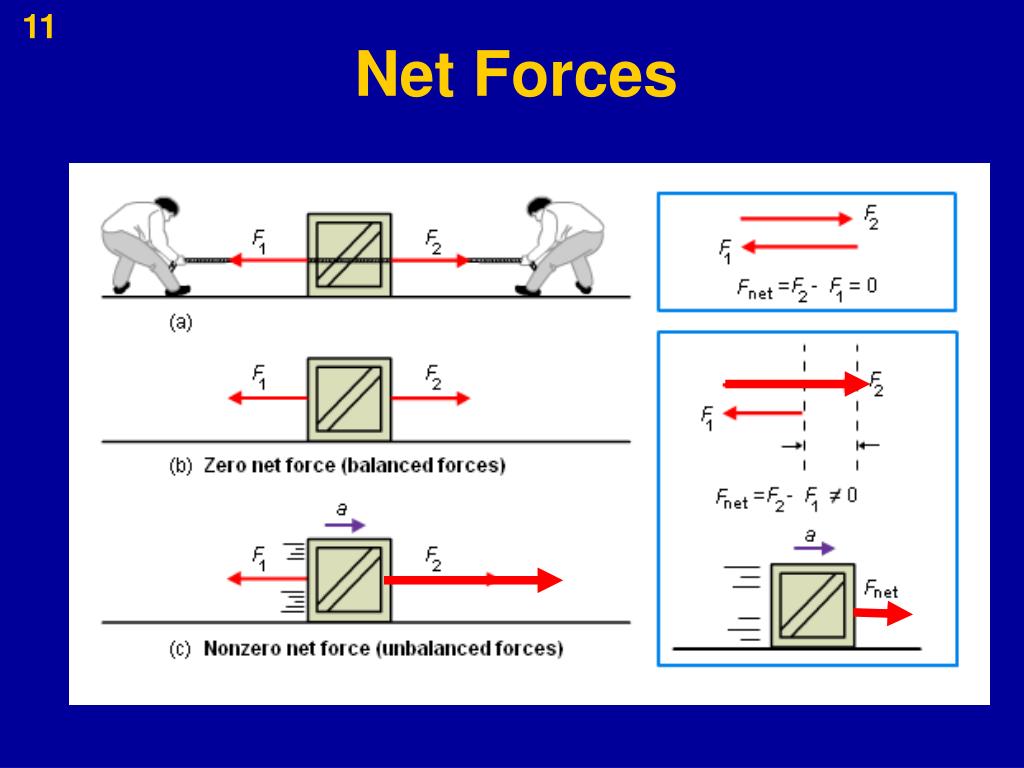
Net force is just the total force acting on an object after you add up all the individual pushes and pulls. That's really it. Everything else you see online is overcomplicating it. In practice, you resolve every force into x and y components, sum them separately, and then recombine them if you need a magnitude and direction. F_net = ma is the equation, but the real work is in getting the free-body diagram right. I used to watch students skip that step and jump straight to plugging numbers into F=ma. It always fell apart. A block on an inclined plane with friction is where people get chewed up. You've got gravity pulling down, the normal force perpendicular to the surface, friction opposing motion, and sometimes an applied force at an angle. If you don't decompose gravity into parallel and perpendicular components relative to the ramp, your answer will be wrong and you won't know why.
What Is A Net Force in Practice
When I was debugging simulation code for a robotics project a few years back, I ran into a case where two forces of equal magnitude were acting on opposite sides of a rigid body but not along the same line. The net force was zero, so the center of mass didn't accelerate. But the body was spinning like crazy. Beginners often miss this entirely because they conflate net force with net effect. Zero net force doesn't mean nothing happens. It means no translational acceleration. Rotational effects still exist. Another thing nobody warns you about: friction direction depends on the net force component parallel to the surface, not on which way the object is currently moving. If you push a heavy crate lightly and it stays still, static friction matches your push exactly. The moment you exceed the static threshold, kinetic friction takes over and it's usually lower. I spent a solid afternoon chasing a bug where my controller assumed kinetic friction from the start, and the simulation behaved nothing like the real system. Here's how I actually work through these problems now without wasting time. Write out every force acting on the object. Label each one. Resolve everything into components along your chosen axes. Sum the x-components to get F_net,x and the y-components to get F_net,y. The magnitude is the square root of the sum of squares. The direction is arctangent of y over x. That's the full procedure. Any shortcut that skips component resolution is going to fail you on anything beyond the simplest cases.
The biggest pitfall is coordinate choice. Pick axes that align with the problem geometry. On an incline, tilt your axes so one runs parallel to the ramp and the other perpendicular. You'll avoid having to decompose the normal force or friction, which saves about ten minutes per problem and reduces errors significantly. I've seen people use horizontal and vertical axes on inclined planes and end up with three components instead of one. That's unnecessary work. There are cases where this approach breaks down. Non-inertial reference frames, for example. If you're analyzing forces from inside an accelerating car, you need to introduce fictitious forces like the centrifugal or Coriolis terms. Newton's second law in its standard form doesn't apply directly. I had a student once try to solve a problem from the perspective of a rotating platform without adding the pseudo-force, and the results were completely nonsensical. If your frame is accelerating, either switch to an inertial frame or add the fictitious forces. Pick one and stick with it. Another limitation: net force as a single vector only tells you about translational motion. For extended bodies, you also need to consider torque. Two equal and opposite forces can produce zero net force but nonzero net torque. If you're designing something like a robot arm or a bridge truss, ignoring rotational equilibrium gets you failures. Check both sum of forces and sum of torques. They're independent conditions and both must be satisfied for static equilibrium.
Get the Full Details
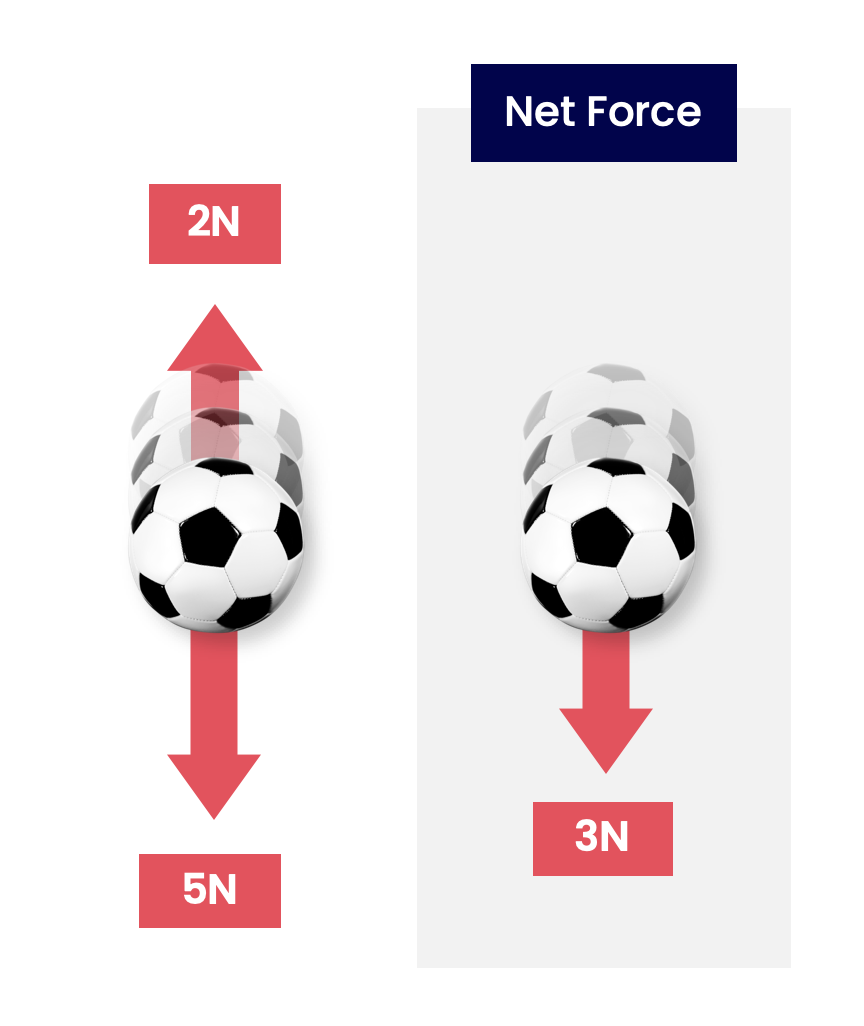
I keep a quick reference sheet with the common force types and their formulas: weight is mg downward, normal force equals the perpendicular component of other forces on a flat surface, kinetic friction is mu_k times the normal force, static friction is anything up to mu_s times the normal force, spring force is -kx, and drag is proportional to velocity squared at high speeds or velocity at low speeds. Having these memorized means you spend less time looking things up and more time setting up the actual problem.