Understanding Vectors Without the Textbook Fluff
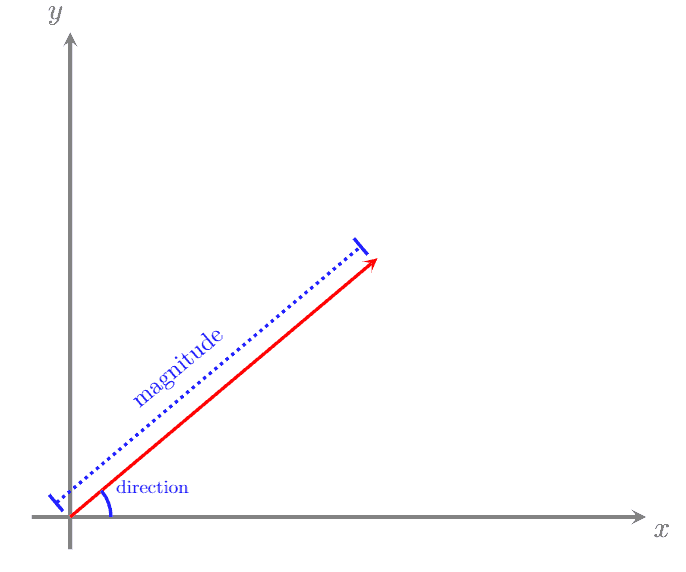
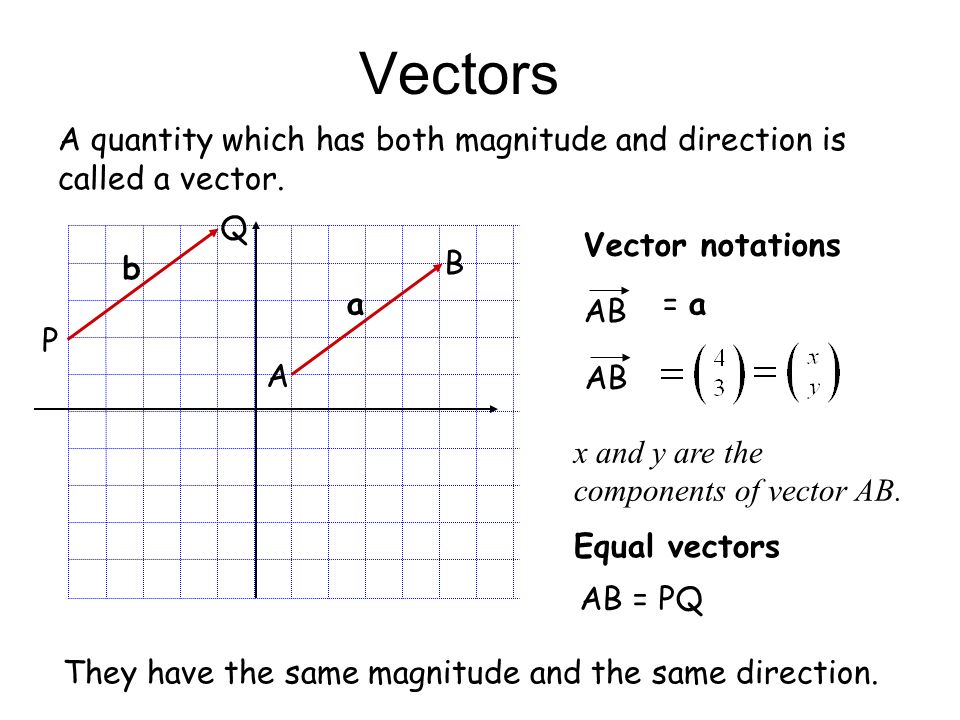
A vector is just a quantity with magnitude and direction. That's it. You see them everywhere in geometry classes, but they're also the backbone of physics simulations, computer graphics rendering, and any engineering discipline that deals with forces or motion. When you're working with them in practice, you don't need fancy language. You need to know how to add them, scale them, and project one onto another without second-guessing yourself. Geometrically, a vector is a directed line segment. It has a starting point and an ending point, but the position of those points doesn't actually define the vector. Two arrows pointing the same way with the same length are the same vector, even if they're drawn in completely different places on the page. This is probably the most misunderstood part for students. They treat vectors like fixed positions when they're really displacement relationships between two points. I've seen people waste hours debugging collision detection code because they confused position vectors with direction vectors. A position vector tells you where something is. A direction vector tells you which way something is moving. Mixing them up will break your simulation every time. In my case, I was working on a simple particle system for a mobile game, and the objects were drifting toward the wrong targets. After tracing through the math three times, I realized I was normalizing a position vector instead of computing the difference between the target and current position first. The fix was one line: subtract the current position from the target, then normalize the result.
How Vectors Actually Work in Practice
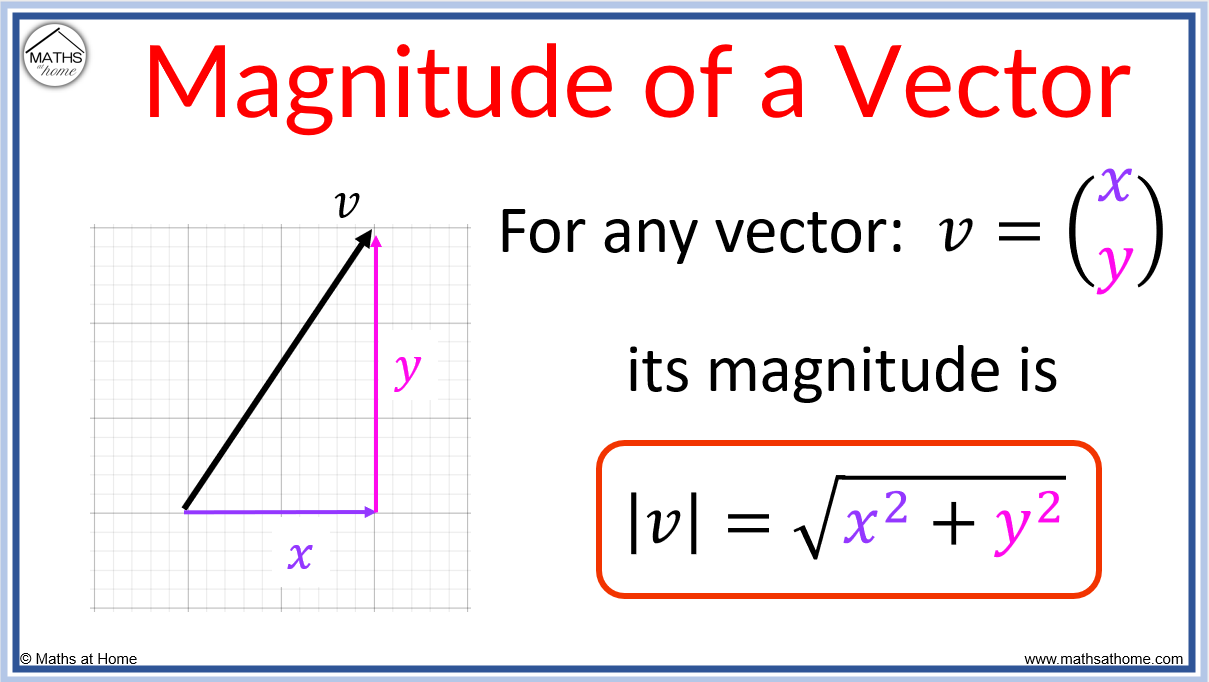
The core operations you'll use are addition, scalar multiplication, dot products, and cross products. Vector addition is straightforward. Place the tail of one vector at the head of another and draw from the first tail to the last head. Mathematically, you just add the corresponding components. If v1 is (3, 4) and v2 is (1, -2), their sum is (4, 2). Scalar multiplication means stretching or shrinking the vector. Multiply every component by the scalar. A negative scalar also flips the direction. The dot product deserves more attention because it's the most useful operation in applied work. It takes two vectors and returns a scalar value. The formula is a1*b1 + a2*b2 + a3*b3 in three dimensions. But the more important form is |a||b|cos(theta), where theta is the angle between the vectors. This tells you how aligned the vectors are. If the dot product is zero, they're perpendicular. If it's positive, the angle is less than 90 degrees. If it's negative, the angle is greater than 90 degrees. I use this constantly for checking whether a surface is facing a light source in rendering, or whether a character's facing direction is roughly toward a target in pathfinding logic. The cross product only works in three dimensions and produces a new vector perpendicular to both input vectors. Its magnitude equals |a||b|sin(theta). This is essential for calculating surface normals, torque, and angular momentum. In game development, I use cross products to determine the orientation of a triangle face so the engine can cull back-facing polygons before rendering. It's a small operation but it can save significant processing time on complex scenes.
Common Pitfalls That Nobody Warns You About
One issue that comes up constantly is the difference between row vectors and column vectors. Some libraries treat vectors as rows and multiply them on the left of matrices. Others treat them as columns and multiply on the right. Using the wrong convention flips your entire transformation pipeline. I ran into this when switching from Unity's coordinate system to a custom C++ engine. Rotations that worked perfectly in the editor produced completely wrong results in the engine because I was applying rotation matrices to row vectors instead of column vectors. The fix was switching the multiplication order and transposing the matrices, which took about an hour of testing to verify. Another thing people get wrong is assuming that normalization always preserves direction. It does preserve the direction, but it destroys magnitude information. If you normalize a zero vector, you get a division-by-zero error. I've crashed entire applications from this. Always check that a vector has non-zero length before normalizing it. In code, that's usually a simple magnitude check with a small epsilon threshold to handle floating-point imprecision. Here's a less obvious problem: vector subtraction is not commutative. b - a is not the same as a - b. They point in opposite directions. This matters enormously when you're computing directions between two points. If you want the direction from point A to point B, the calculation is B minus A, not A minus B. Swapping them sends your projectile or agent in the wrong direction entirely. I made this mistake when building a simple AI navigation system where characters were supposed to move toward waypoints. They were moving away from them instead. The swap was subtle enough that I didn't catch it during basic testing because the magnitude of movement was correct, just the direction was inverted.
Get the Full Details

When Vectors Aren't the Right Tool
Vectors work brilliantly for representing direction, force, velocity, and position in Euclidean space. But they break down in certain contexts. In projective geometry, where points at infinity and perspective transformations matter, vectors in the traditional sense don't capture the full picture. You'd need homogeneous coordinates instead. In non-Euclidean spaces like spherical geometry on a globe, straight-line vector addition doesn't work because the shortest path between two points follows a great circle, not a straight line. If you're doing navigation or geospatial calculations, using standard vector math on lat-long coordinates will give you wrong distances and incorrect directions. Quaternions are a better choice for representing 3D rotations when you're dealing with complex multi-axis rotations, because they avoid gimbal lock issues that arise with Euler angles. Vectors can represent rotation axes, but they don't encode rotation amounts elegantly on their own. When I need to implement vector operations from scratch, I start by defining a simple struct or class with x, y, and z components. Then I implement the basic arithmetic operators. After that, I add magnitude, normalization, dot product, and cross product. I test each function with known values before moving forward. For example, the dot product of two perpendicular unit vectors should always be zero. The cross product of the standard basis vectors i and j should produce k. These known cases catch implementation errors early. In Python, the numpy library handles vector operations efficiently with C-level optimizations. In C++, GLM is the standard for geometry-related calculations. Both are widely used in industry and well-tested. For quick scripting or prototyping, writing your own vector class is fine, but for production work, using an established library saves time and reduces bugs. The overhead of implementing and maintaining your own vector math library usually outweighs any perceived benefit unless you have very specific performance requirements.
Once you understand the mechanics, vectors become almost invisible. You stop thinking about them as separate entities and start using them as a native way of describing spatial relationships. That's when the geometry stops being abstract and starts being practical.