What Actually Happens When Objects Bump Into Each Other
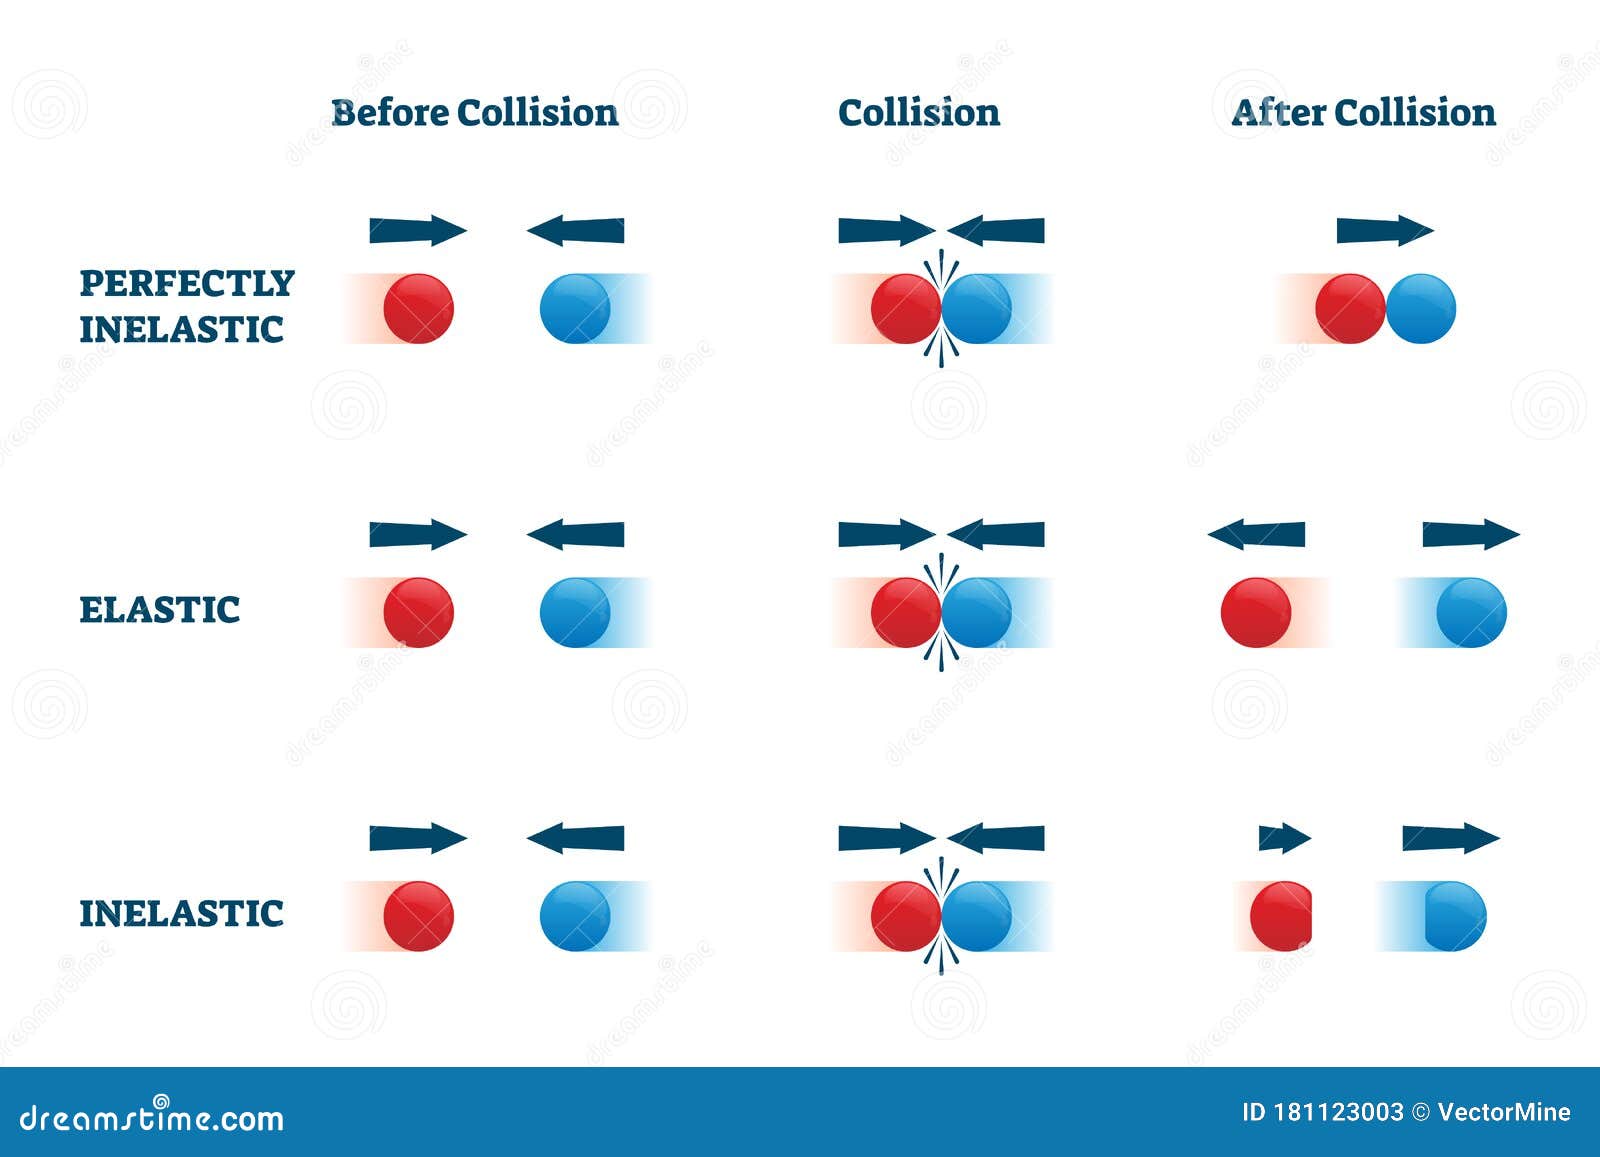
Elastic collisions are exactly what they sound like. Two objects collide, nothing gets lost in the process, and they bounce apart with the same total kinetic energy they had before impact. That is the short version. The reality is a lot messier than most intro physics classes let on. In a textbook elastic collision, both momentum and kinetic energy stay conserved. Momentum is the easier one to track. It always stays the same whether the collision is elastic or not. Kinetic energy is the real question. In a truly elastic collision, the total kinetic energy before the impact equals the total kinetic energy after. No heat generated. No permanent deformation. No sound energy leaking out into the environment. I spent a few years working with high-speed impact testing, and let me tell you, real-world collisions rarely behave like the textbook diagrams. Most collisions are somewhere between perfectly elastic and perfectly inelastic. The distinction matters when you are actually trying to predict what happens next.
What Is An Elastic Collision
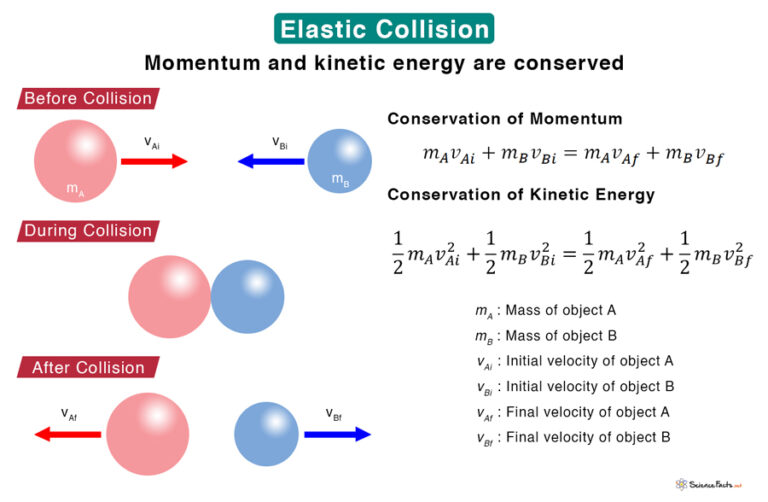
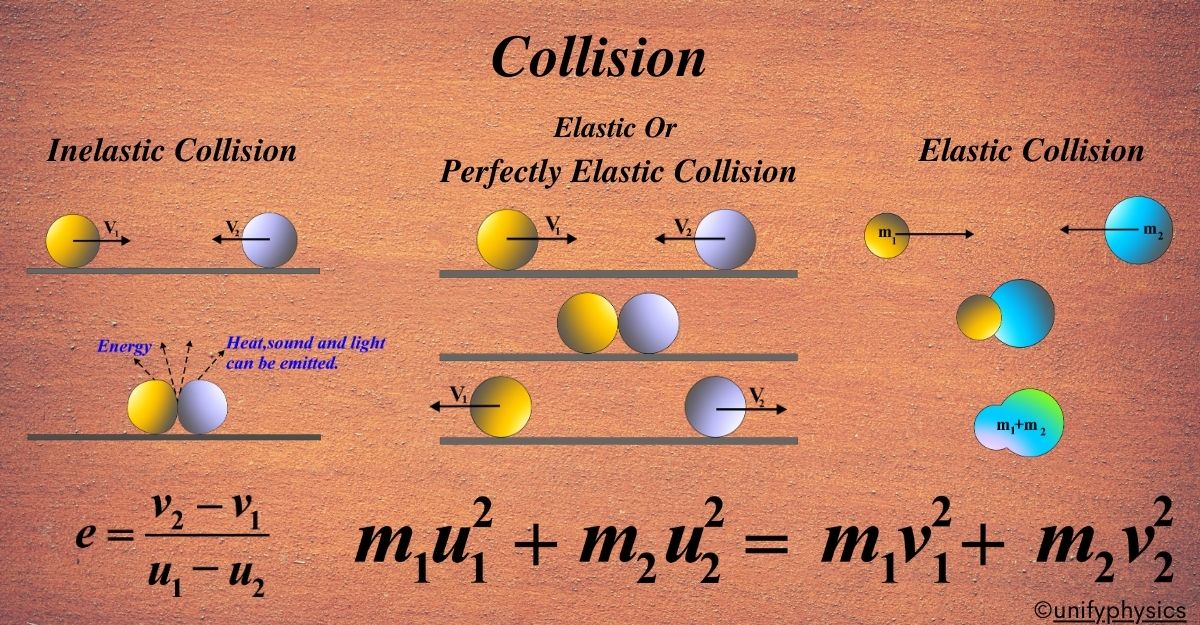
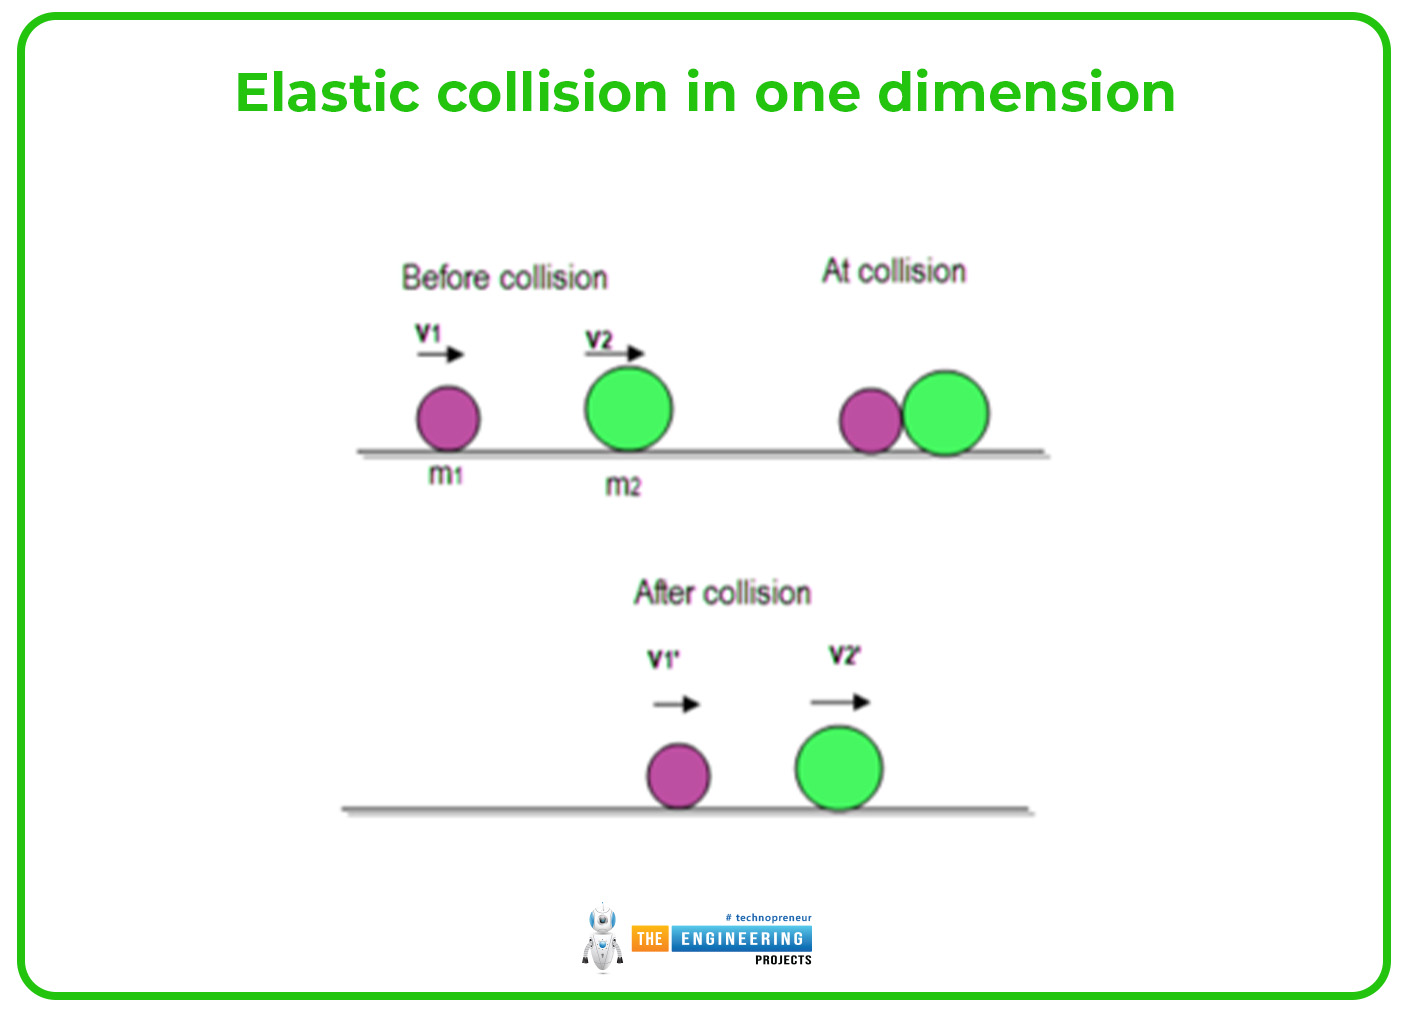
The formal definition hinges on conservation laws. When two particles collide elastically, the system's total momentum remains constant, and the total kinetic energy also remains constant. That second condition is the one that gets people in trouble because it is extremely restrictive in practice. For macroscopic objects at everyday speeds, nearly every collision loses some energy to heat, sound, or internal deformation. The equations are straightforward though. For two objects with masses m1 and m2, moving at velocities u1 and u2 before collision, and v1 and v2 after collision, you set up two equations simultaneously: m1*u1 + m2*u2 = m1*v1 + m2*v2 (momentum conservation)
½*m1*u1² + ½*m2*u2² = ½*m1*v1² + ½*m2*v2² (kinetic energy conservation) Solving those gives you the post-collision velocities. In the special case where one object starts at rest, the equations simplify to something you can memorize if you deal with this often enough. But I still look them up because the algebra gets sloppy when you are doing it under time pressure. One thing beginners consistently get wrong is assuming that equal masses mean equal velocities after collision. That only happens in head-on collisions along a single line. Once you introduce angles, everything changes. A ball hitting another ball at an offset angle will scatter at specific angles determined by the collision geometry, not just reverse direction.
Get the Full Details
Where The Theory Meets Reality
I ran into a real problem a couple years ago working on a project involving steel bearings rolling through an automated sorting system. The design team modeled the interactions as perfectly elastic collisions using standard equations. The simulation predicted the bearings would separate cleanly into designated bins. In practice, the bearings were bouncing unpredictably and jamming the mechanism. The issue was surface contamination. A thin layer of machining oil changed the effective coefficient of restitution from near-perfect elasticity down to about 0.85. That might not sound like a huge difference, but over multiple sequential collisions, the energy loss compounds rapidly. The bearings weren't just losing speed. They were changing their rebound angles in ways the elastic model couldn't account for because the model assumed zero energy dissipation. Our workaround was simple enough in hindsight. We recalibrated the simulation using a measured coefficient of restitution specific to oiled steel on steel, which was approximately 0.87 for our particular bearing alloy and surface finish. That single parameter change brought the simulation within about 4 percent of actual bearing trajectories. Still not perfect, but good enough to redesign the bin geometry and stop the jamming.
If you are doing any kind of simulation work involving collisions, measure your coefficient of restitution rather than assuming ideal values. Drop a ball from a known height onto your actual materials and measure the bounce height. The ratio of bounce height to drop height gives you e squared, where e is the coefficient of restitution. Taking the square root gives you e directly. This takes about ten minutes and saves you from discovering later that your entire model is drifting away from reality. There is also a subtlety with rigid body collisions that textbooks tend to gloss over. In real materials, no collision is truly instantaneous. Even steel on steel involves a brief compression phase where energy temporarily stores as elastic potential energy before being released. If your objects are significantly different in hardness, that energy release becomes asymmetric. A rubber ball hitting a concrete floor behaves differently than a steel ball hitting the same floor, not just because of different restitution coefficients, but because the contact time and deformation profile alter how the force distributes across the collision surface. Another thing nobody warns you about is rotational energy. When objects collide off-center, some kinetic energy transfers into spin. Standard elastic collision equations assume point masses with no rotation. Real objects have moments of inertia. If you are tracking a spinning baseball that gets hit by a bat, the spin before and after matters for the trajectory. Ignoring rotational energy in those cases will give you results that are qualitatively wrong even if the translational numbers look reasonable.
Pure Elastic Collisions Are Basically Rare
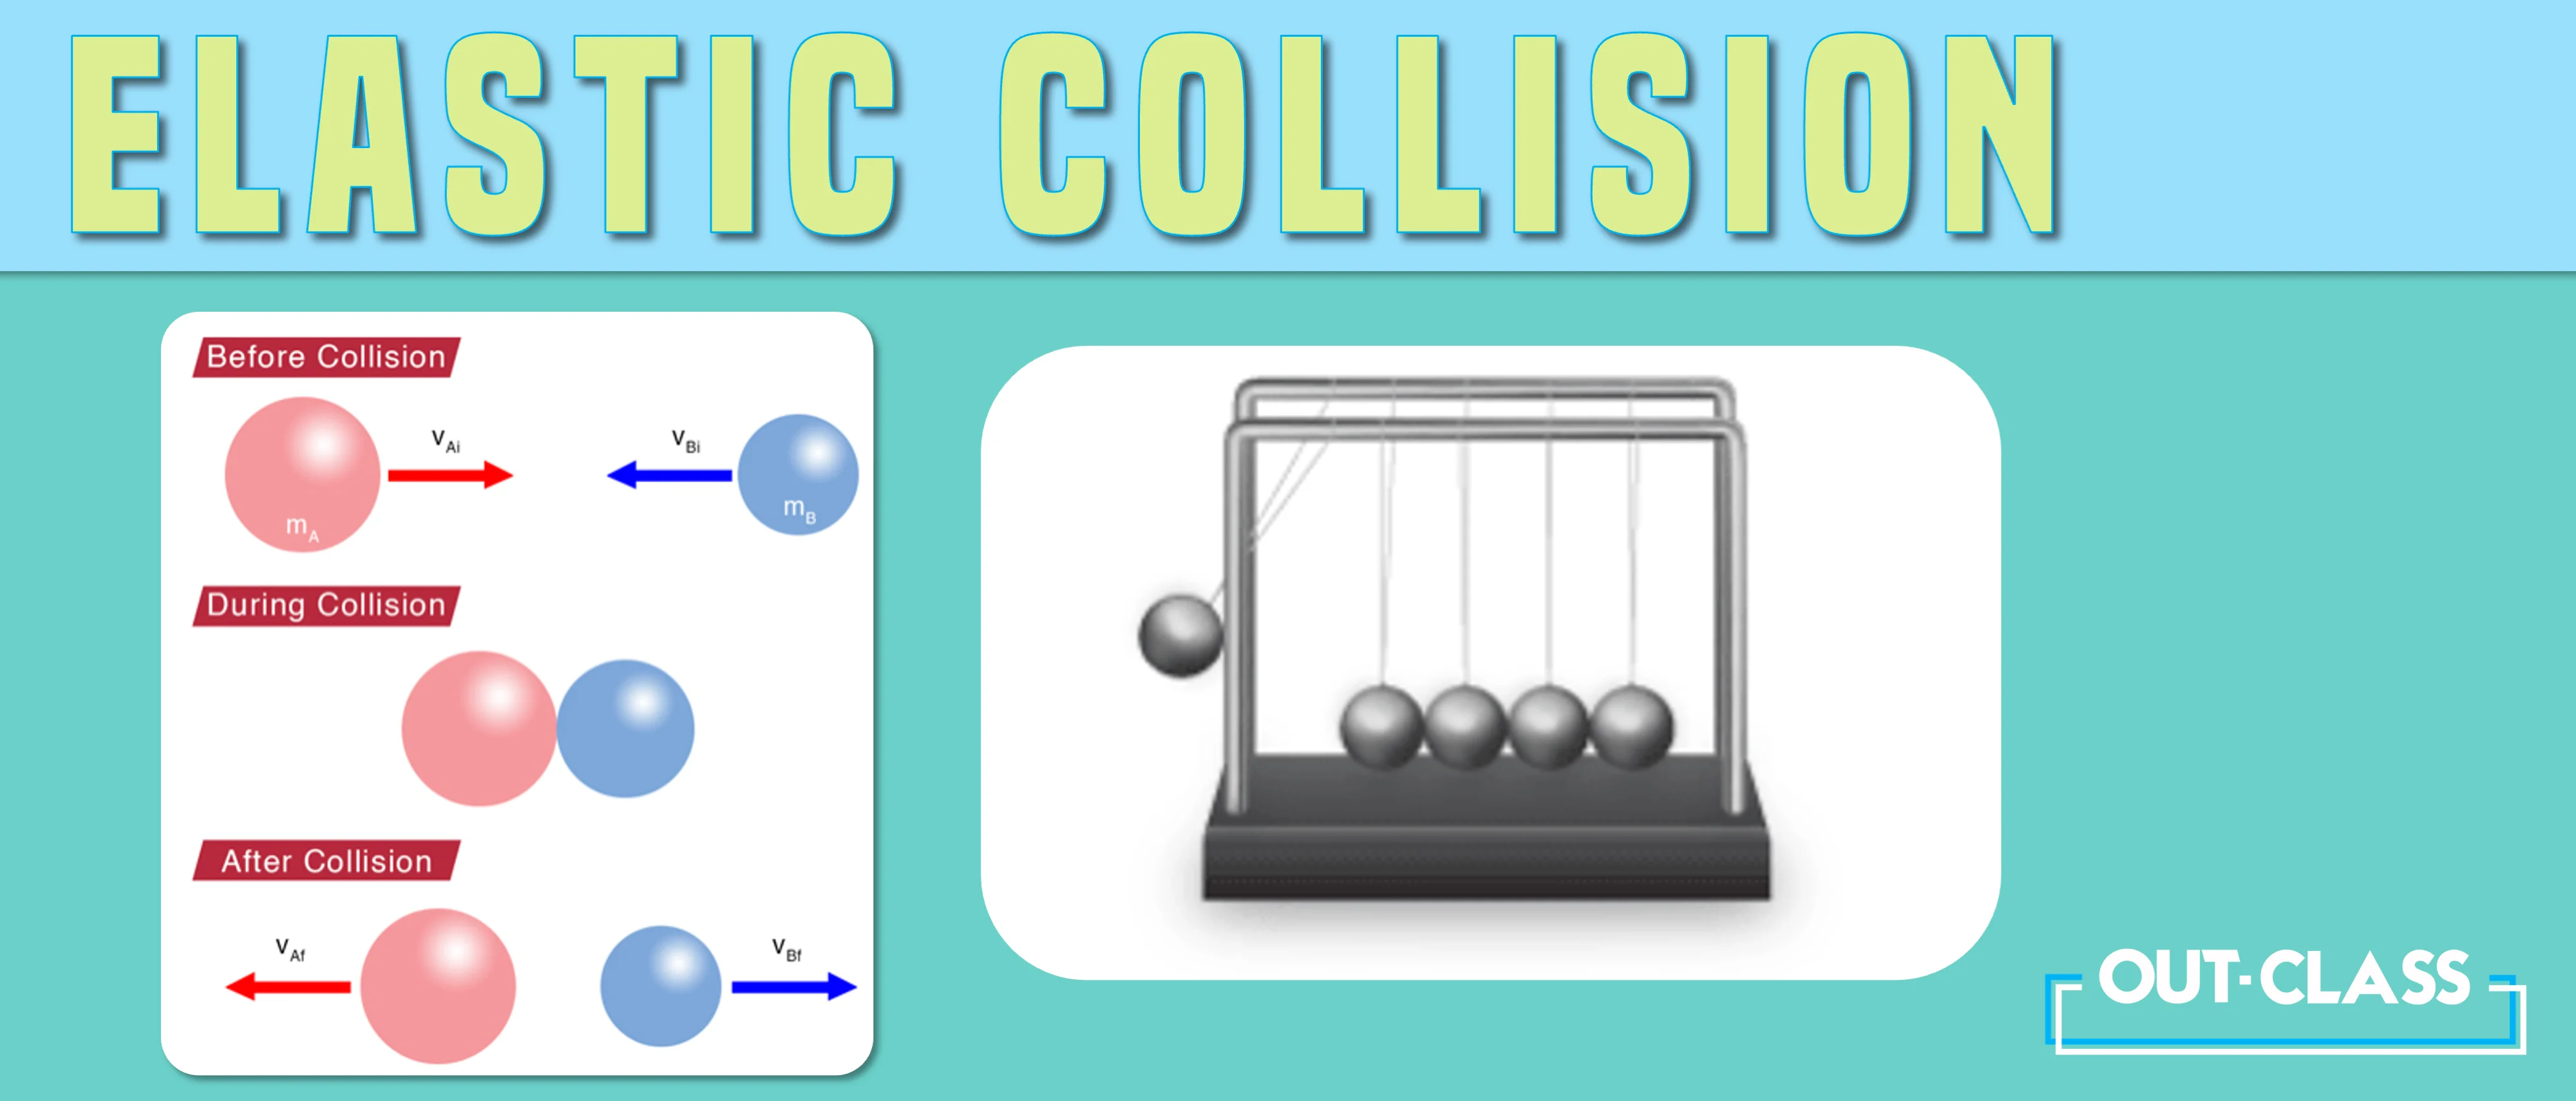
The closest things to perfectly elastic collisions in nature involve atomic and subatomic particles. Gas molecules colliding under standard conditions are a decent approximation. Superfluids exhibit nearly frictionless flow that approaches elastic behavior at macroscopic scales. Some very specific material pairs at controlled temperatures can approximate elastic collisions over short sequences, but each successive bounce degrades the approximation. Newton's cradle is the classic demonstration everyone has seen. Five steel balls hanging in a row. Lift one, let it go, and one ball pops out the other side. Looks perfectly elastic. But watch closely and you will see the effect degrade with each cycle. The sound you hear is energy leaving the system. The tiny deformation in the steel at each impact converts a fraction of kinetic energy into heat. After about twenty cycles, the motion is clearly damping out. If you need to model collisions for engineering purposes, the elastic collision framework is still useful as a first approximation. But you should treat it as a baseline, not a final answer. Introduce a coefficient of restitution less than one. Account for rotational degrees of freedom if the objects are large enough or spinning fast enough. Validate your assumptions against physical measurements whenever possible.

The math works cleanly only under ideal conditions. The real world does not care about ideal conditions. I have seen perfectly sound calculations produce garbage results simply because someone forgot to check whether the objects they were simulating actually obeyed the elastic collision assumption in the first place. It sounds obvious when I say it, but it comes up more often than I would like to admit.