What Mechanical Energy Actually Is, in Practice
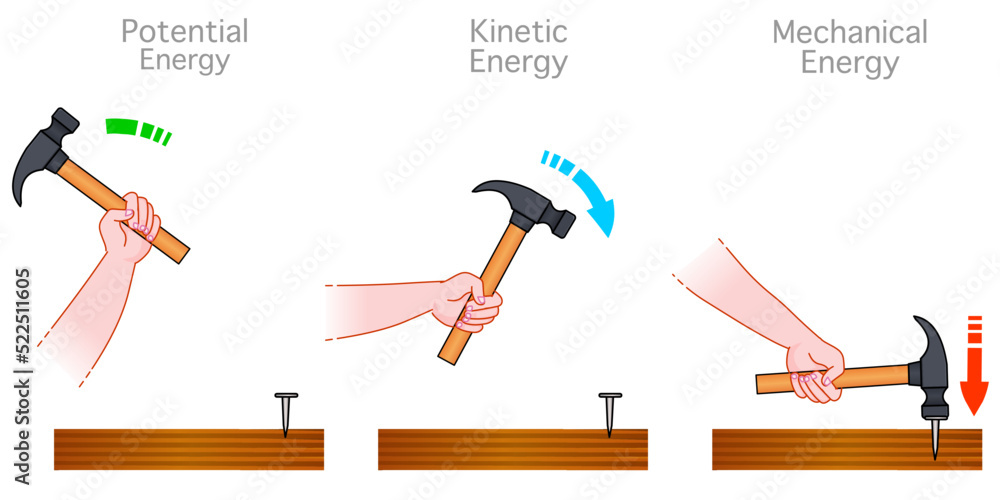
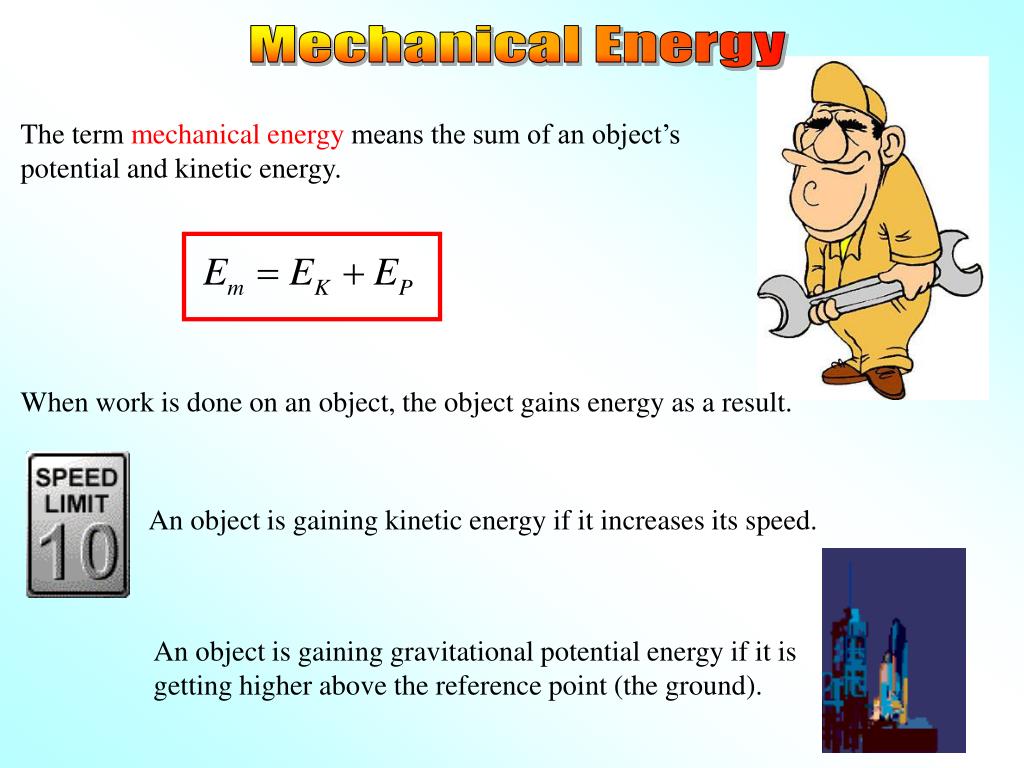
Most textbooks define it as the sum of kinetic and potential energy in a system. That is correct. It is also nearly useless for anyone trying to design a real machine or troubleshoot why a mechanism is losing performance. The gap between the textbook definition and the shop floor is where this topic usually falls apart. Mechanical energy is the energy stored or carried by a physical system due to motion and position. Kinetic energy comes from mass and velocity. Potential energy comes from position in a force field, most commonly gravity or a spring. The total is simply the two added together. That is it.
What Is Mechanical Energy for? It Is a Bookkeeping Tool
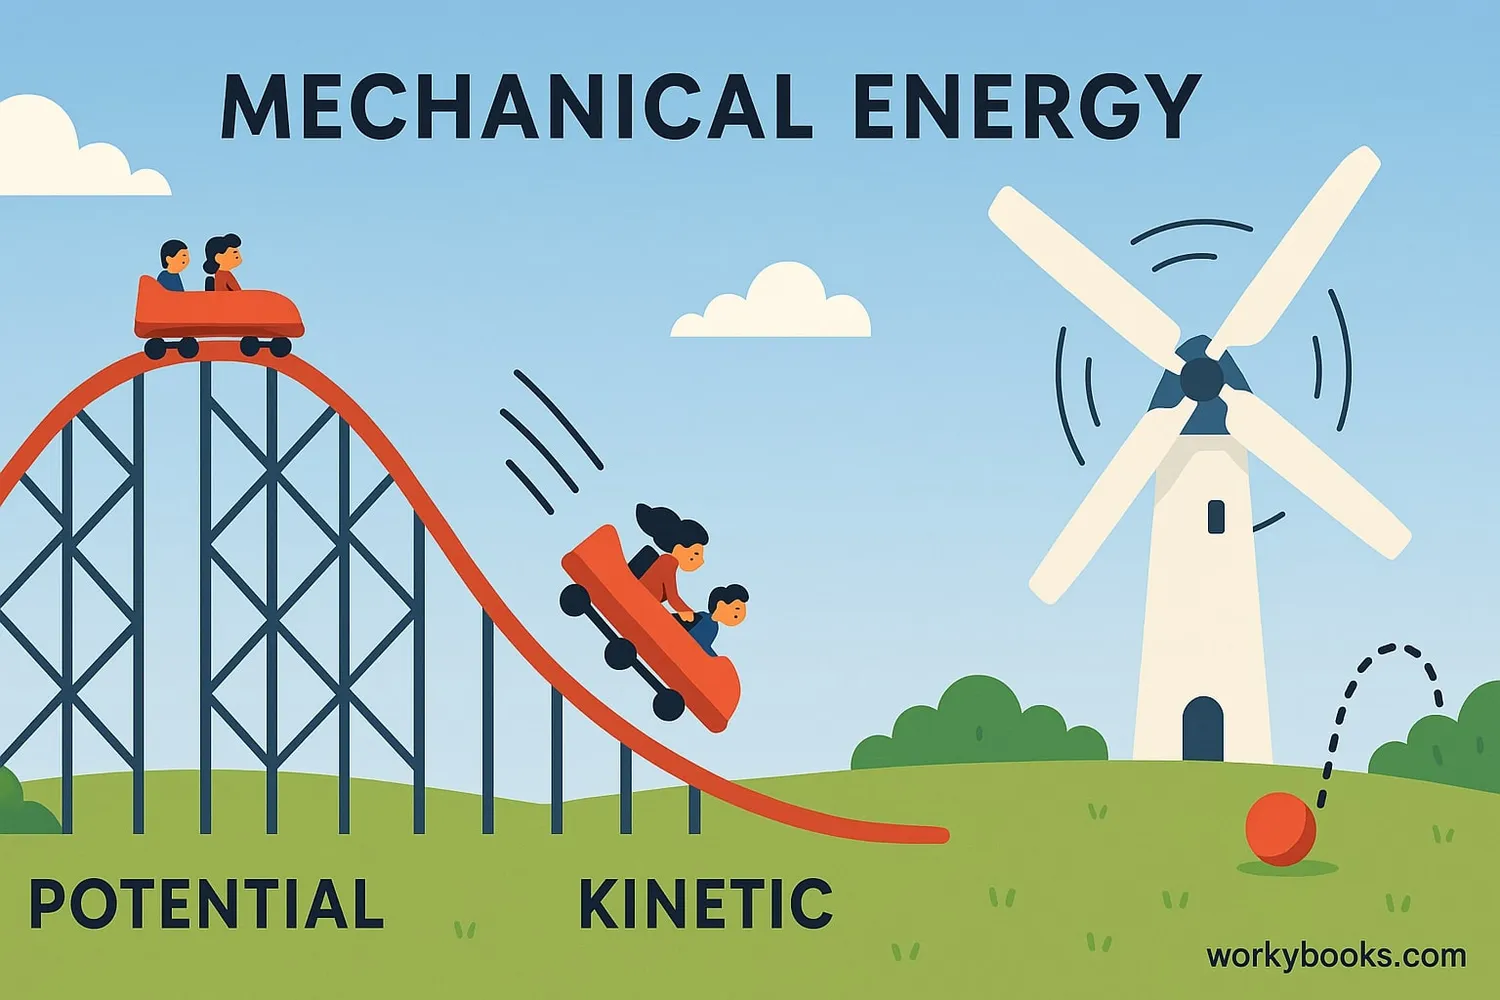
Think of mechanical energy as a way to track whether a system is gaining or losing useful capacity to do work. In an ideal system with no friction, no air resistance, and no material hysteresis, the total mechanical energy stays constant. You move from one point to another, potential trades into kinetic, kinetic trades into potential, and the sum does not change. Engineers rely on that constancy to size components and predict behavior without running a full simulation. Real systems are never ideal. The reason mechanical energy matters in practice is not because it stays conserved. It matters because measuring how much it changes tells you where the losses are hiding.
The Two Pieces You Need to Track
Kinetic energy is straightforward. It is one-half mass times velocity squared. A heavier object at the same speed carries more of it. Double the speed and you quadruple the amount. That quadratic relationship is why impact damage scales so fast, and it is also why people routinely underestimate energy in rotating parts. Rotational kinetic energy uses moment of inertia instead of simple mass. If you treat a spinning flywheel like a sliding block of the same weight, your calculation will be wrong. Potential energy has two common forms here. Gravitational potential depends on mass, gravity, and height. Elastic potential depends on spring stiffness and displacement squared. Again, the squared term shows up. Compress a spring twice as far and you store four times the energy, not twice. That detail gets missed during preliminary design all the time.
Get the Full Details

Where People Mess It Up First
The biggest error I see is treating mechanical energy conservation as a law of nature rather than a model that only works under specific conditions. It is a model. Friction removes mechanical energy and turns it into heat. Air drag does the same. Material damping in a vibrating beam does the same. Once you introduce any of those, the mechanical energy of the system drops. The energy is not gone from the universe. It is just no longer mechanical. I once sized a gravity-fed roller conveyor assuming energy conservation across a series of lifts and drops. The math looked clean. The actual system stalled under load because I ignored bearing friction and the fact that the rollers accelerated differently than the cartons on top of them. Slippage between the package and the roller surface meant kinetic energy was being dumped into heat instead of keeping the line moving. The fix was not a better formula. It was adding a friction margin based on measured coefficients for the actual materials, then running the energy balance with that loss term included. After that, the design held up.
Using Mechanical Energy to Find Lost Energy
In practice, the most useful step is often calculating the delta. Measure or compute the initial mechanical energy. Measure or compute the final mechanical energy. The difference is the loss. From there, you can trace where that loss came from by looking at the dominant dissipation paths in your setup. If you have a pendulum, measure the peak height on successive swings. The drop in potential energy from peak to peak tells you the energy lost per cycle to air resistance and pivot friction. If you have a spring-mass system, measure the decay of oscillation amplitude over time. The loss per cycle shows material damping. This approach is usually faster and more honest than trying to calculate every small loss term from scratch.
A Worked Setup
Consider a 2 kilogram mass dropped from rest at a height of 1.5 meters onto a spring with a stiffness of 800 newtons per meter. At the top, kinetic energy is zero. Gravitational potential energy is mass times gravity times height, which is about 29.4 joules. When the spring is fully compressed, velocity is zero again, so kinetic energy is zero. Gravitational potential has decreased based on the extra distance fallen while compressing the spring, and elastic potential has increased by one-half stiffness times compression distance squared. If you assume no losses, you set the initial energy equal to the final elastic plus gravitational terms and solve for compression. That gives a clean answer, and it is close enough for preliminary sizing of shock absorbers and bumpers. Then you run the real hardware. You measure the actual compression and find it is less than the ideal prediction, or sometimes more, depending on whether the surface was lubricated or rough. If the mass bounces back lower than expected, you have damping losses. If it settles higher, you likely had extra friction holding it. Either way, the measurement teaches you more than the calculation did.

Rotating Systems Complicate the Picture
Rotational kinetic energy uses moment of inertia, which depends on mass distribution. A solid disk and a ring with the same mass and radius do not store the same energy at the same angular speed. The ring stores more because its mass sits farther from the center. If you replace a solid shaft with a hollow one of the same outer diameter and similar weight, you change the energy picture even if the static load capacity looks similar. That detail matters for flywheels, clutch design, and any system where rapid acceleration is involved. I ran into a case where a motor-driven reel kept tripping on startup. The energy balance on the linear side looked fine. The problem was rotational. The reel had a large moment of inertia because the cable wound on it built up a thick outer layer over time. As the spool filled, the effective radius grew, and the kinetic energy required to spin it up jumped well beyond the initial estimate. The workaround was to model the reel as a varying radius and recalculate the torque demand across the full fill range, then select a motor with enough peak torque for the worst case instead of the empty-spool case.
Common Pitfalls to Avoid
Do not confuse force with energy. A large static force does not mean a system has high mechanical energy if nothing is moving and nothing is displaced from equilibrium. Do not double-count gravitational potential when the reference height changes mid-system. Pick one datum and stick to it. Do not ignore elastic energy stored in flexible links and belts. A tensioned belt under load stores energy, and that energy participates in dynamics even though it is not obvious. Another mistake is applying conservation across a collision without checking whether the collision is elastic. Most real collisions are inelastic. Mechanical energy is lost to deformation and heat. Momentum is conserved in both cases. If you use energy conservation for an inelastic collision, your result will be wrong. Use momentum for the impulse, and reserve energy methods for elastic or near-elastic interactions.
When Mechanical Energy Approaches Break Down
The concept fails as a practical tool when deformations are large and path-dependent, when materials exhibit significant viscoelastic behavior, or when thermal effects dominate the response. In those cases, a full thermodynamic or finite element analysis is faster than trying to patch an energy balance with empirical loss factors. Mechanical energy is still a valid physical quantity. It is just not the most efficient way to predict what happens. I used it once for a quick check on a polymer damper design. The displacement was large, the strain rate mattered, and the temperature rose noticeably during cycling. The energy method gave a number, but the number did not match the test data within a useful margin. Switching to a hysteresis-based model with rate-dependent parameters closed the gap. The mechanical energy approach still helped me frame the problem and explain the loss mechanism to the team. It just was not the right calculation for the final design.
How to Use It Without Getting Confused
Write the energy balance explicitly. List kinetic, gravitational potential, elastic potential, and any external work inputs or outputs. Define your reference height. Define your sign convention for work and heat. Keep it all in one place. Then solve for the unknown. If you cannot identify the loss term, measure it. A simple force sensor, a displacement probe, and a tachometer are enough to get real numbers. Those numbers will correct your model faster than any textbook example. Start with the ideal calculation. Run the real test. Compare. If the measured final energy is lower, you have dissipation. Quantify it. Trace it to bearings, seals, air, or material damping. If the measured energy is higher, you likely added external work through a spring preload, a cam lift, or an actuator you did not account for. Adjust the model and repeat. Two or three cycles usually pin down the dominant terms. After that, you can rely on the energy balance for sizing and comparison without running detailed simulations for every variant. That routine is why mechanical energy remains useful despite being an introductory topic. It forces you to account for every form of motion and position energy in the system. It exposes missing components before they become field failures. And it gives you a clear number to compare across design alternatives.
What to Remember
Mechanical energy is kinetic plus potential. It is conserved only in idealized systems. Real systems lose it to friction, drag, damping, and inelastic deformation. The value is in the delta. Use it to size, to diagnose, and to compare. Use measurements to correct the model. And do not apply conservation rules to collisions or deformations where they do not belong.