Why This Law Keeps Tripping People Up
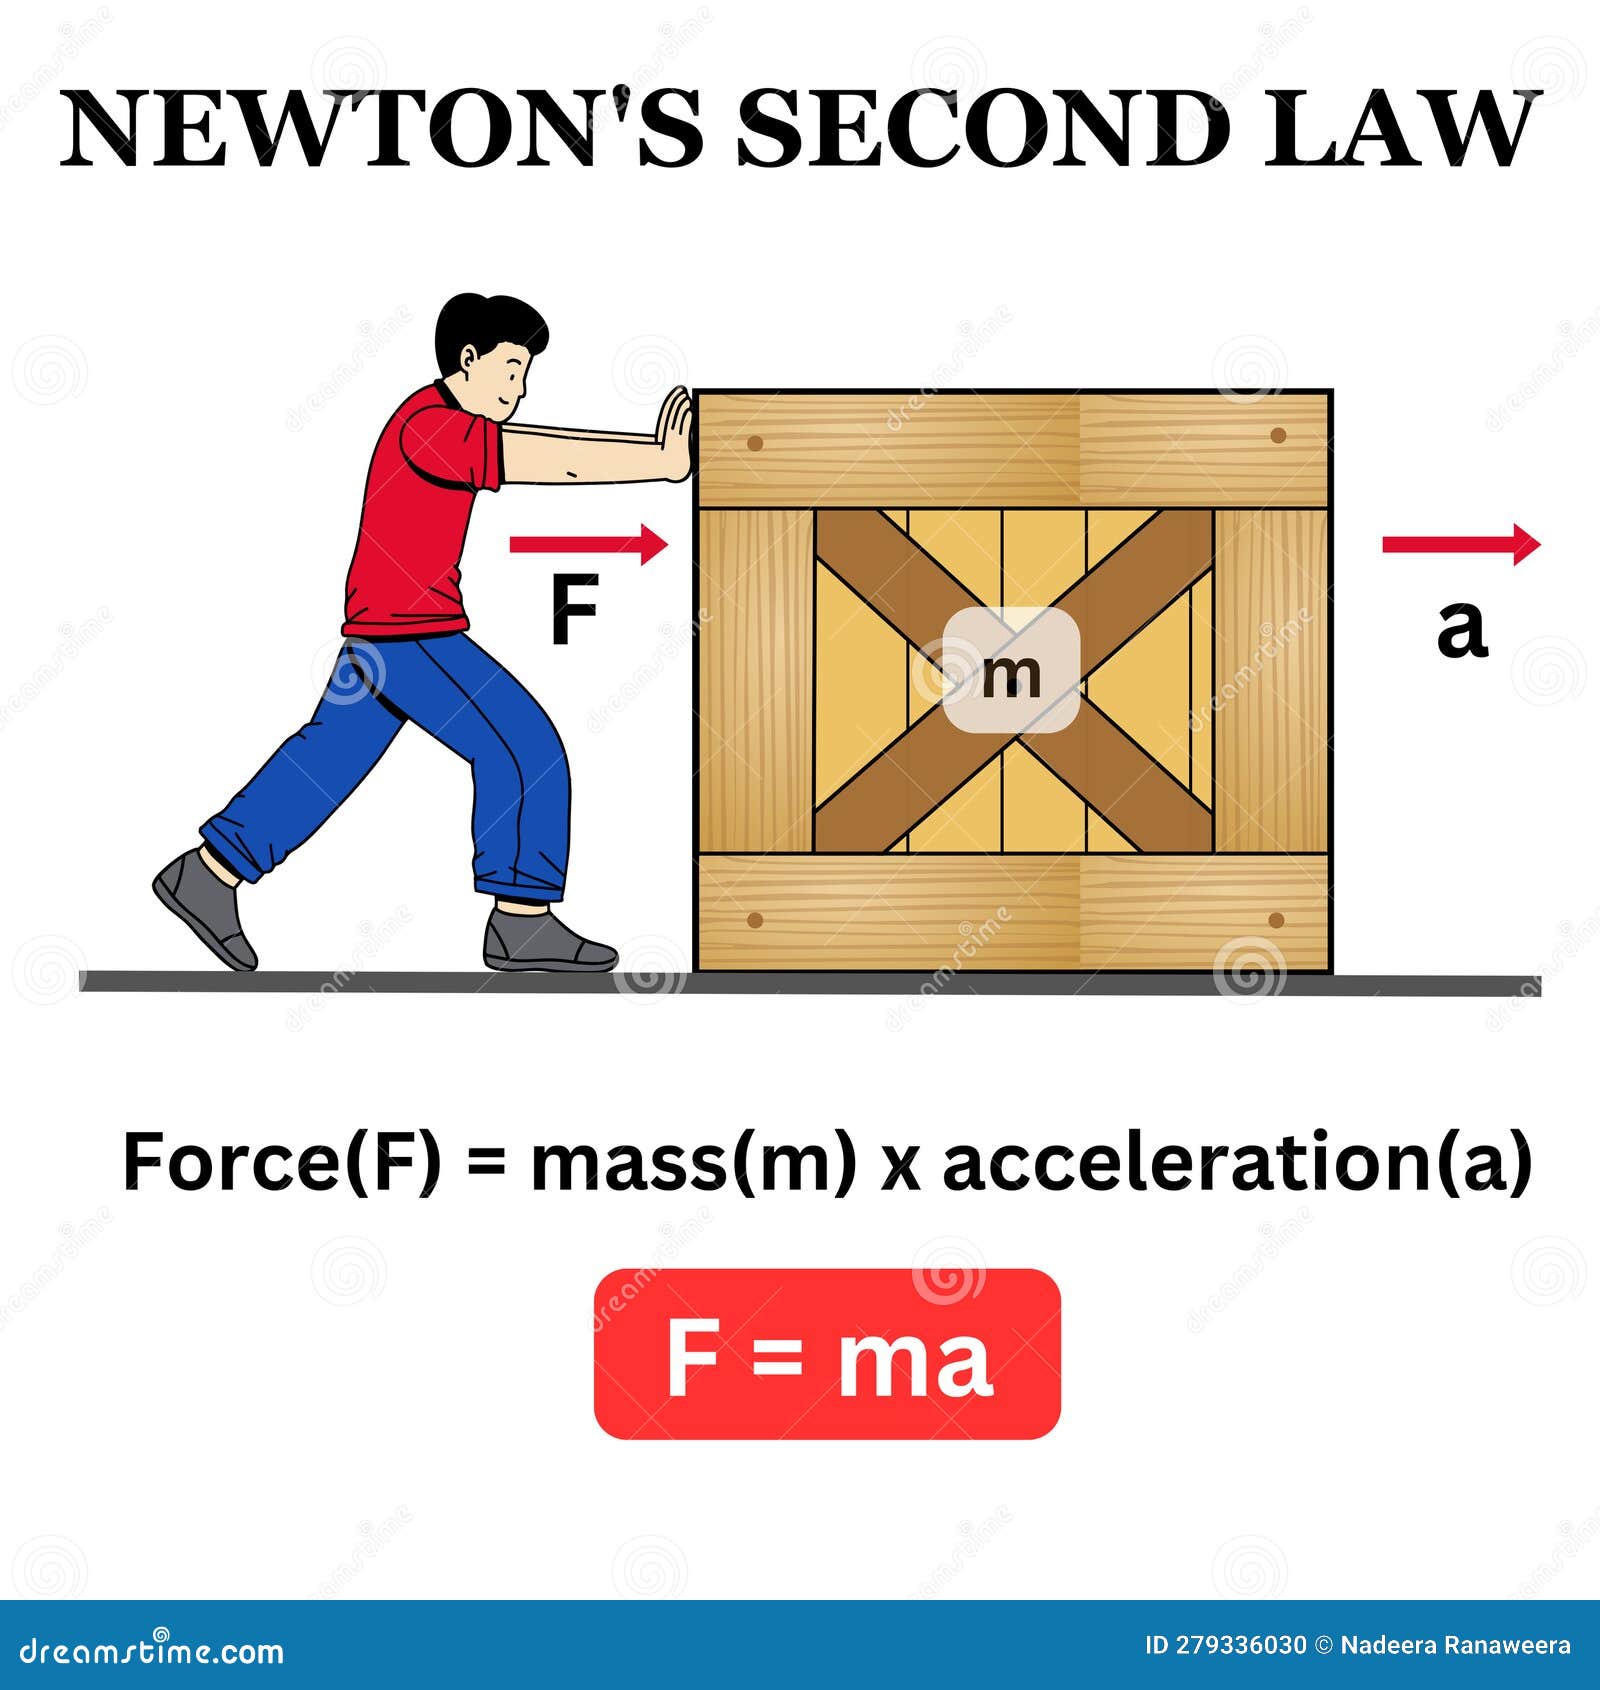
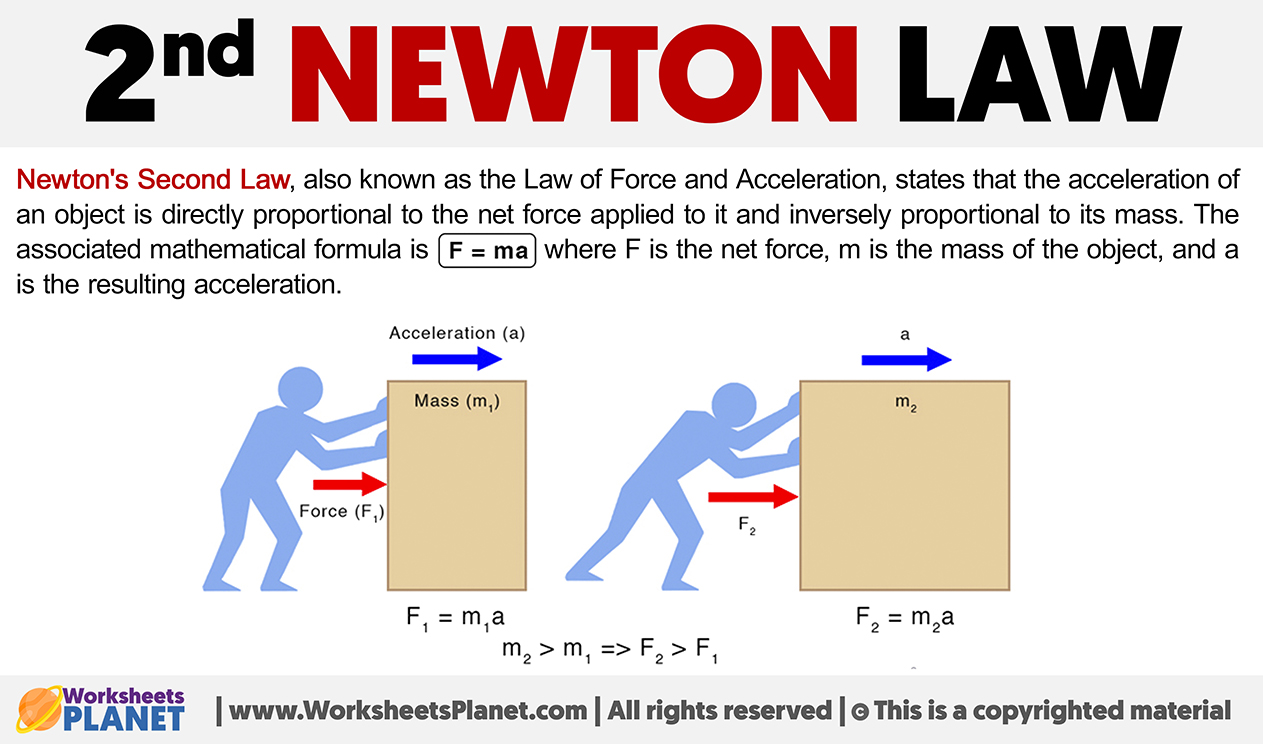
I spent about three years troubleshooting simulation drift in robotics software before I realized most of it came down to how engineers applied Newton's Second Law in dynamic systems. They knew the formula. They didn't know what it was actually doing under real conditions. Force equals mass times acceleration. That's F = ma. It sounds trivial until you're trying to calculate the thrust needed for a multi-stage vehicle or the braking force on a system with moving parts that shift mass around. The equation itself doesn't change, but what you're solving for in practice gets messy fast. The way it actually works is this: every force acting on an object contributes to a net force, and that net force divided by the object's mass gives you its acceleration. Direction matters. If you're working in two dimensions or three, you break it into components. A 500 newton force at a 30 degree angle isn't just 500 newtons of forward push. It's roughly 433 newtons forward and 250 newtons upward, or whatever your coordinate system happens to be.
I learned this the hard way debugging a conveyor belt system at a packaging facility. The client complained the motors were stalling intermittently. We had calculated the force requirements using static mass assumptions. The problem was the product on the belt wasn't uniform. Boxes of different weights moved at different speeds, creating variable friction and inertial loads that our simple F = ma calculation completely missed. We ended up adding accelerometers to the motor shafts and feeding real-time acceleration data into the control loop. The static calculations were off by about 18 percent under worst case loading conditions. That margin killed the drives during peak throughput.
How to Actually Use It Without Messing Up
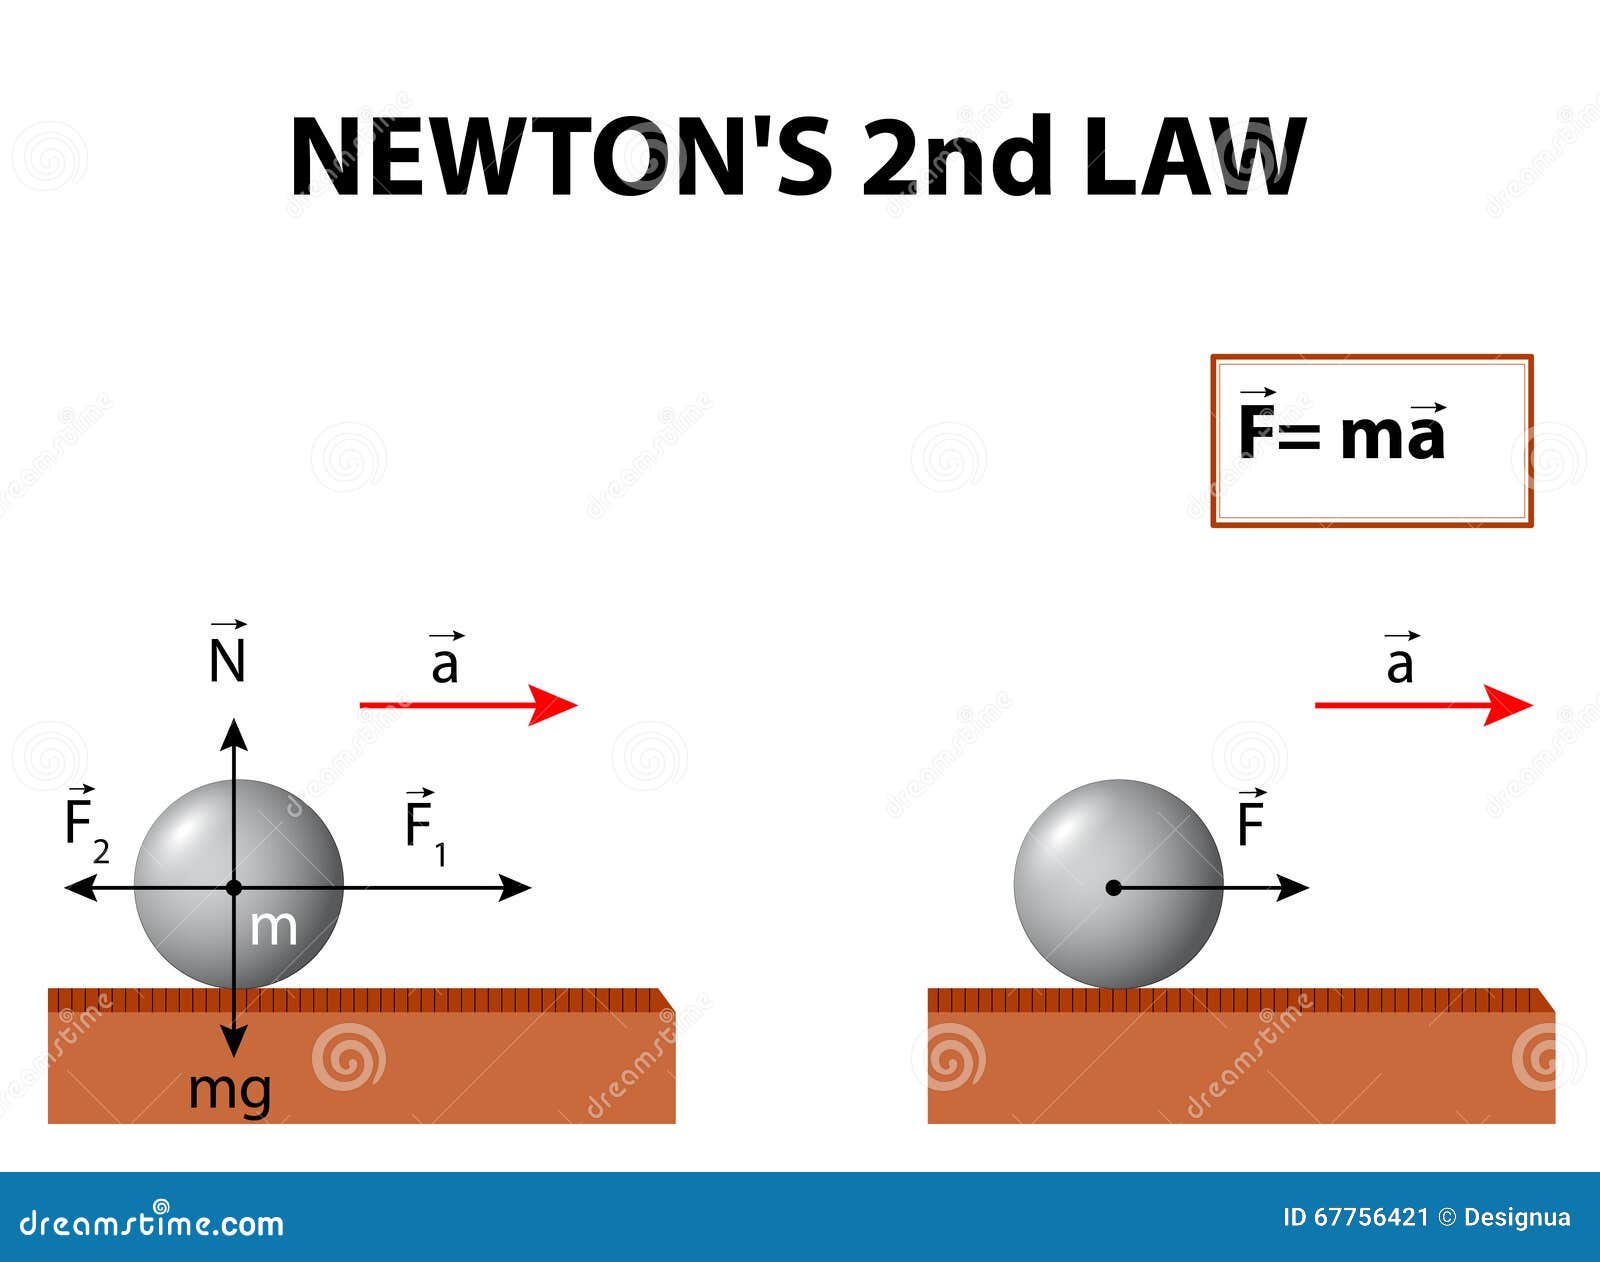
Start by drawing a free body diagram. I know that sounds like textbook filler, but skipping it is where most mistakes happen. Every force going into or out of the system needs to be mapped before you write any equations. Gravity, friction, normal force, tension, applied loads. Get them all on paper or screen first. Then sum the forces. Not pick one and go. Sum them. The net force in each direction determines the acceleration in that direction independently. This is where people slip up when things get complex. They start combining forces that belong in separate axes or forgetting that friction changes direction based on motion rather than just opposing it blindly. When mass changes during the interaction, which happens more often than most people realize, you can't just plug a single number into F = ma. Rocket propulsion is the classic example, but even something like a snowplow pushing accumulating snow or a rocket sled burning through fuel has variable mass. In those cases the equation becomes F = dp/dt, where p is momentum. The derivative approach accounts for both changing velocity and changing mass. You can approximate it with small time steps if you're doing numerical simulation, but you need to be careful with the step size. Too coarse and your results drift. Too fine and you're wasting compute for no real gain.
Get the Full Details

I've seen engineers use the simplified version on variable mass systems and wonder why their simulations diverge after a few seconds. It's not a bug in their code. It's the physics model being wrong.
Edge Cases Where the Standard Approach Breaks Down
Newton's Second Law assumes inertial reference frames. If you're working from an accelerating platform without accounting for that, your numbers are garbage. I worked on a project involving a mobile testing rig mounted on a vehicle that was constantly maneuvering. We initially treated the vehicle as stationary and just added vibration isolation. The acceleration data from the onboard sensors was contaminated by the vehicle's own motion. We had to decouple the vehicle's frame acceleration from the test object's acceleration by subtracting the platform's measured acceleration from every data point. This took maybe an hour to implement once we figured out the approach, but it made the difference between usable and completely invalid test results. Another thing nobody warns you about early enough: at very high velocities approaching significant fractions of the speed of light, the classical formulation breaks down. You need relativistic mechanics. For most engineering work this won't matter. If you're building bridges or designing car suspensions or running factory automation, you're fine. But if you're working on particle accelerator components or satellite trajectory modeling where precision matters at extreme scales, the classical equation gives you answers that are technically wrong, even if the error is small. At 10 percent of light speed the classical and relativistic predictions start diverging measurably. At higher fractions the gap widens quickly. Dissipative forces like air resistance also complicate things because they depend on velocity in a non-linear way. Drag is proportional to velocity squared at higher speeds. That turns F = ma into a differential equation you usually can't solve analytically. You need numerical methods. Euler integration works for quick approximations but accumulates error over time. A fourth order Runge Kutta method is more accurate but computationally heavier. For real-time control systems you often have to compromise between accuracy and processing speed. I typically use a semi-implicit symplectic integrator for mechanical simulations. It preserves energy better over long runs than Euler and runs fast enough for interactive applications.
Practical Tips That Actually Help
When you're hand calculating systems, keep your units consistent. I've seen people mix kilograms and pounds force without converting and wonder why the result was off by a factor of 4.448. Write out your units at every step. It catches these problems immediately. For simulation work, validate your model against a known analytical solution before trusting it with real data. Test it on a simple inclined plane with friction first. If your simulation doesn't reproduce the textbook answer for that basic case, it won't work for anything harder. This validation step usually takes less than 20 minutes and has saved me from chasing ghosts in complex models multiple times. If you're dealing with connected systems like pulleys or linked particles, remember that the tension in a massless rope is the same throughout. Real ropes have mass and stiffness, but in most textbook and preliminary design scenarios treating the rope as massless is acceptable. Just be aware when you're making that approximation so you know where the simplification sits.
Measurement error propagates through your calculations. If your force sensor has a 2 percent tolerance and your mass measurement is off by 1 percent, your acceleration result carries roughly 2.2 percent uncertainty combined. Know your error bars. They matter more than the precise value when you're making design decisions. I recently went back to first principles with a client who was getting inconsistent results from their finite element analysis. Their model was correctly set up for static loads but they were applying dynamic forces without accounting for inertial effects in the material response. The solver was treating everything as if it were quasi-static. Adding explicit dynamics to the simulation and reducing the time step to capture the acceleration transients brought the results in line with physical testing. The fix wasn't complicated, but diagnosing it required recognizing that the loading rate was too fast for a static assumption to hold. That kind of judgment comes from seeing the same failure mode repeat across different projects.