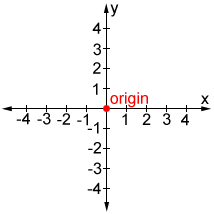
Origin in Math
Most people learn the origin as the point where axes cross, but they rarely stop to think about what that actually means when you start using it in practice. If you've ever plotted data in OriginLab software or worked through coordinate geometry problems, you already know the origin appears everywhere without much fanfare. The origin is simply the reference point from which all coordinates are measured. In a standard Cartesian plane, it sits at the intersection of the x-axis and y-axis, labeled as the point (0, 0). Move three units right and two units up, and your point becomes (3, 2). The distance from the origin is found using the Pythagorean theorem, which gives you the Euclidean distance. There is no deeper secret here. The coordinate system was built around this single point, and everything else derives from it. But there is a practical wrinkle that trips people up.
In 3D space, the origin expands to (0, 0, 0). A third axis introduces depth, and suddenly you have to think about things like right-hand rule orientation, cross products, and whether your coordinate system is left-handed or right-handed. I spent an afternoon once debugging a shader that rendered everything backwards along the Z-axis. The origin itself was correct, but the handedness of the coordinate system was flipped, which made vectors point the wrong way everywhere. Took me two hours to realize I had mixed up my handedness convention. After that, I always check the handedness first when something looks geometrically off.
How the Origin Actually Functions in Computation
When you are using mathematical software to work with the origin, there are a few things worth knowing that are not in any introductory textbook. The software does not treat the origin as a sacred constant. It treats it as whatever point your axes intersect at, which may or may not be (0, 0) depending on how your data is centered and scaled. If you are working in a domain like signal processing or computer vision, you will often encounter the origin being shifted so that the low-frequency or zero-phase components sit in the center of a frequency domain representation. The 2D Fourier transform places the origin at the corners by default, which is unintuitive unless you know to use a zero-phase shift function to move it to the middle. I wrote a quick wrapper around the transform routine that automatically applies this shift, and it saved me from manually reindexing arrays every time I needed to inspect a frequency spectrum. In linear algebra, the origin is the zero vector, and every linear transformation must map the origin to itself. This is a hard constraint. If you are applying a transformation and the origin moves, your matrix is not linear, or you have introduced an affine translation that you did not account for. I ran into this when someone sent me a transformation matrix for a robotics arm that included a translation component without separating it out, and the kinematics chain broke in unexpected ways.
Get the Full Details
Common Pitfalls and Workarounds
One of the most frequent mistakes I see is assuming the origin is always at (0, 0) in a plot. Most graphing libraries default to auto-scaling the axes to fit the data range. If your data runs from 950 to 1050, the origin will not appear anywhere near the visible area unless you explicitly set the axis limits. This is not a bug. It is a design choice that saves screen space, but it catches people off guard. Another issue comes up in numerical computing. Floating-point arithmetic means that values you expect to be exactly zero can end up as very small non-zero numbers. If your code checks for the origin by comparing a point directly to (0, 0), you will miss these cases. I started using a tolerance-based check instead. Anything within a small epsilon of the origin is treated as the origin. This has prevented a number of silent failures in my scripts. In projective geometry, the origin behaves differently depending on how you represent points. Homogeneous coordinates add an extra dimension, and the origin is represented as (0, 0, 1) in 2D projective space. If you are working with perspective transformations or camera projections, confusing the Euclidean origin with the projective origin will give you results that are numerically correct but semantically wrong. I learned this when porting a graphics engine from OpenGL to DirectX. Both APIs use the origin, but their clip space conventions differ, and the same equations produced visibly different output until I adjusted the origin interpretation for each pipeline.
Why the Origin Matters in Practice
The origin is not just a theoretical construct. It is the anchor point for everything from simple graphing to complex numerical simulations. When you set up a regression model, the intercept term is essentially the predicted value at the origin. When you rotate a shape, the origin determines the center of rotation. When you mesh a surface for finite element analysis, the origin position affects how the mesh is generated and whether boundary conditions are applied correctly. I once worked on a project where the finite element mesh was generated relative to an origin that was arbitrarily placed far from the actual geometry. This caused numerical instability in the solver because the coordinate values became very large, which amplified rounding errors. Moving the origin to the centroid of the geometry reduced the condition number of the stiffness matrix and cut the solve time in half. It was a simple change, but it made a dramatic difference.
Related Concepts Worth Knowing
If you are comfortable with the basic origin, there are a few adjacent ideas that will make your work easier. Translation operators shift the origin without changing the underlying geometry. Polar and spherical coordinate systems redefine the origin's role, using distance and angles instead of Cartesian components. The Jacobian matrix at the origin is often the identity for well-behaved transformations, which simplifies a lot of analysis. In graph theory and network analysis, the origin can be thought of as the root node from which traversal begins. This is a looser analogy, but it is useful when you are mapping between different mathematical domains. For people who use OriginLab's software product line for data analysis and graphing, the origin point is configurable in the axis properties. You can set the origin position, adjust the scale, and control how grid lines intersect. It is not the same thing as the mathematical origin, but it is a practical implementation of the concept that many users rely on daily.

A Note on Limitations
The origin is not a universal solution for every problem. In non-Euclidean geometries, the concept breaks down or requires significant reinterpretation. On curved surfaces, the idea of a single origin point does not apply in the same way. If you are working in differential geometry or general relativity, you will need to think in terms of manifolds and local coordinate charts rather than a global origin. The origin is a tool, not a principle, and it has clear boundaries where it stops being useful.