Acceleration Basics Nobody Warns You About
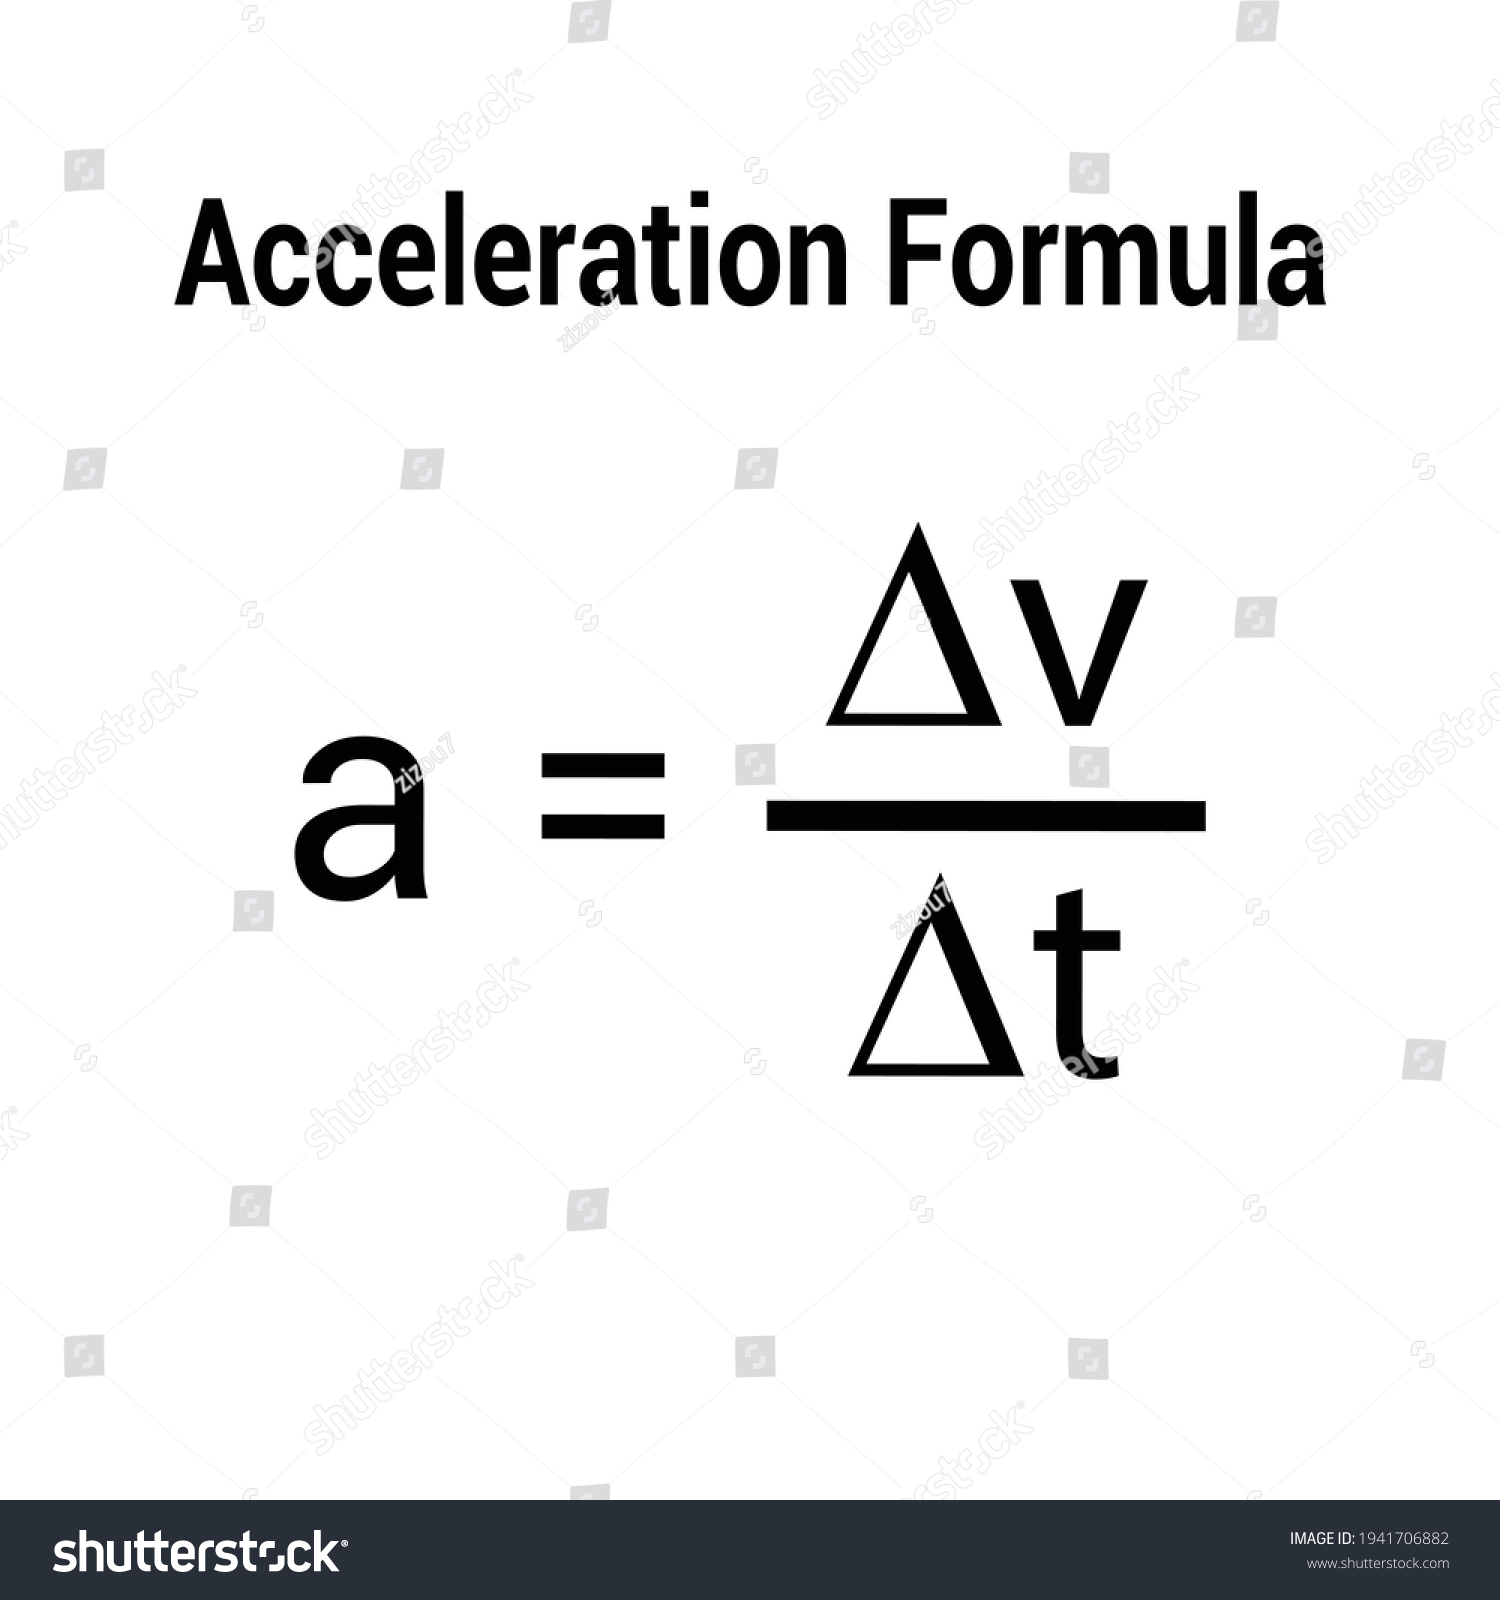
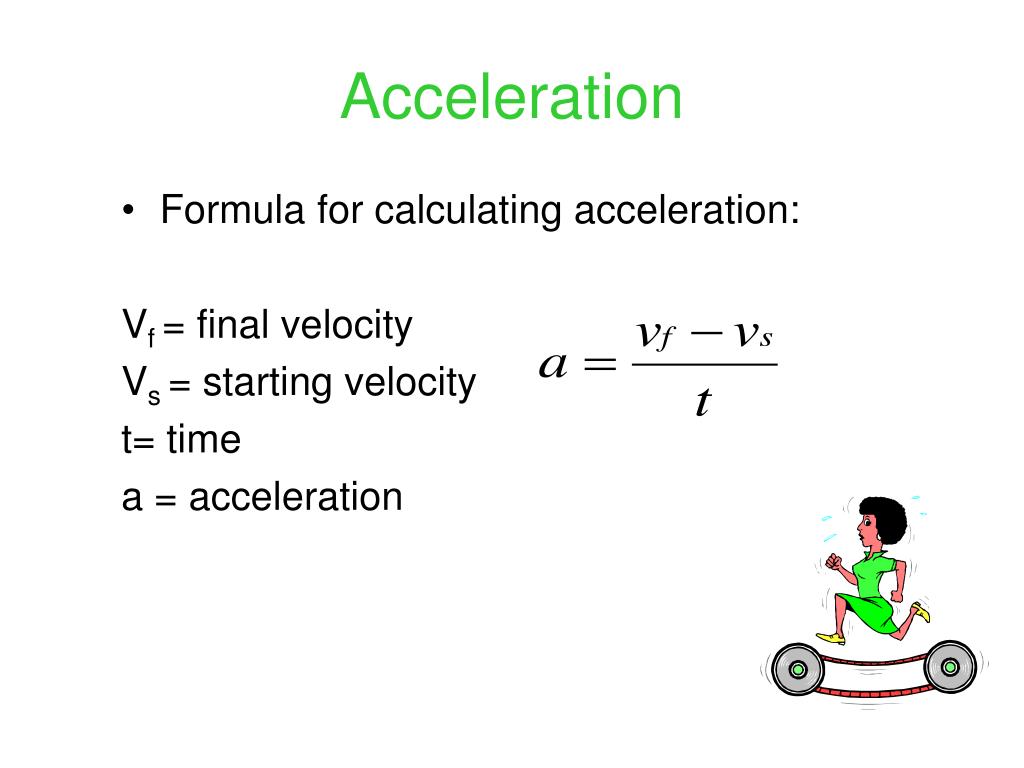
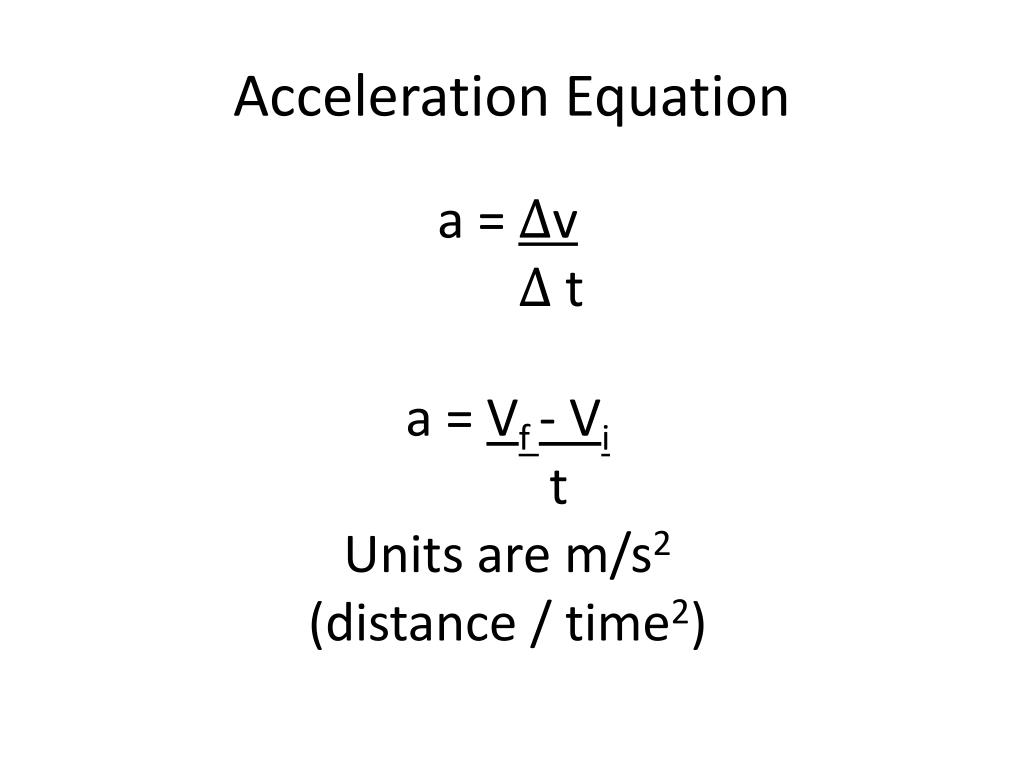
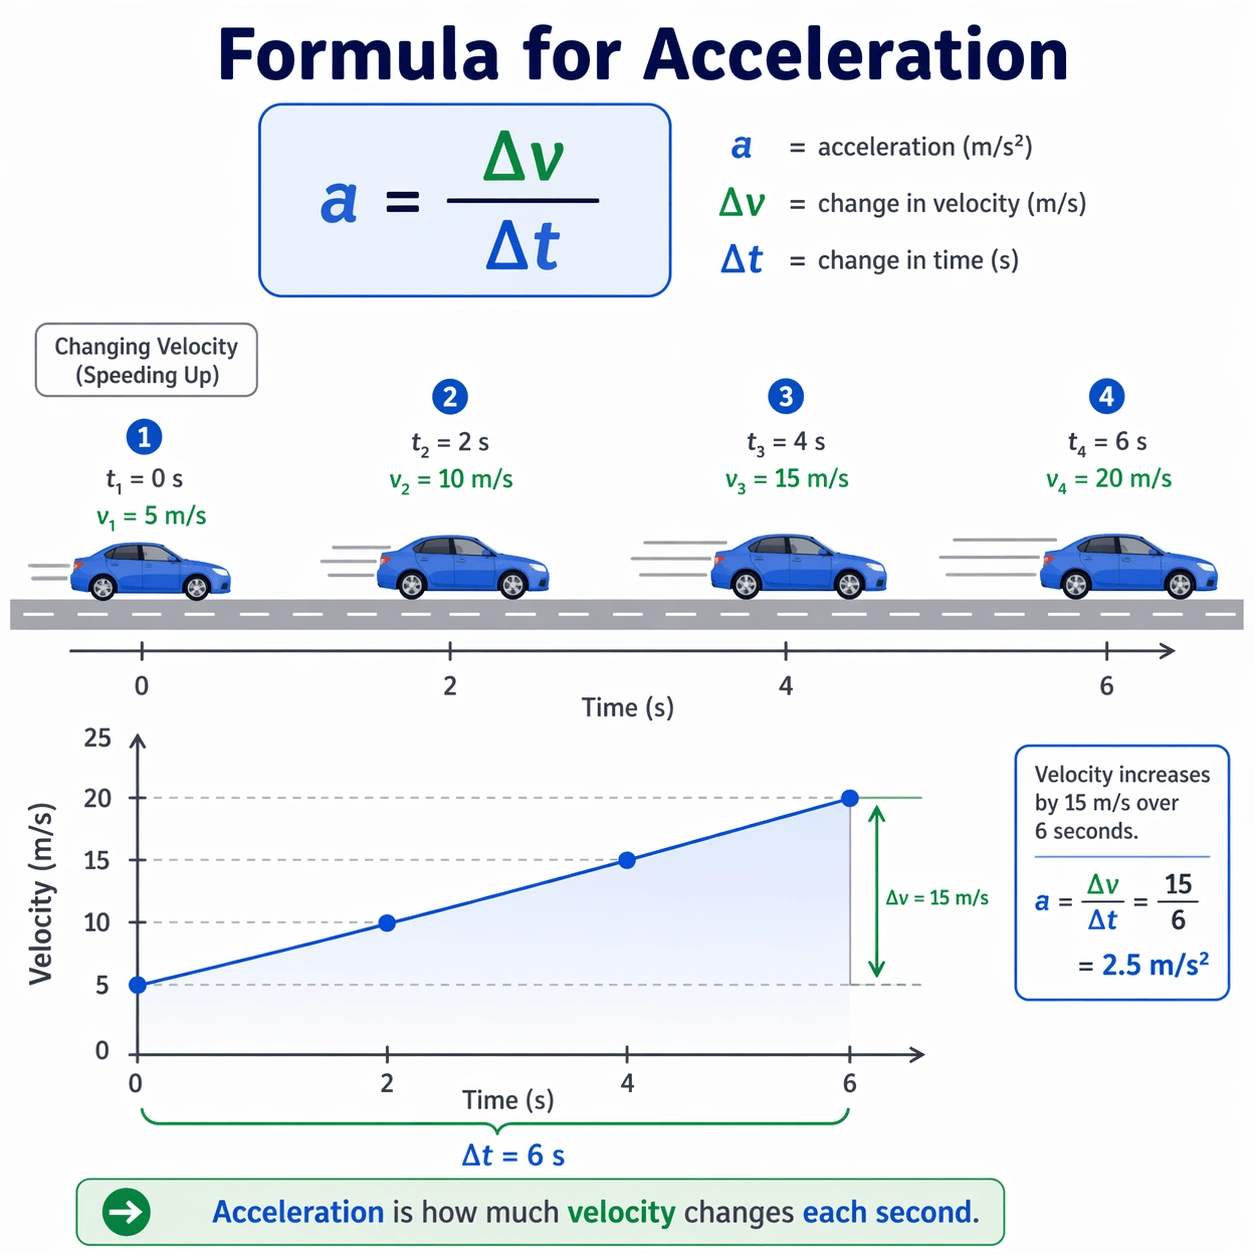
The formula for acceleration is straightforward if you know what you're actually calculating. It's change in velocity divided by change in time. Written out, that's a = v / t. Velocity is a vector, which means direction matters as much as the number. If your car goes from 0 to 60 mph in 5 seconds heading north, the acceleration is 12 mph per second north. Mess up the vector part once and your answer is wrong even if the math checks out. I've seen this trip people up in basic physics labs repeatedly. During a dynamics course back in grad school, I was setting up a cart-and-pulley experiment to measure gravitational acceleration on a track. The theoretical value should have been 9.81 m/s². My results came back at roughly 8.4. Turns out the rolling friction on those cheap lab carts isn't negligible at low accelerations, and the pulley axle had enough resistance to skew things noticeably. I stopped trying to fight it and just added a friction correction term to the equation instead of pretending the system was ideal. It matched the data almost perfectly after that.
What Is The Formula For Acceleration
There are actually a few forms depending on what variables you have available. The standard kinematic definition is a = (v_f - v_i) / t where v_f is final velocity, v_i is initial velocity, and t is the time interval. If you need acceleration from force and mass, you use Newton's second law rearranged: a = F / m. When you're dealing with circular motion, centripetal acceleration takes the form a = v² / r, pointing toward the center of the curve. And if you know displacement and time under constant acceleration starting from rest, you can derive it from d = ½at², giving a = 2d / t². The form you pick depends entirely on what quantities are actually measured in your problem. That's where most mistakes happen. People see numbers and reach for the first formula they memorize instead of checking which variables the equation actually requires. A common one I run into involves projectile motion where someone uses a = F/m with just the horizontal component of force while ignoring that gravity is still acting vertically. The acceleration vector has both components. Treating them separately and then combining them with vector addition at the end is the clean way to handle it.
When The Standard Formula Breaks Down
Constant acceleration is a nice textbook assumption that rarely holds in real systems. Once you introduce air resistance, the acceleration isn't constant anymore because drag force scales with velocity squared. For a falling object, the equation becomes a = g - (Cd * * A * v²) / (2m) where Cd is the drag coefficient, is air density, A is cross-sectional area, and v is instantaneous velocity. That means acceleration decreases as speed increases until it reaches zero at terminal velocity. Using the simple v / t formula across that whole fall gives you an average acceleration, not the actual acceleration at any point in time. If you're working with something like a rocket that's losing mass as it burns fuel, F/m changes continuously even if thrust stays constant. The acceleration increases as the mass drops. I worked on a small satellite deployment project where we modeled the launch vehicle trajectory using constant-thrust assumptions and the predicted orbit insertion was off by about 400 meters in altitude. The mass depletion over the burn phase accounts for roughly 30% of that discrepancy. We switched to numerical integration with a time step of 0.1 seconds and updated the mass each step. Computationally heavier but accurate enough to matter for orbital mechanics. Relativistic speeds are another place the classical formula gives garbage answers. Once velocity approaches a meaningful fraction of the speed of light, you need to account for relativistic mass increase or work entirely in terms of four-vectors. For most practical purposes on Earth this doesn't apply, but if you're simulating particle accelerator trajectories it completely changes your approach.
Get the Full Details
Common Pitfalls In Practice
Unit consistency is the number one thing that screws people up. Mixing meters and kilometers per hour, seconds and minutes, grams and kilograms. I once had to debug a simulation where someone reported acceleration in km/h² without converting. The numbers looked reasonable until I checked the units and realized the values were off by a factor of 3,600,000. Always convert everything to SI base units before plugging into any formula. Direction signs are another frequent source of error. If you define upward as positive and an object is slowing down while rising, its acceleration is negative. The velocity is positive but decreasing, so acceleration opposes the velocity vector. Getting that sign wrong flips your entire solution. The same issue shows up with deceleration labeled as a separate concept — it isn't. Deceleration is just negative acceleration along the chosen axis. Another thing people overlook is that the basic formula assumes the time interval is measured in an inertial reference frame. If your measuring platform is itself accelerating, you need to account for that fictitious force. Standing on a accelerating train and dropping a ball, the ball appears to accelerate backward relative to you even though no horizontal force acts on it. From the ground, it's moving forward at constant horizontal velocity while falling. Both descriptions are correct in their own frame, but plugging the observed acceleration into F=ma without adjusting for the frame acceleration gives wrong results.
How To Apply This In Actual Work
Start by identifying what you know and what you need. List your known variables with units. Determine whether acceleration is constant or variable. If constant, any of the standard kinematic equations apply directly. If variable, you'll need calculus or numerical methods. For engineering work with real sensors, acceleration data often comes as a time series from an accelerometer. Sampling rate matters — a 100 Hz sensor won't capture quick impact events accurately, and aliasing will corrupt your data. I typically recommend sampling at least 10 times the highest frequency component you care about, though 50 Hz is a more conservative minimum for most mechanical systems. When processing accelerometer data, expect to deal with bias drift and noise. A decent quality MEMS accelerometer might have a bias stability of around 100 µg (that's 0.001 m/s²), which sounds small but accumulates quickly when you integrate acceleration to get velocity and position. Over a minute of operation, uncompensated bias can drift position by several meters. Calibration before use and temperature compensation make a measurable difference. A simple two-point calibration at different known temperatures usually reduces thermal drift by about 70 percent. For structural testing, I've found that using the raw formula a = v/t with finite differences on noisy data amplifies high-frequency noise significantly. Taking the derivative numerically multiplies noise by the frequency content, which means your acceleration signal can become almost unusable above a few hundred hertz depending on your sensor. Applying a low-pass Butterworth filter at about 20% below your Nyquist frequency before differentiating keeps the signal clean without introducing significant phase distortion. A fourth-order filter with a 5 millisecond group delay is what I typically use.