Reading Motion From a Line on Paper
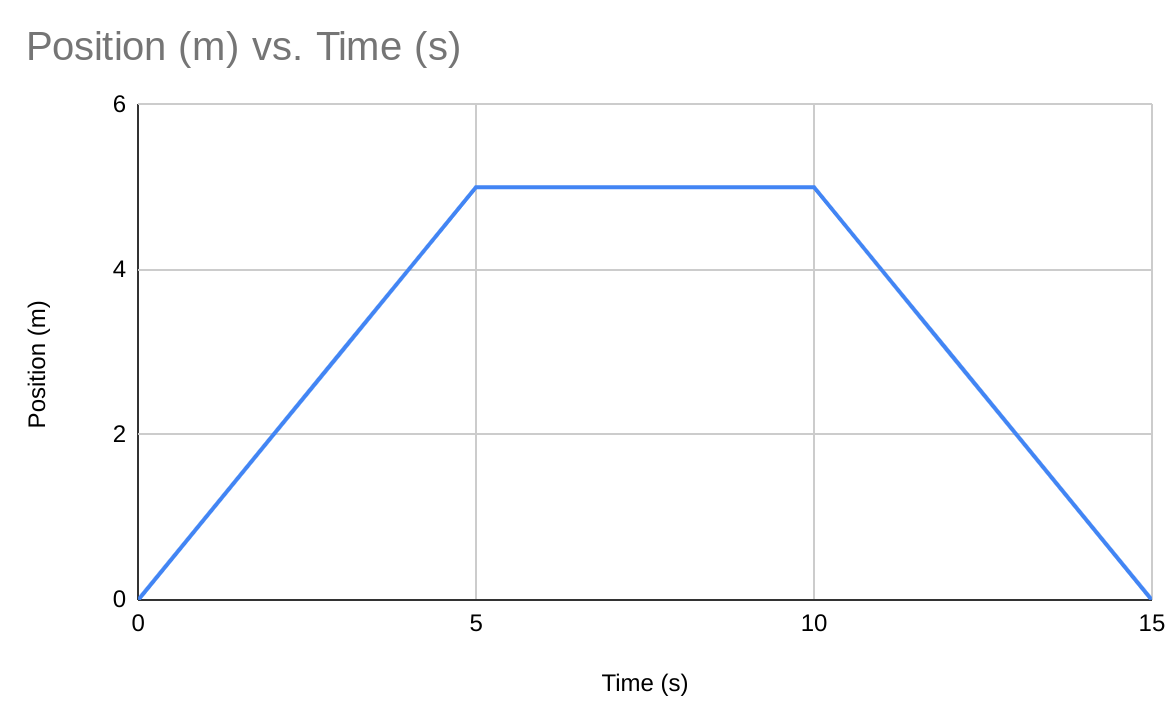
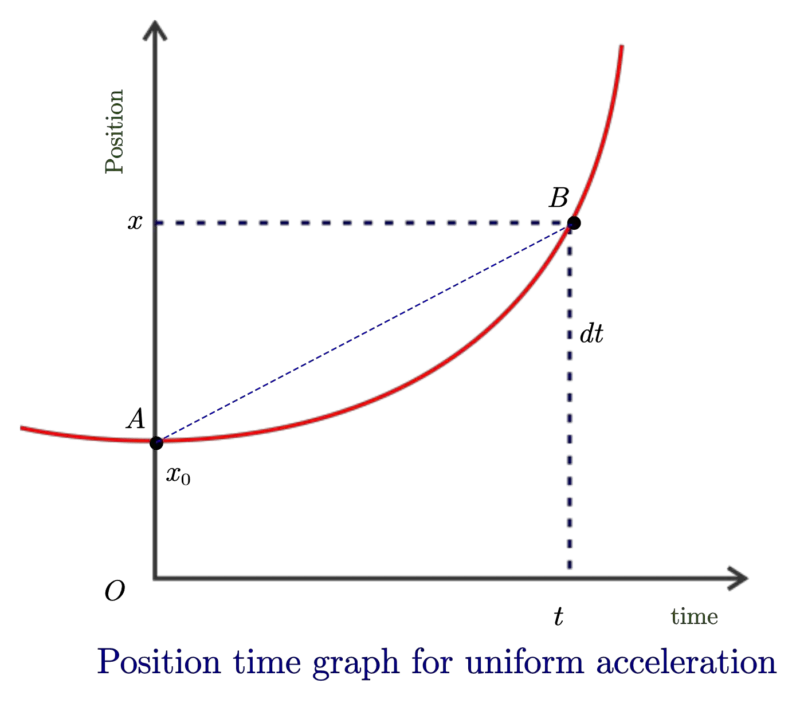
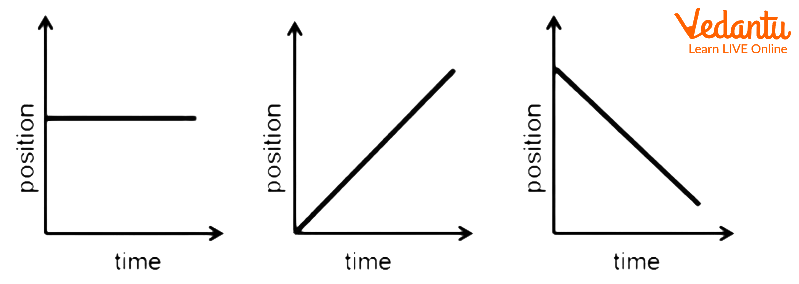
A position time graph is just a visual record of where something was at every moment during a span of time. You plot position on the vertical axis and time on the horizontal axis. The line that connects your data points tells you what the object was doing. That is the entire thing. Most textbooks make it sound more complicated than it actually is because they spend too much time on idealized scenarios with perfectly straight lines. Real data is never that clean. The nature of the graph depends entirely on what the motion looks like. A flat horizontal line means the object stayed at the same position. Zero velocity. Nothing moving. A diagonal straight line means constant velocity — the steeper the slope, the faster the speed. A curved line means acceleration or deceleration is happening. The slope is changing from point to point. That slope at any single point is your instantaneous velocity, which you find by drawing a tangent line and calculating its gradient. That last part trips up people constantly because they forget that velocity has direction, and on a position time graph, a negative slope means movement in the opposite direction of your positive axis.
What Is The Nature And Importance Of Position Time Graph
Its importance comes down to one practical fact: it is usually the first thing you can measure accurately when studying motion. Distance sensors, motion trackers, video analysis software — they all output position versus time data. You do not need sophisticated equipment to get useful results. A stopwatch and a measuring tape will give you enough to sketch a meaningful graph. The graph then becomes your primary analytical tool for understanding what happened during the experiment. I worked on a project a few years ago where we were tracking the displacement of a pneumatic actuator over repeated cycles. The manufacturer's spec sheet claimed the actuator reached position within 0.5 milliseconds of the target, but when I plotted the position time data from our high-speed camera, the curve showed a clear exponential settling pattern with a visible overshoot before stabilization. The graph revealed that the controller was overcompensating on every cycle, causing micro-vibrations that accumulated into measurable positional error over time. That insight came entirely from looking at the shape of the curve in the settling region, not from any numerical readout. We adjusted the gain parameters and the graph changed immediately — smoother approach, no overshoot, faster true settling time. Here is something most people miss when they are learning this. The area under a position time graph does not represent anything useful. Students routinely try to integrate it and get confused when the units do not make sense. The area under a velocity time graph gives displacement, and the area under an acceleration time graph gives change in velocity. But the area under position time is position multiplied by time, which is a quantity called absement and it is essentially never relevant in introductory physics. Do not waste time trying to find meaning in that area.
Another thing that causes problems is confusing position time graphs with distance time graphs. They look identical when motion is always in one direction, but they diverge the moment the object reverses. A distance time graph can never slope downward because distance from the starting point does not decrease when you move back toward it — that is displacement, which a position graph shows correctly with negative values. If you are analyzing circular motion or anything involving returns, using a distance time graph will give you wrong conclusions about velocity. Stick with position. There are also cases where the graph becomes nearly useless. If two objects are moving at the same constant velocity, their position time lines are parallel and you cannot determine which is ahead without additional context about where you set your origin point. Similarly, if your time resolution is too coarse relative to the motion, you will miss rapid changes entirely. I once had a student recording a bouncing ball with a sensor sampling at 10 hertz. The graph looked like a series of smooth curves when it should have shown sharp V-shaped reversals at each bounce. The sampling rate was simply too low to capture the brief contact events. Increasing the sample rate to 100 hertz fixed the problem completely. Always check your sampling frequency against the fastest change in your system before trusting the shape of the graph. The limitations are worth stating plainly. Position time graphs show you velocity through slope, but they do not directly show forces, energy, or momentum. You need additional data or assumptions to extract those quantities. They also assume you have a single defined reference point for position, which can be arbitrary and sometimes misleading if you do not state your coordinate system explicitly. Two people analyzing the same motion with different origin points will produce different graphs that are both correct, which causes unnecessary confusion in collaborative work.
Get the Full Details
If you need position and velocity information simultaneously, switching to a velocity time graph or a phase space plot where position and velocity are on separate axes will save you a lot of headache. Those alternatives give you direct access to speed without calculating slopes, and they make it easier to spot oscillatory behavior at a glance. For basic kinematics and introductory analysis, the position time graph remains the standard tool. It is not glamorous, but it is reliable when you respect its constraints and understand what the slope actually represents at every point along the curve.