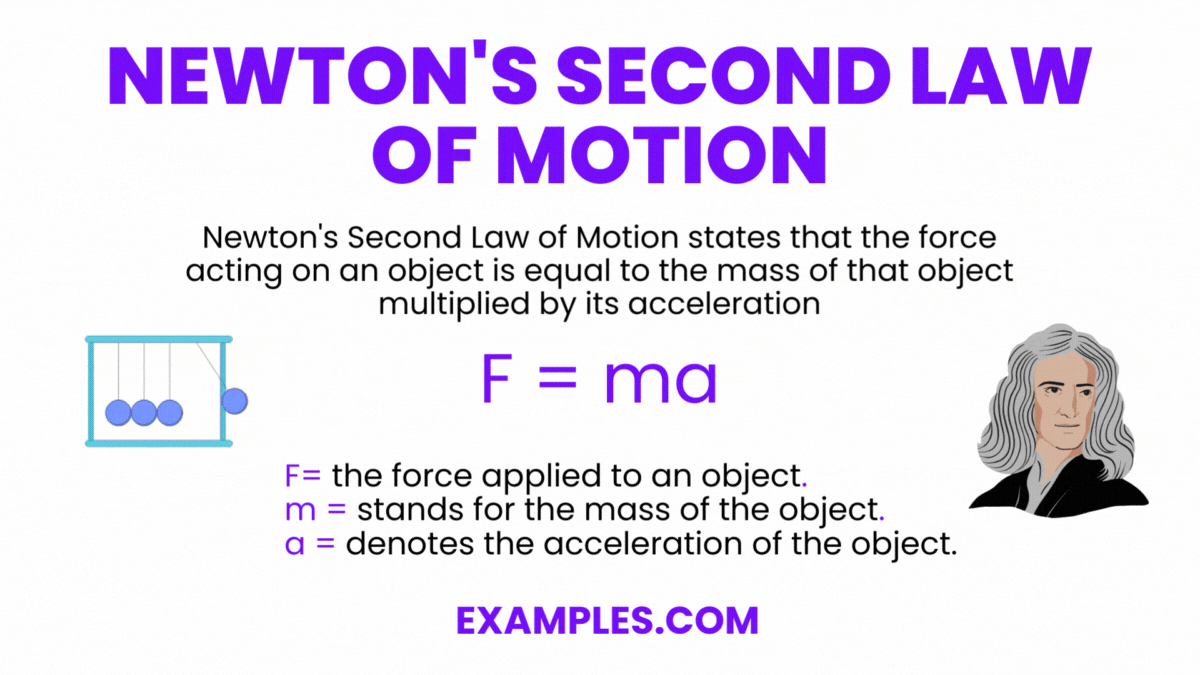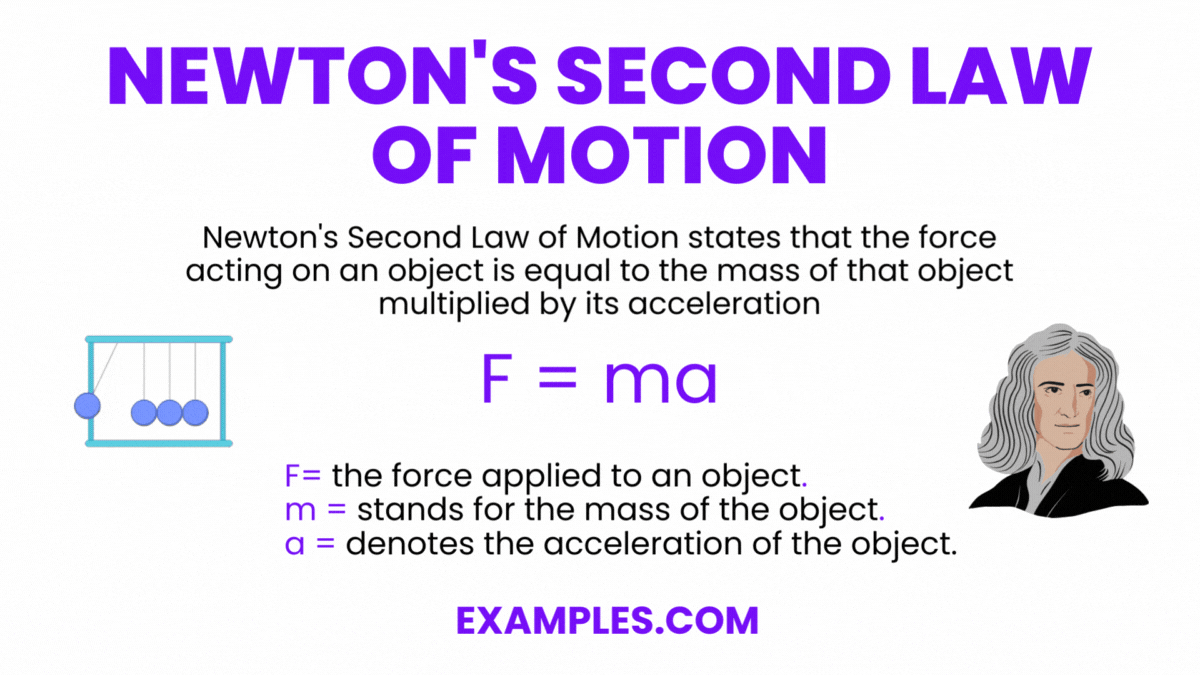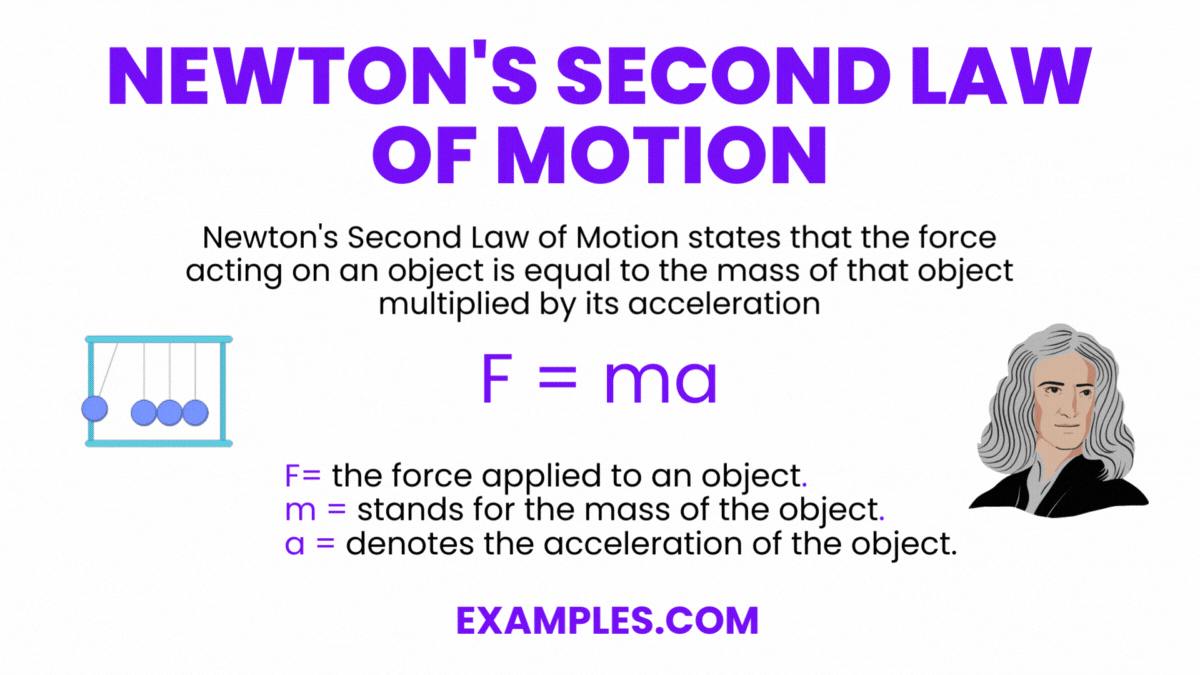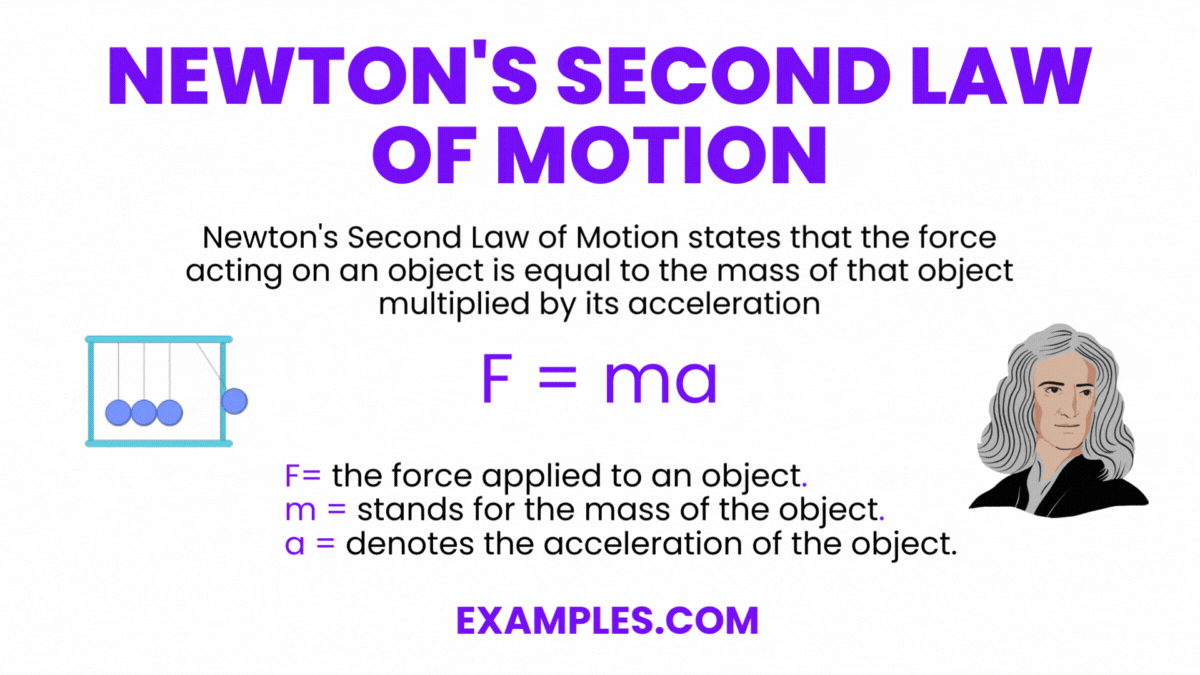
Newton's Second Law in the Real World
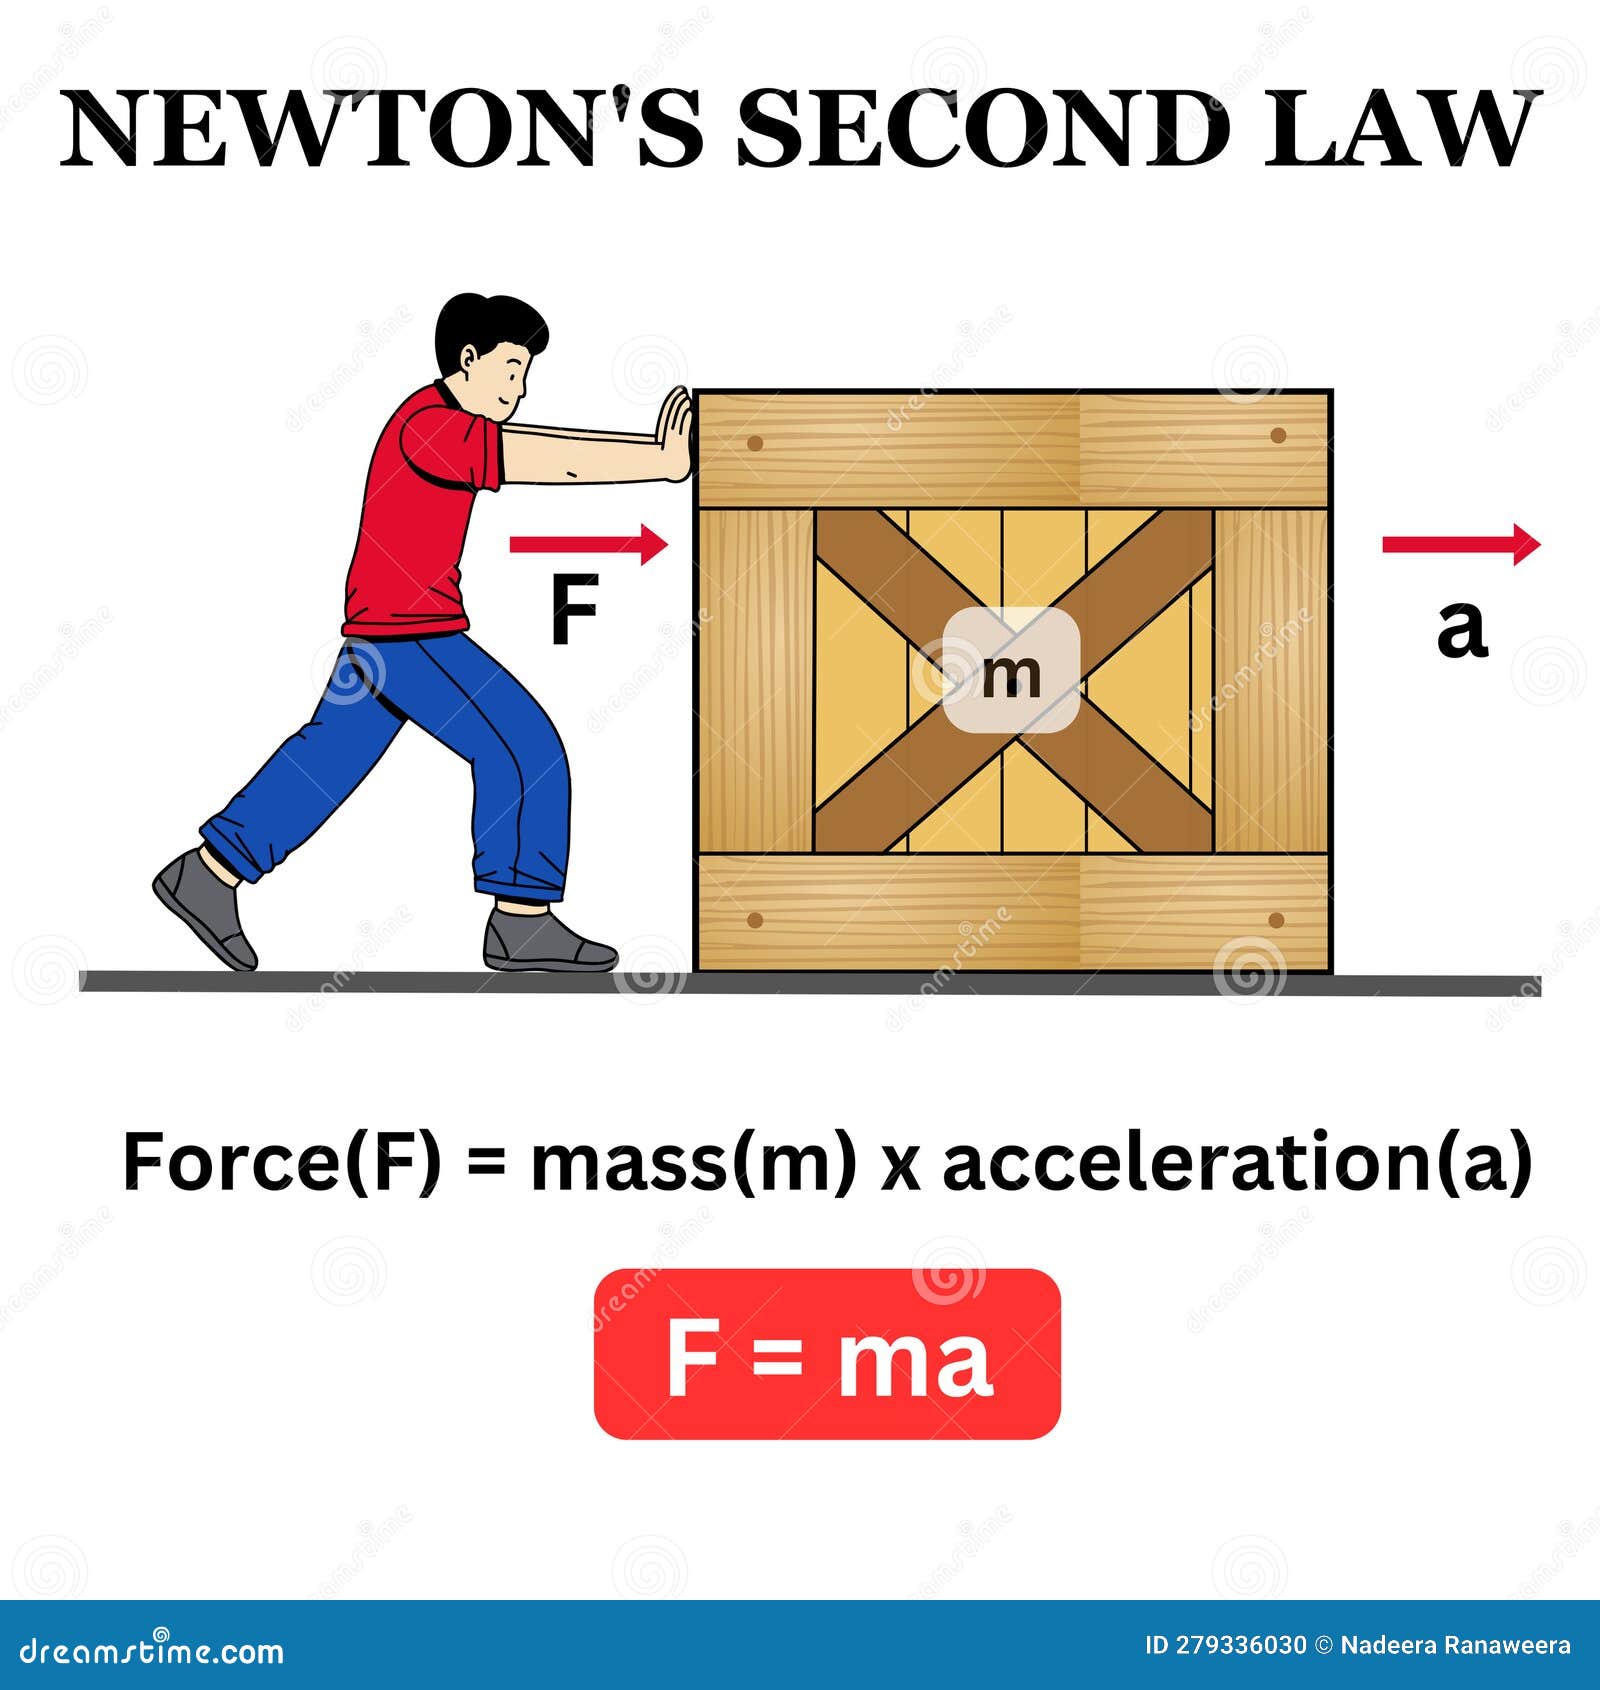
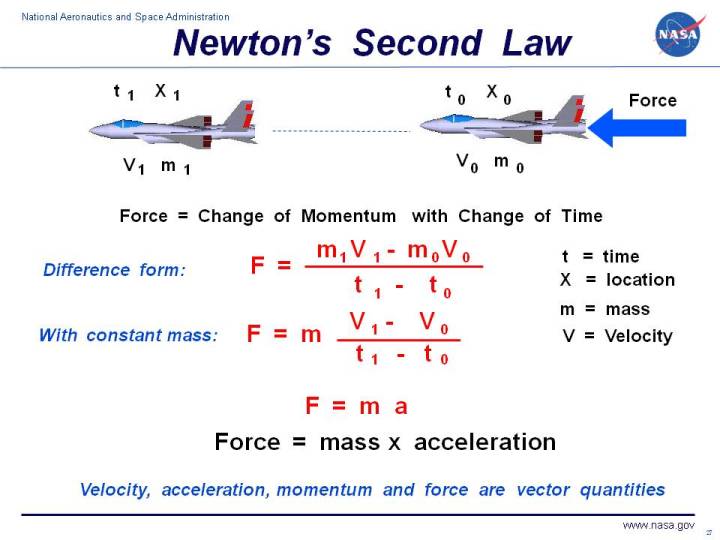
F=ma. Everyone learns that in high school physics. It sounds straightforward until you actually try to use it outside a textbook. That's because the real world rarely gives you clean, frictionless surfaces and isolated forces. When you're working with moving parts, material handling, or anything mechanical, the second law of motion becomes a practical tool that can make or break a design. The formal definition is simple: the net force acting on an object equals the rate of change of its momentum. In most practical applications, mass stays constant, so it collapses to the familiar equation. But that convenience hides a lot of complications. Friction isn't constant. Mass distribution matters. And sometimes you're dealing with systems where the mass changes while things are moving.
What Is The Second Law Of Motion
At its core, the law tells you that force, mass, and acceleration are locked together. Push something heavier with the same force and it accelerates more slowly. Accelerate something faster and you need proportionally more force. That's the basic relationship. The trick is applying it when everything else is fighting against you. I once designed a pick-and-place mechanism for a small electronics assembly line. The math said a 50-newton linear actuator would handle a 10-kilogram carriage with acceptable cycle times. The equation checked out. What it didn't check out was the real-world friction in the guide rails, the belt tension variance across temperature swings, and the fact that the parts being picked up added unpredictable mass to the moving carriage. The first unit I built kept overshooting its target by about four millimeters at the end of each stroke. The actuator simply couldn't deliver the force the model predicted because we hadn't accounted for the full friction envelope. The fix wasn't to throw more power at it. More force just made the overshoot worse on the deceleration phase. Instead, I mapped the actual friction curve by running the carriage at different speeds and measuring the current draw. The friction wasn't static like the textbook assumption—it was velocity-dependent in a way that shifted the entire force budget. Once I modeled the friction as a damping term and adjusted the acceleration profile to work within the real force window, the machine hit its targets consistently. The theoretical law didn't change. My application of it did.
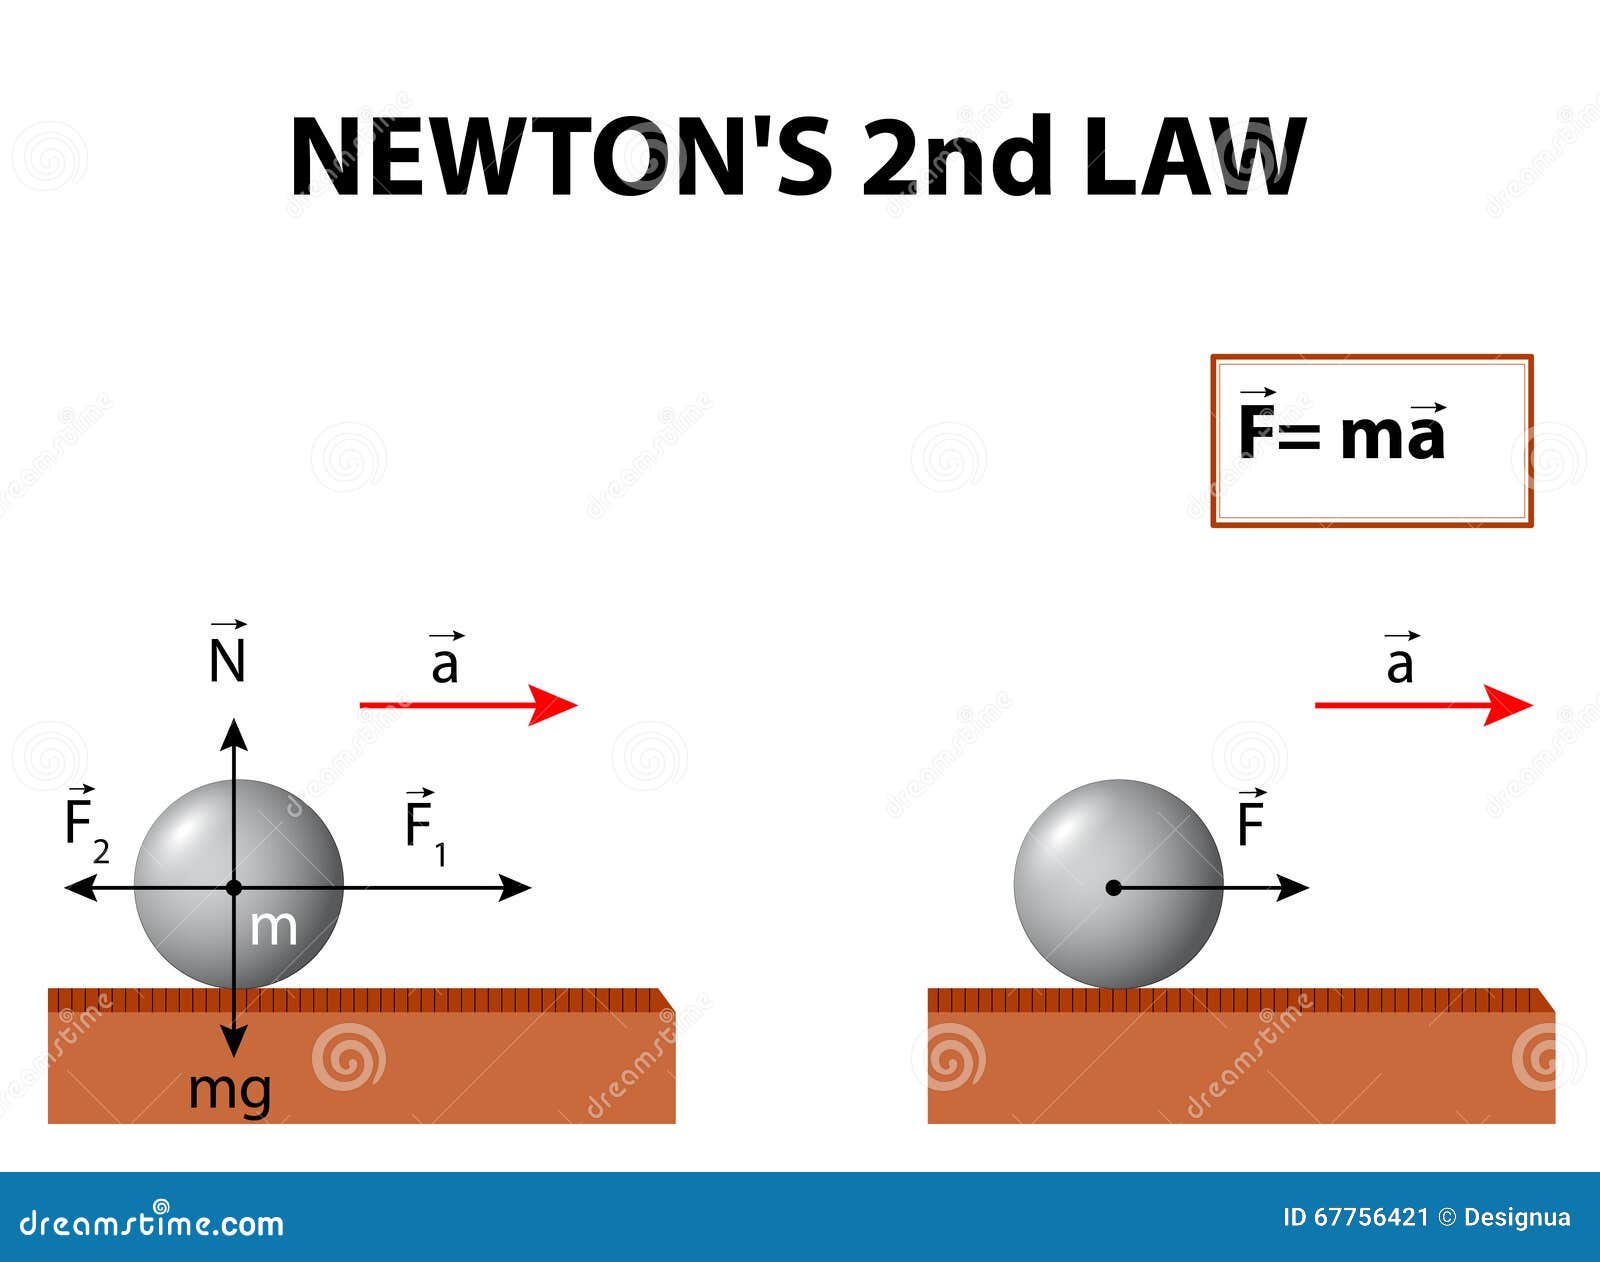
One thing most people get wrong is treating the equation as a scalar when it's fundamentally a vector. Direction matters as much as magnitude. If you're working on an incline or a multi-axis system, you need to resolve forces along each axis independently. I've seen engineers skip this step and wonder why their calculations don't match reality. Resolve every force. Then add them vectorially. Then solve. Another nuance that catches people out is what happens when your system isn't rigid. The second law assumes a point mass or a rigid body. In practice, flexible components absorb and redistribute energy. I've seen conveyor belt systems where the belt deflection under load created a lag between when the motor applied force and when the payload actually started accelerating. The actuator was delivering the right force, but the belt stretch meant the payload experienced a delayed and damped version of it. Adding proper belt tensioning and reducing span lengths between supports brought the response in line with predictions. The law also breaks down when mass isn't constant. Rocket propulsion is the classic case, where the equation needs to be expressed in terms of momentum change rather than just F=ma. But even in industrial settings you encounter variable mass. A hopper discharging material, a conveyor picking up items, a robotic arm grasping objects mid-cycle. In those cases, you need to account for the momentum transferred by the incoming or outgoing mass. The basic formula gives you a starting point, not the final answer.
Get the Full Details
Working Through a Practical Calculation
Let's say you're sizing a motor for a linear axis. The carriage mass is 8 kilograms. You need to accelerate it to 0.5 meters per second in 0.2 seconds. The friction force from the bearings and seals measures at about 12 newtons at rest and increases slightly with speed. You're moving horizontally, so gravity doesn't factor into the acceleration force. First, calculate the required acceleration: 0.5 divided by 0.2 equals 2.5 meters per second squared. The force to overcome inertia is mass times acceleration, which is 8 times 2.5, giving you 20 newtons. Add the friction force of 12 newtons and you're looking at 32 newtons of total force the motor needs to deliver. That's the minimum at the start of the move. But here's where the simplification starts to crack. Friction isn't purely constant. There's static friction at rest that's higher than kinetic friction once things are moving. The transition between the two creates a stick-slip effect if the motor torque isn't smooth. A gearmotor with significant backlash will also introduce a dead zone where force is applied but no motion results until the gears mesh on the other side. These aren't theoretical concerns—they're the reason your calculated motor size ends up too small in practice.
A rule of thumb I use is to add a safety factor of at least 1.5 to the calculated force. So 32 newtons becomes a target of roughly 48 newtons at the motor shaft, which then gets translated back to motor torque based on your lead screw or belt drive specifications. This accounts for friction variations, wear over time, and any unexpected load changes. It's not wasted capacity. It's the difference between a system that works and one that struggles. When you're dealing with vertical motion, gravity enters the equation directly. A 8-kilogram mass on a vertical axis needs 78.5 newtons just to hold it stationary (8 times 9.81). Add acceleration force on top of that and the motor sizing changes dramatically. I've seen the same motor selected for both horizontal and vertical applications because someone forgot the gravity term. The vertical one failed to hold position and drifted down whenever the power cycled.
Common Pitfalls and Where the Law Falls Short
The second law assumes inertial reference frames. If you're working in an accelerating frame—say, a vehicle mounting equipment that will itself be moving—the apparent forces change. You need to add fictitious forces to your calculations, which is another layer most people skip. It's easy to forget because the problem usually presents itself as "why isn't this holding up" rather than "my reference frame is wrong." High-speed applications expose another limitation. At very high accelerations, the structural compliance of your mounting points and the flexibility of your components can cause resonant vibrations that dominate the dynamics. The F=ma calculation tells you the ideal motion, but the physical system oscillates around that ideal. Adding mass dampers or increasing structural stiffness usually resolves it, but you won't see it in a basic force calculation. There's also the question of force measurement. In theory, you calculate the required force. In practice, you often need to measure it. Strain gauges, load cells, and force sensors each have their own accuracy limits and installation requirements. A load cell mounted incorrectly can read 10 to 20 percent off, which makes your calibration efforts pointless. I've wasted days troubleshooting systems that were actually fine—the sensor was just giving bad data. Verify your measurement chain before you trust it.
Another blind spot is thermal effects. Friction generates heat. Heat changes material properties. A steel guide rail that's warm from extended operation has different friction characteristics than when it's cold. Lubricant viscosity shifts with temperature. If your system runs through wide temperature ranges, the force requirements will shift with it. I learned this the hard way on an outdoor installation where the motor that performed perfectly in the shop would stall on cold winter mornings. The lubricant had thickened enough to increase starting friction beyond the motor's stalling torque. Switching to a wider viscosity range grease solved it. Forces also don't always apply where you think they do. Off-center loading creates torques and moments that your basic linear calculation ignores. A carriage that's not properly loaded can bind in its guides because the force distribution across the bearing surfaces becomes uneven. The motor fights against its own constraint rather than moving the load. Proper load distribution and periodic realignment checks are cheaper than redesigning the drive system.
Advanced Considerations for Complex Systems
When you move into multi-degree-of-freedom systems—robotic arms, gantry platforms, anything with more than one moving axis—the second law still applies, but the math gets messy. Each axis interacts with the others through coupling forces. Moving one joint creates reaction forces on adjacent joints. This is where you start needing equations of motion derived from Lagrangian mechanics rather than simple F=ma calculations. The principles are the same. The bookkeeping is heavier. Centrifugal and Coriolis forces become relevant in rotating systems. A robotic arm extending while rotating experiences an outward force that increases with the square of the angular velocity. The motor driving the extension axis has to fight this force in addition to the arm's own weight and acceleration requirements. Ignoring these effects leads to position errors that grow worse at higher speeds. Control theory intersects with the second law in ways that matter for practical implementation. A well-tuned PID controller can compensate for some of the inaccuracies in your force model, but it can't create force that doesn't exist. If your motor can't deliver the calculated peak force, no amount of tuning will make the system follow its trajectory accurately. The controller can only work within the physical limits of the hardware.
For precision applications where micro-newton forces matter, the second law still governs but the measurement and control challenges become enormous. Vibrations from the building, electromagnetic interference in the motor drivers, even air currents can introduce forces that dwarf your signal. In those cases, isolation and shielding matter more than the theoretical calculation. The second law of motion is one of those fundamentals that seems so obvious it's easy to underestimate. It's the foundation of almost every mechanical design decision you'll make. But the gap between knowing it and applying it correctly is where real engineering happens. Your calculations will be wrong. Something will always be unaccounted for. The goal isn't to eliminate error—it's to understand what you're missing and build margins accordingly. If you're starting out, begin with simple systems. Measure actual forces whenever possible. Compare them to your calculations. The difference between the two is where you learn. Keep doing that and the gaps in your understanding start to close.