Working With Angles Without Losing Your Mind
Getting Started With Angle And Angle Measure
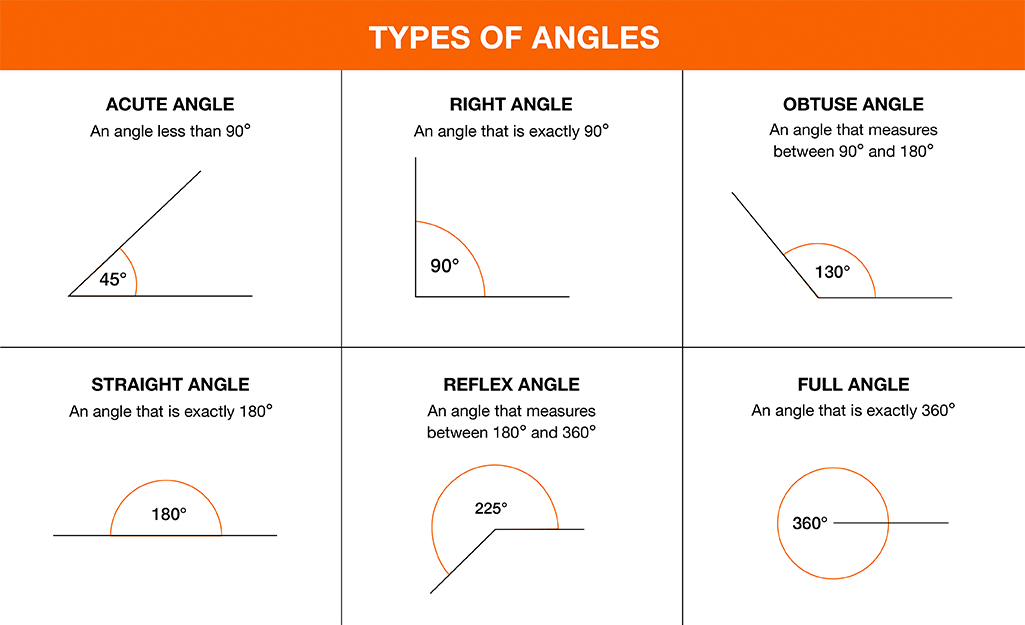
I spent three weeks last year chasing a ghost error in a CNC toolpath where the axis wasn't positioning correctly at about 87 degrees. The machine was reading its own encoder values fine. The G-code looked right. Turns out the CAM software was outputting radians to a post-processor that was treating them as degrees, and nobody had noticed because the error was invisible until the tool was already cutting into the part. That's the thing about angular measurement — it's usually fine until it isn't, and by then you're either dealing with scrap material or a safety issue. The core idea is straightforward enough. An angle measures the rotation between two rays sharing a common endpoint. You pick a reference direction, call it zero, and measure how far you've turned from there. The most common unit is the degree, which splits a full circle into 360 equal parts. A right angle is 90 degrees. Straight line is 180. Full circle brings you back to 360. Radians are the other system you'll encounter constantly, especially in anything involving calculus or trigonometric functions. One radian is the angle where the arc length equals the radius. There are 2*pi radians in a full circle, which is roughly 6.28318. Here's something most beginners miss: radians aren't just a math convention. They're the natural unit for describing motion, and using degrees in any calculation involving rates of change, derivatives, or angular velocity introduces a scaling factor you have to carry around everywhere. If you're writing simulation code or doing kinematic analysis and you keep your angles in degrees the whole time, you're going to get wrong answers on things like centripetal acceleration or angular momentum without immediately realizing why. Convert to radians before you do any calculation that isn't purely geometric, then convert back only for display purposes. That single habit eliminates an entire category of bugs.
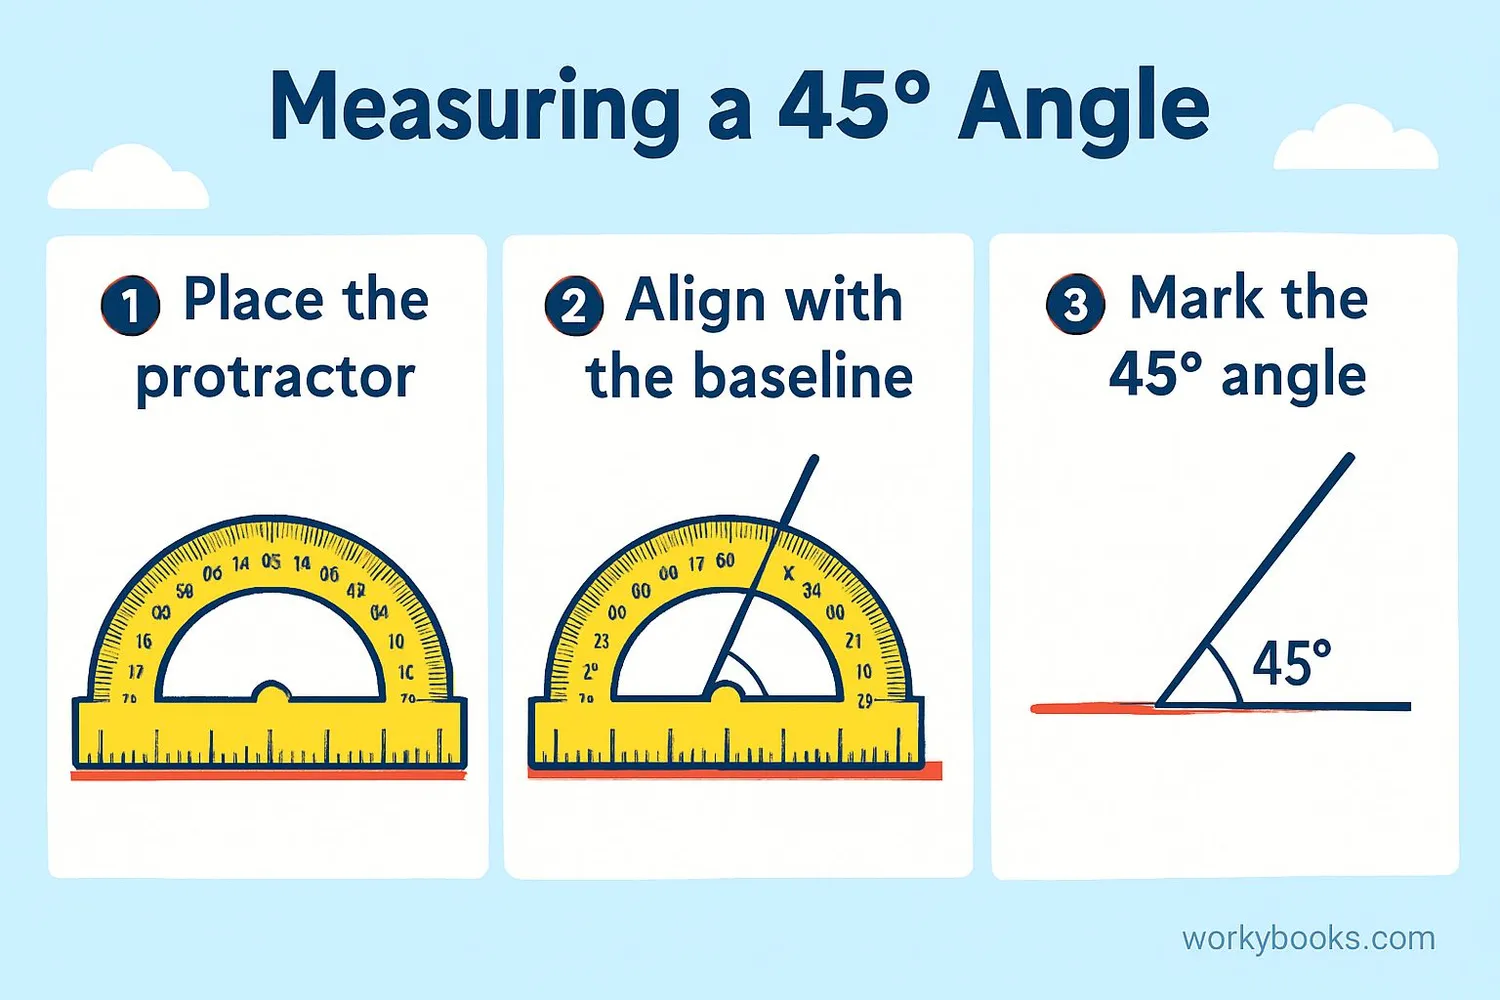
The atan2 function is where most people trip up. You might think you can use a regular arctangent to find an angle from a ratio of opposite over adjacent, but that only works in two of the four quadrants. atan2 takes both the y and x components separately and resolves the correct quadrant automatically. When I was debugging that CNC problem, the real issue was actually in the coordinate transformation code that used atan instead of atan2, so the toolpath mirrored incorrectly whenever the angle crossed into negative territory. I caught it by comparing the output of both functions side by side and noticing they diverged at exactly the points where the coordinate system flipped signs. For physical measurement, a standard protractor works for rough work up to about half a degree of accuracy if you're careful. Digital angle finders and smart levels will get you down to around 0.1 degrees, sometimes better. But if you're working in surveying or precision machining, you need something like a theodolite or a coordinate measuring machine, and even then you're looking at angular uncertainty in arcseconds rather than whole degrees. One arcsecond is one three-thousand-six-hundredth of a degree. At that scale, the curvature of the earth starts mattering if you're measuring distances over a kilometer or more. There's also the gradian system, which divides a circle into 400 grads instead of 360 degrees. A right angle is exactly 100 grads. It was invented during the French Revolution to make everything decimal, which sounds nice in theory, but nobody uses it anymore except in some European surveying legacy systems and occasional French engineering contexts. You'll encounter it occasionally when reading old drawings or working with equipment that was imported. Just know that 1 grad equals 0.9 degrees, and 100 grads is the same as 90 degrees. Memorize that one conversion and you'll be fine if it ever comes up.
When measuring angles from images or video, people often reach for edge detection and then try to calculate angles from pixel coordinates. This works in controlled setups with known camera calibration, but in practice the margin of error grows quickly if your subject isn't parallel to the sensor plane. A slight tilt of the measured object introduces perspective distortion that makes the apparent angle different from the true angle. I've seen this cause problems in motion capture systems where the tracking markers were on a surface that wasn't perpendicular to the camera. The fix was to calibrate with a known reference grid in the same plane as the markers and apply a homography transformation before doing any angle calculations. Without that step, your angular measurements could be off by several degrees depending on where in the frame the subject was located. Small angle approximation is another thing worth knowing about. When angles are sufficiently small, you can treat sin(theta) as approximately equal to theta (in radians), tan(theta) as approximately theta, and cos(theta) as approximately 1 minus theta squared over two. This approximation is valid to within about one percent for angles under 0.1 radians, which is roughly 5.7 degrees. It's extremely useful in structural analysis, optics, and control theory where you're dealing with perturbations around an equilibrium point. But it breaks down fast once you go past about 10 degrees, and applying it blindly to a larger angle will give you results that look plausible but are quantitatively wrong. If you need to measure angles from a photograph or screen capture without specialized equipment, the simplest approach is to find two points along each ray of the angle, calculate their slopes, and use the formula for the angle between two lines. This requires that you know the scale or at least that the image isn't distorted. If your image has been resized non-uniformly, which happens more often than you'd think with screenshots taken on different displays, the measured angle will be wrong. Check your aspect ratio first. A 4 by 3 image that's been stretched to fit a 16 by 9 screen will make right angles look like they're about 78 degrees if you don't correct for it.
Get the Full Details

The biggest practical limitation of angular measurement is that every tool has a resolution limit. Even the best theodolites have a finite number of ticks they can read, and digital encoders have a finite number of bits. A 12-bit encoder on a rotating shaft gives you 4096 positions over a full revolution, which works out to about 0.088 degrees of resolution. If your application requires finer measurement, you need a higher-resolution encoder or a method that doesn't rely on absolute angular position. I worked on a project once where we needed to track angular position to within 0.01 degrees over a range of plus or minus 30 degrees, and a standard absolute encoder couldn't handle it. We ended up using a relative measurement approach with a reference mark and interpolating between encoder ticks, which got us down to about 0.005 degrees of effective resolution. It added complexity to the code but solved the problem without upgrading the hardware.
Converting Between Common Angular Units
Degrees to radians means multiplying by pi divided by 180. Radians to degrees means multiplying by 180 divided by pi. Minutes and seconds are subdivisions of degrees, with 60 in a degree and 60 seconds in a minute. So 45 degrees 30 minutes is 45.5 degrees. Sexagesimal notation is still used in navigation and astronomy, and you'll see it on nautical charts and in telescope pointing systems. If you're doing manual calculations with sexagesimal angles, converting them to decimal degrees first before applying any trigonometric function saves you from making arithmetic errors with the base-60 subdivision. Angular measurement is deceptively simple on the surface, and the complications only show up when you try to use it in a real system. The units themselves are agreed upon fairly universally in technical work. The real issues come from implementation details — which function you use to compute an angle, whether your angles are in the right units at each step of a calculation, and how your measurement tool's resolution limits what you can actually trust in the result. Download links for measurement tools vary depending on what you're trying to do. For basic angle measurement from images, there are a few free options like Protractor or Angle Measure that run in the browser and let you drop in a photo and place points to measure. For CAD work, any decent package handles angular dimensioning natively. If you're doing field surveying, dedicated apps like GeoMeasure or FieldMap are more appropriate than general-purpose tools. The caveat is that no software can compensate for poor input data. Measuring an angle from a low-resolution or perspective-distorted image will give you a number, but that number might not correspond to anything physically meaningful.
I still run into people who treat angles as just numbers without considering the frame of reference they belong to. An angle of 45 degrees means something completely different if your zero reference is magnetic north versus true north versus the long axis of a building. In construction and surveying, this distinction matters because the measurements feed into layout work that's going to be built. A few degrees of error in your reference frame can compound into feet of deviation over a long measurement baseline. Always note what your reference direction is when recording angular measurements, and if someone else is going to use your data, state it explicitly. It takes one sentence and saves hours of confusion later. The relationship between angular measurement and linear distance is governed by the arc length formula, s equals r theta, where theta is in radians. This is why radians are convenient in physics and engineering — the math comes out naturally without extra conversion factors. In practical terms, this formula tells you how far something moves along a circular path for a given angular displacement. If you're designing a rotary stage or a steering mechanism, this relationship is what connects the motor's angular output to the actual position of whatever you're moving. Skipping the radian conversion here is one of the most common mistakes I see in beginner mechanical design work, and it almost always surfaces as a part that doesn't go where it's supposed to.