The Practical Guide to Converting Analog Signals to Digital Data
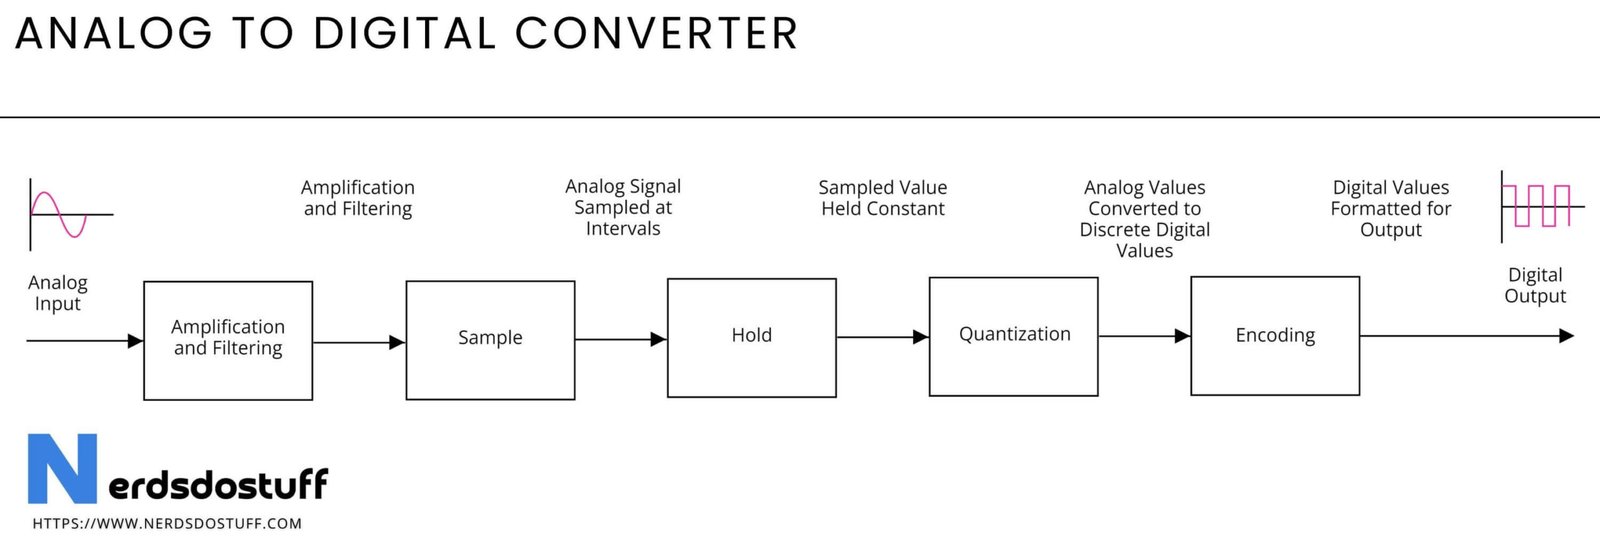
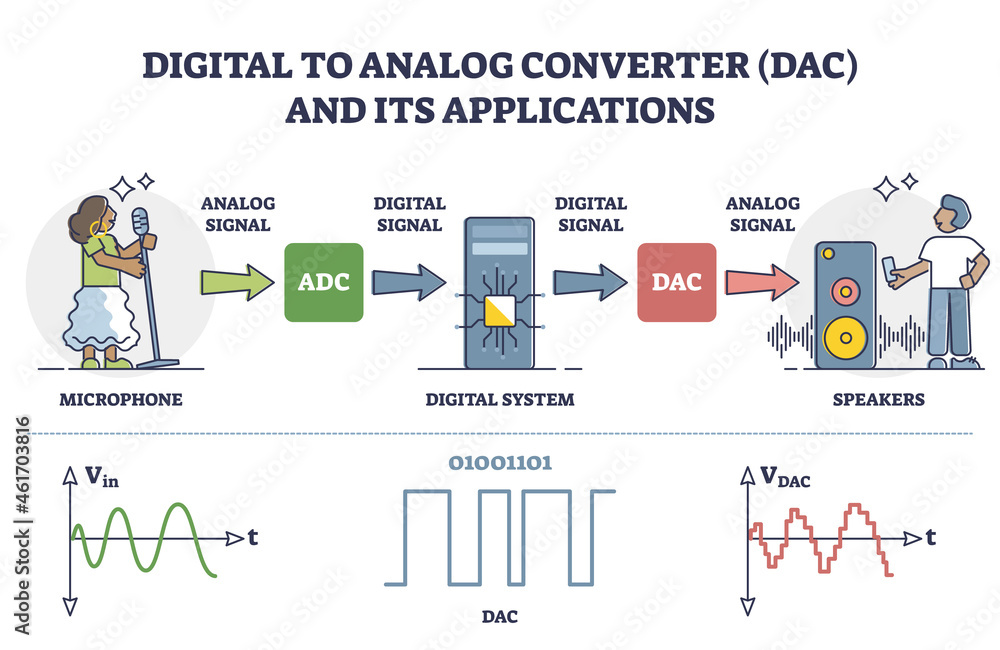
Analog to digital conversion is the process of taking a continuous physical signal—like voltage from a microphone, temperature from a sensor, or light from an image sensor—and representing it as discrete binary numbers. The entire digital audio, video, and instrumentation industry runs on this single operation. If you are working with any hardware that interfaces with a microcontroller, FPGA, or computer, you will eventually need to understand how this conversion actually works and where it breaks down. At its core, the process has two stages: sampling and quantization. Sampling determines how frequently you measure the analog signal, measured in samples per second (Hz). Quantization determines how many discrete amplitude levels your measurement can take, expressed as bit depth. An 8-bit system gives you 256 levels. A 16-bit system gives you 65,536. A 24-bit system gives you roughly 16.7 million levels. That number matters more than people realize when you are working with weak sensor signals. The Nyquist-Shannon sampling theorem states that your sample rate must be at least twice the highest frequency component you want to capture. In practice, you usually want 2.5 to 3 times that to give yourself headroom. A common mistake people make is sampling at exactly 2x the signal frequency and then wondering why their reconstruction looks terrible. It looks terrible because real-world anti-aliasing filters are not perfect brick walls. They roll off gradually, and without sufficient oversampling, high-frequency noise folds back into your bandwidth and corrupts the signal.
I spent three weeks debugging a bad reading on a custom thermocouple amplifier board before realizing the issue was not in the code or the op-amp design. The 12-bit ADC on my STM32 was sampling at 10 kHz, and there was switch-mode power supply noise at 50 kHz riding on the same rail. Because 50 kHz is five times the sampling rate, it was aliasing directly down into the 0 to 5 kHz range I cared about. The fix was straightforward once I identified it: I added a simple RC low-pass filter at 8 kHz before the ADC input and dropped the sample rate to 20 kHz. The readings stabilized immediately. The thermal noise floor of the thermocouple itself was well below what the ADC could resolve, so the filter removed everything that mattered without affecting the actual signal.
How to Set Up an Analog to Digital Conversion Pipeline
Whether you are working with a dedicated ADC chip, a microcontroller built-in ADC, or a USB data acquisition device, the pipeline follows the same logical structure. Here is how to approach it practically. Step one: characterize your analog source. Before you touch anything digital, you need to know the voltage range, output impedance, and bandwidth of your signal. A piezo contact mic might output signals in the hundreds of millivolts with a source impedance over 10 k. A load cell bridge might output microvolts per volt of excitation. A potentiometer wiper sits right in the middle. You cannot choose the right ADC or amplification stage without knowing these parameters first. Most beginner projects skip this step and end up with either a clipped signal or one that uses only 5 percent of the ADC's available range because the signal was too small and never amplified properly. Step two: condition the signal. This means scaling the voltage to match your ADC's input range and filtering out frequencies you do not want. If your ADC accepts 0 to 3.3 volts and your sensor outputs negative voltages, you need a level-shifting circuit. If your sensor is noisy, you need an anti-aliasing filter. A first-order RC filter is often enough for basic work. A fifth-order Chebyshev or Butterworth active filter is what you use when you need clean rejection. I tend to reach for a Sallen-Key second-order Butterworth stage as a default because it is stable, easy to calculate, and provides 40 dB per decade of roll-off, which handles most non-critical applications.
Get the Full Details
Step three: select your sampling rate and resolution. Higher sample rates capture more temporal detail but generate more data and can introduce clock jitter issues. Higher resolution captures smaller amplitude differences but is typically slower and more sensitive to noise. There is a trade-off. A 24-bit audio ADC will not run at the same speed as a 12-bit industrial ADC. If you need both, you buy two different chips or accept that your system will have different modes for different use cases. I once designed a system that needed both high-speed vibration sensing and high-resolution DC temperature monitoring. The solution was splitting the analog front end: one path went through a fast 16-bit ADC for vibration, another through a slower 24-bit delta-sigma ADC for temperature, and the MCU handled both via separate SPI buses. Step four: implement proper grounding and reference design. This is where most hobbyist projects fail and why commercial products cost more than you expect. The ADC reference voltage determines your absolute accuracy. If your reference is noisy, your conversion is noisy regardless of how good the ADC is. Using the same power rail for both the ADC reference and the system logic is a recipe for corruption because digital switching noise will modulate your reference. A low-dropout regulator with a bypass capacitor network dedicated to the analog supply and reference pin is the minimum. For anything precision, a separate voltage reference IC like an ADR445 or LM4040 is worth the ten dollars. Step five: calibrate after assembly. Every ADC has offset error and gain error. Datasheets specify these, but the values you get on your actual board will differ due to PCB trace resistance, component tolerance, and thermal effects. A two-point calibration using a known reference voltage and a known zero or near-zero input will correct most of this. Record the calibration coefficients in non-volatile memory and apply them in software. This is what separates a lab-grade measurement system from something that works on a bench but drifts when it gets warm.
Where Analog to Digital Conversion Fails and What to Do Instead
The biggest limitation of direct ADC conversion is dynamic range. A 16-bit ADC gives you theoretically 96 dB of dynamic range. Real-world performance is usually 10 to 20 dB less due to noise, distortion, and reference imperfections. If your signal varies by a factor of a thousand in amplitude—like capturing both a whisper and a shout with the same microphone—you will either clip the loud parts or bury the quiet parts in quantization noise. The workaround is either dual-gain staging, where you amplify weak signals more and reduce gain for strong ones, or using an ADC with automatic gain control built in, which is common in communication receiver front ends. Another failure mode is sampling aperture uncertainty, also called aperture jitter. When your ADC samples, it needs a finite amount of time to take each measurement. If your input signal is changing rapidly during that window, the sample is ambiguous. This becomes a serious problem at high frequencies with high-resolution ADCs. A 16-bit ADC sampling a 100 kHz sine wave needs extremely stable timing. The same ADC sampling a 1 MHz sine wave will have jitter-induced errors that exceed one LSB even with a good clock. The solution is either lowering the input frequency, accepting lower effective resolution at higher frequencies, or using a tracking ADC architecture for the highest speed applications. Delta-sigma ADCs solve some of these problems by oversampling massively and using digital filtering to achieve high resolution at lower speeds. They are excellent for temperature, pressure, and audio applications where speed is not critical. But they are terrible for wideband RF sampling or fast control loops. Successive approximation register ADCs, on the other hand, are fast and efficient but struggle with resolution above 16 bits without additional techniques like pipelining. Understanding which architecture fits your application saves more development time than any amount of code optimization.
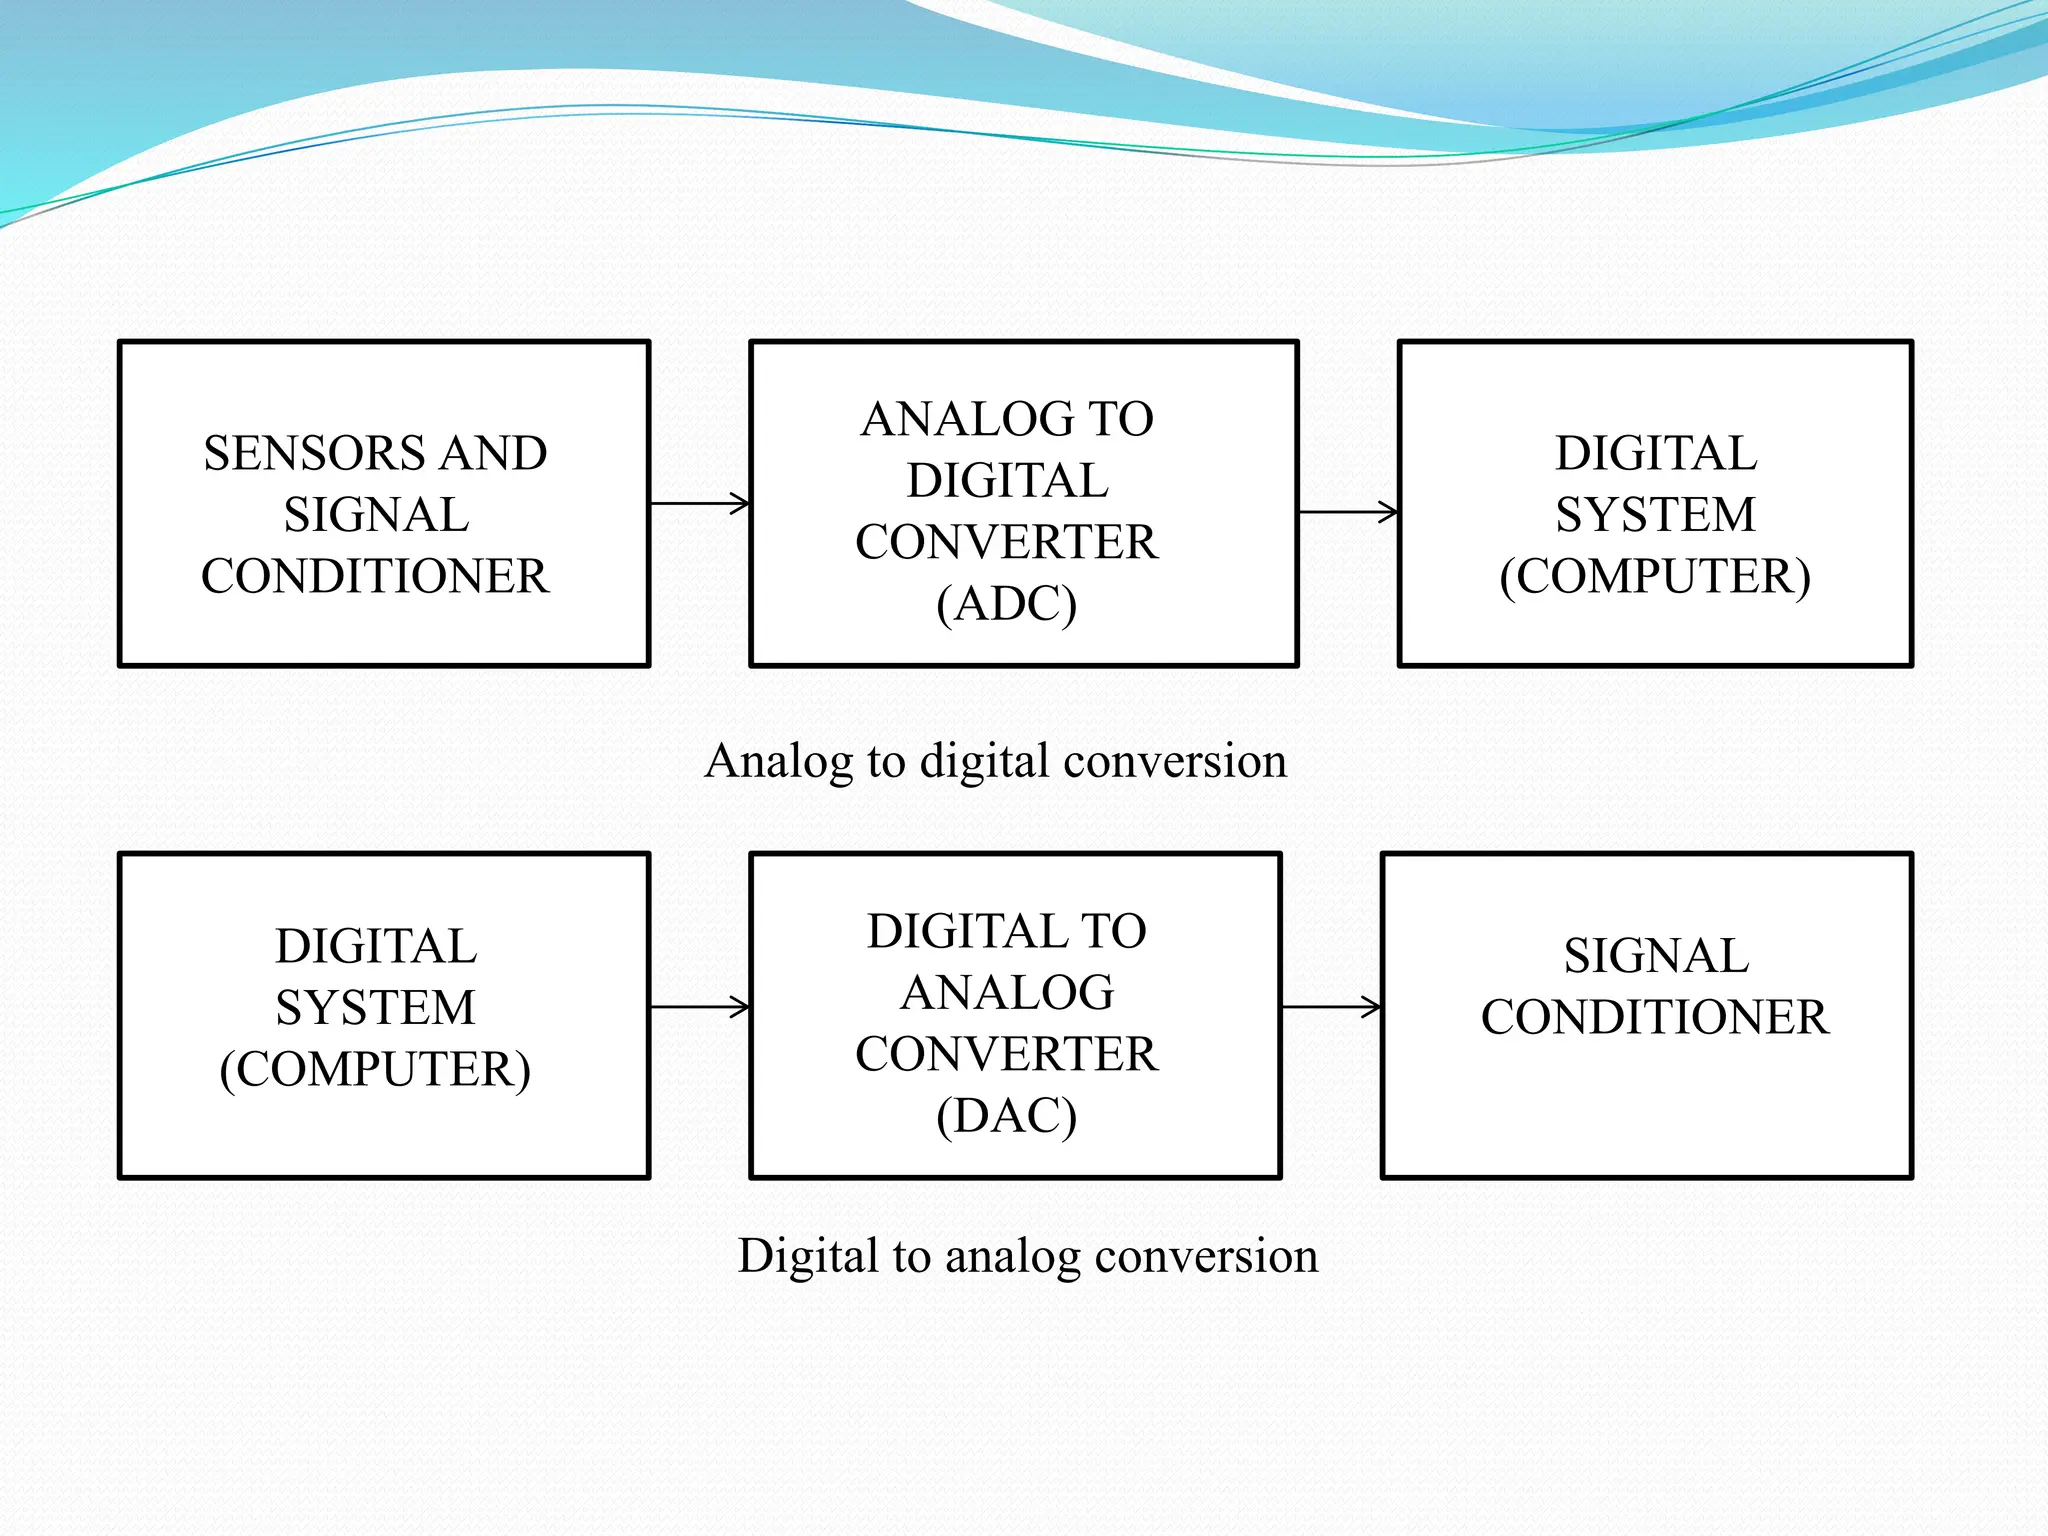
Software reconstruction is also a consideration. Simply reading raw ADC values and sending them to a PC will give you data, but it will not always give you useful data. Aliasing, quantization noise, and timing jitter do not disappear because you have a good CPU. Proper signal reconstruction requires understanding what your sampling system actually captured versus what the original signal contained. In my experience, spending time on the analog front end and clock distribution yields ten times the improvement that any post-processing algorithm can provide. Post-processing can clean up what the ADC actually measured. It cannot recover information that was never captured in the first place.