Converting Between Coordinate Systems Is Something You Do Once Per Project
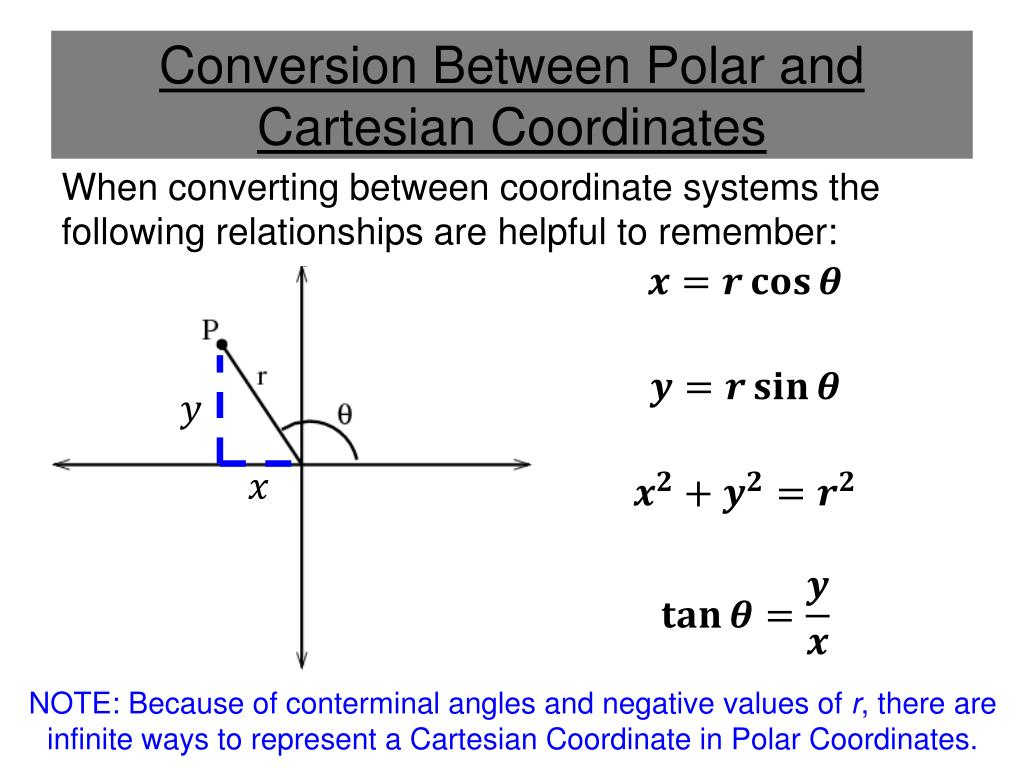
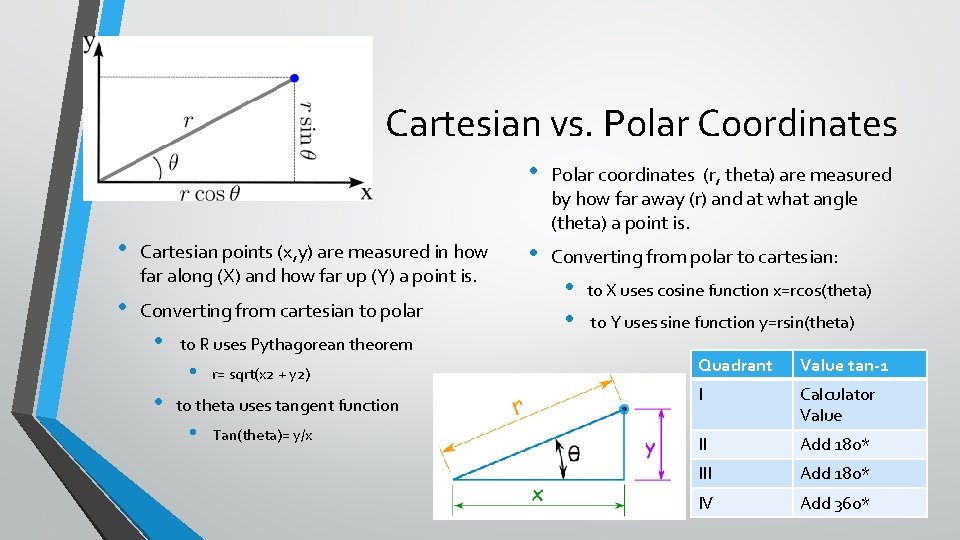
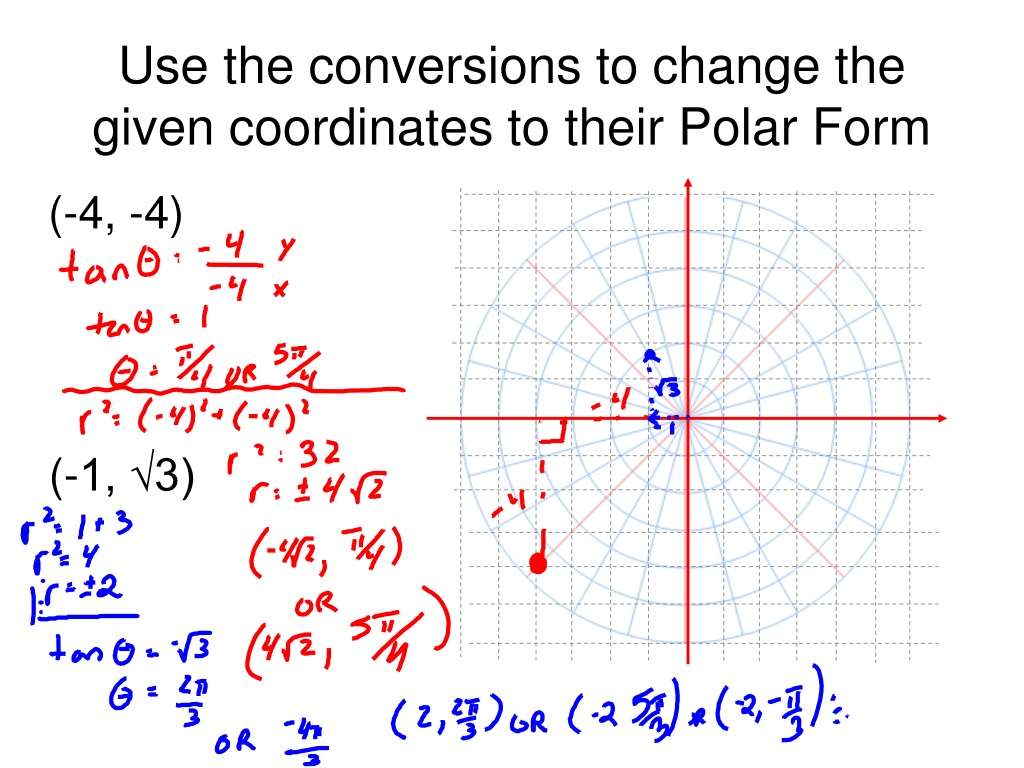
The formula set is straightforward enough that anyone can copy it from a textbook. r equals square root of x squared plus y squared. Theta equals arctangent of y over x. That's it on paper. In practice, people hit the quadrant issue immediately and waste an afternoon chasing phantom rotation angles before realizing the standard arctangent function collapses everything into a negative ninety to positive ninety degree range. I ran into this properly on a PCB routing project where I needed to convert component placement coordinates from a manufacturer's spreadsheet into polar form for a CNC machining script. The spreadsheet had negative values scattered everywhere and my initial conversion routine spit out bearings that were wildly off in the second and third quadrants. The fix was swapping to the atan2 function instead of plain arctangent. Most programming languages implement atan2(y, x) with the correct two-argument logic built in, so you stop guessing which quadrant a point lives in and just feed it both coordinates directly. That cut my debugging time from roughly six hours down to maybe forty minutes.
When to Actually Use Cartesian To Polar Coordinates
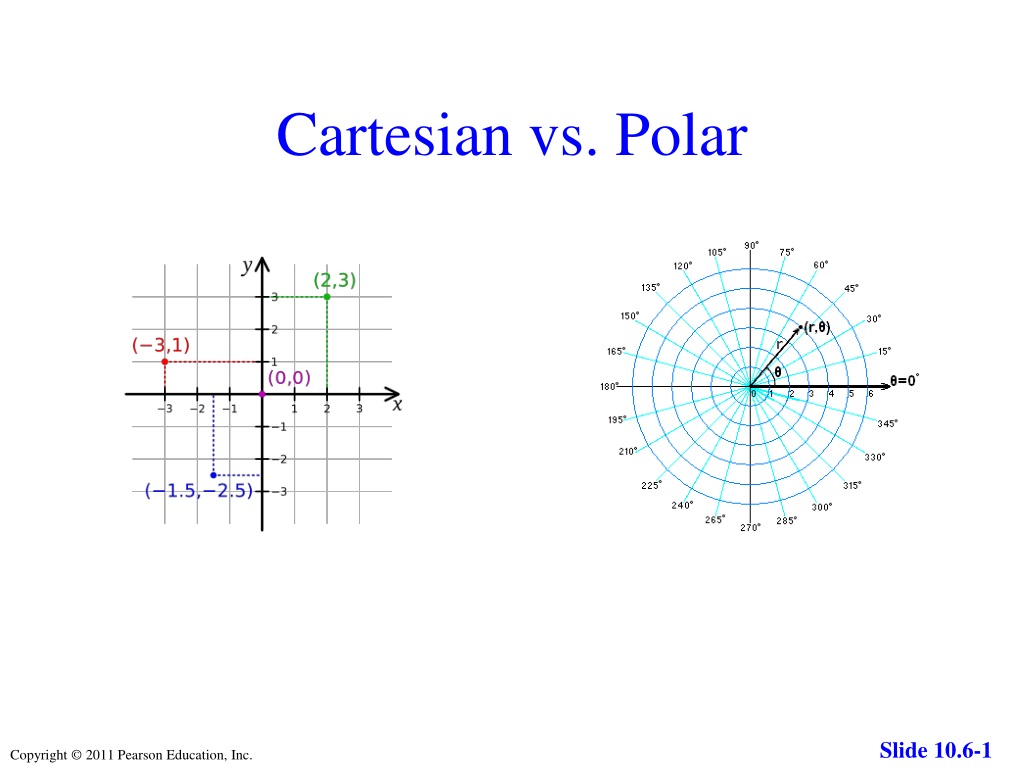
Cartesian coordinates work fine for most grid-based operations. They're what your database stores, what your spreadsheet displays, and what your CAD software outputs by default. But they break down when you're working with anything that has inherent radial symmetry or angular dependency. Rotating a vector around an origin is trivial in polar form and painful in Cartesian. Doing a radial scan pattern for radar simulation would require nested loops in Cartesian but becomes a single sweep across theta and r in polar. Circuit board toolpaths, antenna array design, sonar beam patterns, orbital mechanics calculations, even some game dev pathfinding scenarios where movement is angle-based rather than grid-based — these are the places where switching representations actually saves work instead of creating it. The reverse conversion, polar back to Cartesian, is equally simple. X equals r times cosine of theta. Y equals r times sine of theta. You'll do both directions in the same project about half the time. Knowing which direction you're going before you start writing the conversion code prevents a class of bugs where angles get interpreted as radians when the trig function expects degrees, or vice versa. This is genuinely the most common source of errors I see. Factorials are not involved here, but precision loss from mixed units absolutely is.
Precision And Edge Cases That Won't Appear In Tutorials
There are three scenarios where standard conversion routines fail silently. The first is the origin point itself. When x equals zero and y equals zero, theta is undefined because there is no meaningful angle at a singularity. Some libraries return zero. Some return null. If your application requires a valid angle at the origin for downstream processing, you need to handle that case explicitly rather than trusting the library to make a reasonable choice. The second edge case involves integer overflow when computing r squared. If your input coordinates are large integers and you're working in a language without arbitrary precision arithmetic, x squared plus y squared can exceed the maximum representable value before the square root operation even runs. Scaling the inputs down by a constant factor before squaring, then scaling the final radius back up, prevents this without changing the mathematical result. This is a real concern in embedded systems and game engines where coordinates can reach into the tens of thousands. The third issue is angle wrapping. Once theta exceeds two pi or drops below negative two pi, you typically need to normalize it back into a standard range depending on what the downstream function expects. Some systems want negative one pi to positive pi. Others want zero to two pi. A simple modulo operation handles this but the result depends on how your language's modulo operator treats negative numbers. Python and JavaScript disagree on this. C and C++ leave it implementation-defined. Write a normalization helper function once and reuse it everywhere instead of patching it inline across multiple files.
Get the Full Details

If you need something ready to run, most modern environments have this built in. Python's cmath.polar and polar functions handle the conversion with proper quadrant logic. JavaScript's Math.atan2 covers the angle part while you compute the radius manually. MATLAB has cart2pol and pol2cart as part of its standard library. For anything running on bare metal or in a constraint-heavy environment, a thirty-line implementation using atan2 with explicit quadrant handling and angle normalization is about all you need.
Why Your Results Might Look Wrong Before You Realize What Happened
Trig functions expect radians in virtually every programming language except BASIC variants and some older calculator libraries. If you feed degrees directly into Math.sin or Math.cos, your converted coordinates will appear geometrically valid but completely misaligned. Converting theta to radians before any trig operation, or converting the output back to degrees for display, adds one line and prevents a category of errors that looks like a bug in the math itself when it's actually just a unit mismatch. A lot of people spend hours checking their formulas when the real problem is that they passed degrees into a radians-only function and got radians back without noticing. There's also the floating point artifact problem. You will occasionally see r values like 5.000000000000001 or -0.0000000000000000001 when the mathematically exact answer should be a clean integer. This is normal IEEE 754 behavior and rounding to the expected precision level fixes it. Don't treat every small deviation as a bug in your conversion routine. Check whether the deviation is within machine epsilon for your data type before opening a can of worms looking for an error that doesn't exist. The main limitation of polar conversion is that it introduces a non-linear coordinate system into what might have been a linear pipeline. Filtering operations, interpolation, and linear algebra routines are all designed for Cartesian space. Converting a dataset to polar, doing your operation, and converting back can introduce artifacts that didn't exist in the original representation. If you're doing signal processing or image filtering, staying in Cartesian is usually the right call unless the operation you're performing is fundamentally angular. There's no universal advantage to polar coordinates just because the formula is short. Use the representation that matches the geometry of your problem, not the one that looks cleaner on a whiteboard.