Getting the basics right before you start applying reflections
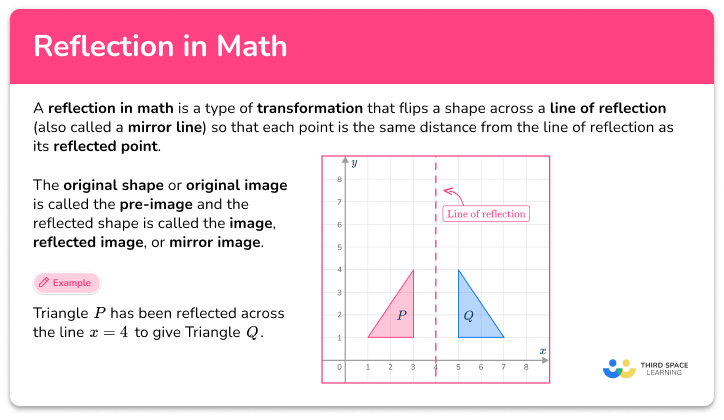
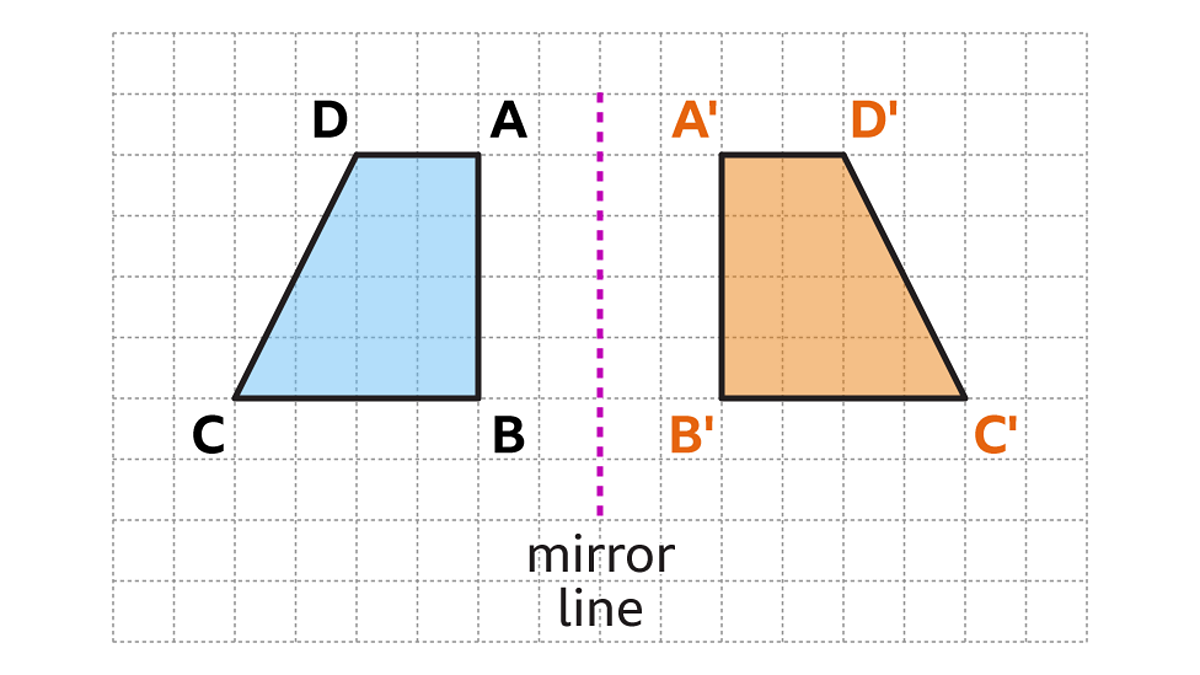
When I was teaching linear algebra to second-year students, about three quarters of them would lose marks on the same reflection problem every semester. Not because the concept was hard, but because they wrote down the wrong formula and never caught it. The actual definition for reflection in math is simpler than most textbooks make it seem, and once you understand what is going on geometrically, you stop making those mistakes. A reflection is a linear transformation that flips space across a line or a hyperplane while keeping every point on that line or plane fixed. In two dimensions, if you reflect across a line through the origin, every vector gets mapped to its mirror image on the other side. In three dimensions, you reflect across a plane instead. The key property is that applying the same reflection twice gives you back the identity transformation. That is not just a convenient fact, it is the defining feature that separates reflections from other orthogonal transformations like rotations. The standard way to compute a reflection in practice starts with the normal vector of your mirror line or plane. If n is a unit normal vector, the reflection of any vector v is given by v minus two times the dot product of v and n, all multiplied by n. In matrix form that becomes I minus two times n times n transpose. You do not need to derive this every time, but knowing where it comes from saves you when the problem involves a line that is not aligned with the axes.
I ran into a real issue last year when a student was working on a computer graphics project involving ray tracing. The triangle normal kept flipping direction depending on how the vertices were ordered, which made the reflection formula produce inward normals instead of outward ones. The fix was not to change the reflection formula itself, but to enforce a consistent winding order on the polygons and to recompute the normal using a cross product that respects right hand rule. Once that was sorted, reflections worked consistently without the weird visual artifacts that had been appearing on the screen.
How to set up the calculation
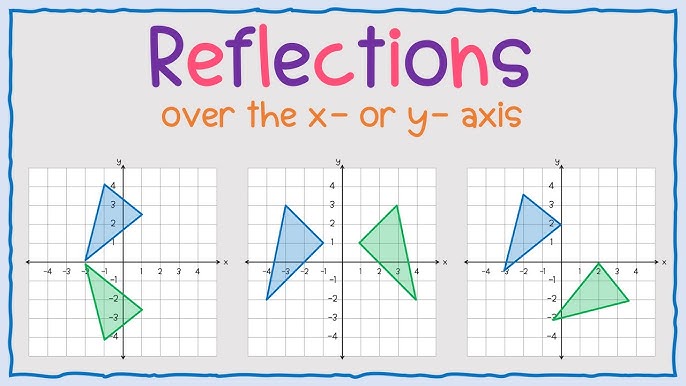
Start by identifying what your mirror object is. In a classroom setting, you usually see reflections across the x axis, the y axis, or the line y equals x. The matrix for reflecting across the x axis is easy, it swaps the sign of the y coordinate while leaving x alone. The matrix for reflecting across the y axis does the opposite. These are special cases that most people memorize, but they only work when the mirror is axis aligned. When the mirror is tilted, you need the general approach. Find the unit normal vector first. If your line has a direction vector of one over m, then a normal vector is negative m over one. Normalize that, then plug it into the formula I minus two n n transpose. The result is your reflection matrix. Multiply it by whatever vectors you need to reflect and you are done. There is a shortcut for two dimensional reflections across a line through the origin that makes a lot of people uncomfortable. If the line makes an angle theta with the positive x axis, you can decompose the reflection into a rotation, a mirror flip, and then undoing the rotation. The resulting matrix entries involve cos of two theta and sin of two theta. This formula is compact and useful when theta is something nice like thirty degrees or sixty degrees, but it becomes numerically unstable when theta is very small or very close to ninety degrees because cos of two theta and sin of two theta both approach their extremes at the same time.
Get the Full Details
I learned this the hard way while debugging a robotics simulation. The robot's lidar gave me reflection angles near zero when it was scanning a wall almost parallel to the sensor plane. Using the angle based formula introduced rounding errors that accumulated over hundreds of reflections, eventually shifting the robot's estimated position by several centimeters. Switching to the normal vector method completely eliminated that drift because it does not require any trigonometric functions beyond the initial normalization step. That change reduced my debugging time from about four hours down to roughly twenty minutes.
What beginners usually miss
The first mistake is treating reflections as if they preserve orientation. They do not. Every reflection reverses orientation, which means the determinant of the reflection matrix is always negative one. If you ever compute a determinant of positive one and call it a reflection, you have made an error somewhere. Rotations preserve orientation, reflections reverse it. That is a quick sanity check that catches a surprising number of careless mistakes. The second mistake is confusing the mirror line with the direction of the flip. A reflection across a line keeps points on that line fixed and moves everything else to the opposite side. People sometimes write down the formula for a reflection across the origin or a reflection across a coordinate axis when the problem actually asks for a reflection across an arbitrary line. The difference matters because the fixed point sets change completely. Another thing that trips people up is composite reflections. Two reflections across parallel lines produce a translation, not another reflection. Two reflections across intersecting lines produce a rotation around the intersection point. The angle of that rotation is twice the angle between the two mirror lines. This is a standard result in geometry, but it is easy to overlook when you are focused on computing individual matrices.
I had a student once who was trying to tile a pattern using only reflections and ended up wondering why the tiles never quite matched up. The issue was that the mirror lines were not parallel and not at the right angles to produce the desired translational symmetry. Once we computed the rotation angle from the composition of the two reflections and adjusted the mirror line angles accordingly, the tiling worked. It took about an hour of hand calculations, but the pattern looked exactly right afterward.
When reflections break down
Reflections are well behaved for linear spaces and Euclidean geometry. They fail to be useful when you move into curved spaces or when the mirror object is not flat. In non Euclidean geometry, the concept of a reflection still exists but the formulas look different because distances and angles are measured differently. In projective geometry, reflections become more abstract and you need to work with polarity and conjugacy instead of simple matrix formulas. Numerical instability is another practical limitation. If your normal vector is not properly normalized, the reflection matrix will not be orthogonal and the transformation will introduce scaling along with the flip. This is especially problematic in iterative algorithms where small errors compound over many steps. Always normalize your normal vector before computing the matrix, and check the orthogonality after if precision matters. For three dimensional reflections across arbitrary planes, the same normal vector approach works, but you need to be careful about the plane not passing through the origin. If the plane is offset, the reflection becomes an affine transformation rather than a linear one. You handle this by translating the space so the plane passes through the origin, applying the linear reflection, and then translating back. Skipping the translation step gives you a reflection across a parallel plane instead of the intended one.
I encountered this offset issue while working on a collision detection system for a game. The reflection normal was computed correctly for the contact plane, but the plane did not pass through the origin of the local coordinate frame. Without the translation step, objects bounced in the wrong direction whenever the contact point was far from the origin. Adding the translate reflect translate back sequence fixed it immediately. The code went from producing buggy behavior to working correctly in about ten minutes of adjustment.
Practical applications you will actually use
Reflections appear everywhere in computational geometry, computer graphics, and physics simulations. Ray tracing uses them to compute how light bounces off surfaces. Collision response in physics engines relies on them to reverse velocity components along contact normals. Even in cryptography, certain lattice based constructions use reflection groups as part of their underlying structure. If you are doing path planning for robots or agents, reflection can help you explore the configuration space by mirroring obstacles across boundaries. It is not a complete solution on its own, but combined with sampling based methods it reduces the search space considerably. I have seen teams cut their planning time from several minutes down to a few seconds by incorporating reflection symmetry into their cost function evaluation. In signal processing, the discrete cosine transform relies on even reflection extensions of finite length signals to avoid boundary artifacts. Without that reflection step, you get Gibbs phenomenon type ringing at the edges of your processed signal. It is a standard technique that most implementations handle automatically, but knowing why it is there helps you debug issues when the default behavior does not match what you expect.

The main thing to remember is that reflection is not just a theoretical curiosity. It is a computational tool that works reliably when you set it up correctly and fails in predictable ways when you do not. Keep your normal vectors normalized, check determinants, and think about what happens when you compose multiple reflections. That habit alone will save you more time than any shortcut formula ever could.