What These Notes Actually Look Like
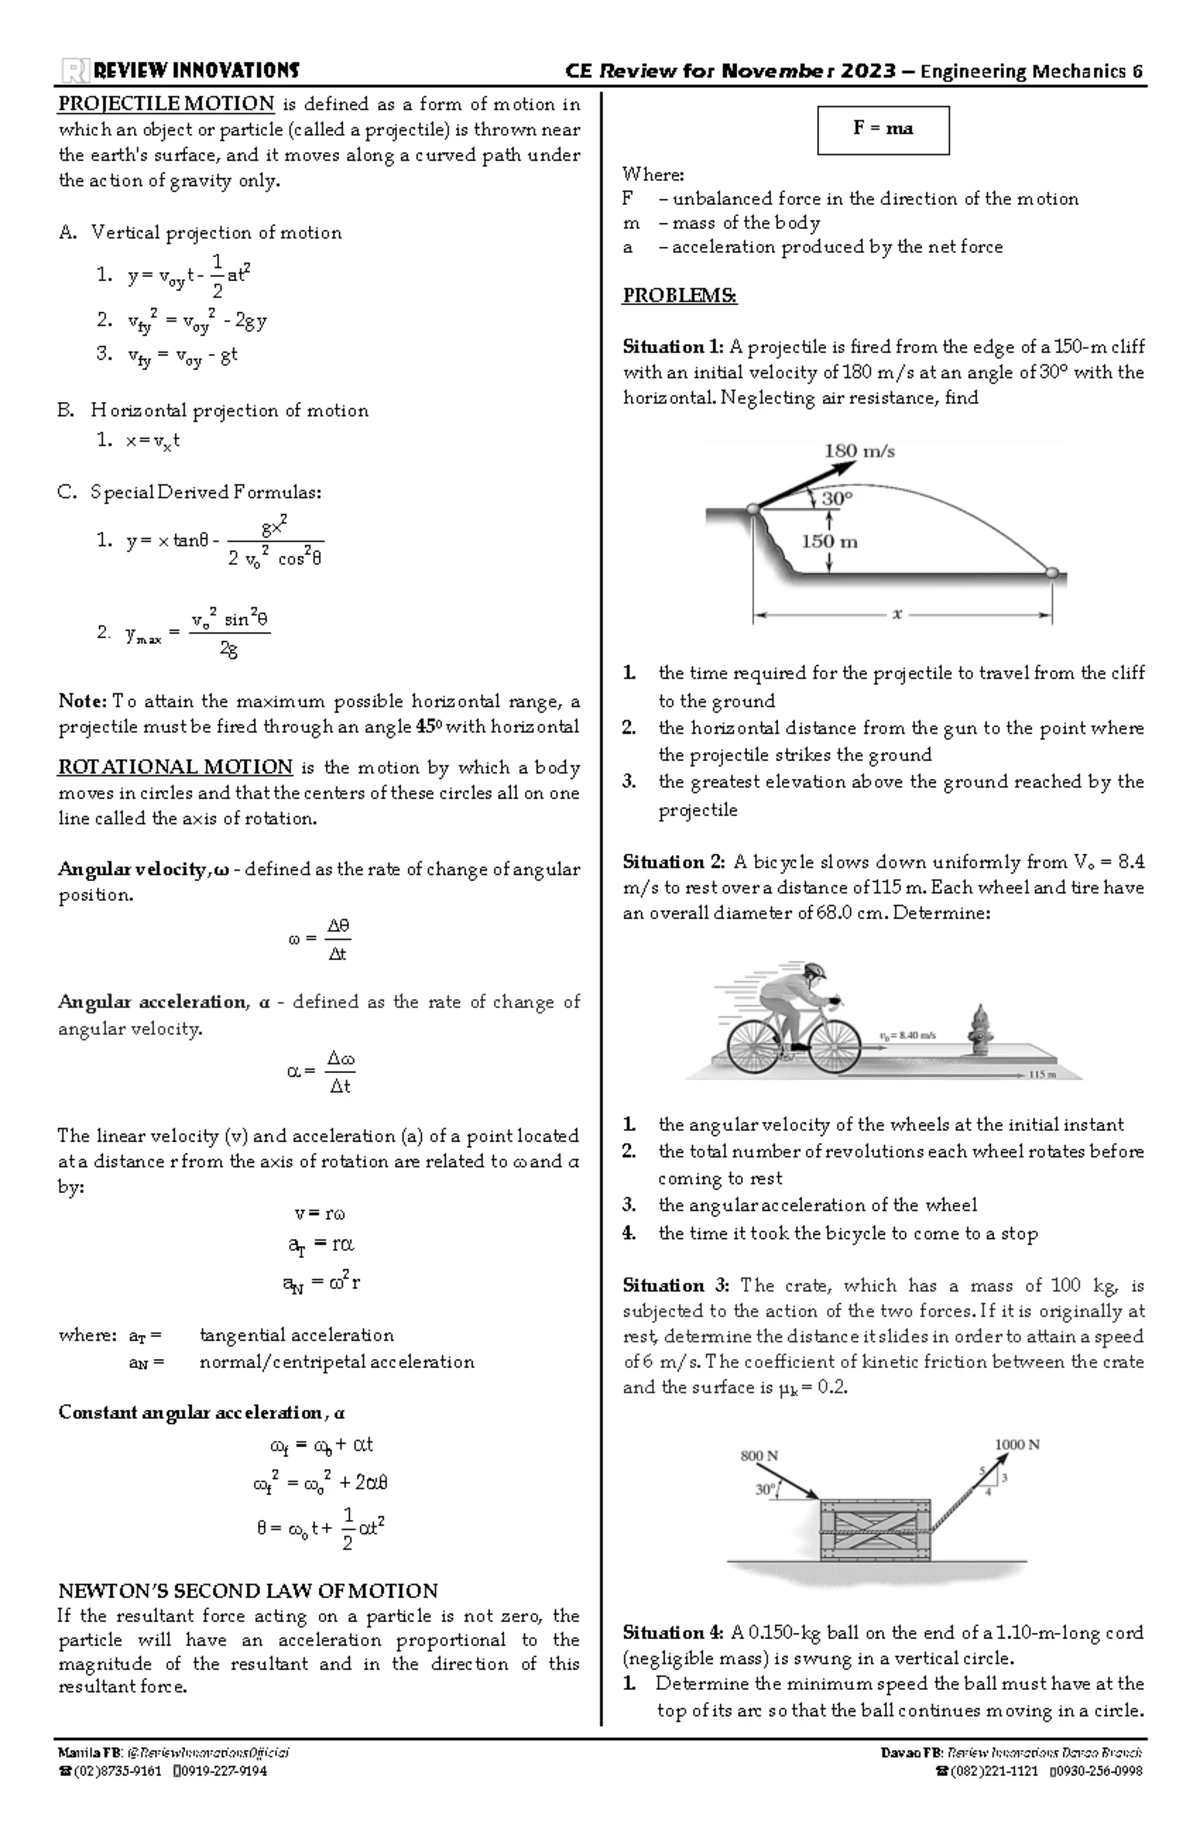
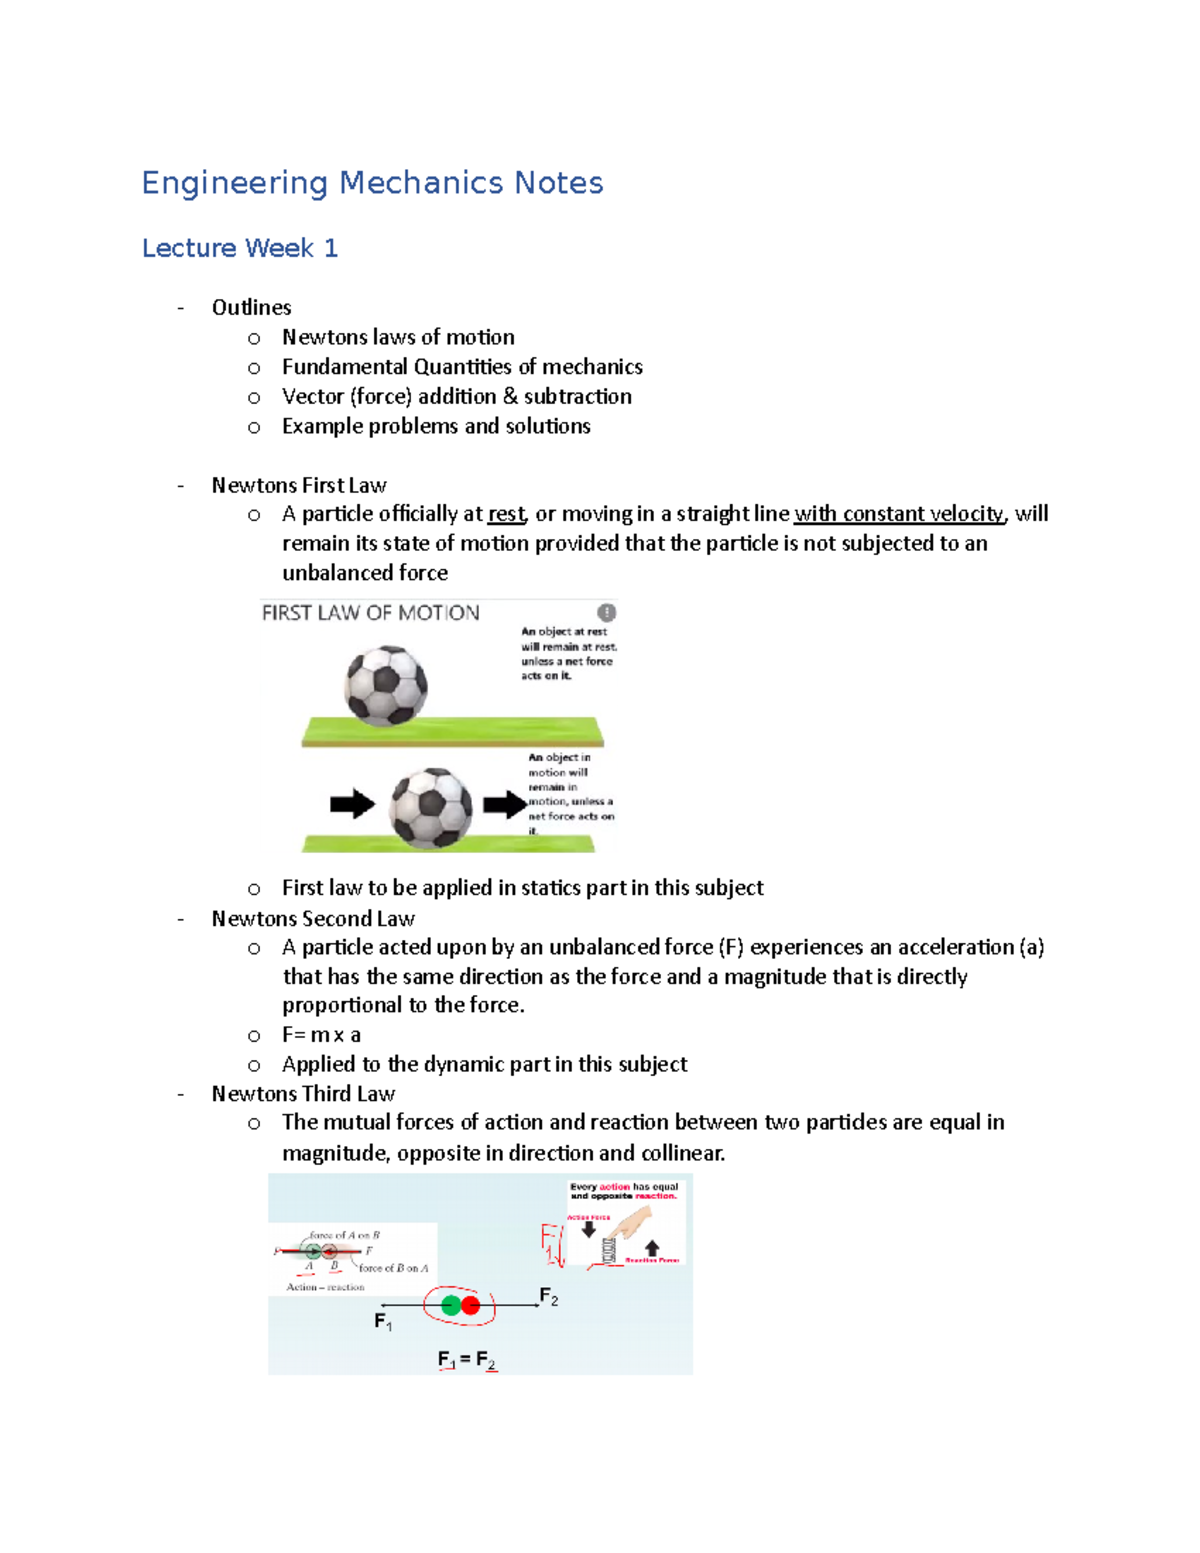
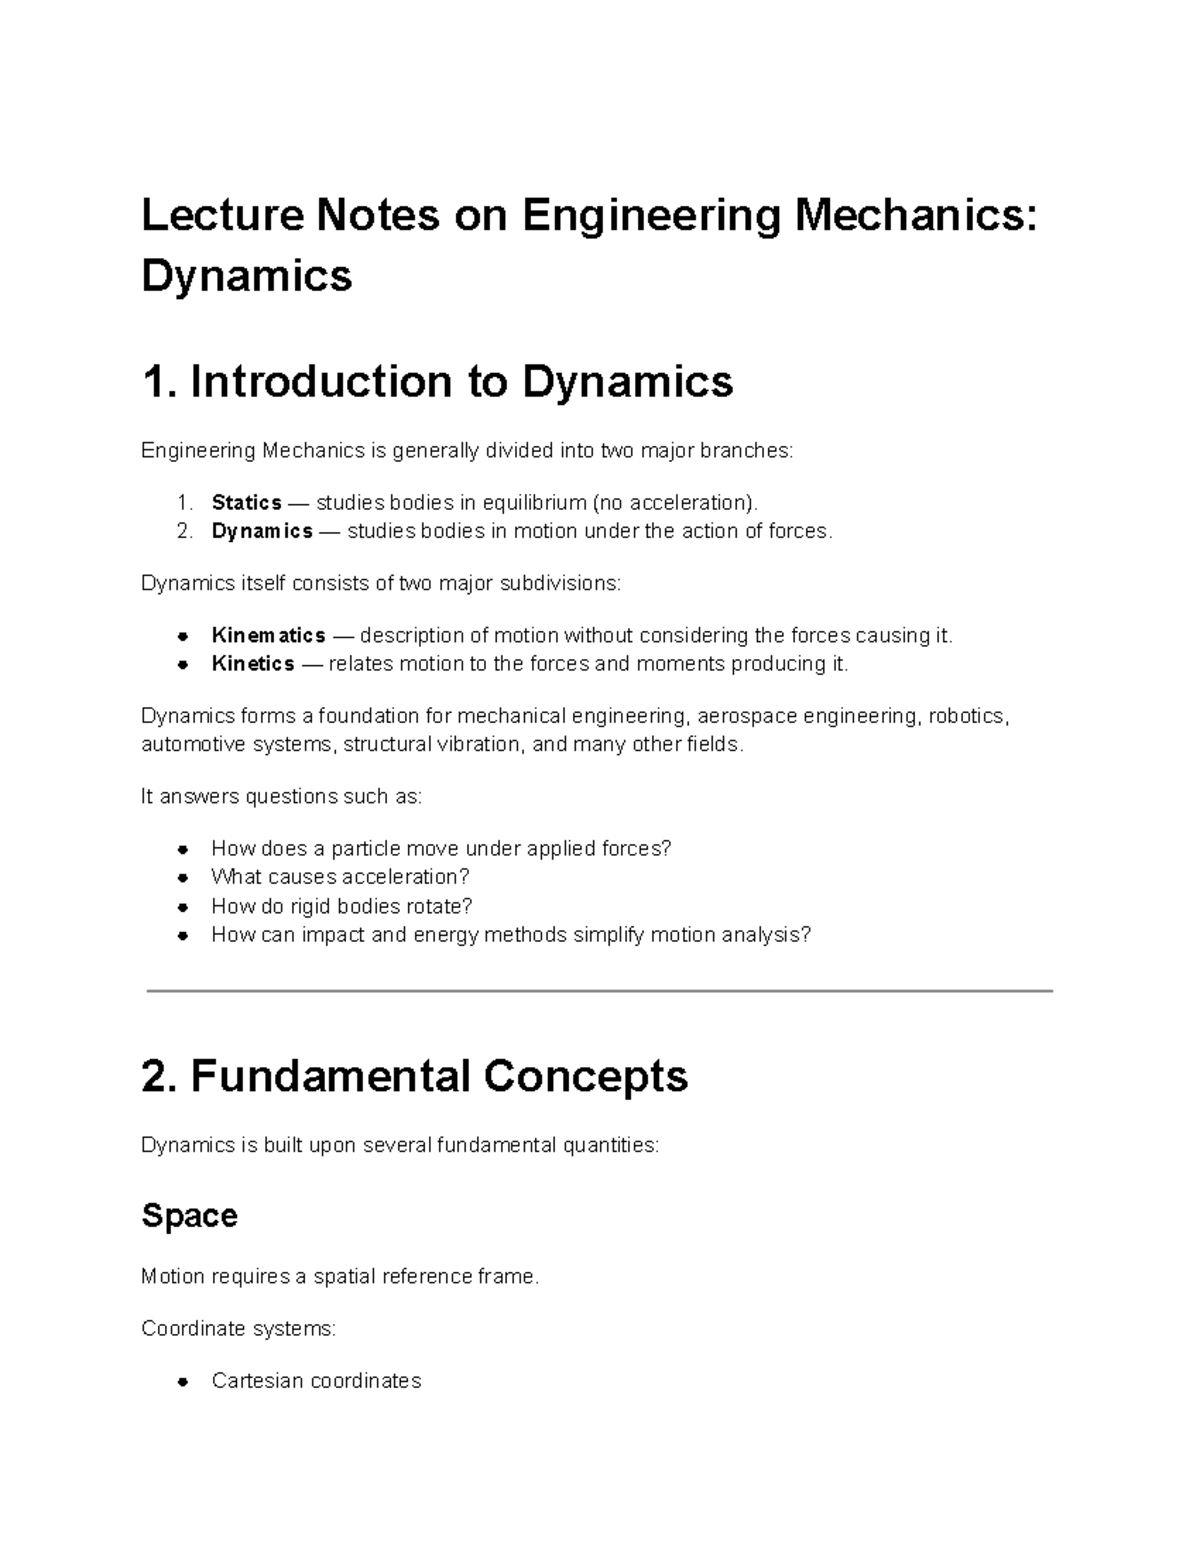
You'll find Engineering Mechanics Dynamics Lecture Notes scattered across university servers, course websites, and random PDF repositories. Most of them are from MIT, Caltech, Stanford, or similar programs that publish their course materials openly. They range from a few dozen pages to over two hundred, and the quality gap between them is enormous. Some are clean typed notes from a professor who actually cares about pedagogy. Others are scribbled blackboard photos converted to PDF with zero formatting, missing half the derivations. I spent about three semesters working through dynamics material at the graduate level and ended up compiling my own version. The standard notes you find online cover the basics—Newton's laws applied to particles, work-energy methods, impulse-momentum, rigid body kinetics, and usually a chapter on vibrations. What they often skip, or handle poorly, is the transition from particle dynamics to systems of particles and rigid bodies, which is where students actually hit a wall.
Engineering Mechanics Dynamics Lecture Notes
Here's how I approach using them. You grab notes from one or two sources, not more. Three sources tends to create confusion because different professors use different sign conventions and coordinate system choices. Pick one that uses a consistent approach and stick with it. Meriam and Kraige is the standard textbook most courses align with, but the notes themselves are what matter for your review process. The core topics you need to master are: Particle kinematics: position, velocity, acceleration in Cartesian, normal-tangential, and polar coordinates. You should be able to switch between coordinate systems without thinking about it. This comes up everywhere.
Particle kinetics: F = ma applications, work-energy theorem, impulse-momentum. The work-energy approach saves time on problems where forces vary with position. Impulse-momentum is essential for impact problems. Rigid body kinematics: relative velocity and acceleration analysis, instantaneous center of zero velocity, rotation about a fixed axis. The IC method cuts calculation time roughly in half compared to writing full vector equations for many planar problems. Rigid body kinetics: moment equations, kinetic diagrams, three equivalent methods of solution (force-acceleration, work-energy, impulse-momentum). Knowing all three matters because exam problems are often designed to reward the method that minimizes algebra.
Get the Full Details

Vibrations: free and forced vibration of single degree of freedom systems, damping ratios, resonance. This is usually the shortest chapter and the most formula-heavy. Memorization works here in a way it doesn't elsewhere. One thing nobody warns you about: the notation changes between sources. One set of notes might write the kinetic energy of a rotating body as (1/2)I_G * omega^2 plus (1/2)m*v_G^2, while another combines them differently or uses point O instead of the center of mass G. If you're cross-referencing multiple note sets, flag every notation difference immediately or you'll lose an hour debugging a sign error that was never an error at all. I ran into this exact problem during my second semester. I was solving a compound pendulum problem using notes from two different professors and got answers that differed by a factor of 2 in the period calculation. Spent forty-five minutes convinced I'd derived something wrong. Turned out one professor defined the moment of inertia about the pivot point and the other about the center of mass, and neither note set made that distinction explicit in the formula headers. Once I mapped both to the parallel axis theorem, the answers aligned perfectly. Now I annotate every formula sheet with the reference point before using it.
How to Actually Study From Them
Reading lecture notes passively doesn't work for dynamics. You have to work the problems. The notes give you maybe ten to fifteen example problems per topic. That's not enough. You need to do at least double that on your own, mixing in textbook problems from Hibbeler or Meriam. The most efficient study sequence I found is this: read the notes chapter, do the worked examples covering them yourself without looking at the solution first, then tackle the end-of-chapter problems in the textbook. Focus on problems that involve multiple concepts. A block sliding down an incline that's itself on a cart is a classic synthesis problem that tests whether you actually understand the frame of reference choices. Common mistakes I see constantly:
- Drawing free body diagrams without isolating the body first. Skip this step and you'll miss constraint forces or include external forces that don't belong.
- Using work-energy for impact problems. Work-energy doesn't account for energy dissipation during collisions. Use impulse-momentum for impacts.
- Forgetting that angular acceleration and angular velocity are vectors. Direction matters, especially in 3D rigid body problems.
- Mixing up linear and angular quantities. v = r*omega only applies to the tangential component. Radial acceleration is v^2/r or r*omega^2. Both terms show up in the same problem.
There's also a practical issue with the notes themselves. Many are scanned from paper and the handwriting in the derivations is illegible. I've encountered entire pages where the intermediate steps of a Lagrangian derivation were written so compactly that you can see the start and end of each equation but not what happened between them. In those cases, you need the textbook for the full derivation. The notes are outlines, not complete proofs. Another limitation: most publicly available notes skip non-conservative systems with friction handling. They'll show you a clean block on a smooth surface problem and move on. Real exam questions include kinetic friction on inclined planes with variable normal force, which changes the friction force along the path. The work integral becomes piecewise. I recommend finding a separate problem set on this specifically, or working it through from first principles yourself. For download sources, start with MIT OpenCourseWare, then check the engineering departments of any major research university. The notes from courses like 2.003 (Dynamics and Control I) at MIT are particularly thorough. Some professors maintain personal sites with updated notes that include recent exam problems. Those are gold because they show exactly what the professor considers important.
The whole process of going through a solid set of dynamics notes, working every problem, and understanding the underlying mechanics rather than just plugging into formulas takes roughly sixty to eighty hours for a full semester's content. If you're cramming, you can cover it in twenty-five to thirty hours but you'll retain less and make more sign errors under time pressure. There's no shortcut around doing the problems yourself.