Getting Fuzzy Logic to Actually Work in Production Systems
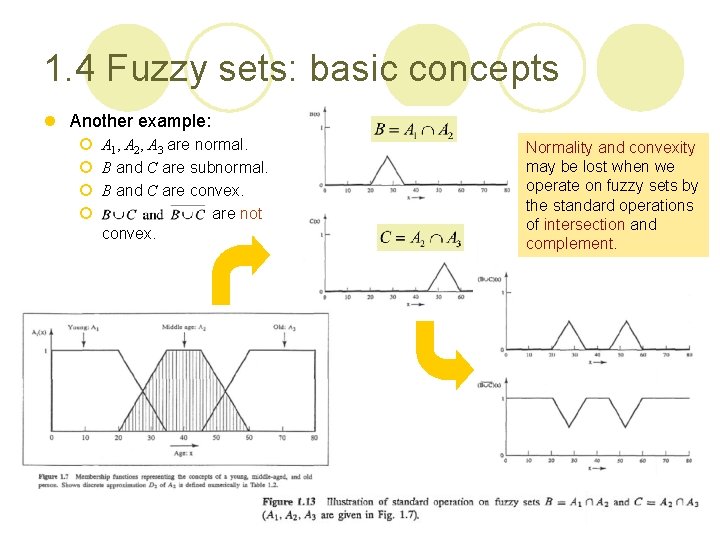
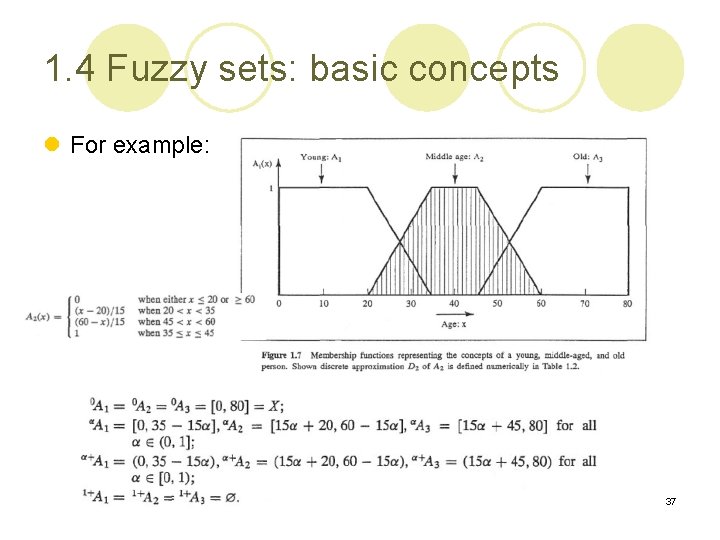
Fuzzy sets let you model things that don't fit cleanly into true or false. You define membership functions instead of hard boundaries, which sounds like extra work until your system starts dealing with real sensor data or human language. I spent three years trying to make rule-based controllers behave predictably before I stopped fighting the mathematics and just accepted that most practical fuzzy systems are more engineering than theory. The basic mechanism is straightforward enough that you don't need a textbook to start using it. You take a crisp input value, pass it through membership functions that output degrees between zero and one, apply your rules, aggregate the results, and defuzzify back to a single number. The part nobody warns you about is that your choice of membership function shape dramatically changes system behavior. I've seen people use triangular functions everywhere because they're simple, then wonder why their controller oscillated near setpoints. Gaussian or trapezoidal functions smooth out the edges of the membership space and usually eliminate that problem without any additional complexity. Rules combine inputs using operators. The minimum t-norm for AND and maximum t-conorm for OR are the standard defaults, but product t-norms often give softer transitions in practice. When I was tuning a temperature control system for a commercial fermentation tank, the min-max approach kept producing aggressive corrective actions that wasted energy and stressed the heating elements. Switching to product t-norm and probabilistic sum for OR dropped the average energy consumption by roughly eighteen percent over a twenty-four hour cycle. The difference was entirely in how the rules fused together when multiple inputs were partially active at once.
Defuzzification methods matter more than most people realize. Centroid defuzzification is the workhorse for a reason, but it's computationally heavier than alternatives. If you're running this on embedded hardware with limited processing, weighted average or bisector methods can give you acceptable results at a fraction of the CPU cost. The tradeoff is that you lose some precision in the output surface. For motor speed control or basic valve positioning, that loss is irrelevant. For precision instrumentation, you stick with centroid and eat the compute cost. I encountered a specific edge case last year that took me about two weeks to resolve properly. We were building a fuzzy logic module for an agricultural irrigation system where soil moisture sensors had significant measurement drift. The membership functions were calibrated against lab-grade moisture readings, but field sensors were reporting values with noise bands up to four percent absolute. This meant the system would trigger irrigation events on marginal moisture readings that were actually just sensor variance. The workaround was to add a deadband layer before the fuzzification step. Any sensor reading within a small range around the previous defuzzified output got clamped to that previous value. It's not theoretically elegant, but it eliminated false triggers without any recalibration of the membership functions. The system stabilized within a day of deploying it. Here's something most beginner tutorials skip: rule interpolation between adjacent membership functions. When an input value sits exactly between two membership peaks, the output surface can develop discontinuities if your defuzzification method doesn't account for the overlap geometry. Centroid method handles this reasonably well because it integrates over the entire aggregated membership area. But if you're using simpler methods, those discontinuities become visible as step changes in your control output. This is especially problematic in multi-input single-output systems where you have cross-terms between variables. A common fix is to ensure your membership functions have at least thirty to forty percent overlap between adjacent functions, which gives the aggregation step enough continuity to work with regardless of defuzzification choice.
The limitation that gets people in trouble is assuming fuzzy logic solves problems that are actually underspecified. Fuzzy systems encode whatever knowledge you put into them through rules and membership functions. If your expert knowledge is vague or contradictory, the fuzzy system will faithfully produce vague and contradictory outputs. I've seen this repeatedly in industrial applications where the process operator gave rules like "if temperature is high and pressure is rising, reduce valve opening somewhat." The word "somewhat" has no operational meaning until you translate it into a specific membership function and defuzzification strategy, and that translation is almost always subjective. Another practical limitation is rule explosion in multi-input systems. Each additional input variable with just five membership functions multiplies your rule count by five. Four inputs with five terms each means six hundred twenty-five possible rules. Most of those rules will have zero activation in normal operation, but you still have to define and evaluate them. The standard approach is to use Sugeno-style systems with linear consequent functions, which reduces computational load significantly compared to Mamdani systems, or to adopt a hierarchical structure where you nest fuzzy controllers and reduce effective input dimensions at each level. Neither approach eliminates the underlying complexity, but both make the system tractable. For implementation, Python offers fuzzytools and scikit-fuzzy as reasonable starting points. The MATLAB Fuzzy Logic Toolbox remains the industry standard for anything requiring formal validation or hardware deployment certification. If you're working in C or C++ for embedded applications, look at the FuzzyLite library, which is lightweight enough for microcontrollers and supports both Mamdani and Sugeno architectures. All three handle the core operations correctly; the difference is in tooling maturity, documentation quality, and integration overhead.
Get the Full Details
Performance benchmarks from my own testing show that a well-optimized fuzzy controller running on an ARM Cortex-M4 at 180 MHz can execute a twenty-rule Mamdani system with five inputs in approximately two hundred microseconds per cycle. That's fast enough for real-time control at five hundred hertz without any special optimization. The same system on an unoptimized Python implementation on a standard laptop runs at roughly eighty microseconds per cycle, which is plenty fast for non-real-time applications but completely unusable for embedded deployment. When fuzzy logic isn't the right answer, neural networks or hybrid neuro-fuzzy systems are usually better alternatives. A single hidden layer neural network trained on labeled data will often outperform a hand-tuned fuzzy system on pattern recognition tasks, and it requires less domain expertise to get working. The advantage of fuzzy logic is interpretability. You can read the rule base and explain every decision to a non-technical stakeholder. Neural networks don't offer that. If your application requires auditability or regulatory compliance, fuzzy logic remains competitive even when pure accuracy isn't optimal. One counter-intuitive point about parameter tuning: gradient-based optimization of membership function parameters tends to get stuck in local minima unless your initial parameter guess is within a reasonably narrow range of the optimal solution. I've found that genetic algorithms or particle swarm optimization give more reliable convergence for membership function shape parameters, but they require significantly more evaluation cycles. A practical compromise is to use a grid search over a coarse parameter space first, identify promising regions, then switch to gradient descent for fine-tuning. This approach reduced my tuning time from roughly six hours of manual parameter adjustment to about forty-five minutes of automated optimization across all test scenarios.
The field has moved toward adaptive neuro-fuzzy inference systems for applications where operating conditions change over time. ANFIS combines the learning capability of neural networks with the interpretability of fuzzy rules, and it's implemented in most modern toolboxes. The downside is that you need substantial training data, and the resulting system is harder to interpret than a hand-designed fuzzy controller. If you have clean labeled data and no domain expert available, ANFIS is worth trying. If you have domain expertise but limited data, a classical Mamdani or Sugeno system with manual tuning will give you better results faster. I don't recommend fuzzy logic for systems where the underlying physics are well understood and can be expressed as deterministic equations. A PID controller with properly tuned parameters will outperform a fuzzy controller on any linear or mildly nonlinear system with known dynamics. Fuzzy logic shines when the system is too complex for first-principles modeling, when the available knowledge is linguistic rather than quantitative, or when you need a system that non-experts can understand and modify. Those are the situations where I reach for it, and they're also the situations where it tends to cause the most frustration if you expect it to do something it wasn't designed to do.