What Vector Magnitude Actually Means
The magnitude of a vector is just its length. That's it. You're not measuring direction or angle, just how far it reaches from the origin point. In computer graphics this comes up constantly—collision detection, ray casting, normalization for lighting calculations, all of that requires knowing the length first. When I first worked with 3D vectors in a game engine, I confused the squared magnitude with the actual magnitude because I wanted to avoid the square root operation. This is actually a legitimate optimization in many cases—you can compare two squared magnitudes to see which is longer without ever computing a sqrt. But when you need the actual distance for a physics calculation, the unsquared value matters. I spent an afternoon debugging a collision system where objects were reacting at roughly double the expected distance because of this mix-up.
How To Find Magnitude Of A Vector
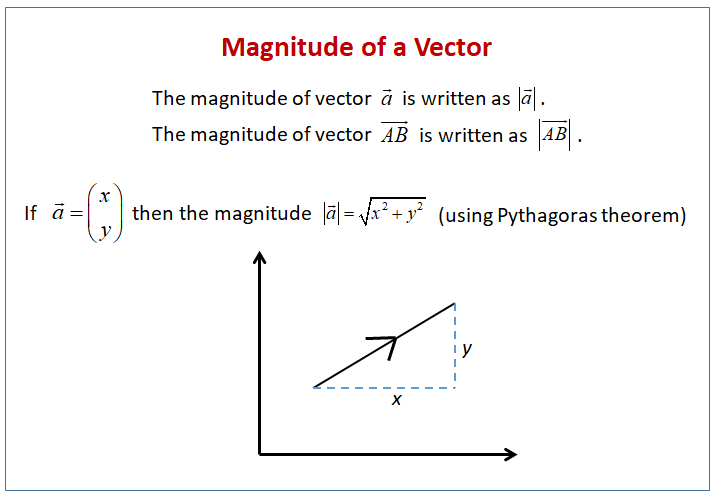
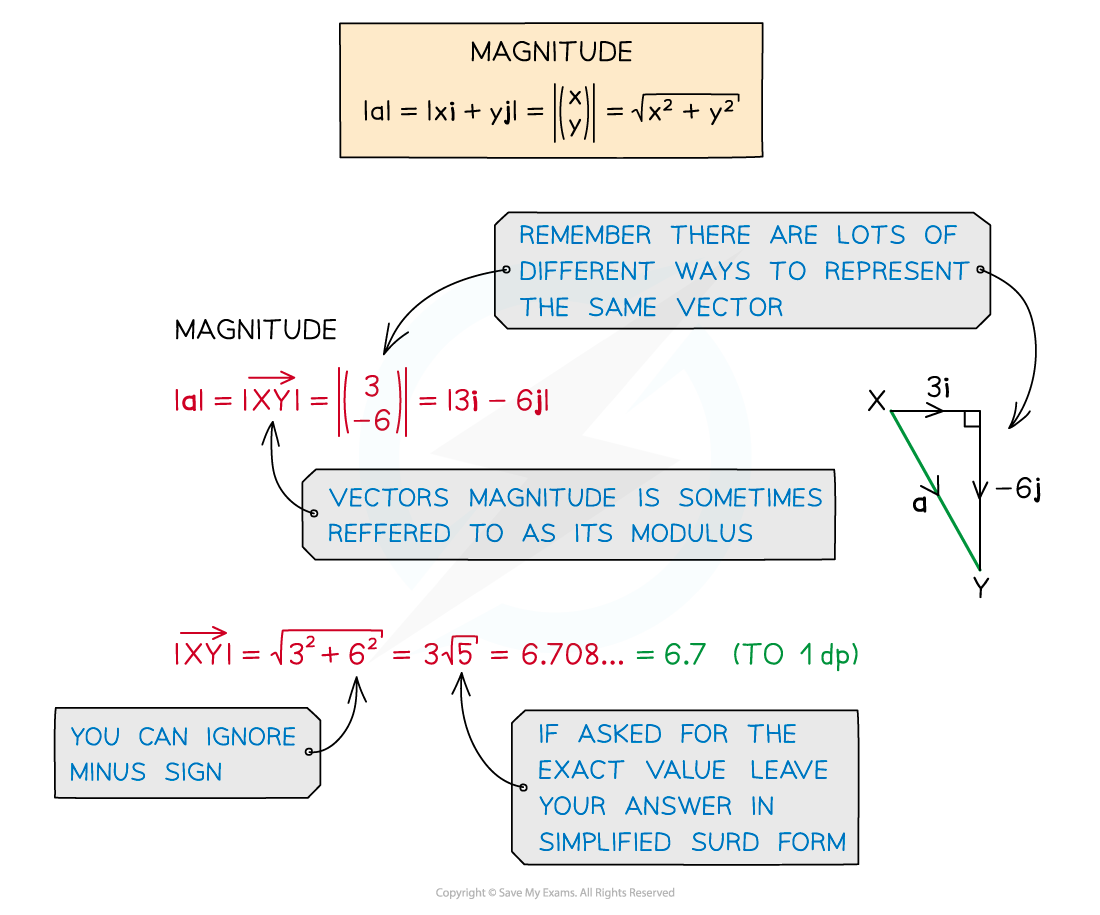
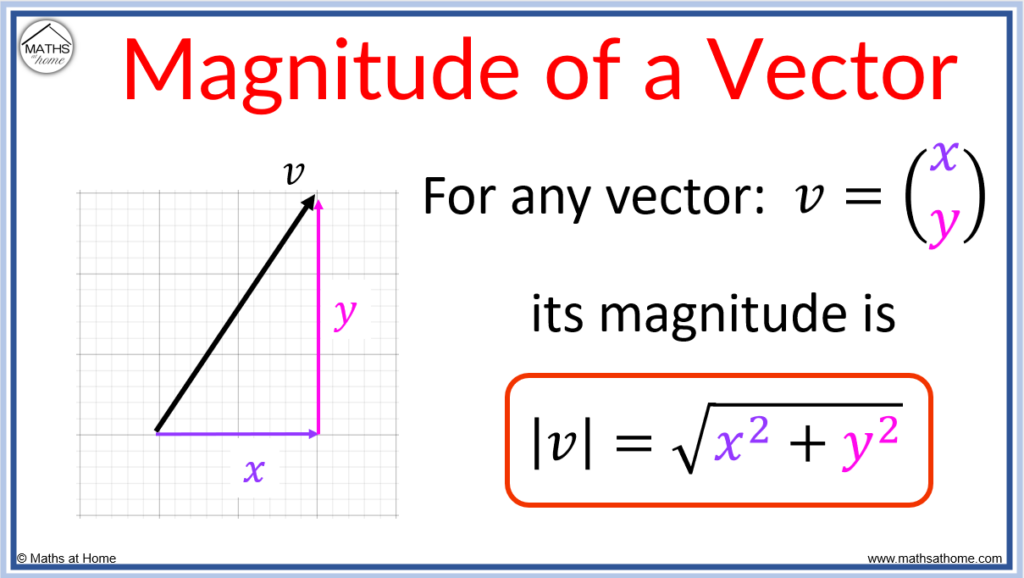
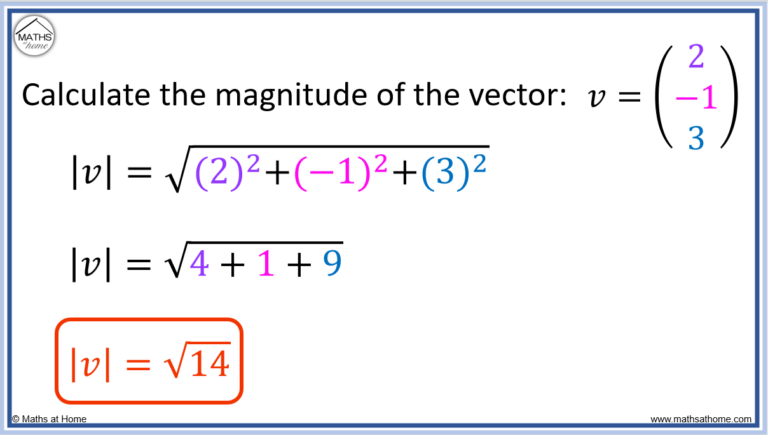
For a vector in n-dimensional space with components v1, v2, through vn, the magnitude is the square root of the sum of each component squared. In two dimensions: |v| = sqrt(v1² + v2²) In three dimensions: |v| = sqrt(v1² + v2² + v3²)
The formula generalizes cleanly to any dimension. Each component gets squared, you add them all up, then take the square root. That's the Euclidean norm, sometimes called the L2 norm. It's the default when people say "magnitude" without qualification. I remember working on a LiDAR point cloud processing pipeline where vectors had 12 dimensions—reflectance values, intensity, time stamps folded in as coordinates. The magnitude calculation itself was straightforward, but the numeric precision became a real problem. When components were on very different scales, squaring them could produce intermediate values that lost precision in float32. I switched to using float64 for the intermediate sum and only cast back to float32 at the end, which fixed the inconsistency. The code ran slower by about 8 percent but the results stopped drifting between runs.
Get the Full Details

The Square Root Problem
The expensive part of computing magnitude is always the square root. If you're working in real-time systems—game loops, interactive visualizations, robotics control loops—sqrt can become a bottleneck. A single sqrt takes roughly 10 to 20 CPU cycles on modern hardware, and if you're computing thousands of magnitudes per frame, that adds up. The standard workaround is the reciprocal square root approximation. The fast inverse square root algorithm, famous from the Quake III engine, approximates 1 over sqrt(x) using a bit-level hack followed by one iteration of Newton's method. It's accurate to about 4 decimal places and runs 3 to 4 times faster than a direct sqrt call. For magnitude calculation specifically, you can compare squared distances instead whenever you only need ordering information—like checking whether a point is inside a radius without caring about the exact distance. But here's the thing beginners miss: the squared comparison trick only works when both sides of the comparison are already squared. If you have a radius threshold, you need to square the radius once upfront, then compare the squared magnitude against that. Don't recompute the square of the radius inside the hot loop.
Edge Cases That Trip People Up
A zero vector has magnitude zero. That sounds obvious until you're writing code that divides by magnitude for normalization and get a division-by-zero crash because your input had all components at zero. Always check whether the vector is near-zero before normalizing, or use a small epsilon threshold. Very large component values can overflow when squared. If your components are around 100 million or more, squaring them produces values near 10 to the 16th power, which exceeds the exact integer representation in float32. Float64 handles this up to about 10 to the 150th power before overflow. In practice, if your application deals with GPS coordinates or astronomical distances, use float64 from the start rather than trying to scale things down. Non-Euclidean norms exist and sometimes matter. The Manhattan norm, or L1 norm, sums the absolute values without squaring or square roots. It's cheaper to compute and more robust to outliers. I used L1 instead of L2 when processing sensor data with occasional spike errors—the outliers would dominate the L2 calculation but the L1 gave a more stable result.
Implementation Details
Here's what a production-ready magnitude function looks like in Python: In performance-critical code, unroll the sum manually to avoid generator overhead. For a fixed-dimension 3D vector, write out the three multiplications explicitly. The difference is small—maybe 2 to 3 microseconds per call—but in a tight loop processing millions of vectors, it compounds. If you're working in a language with SIMD support, the pattern is the same but you'd use vectorized multiply and horizontal add. Modern CPUs can compute four magnitudes simultaneously with AVX2 instructions.
For the common case of normalizing a vector afterward, some libraries provide a combined normalize function that computes the magnitude internally and divides each component. Using this is generally better than computing magnitude separately and then dividing, because it avoids storing the intermediate value and can sometimes fuse the operations at the compiler level.
Common Mistakes
The most frequent error is forgetting to square the components. Someone will add the raw components and take the square root, which gives a completely wrong answer unless the vector happens to lie on a line where all components are equal in sign and magnitude. I see this in code reviews at least once a month. Another mistake is using magnitude when you really want the dot product. If you're checking orthogonality or projecting one vector onto another, the dot product is the right tool. Magnitude only tells you length. Confusing these two shows up when people are learning linear algebra and haven't yet internalized that dot product and norm are different operations even though they use similar formulas. There's also the issue of using the wrong coordinate system. In polar coordinates, the "magnitude" of a position vector is just the radial component r. Converting from polar to Cartesian before computing magnitude is unnecessary work. Similarly, in spherical coordinates, the magnitude is again just the radial distance. Always check whether your vector is already given in a form where the magnitude is trivial to read off.
Finally, a practical note about units. When your vector represents a physical quantity, the magnitude carries units too. A velocity vector with components in meters per second has magnitude in meters per second. A force vector in newtons has magnitude in newtons. Don't treat magnitude as a dimensionless number when the context requires physical interpretation—dimensional analysis catches errors that pure computation misses.