
VLSI Interview Prep Is Different From What You Think
Most people treat VLSI interview questions like a quiz deck. You memorize definitions, recite timing formulas, and walk into a room expecting a clean Q&A. It doesn't work that way. Real VLSI interviews are design walkthroughs disguised as questions. They want to see how you think when the problem has no single right answer, which is most of them. I spent years hiring for physical design and low-power verification teams. The candidates who passed weren't the ones with the longest list of memorized answers. They were the ones who could talk through a messy edge case without panicking. I once asked someone to fix a setup violation in a clock tree where the destination register had a slower process corner than the source. The answer wasn't to just "lower frequency." It involved checking derating factors, adjusting buffer sizing, and explaining why a particular multicycle path exception would be wrong here. Most people stumbled because they'd only studied idealized textbook examples.
Common Interview Questions For VLSI That Actually Show Up
Here are the question categories that come up repeatedly across front-end, backend, and mixed-signal roles. Not all of them are straightforward. You will get timing questions. A lot of them. Start here because everything else builds on it. Setup vs hold violation: Explain the difference between a setup and a hold violation, then describe how you'd fix each one separately. The key detail people miss is that fixing a setup violation can sometimes create a hold violation at the same register pair. Raising the frequency or adding buffers to fix setup increases the delay and can break hold. The fix for hold is usually inserting delay buffers, not touching the clock frequency.
Multicycle path exceptions: When would you apply a multicycle path? A realistic example is a multi-cycle datapath with a pipelined multiplier feeding a register. If you set it to two cycles, you also need a setup delay constraint to tell the tool where the data actually arrives. Without the hold setup, the tool might optimize assuming the data is available too early. I've seen this cause silent timing bugs that only showed up during signoff, not during synthesis. False path vs multicycle path: A false path is a path that never switches in normal operation. A multicycle path takes more than one cycle. The danger zone is setting something false when it's actually functional under an unusual input sequence. I once caught a false path exception that was masking a real race condition in a synchronizer chain. The workaround was to run a formal equivalence check after the constraint was applied and verify the property still held. Clock gating check: Where does the latch sit in a clock gating cell and why? It goes between the enable logic and the gate to prevent glitches from reaching the clock network. If you skip it, you get clock glitches that look like setup violations but aren't timing-related at all. They cause functional failures that are incredibly hard to trace.
Get the Full Details

Digital Design and Architecture
These questions test whether you understand circuits beyond gate-level descriptions. FSM design: You'll be asked to design a finite state machine, usually for a specific protocol. A common one is a sequence detector for overlapping patterns. The tricky part is handling the overlap correctly. If the pattern is "101" and the input is "10101", the output should pulse twice. Most candidates write the non-overlapping version by mistake. Draw the state transition diagram first. Write the next-state logic before you touch the output logic. Metastability: Explain metastability and how to prevent it. The prevention mechanism is a synchronizer flip-flop chain. Two stages give you a mean time between failures in the range of years for typical clock domains. The detail that separates good answers from mediocre ones is mentioning that the probability of failure depends on the data rate and the clock frequency, not just the number of stages. Three stages help, but they add latency. You pick the number based on your MTBF requirement.
Clock domain crossing: Describe at least three CDC techniques. Handshake protocol, FIFO-based crossing, and mux-synchronizer for single-bit signals are the standard three. Each has a tradeoff. The handshake gives you backpressure but adds latency. The FIFO handles burst data but needs depth calculation. The synchronizer is simple but only works for slow single bits. I've seen teams skip the handshake approach for a data bus and then spend weeks debugging a race condition that would have been obvious during the architecture review.
Physical Design and Place and Route
Backend roles focus heavily here. The questions get practical fast. DRC and LVS: What is the difference between DRC and LVS? DRC checks geometric rules from the foundry. LVS checks that the extracted netlist matches the schematic. People often conflate them. The bigger issue is understanding what happens when LVS fails after DRC passes. Usually it's a contact or via issue where the extraction didn't map a terminal correctly. Check the pin mapping and verify that all power nets are connected properly in the extracted view. IR drop: How do you diagnose and fix IR drop? Dynamic IR drop shows up as voltage droop during switching activity. You fix it by adding more power straps, increasing metal width on power nets, or decoupling capacitance placement. Static IR drop is a baseline voltage drop from current flow through resistance. I ran into a case where the dynamic IR drop was fine but the static drop exceeded the margin because a specific block had an unusually high current density. The fix was splitting that block's power ring into two rings with additional vias. It took two reroutes and about four hours of runtime in the tool.
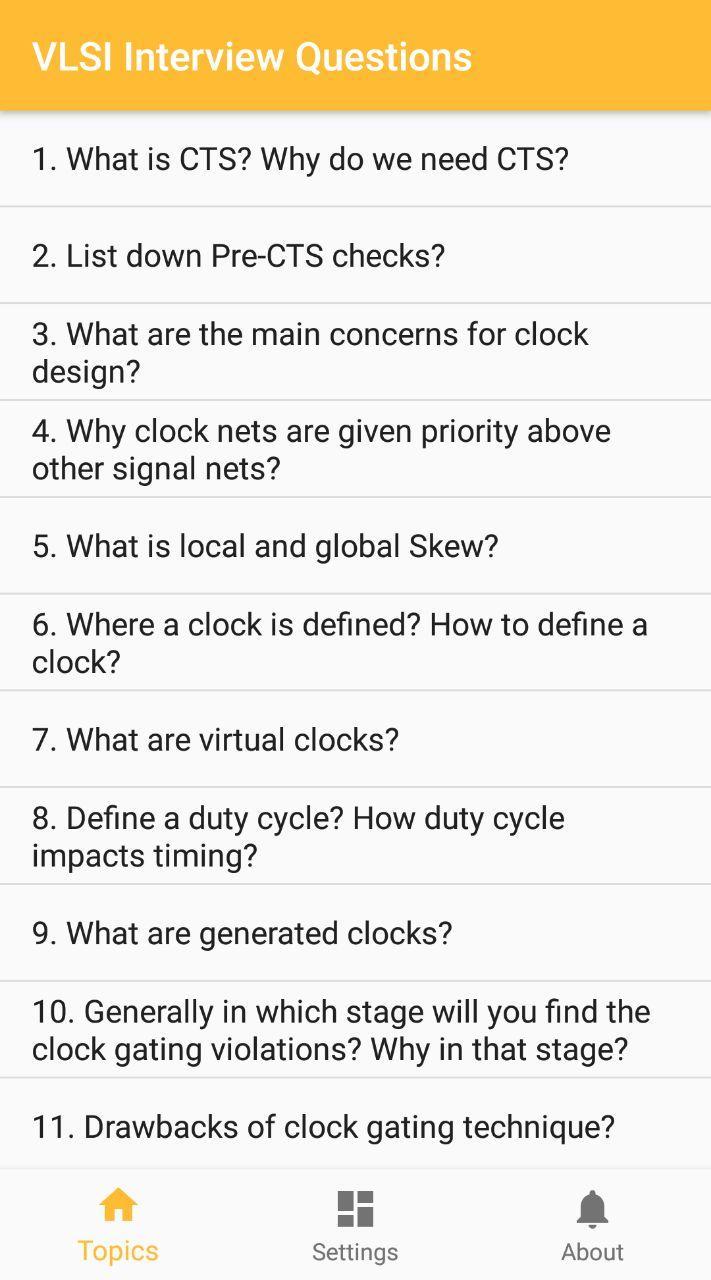
Congestion: What do you do when routing congestion is too high? Standard moves are rerouting the placement, adjusting block placements, or adding more routing layers. But the less obvious fix is checking your cell height alignment and seeing if mixed-height cells are causing placement inefficiencies. Sometimes simply changing the row utilization by two percent opens enough space for the tool to find paths without changing the architecture at all.
Low Power Design
Low power is no longer optional. It's part of every flow. UPF methodology: Explain the UPF flow for multi-voltage design. You define the power domains, the isolation cells, the level shifters, and the power switches. The sequence matters. You create the power intent before synthesis, then the tool honors it during implementation. A common mistake is adding isolation cells after the netlist is already synthesized. The tool won't retroactively insert them correctly. You need to run synthesis with the UPF constraints active from the start. Power optimization techniques: Beyond clock gating, what else reduces power? Input balancing on gates, operand isolation in the datapath, and voltage scaling are the main ones. Input balancing swaps the order of inputs on a gate so the signal that switches less frequently drives the input closer to the output. It's a small saving per gate but it adds up across a large design. I used it on a DSP block where the savings alone covered the power budget for a peripheral section that was running hot.
Verification and Testing
Verification interviews lean toward methodology and debugging skills. UVM components: Walk through the UVM component hierarchy. The testbench top, the agent, the driver, the monitor, the sequencer, and the scorecard. The question that catches people out is asking what the agent does in isolation versus when instantiated in a environment. The agent bundles the driver, monitor, and sequencer for a single interface. The environment orchestrates multiple agents. Confusing the two means your test structure will be wrong from the start. Functional coverage vs code coverage: What's the difference and why do you need both? Code coverage measures which lines of RTL executed during simulation. Functional coverage measures whether your testplan scenarios were hit. They measure different things. I've seen projects with 99 percent code coverage that still missed a corner case in the arbitration logic because the functional coverage model didn't account for simultaneous request scenarios. Code coverage alone is not a completion metric. It never will be.
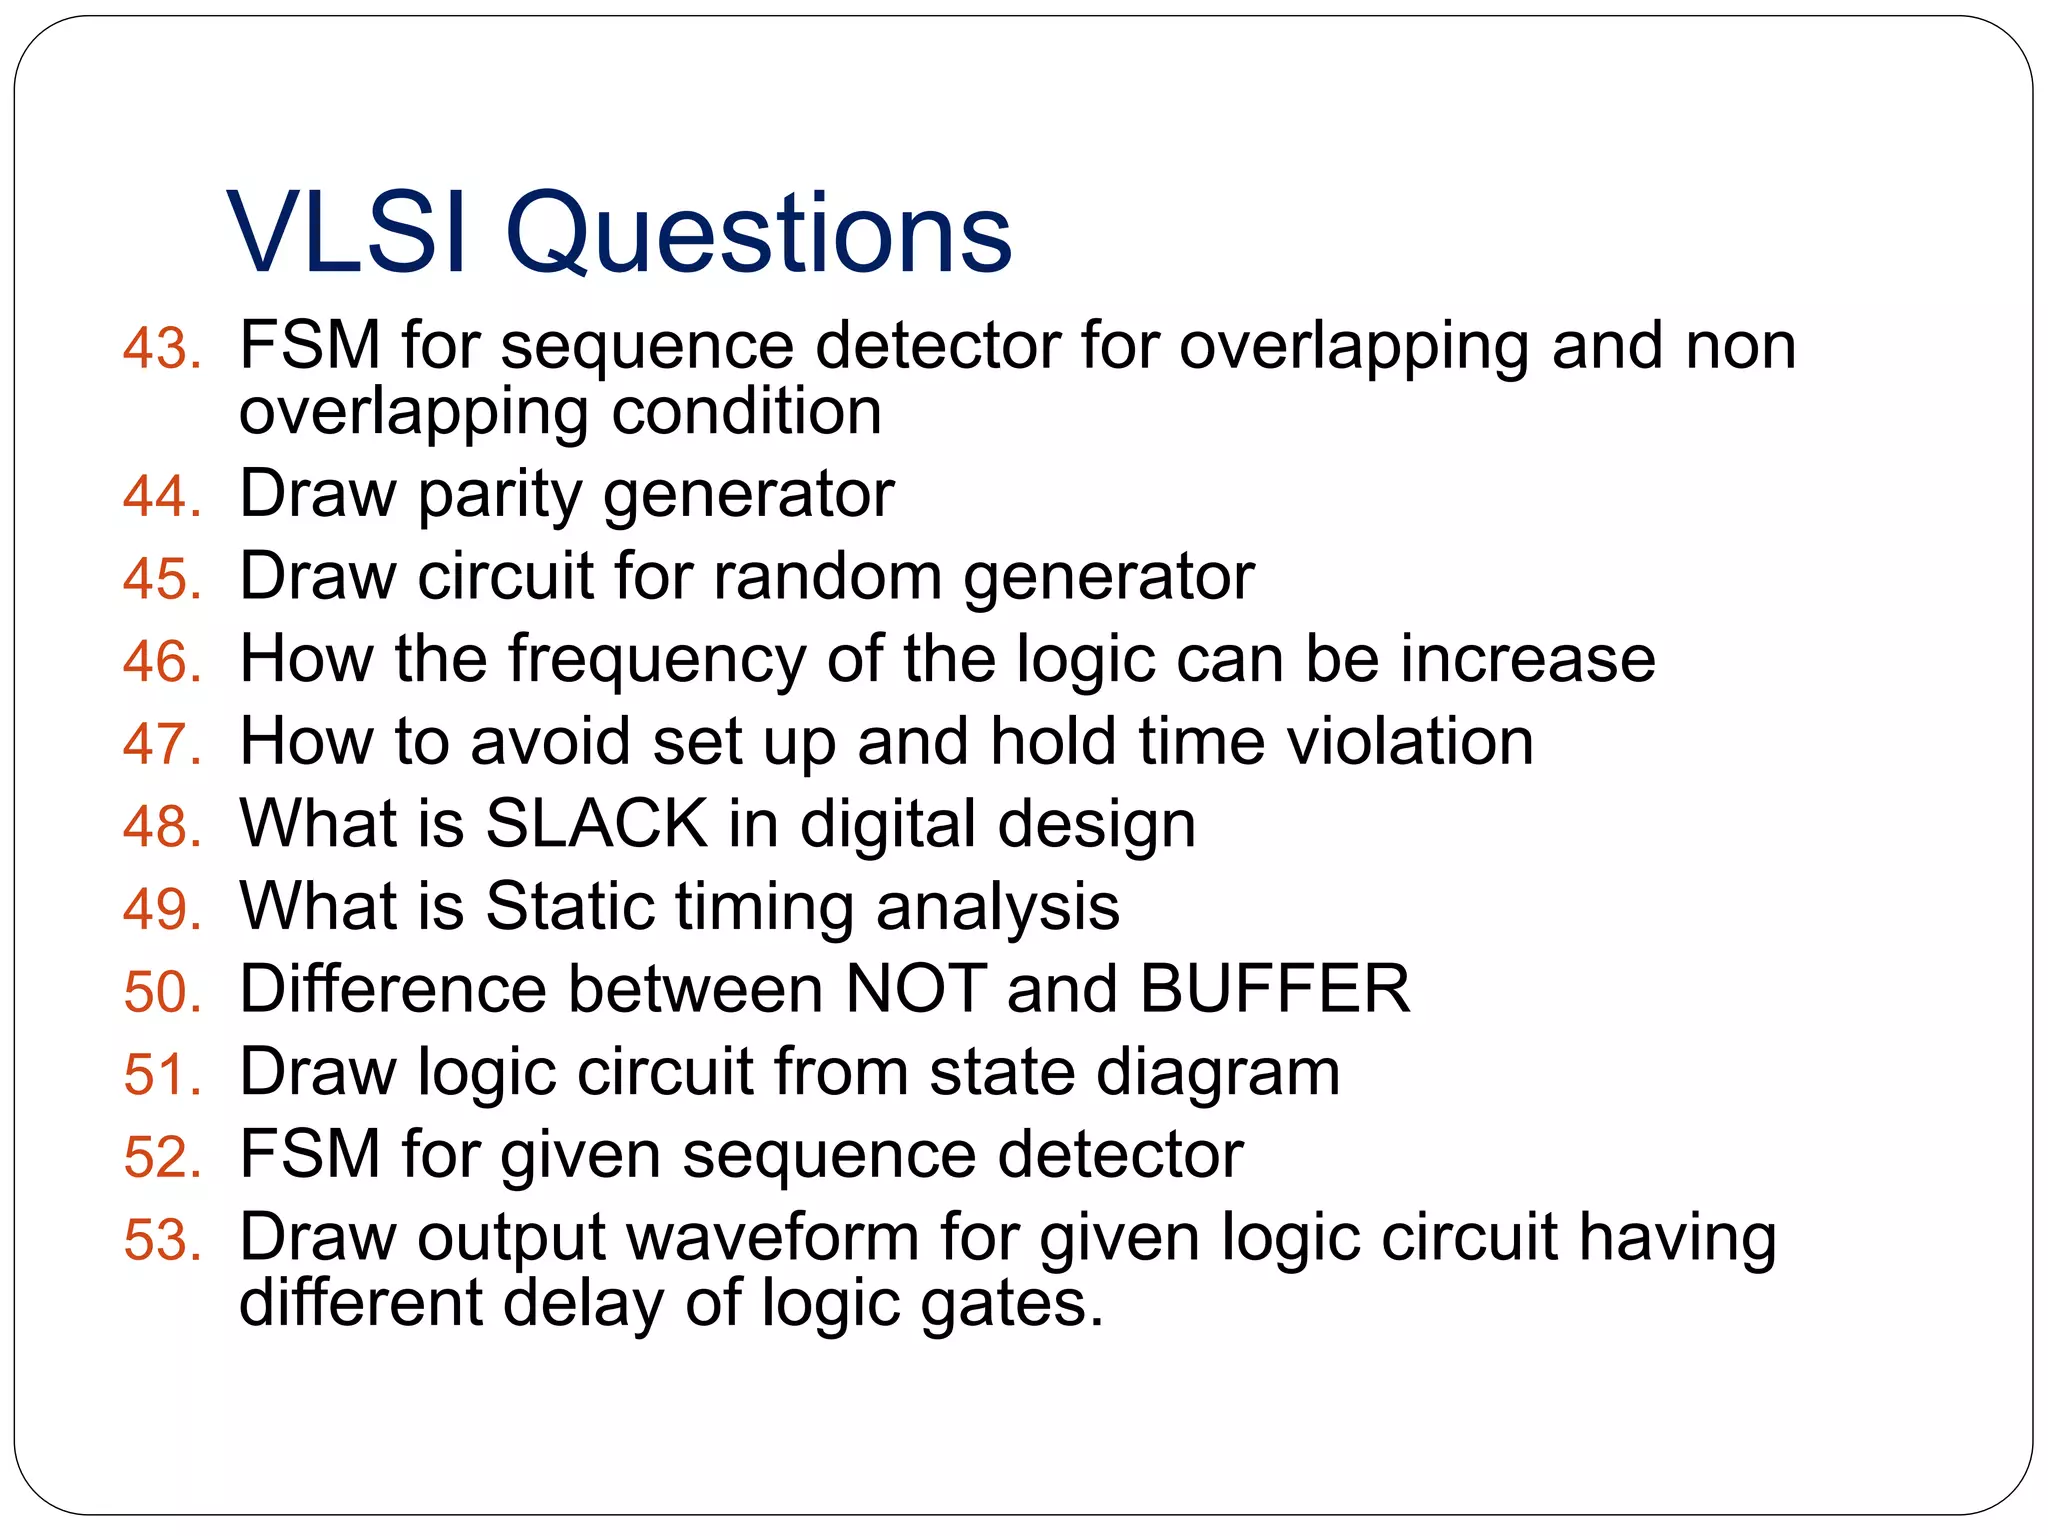
Debugging a failed simulation: Describe your debug process when a test fails randomly. Start with the waveform, identify the failing assertion or mismatch, trace back through the signal dependencies, and isolate the input sequence that triggered it. Then reproduce it in a minimal testbench. The random failure is usually a timing or state-dependent bug. A targeted replay with the same seed will confirm whether it's deterministic or truly random. If it's random, you need to increase your simulation depth or add constraints to your generator to cover the missing scenario.
Verilog and SystemVerilog Specifics
Language questions are usually short but precise. They're designed to catch people who copied code without understanding it. Blocking vs non-blocking: When do you use blocking assignments and when do you use non-blocking? Blocking is for combinational logic. Non-blocking is for sequential logic. The reason is that non-blocking uses the old value for the right-hand side and updates the left-hand side at the end of the time step. If you mix them incorrectly in a always block, you get race conditions that depend on simulation order. The fix is usually separating the logic into two always blocks: one combinational and one sequential. Parameter vs defparam: What's the difference? Parameter is a module-level constant that can be overridden at instantiation. defparam is a hierarchical path assignment that modifies a parameter from the parent. defparam is generally discouraged in modern designs because it makes the hierarchy opaque and harder to track. Use parameter overrides instead. The only case where defparam shows up is legacy codebases that weren't refactored for hierarchical parameter passing.
SystemVerilog assertions: Write an assertion that checks a signal is high for exactly three clock cycles after a trigger. The answer uses the repeat operator inside an assert property. Something like a property that fires on the trigger edge and then checks the signal is high for three consecutive cycles using ##1 and ##2 delays. The common mistake is writing the assertion without an empty_match option, which causes the checker to fail if the signal goes low early and then comes back high. You need to decide whether early termination should be treated as a pass or a fail based on the protocol.

What Good Candidates Do Differently
The candidates who consistently passed weren't the ones who knew every answer. They were the ones who admitted uncertainty and walked through their reasoning out loud. When I asked about a constraint I wasn't familiar with, the good ones would say what they knew, identify the gap, and explain how they'd look it up in the specification. That's actually how the job works. You don't memorize the entire STA manual. You know where to find the answer when you need it. Another habit I noticed was drawing diagrams on the whiteboard before answering. Timing questions especially benefit from a quick sketch of the launch and capture paths. It forces clarity and gives the interviewer something to react to. The verbal answer alone is usually too abstract for a problem that involves clock trees, buffer insertion, and derating factors all at once. Finally, prepare a few stories from your own projects. Something like the congestion fix, the IR drop issue, or the CDC synchronizer you designed. Be ready to discuss the problem, the constraints you worked under, the failed approaches, and the final result. Interviewers ask follow-up questions to see whether you actually did the work or just read about it. The details matter more than the headline. Mention the tool version, the constraint file syntax, and the specific metric you improved. Vague answers don't survive scrutiny.

