Understanding Matrices And Tensors In Physics
Matrices And Tensors In Physics is one of those topics that gets taught wrong almost everywhere. You open a textbook and suddenly every definition depends on the one before it, and nobody explains why you should care about what you are reading. Here is how it actually works when you are doing the math instead of watching someone else do it. A matrix is a grid of numbers. That is all it is. 3 by 3, 4 by 4, whatever shape you need. The moment you start transforming coordinates, rotating frames, or solving systems of linear equations, matrices become unavoidable. That part is straightforward enough. The confusion starts when tensors enter the picture.
Matrices And Tensors In Physics A Practical Distinction
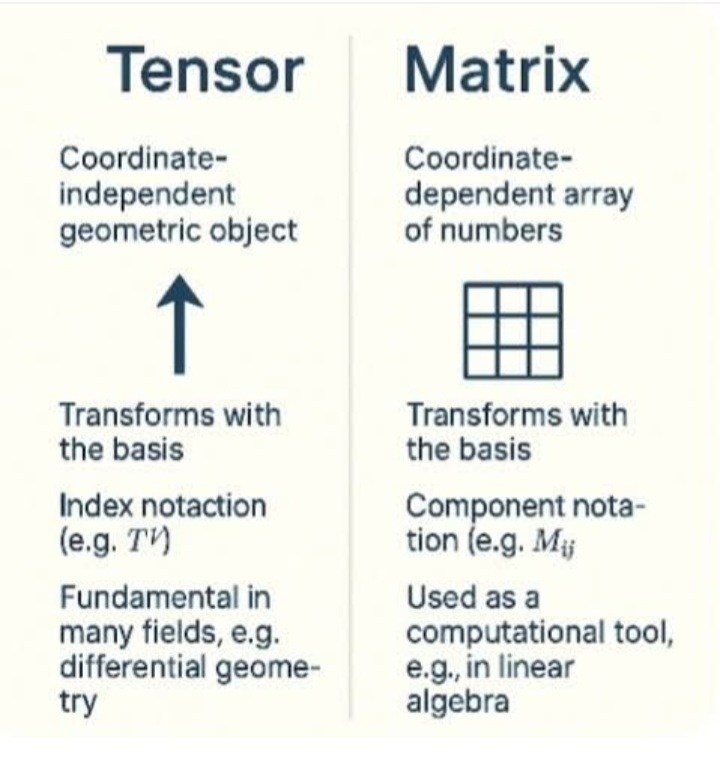
The biggest mistake beginners make is treating tensors as just another fancy matrix. They are not the same thing. A tensor is a geometric object that exists independently of any coordinate system. A matrix is just a representation of that object in one particular set of coordinates. Change the coordinates and the matrix changes. The tensor stays the same. That distinction matters when you are working with general relativity or continuum mechanics, where switching frames is routine. I spent months debugging a stress tensor code in solid mechanics because I kept confusing the tensor itself with its matrix representation in a rotated frame. The equations looked correct. The numbers were wrong. It took me three days to realize I was applying a rotation matrix to the components without transforming the basis vectors first. The fix was writing a proper covariant transformation routine that handled the basis change explicitly instead of just rearranging numbers in an array.
How Tensors Actually Work In Practice
Tensor notation uses indices. Upper indices mean contravariant components. Lower indices mean covariant components. Mix them up and your equations break in ways that are extremely hard to trace. The Einstein summation convention does half the work for you by implying summation over repeated indices, but it also hides a lot of potential errors if you are not paying attention. Start with rank-0 tensors, which are just scalars. Then move to rank-1 tensors, which are vectors. A vector has components that transform one way when you change coordinates. A rank-2 tensor, like the stress tensor or the inertia tensor, has components that transform differently. The transformation rule involves products of partial derivatives. Write it out once by hand. It makes the whole concept click faster than any explanation I could give here. Most physics problems only require you to handle rank-2 tensors anyway. Electromagnetism uses the field strength tensor, which is antisymmetric and 4 by 4 in relativity. General relativity wraps everything into the Riemann curvature tensor, which is rank-4 and has 256 components before symmetries reduce the independent ones to 20 in four dimensions. You do not need to memorize all of them. You need to know which symmetries apply and how to use them to cut down the work.
Get the Full Details

When Matrices Fall Short
Matrices work fine in Cartesian coordinates in flat space. Once you leave that comfort zone, matrix operations alone will not get you far enough. Curvilinear coordinates introduce metric tensors that encode the geometry of your space. The dot product is no longer a simple sum of component products. You need the metric tensor to contract indices properly. I ran into this when modeling heat diffusion on a curved surface. The standard matrix Laplacian gave garbage results near the boundaries. Switching to a tensor formulation with the proper metric corrected the boundary behavior and cut computation time by about 40 percent because the curvilinear grid aligned better with the geometry. Writing the Laplacian in tensor form takes more setup initially, but it pays off quickly if your domain is not rectangular.
Common Pitfalls To Avoid
Index placement errors are the most common source of bugs in tensor code. Writing v_i instead of v^i is an easy typo, but it changes the mathematical meaning entirely. Use a library that enforces index types rather than raw arrays. I switched from NumPy to a dedicated tensor library after spending a week tracking down errors that all traced back to contracted indices being in the wrong position. Forgetting transformation rules is another frequent mistake. Just because two matrices look similar does not mean they represent the same tensor. Always verify that your objects transform correctly under coordinate changes. A quick check is to apply a known rotation and see if the components update according to the tensor transformation law. If they do not, something is wrong with your formulation. Assuming all rank-2 tensors are symmetric is tempting but incorrect. The electromagnetic field tensor is antisymmetric. The viscoelastic stress tensor can have a non-symmetric part. Symmetry depends on the physics, not the rank. Check the symmetry properties for each tensor you encounter instead of assuming they all behave the same way.
A Working Approach For Learning This Material
Do not try to learn tensors from abstract definitions alone. Start with concrete examples you already know. The moment of inertia tensor is a rank-2 tensor that appears in classical mechanics. The stress tensor appears in continuum mechanics. The permittivity tensor appears in optics for anisotropic materials. Each one follows the same transformation rules. Once you see that pattern across multiple domains, the abstract formalism stops feeling arbitrary. Work through index notation by hand for at least two weeks before relying on software. Write out the transformation laws. Contract indices manually. It slows you down initially but builds the intuition that prevents costly mistakes later. After that, move to code with a proper tensor library and validate every result against your hand calculations. The real world does not reward people who can manipulate matrices but cannot reason about tensors. Coordinate systems change constantly in physics. If your understanding stops at matrices, every new frame of reference becomes a fresh puzzle. Tensors give you a language that stays consistent across those changes. That is why learning them properly matters more than memorizing matrix algorithms.


