Why Your Structural Analysis Keeps Failing at the Joints
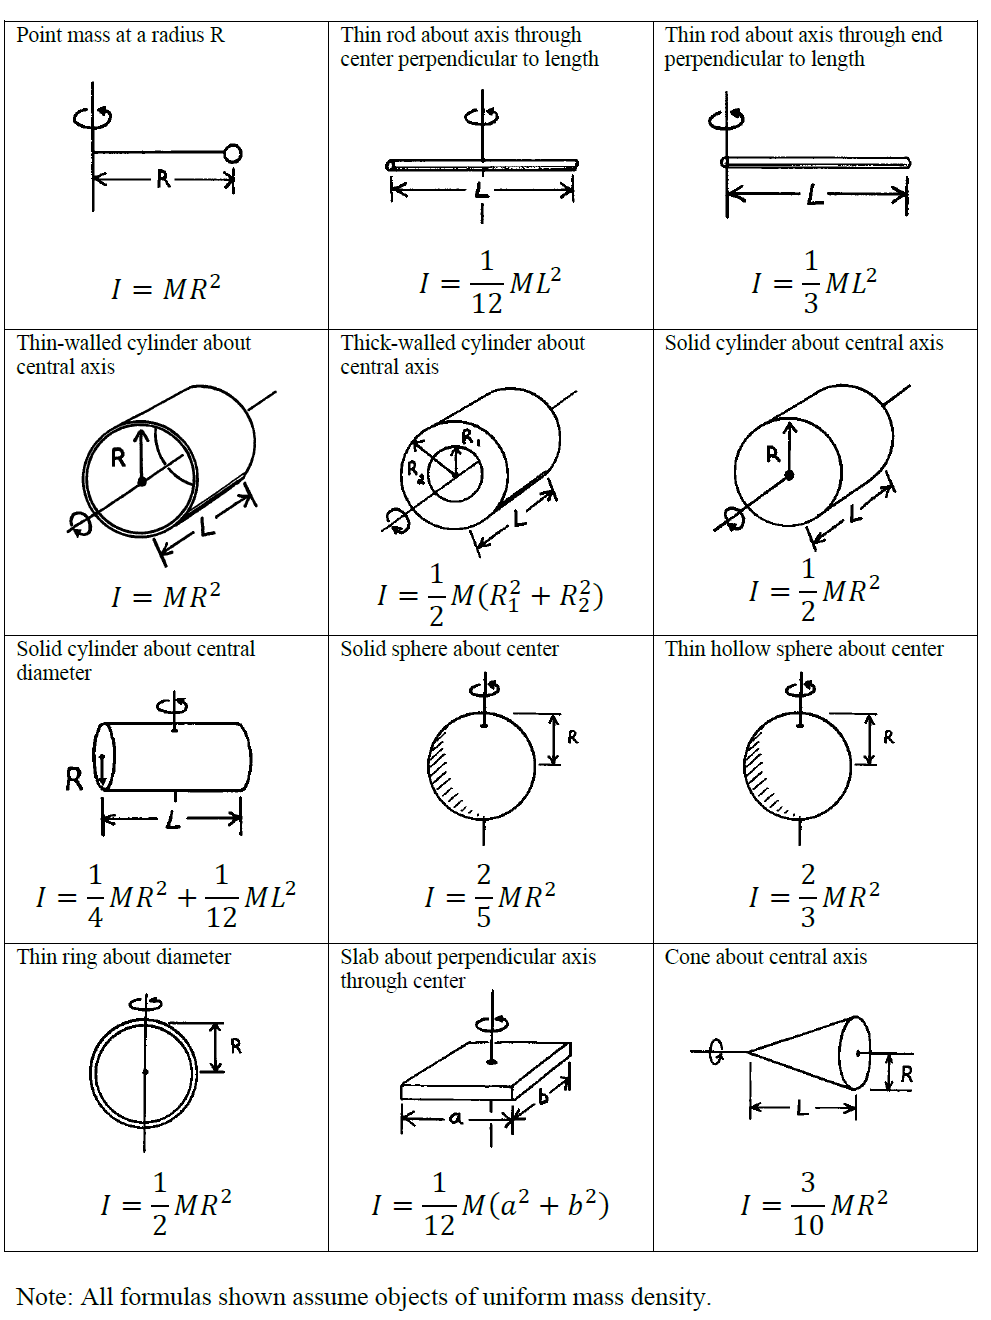
The moment of inertia table is one of those things every engineering student memorizes once, then forgets until they need it at 2 AM before a submission deadline. It sits somewhere between basic and forgettable in the hierarchy of useful knowledge, which is precisely why so many people trip over it when their finite element models start spitting out nonsensical deflection values. I've spent years watching junior engineers treat these tables like they're gospel, pasting values from a PDF into spreadsheets without ever checking whether the assumptions behind the formula actually match their geometry. It doesn't take long before the numbers look right but the physics doesn't.
Building a Moment Of Inertia Table That Doesn't Lie to You
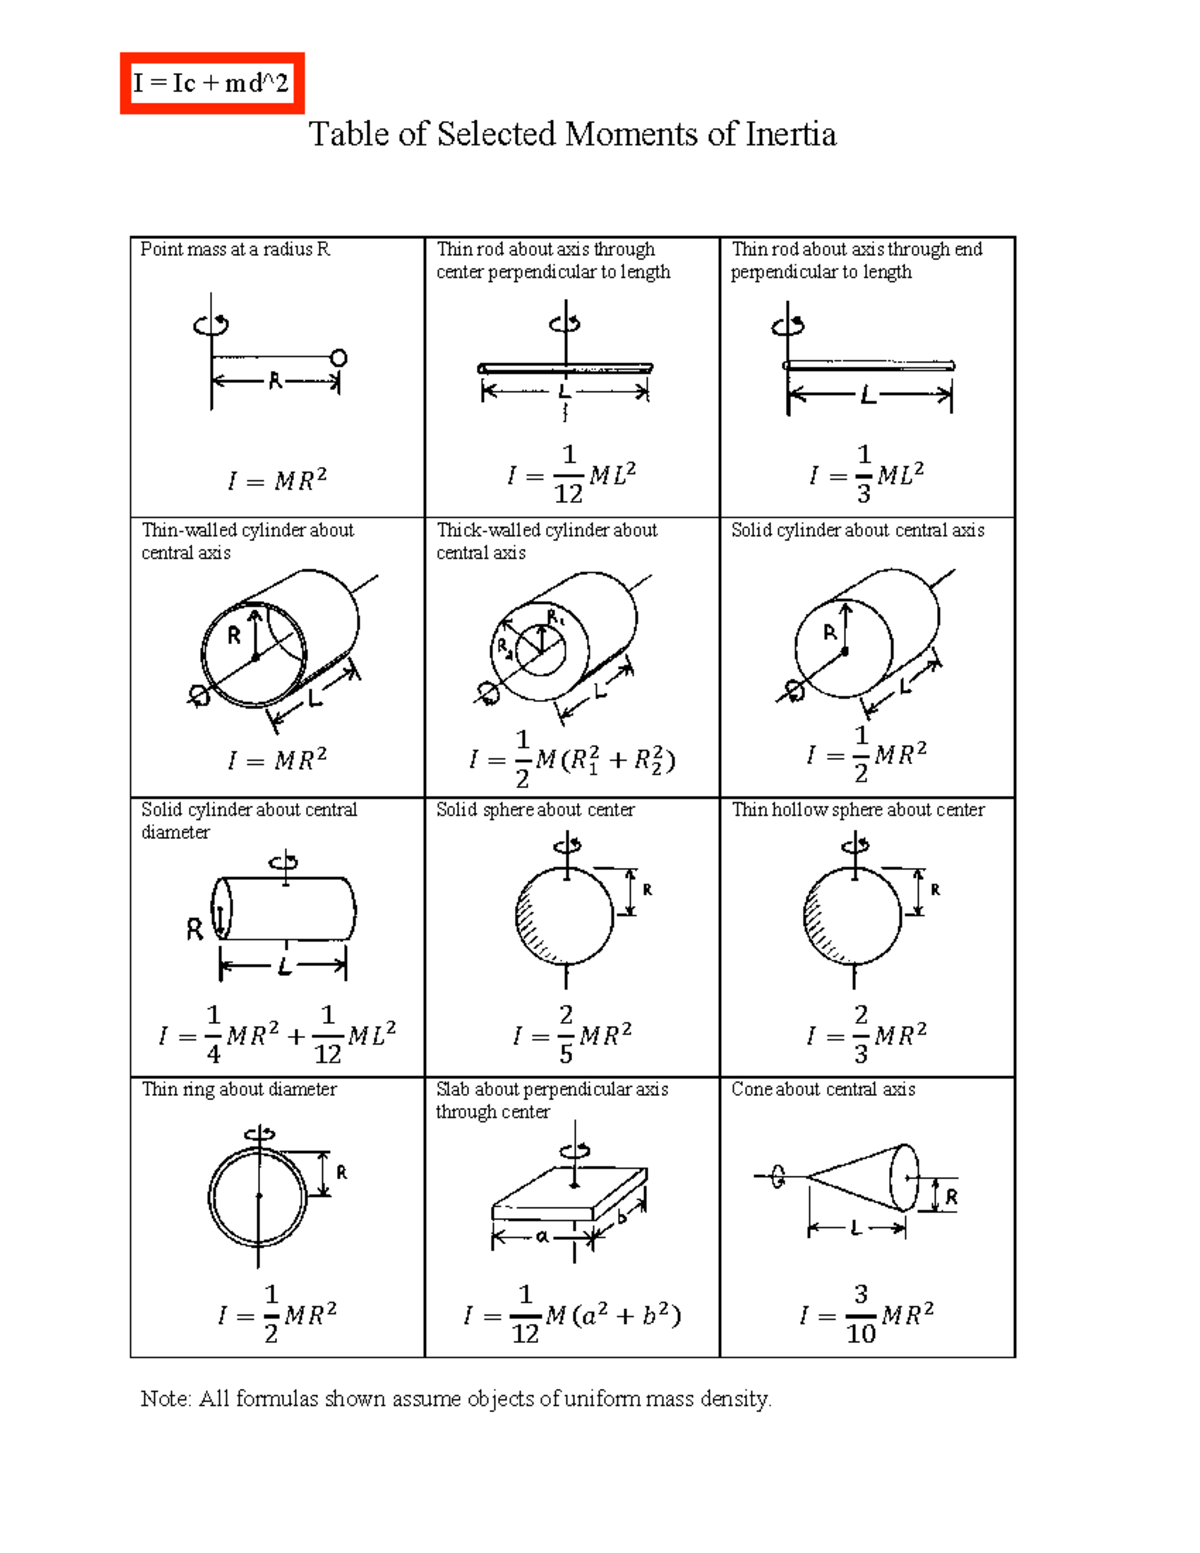
The fundamental problem with most moment of inertia references is that they list standard shapes in isolation. They give you the rectangle, the circle, the I-beam, and call it a day. What they almost never show is what happens when you combine them or when your shape falls outside their neat little cases. I ran into this exact issue on a project last year where I was dealing with a tapered flange plate that sat somewhere between a rectangle and a trapezoid. The table had nothing for it, and using an approximate rectangular value introduced about a twelve percent error in my stress predictions. I ended up integrating the geometry by hand and building a custom entry for it. Here's how to approach this practically. Start by understanding what the moment of inertia actually represents. It's not just a number you plug in, it's a measure of how mass or area is distributed relative to an axis. The farther that material sits from the axis, the larger the value becomes, and it scales with the square of that distance. For area moments of inertia, which is what you'll use for bending and deflection calculations, the basic formula is I equals the integral of y squared dA. For shapes where you can write y as a function of x or vice versa, this becomes a straightforward calculus exercise. For standard shapes, the integration has already been done and you get closed-form results.
The parallel axis theorem is where most people lose their way. I = I_centroid plus A times d squared. The centroidal value is always the smallest possible moment of inertia for that shape about any parallel axis. Move the axis away from the centroid and the value increases. Always subtract the area times distance term when you're working backwards from a known value, which you'll need to do when decomposing composite shapes. When building your own reference table, organize it by shape type and make sure each entry includes the axis it applies to. There's a critical difference between Ix and Iy for asymmetric sections, and swapping them without noticing is a common mistake that produces wrong answers very confidently. Composite sections require you to break the shape into simple components, find each component's centroidal moment of inertia, shift each to the common neutral axis using the parallel axis theorem, and then sum them. Don't skip the sign check on the parallel axis term, especially when your component centroids fall on opposite sides of the overall neutral axis. I've seen people add both d-squared terms and end up with values that were twenty percent too high.
Get the Full Details
For polar moment of inertia, which matters for torsion problems, J equals Ix plus Iy for any cross-section. This is useful to know because some tables list J directly for circular sections but not for others, and calculating it from the rectangular components is always available to you.
Edge Cases and Why Tables Fail You
The biggest limitation of any printed or digital moment of inertia table is that it only covers the shapes someone thought would be useful. Real engineering geometry rarely cooperates. Thin-walled open sections, built-up members with connection hardware, tapered components, and hollow sections with irregular voids all fall outside standard tables. For these, you either derive the value yourself or use numerical integration through a CAD tool or spreadsheet. Another practical issue is the distinction between elastic and plastic section modulus. Tables give you the elastic moment of inertia, but if your design involves plastic analysis or limit state design, you need the plastic section modulus, which requires a different calculation entirely. Using the elastic value for a plastic moment capacity check will underestimate the strength, sometimes significantly, for sections with substantial material away from the neutral axis. Material anisotropy also breaks the simple moment of inertia model. Composite materials, rolled steel with grain directionality, and wood with its grain structure all have directional stiffness properties that a single scalar moment of inertia cannot capture. In those cases you need a inertia tensor, which is a matrix rather than a single number. If your software asks for a tensor and you're feeding it a scalar from a table, it will produce incorrect results and likely not warn you about it.
Thin-walled sections introduce another complication. For closed thin-walled sections under torsion, the Bredt formula gives you shear flow based on the enclosed area, not the moment of inertia. Using the moment of inertia table value for a torsion problem on a thin-walled box section will give you a result with no physical meaning. Make sure you know which property governs your problem before you reach for the table.
What to Do When the Table Doesn't Help
If you're working with a non-standard shape and need a reliable value, the numerical approach is usually faster than deriving an analytical solution. Divide the cross-section into small rectangles or triangles, calculate each one's centroidal moment of inertia, apply the parallel axis theorem to shift to your reference axis, and sum everything. A spreadsheet with about twenty rows can handle most practical shapes in under five minutes. For repeated use, building your own lookup table in a spreadsheet pays off quickly. Organize it with shape type, dimensions, axis designation, centroidal Ix, centroidal Iy, area, and notes on any assumptions or limitations. Once you have this set up, you can also add derived values like section modulus and radius of gyration in adjacent columns, which saves you from recalculating them each time. There's also the option of using open-source computational tools if your geometry is complex enough that manual decomposition becomes error-prone. These tools can handle arbitrary polygons and provide both elastic and plastic properties, though you should always spot-check a simple case against a known table value to verify the software isn't doing something unexpected with its axis conventions.
The bottom line is that the moment of inertia table is a starting point, not a destination. Understanding what the values mean, when they apply, and how to extend them beyond the standard shapes is what separates someone who can look up a number from someone who can actually solve the problem.