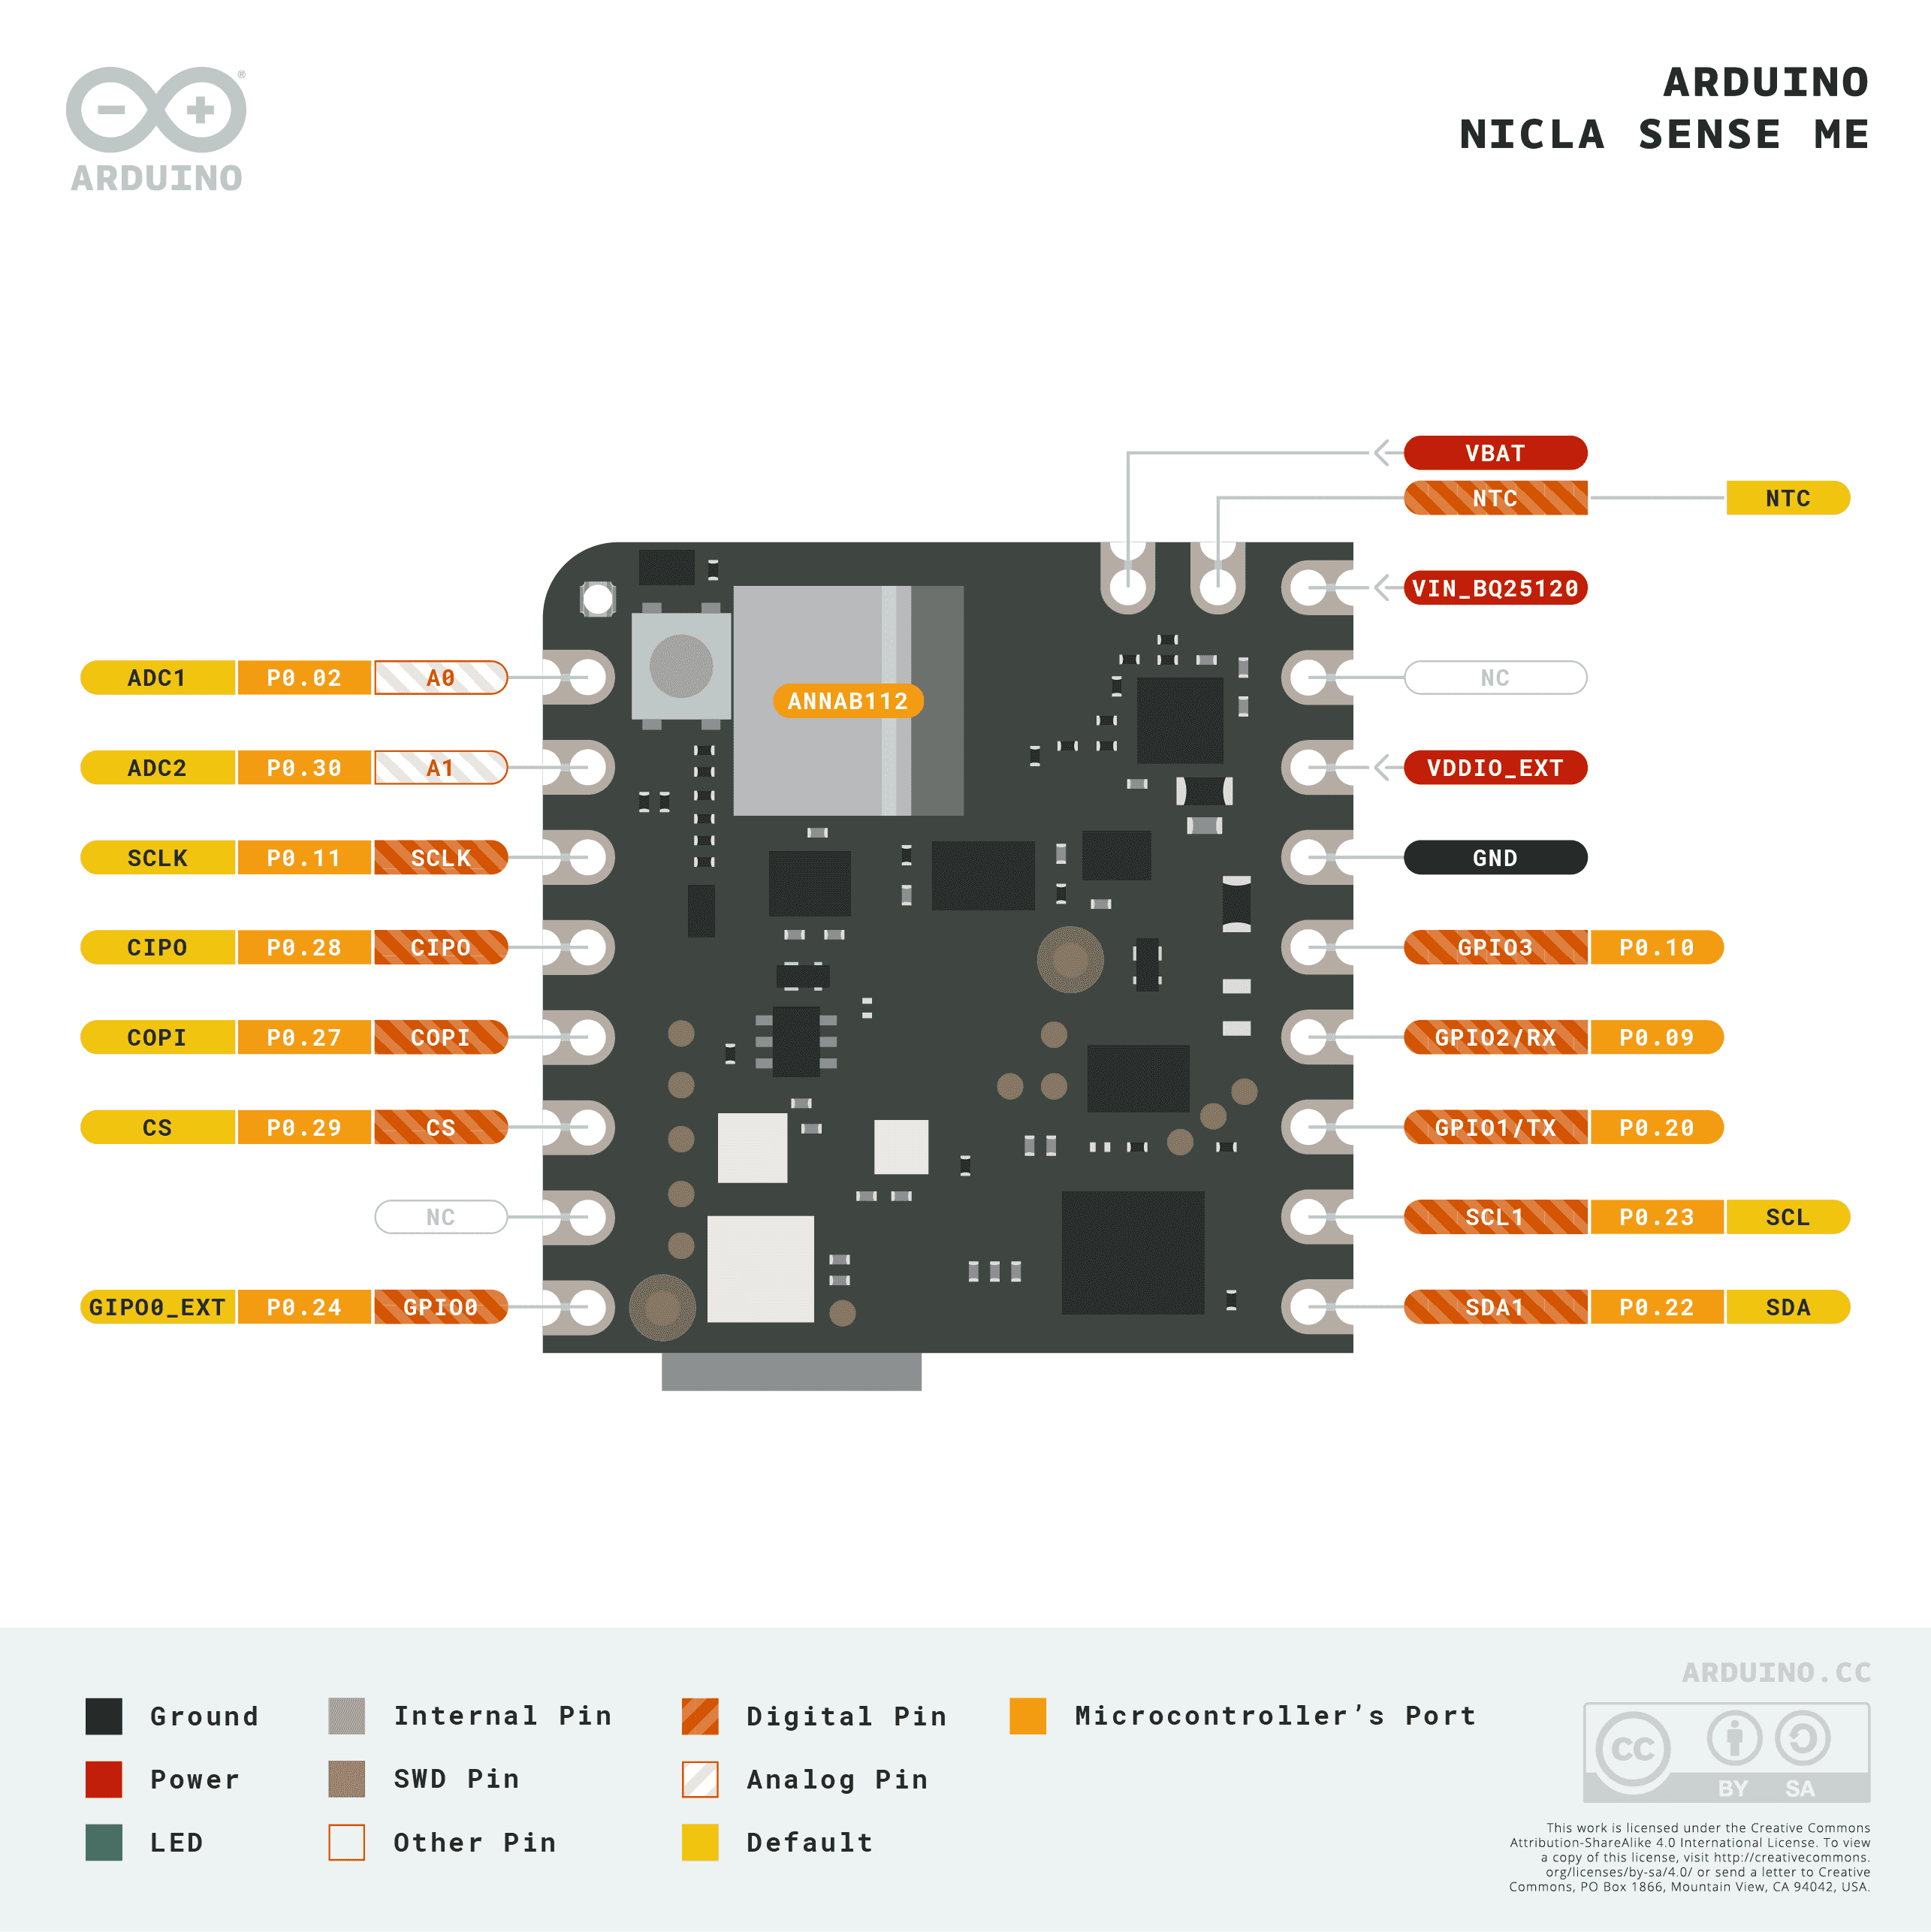
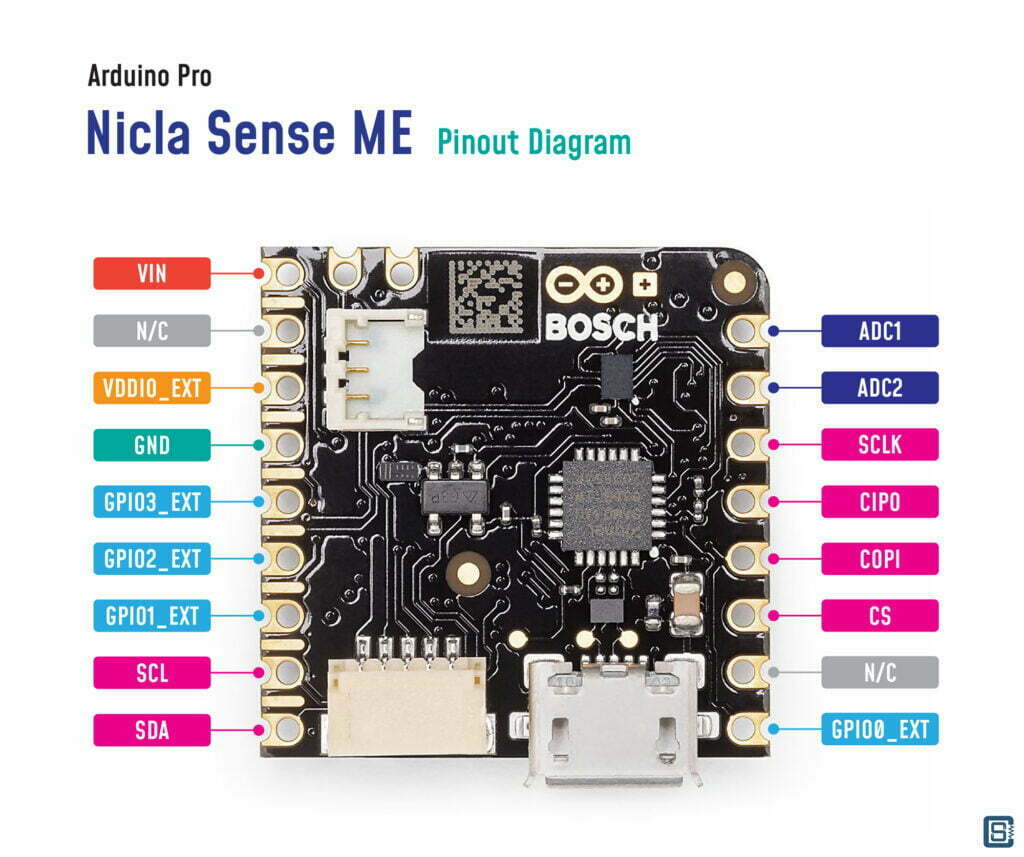
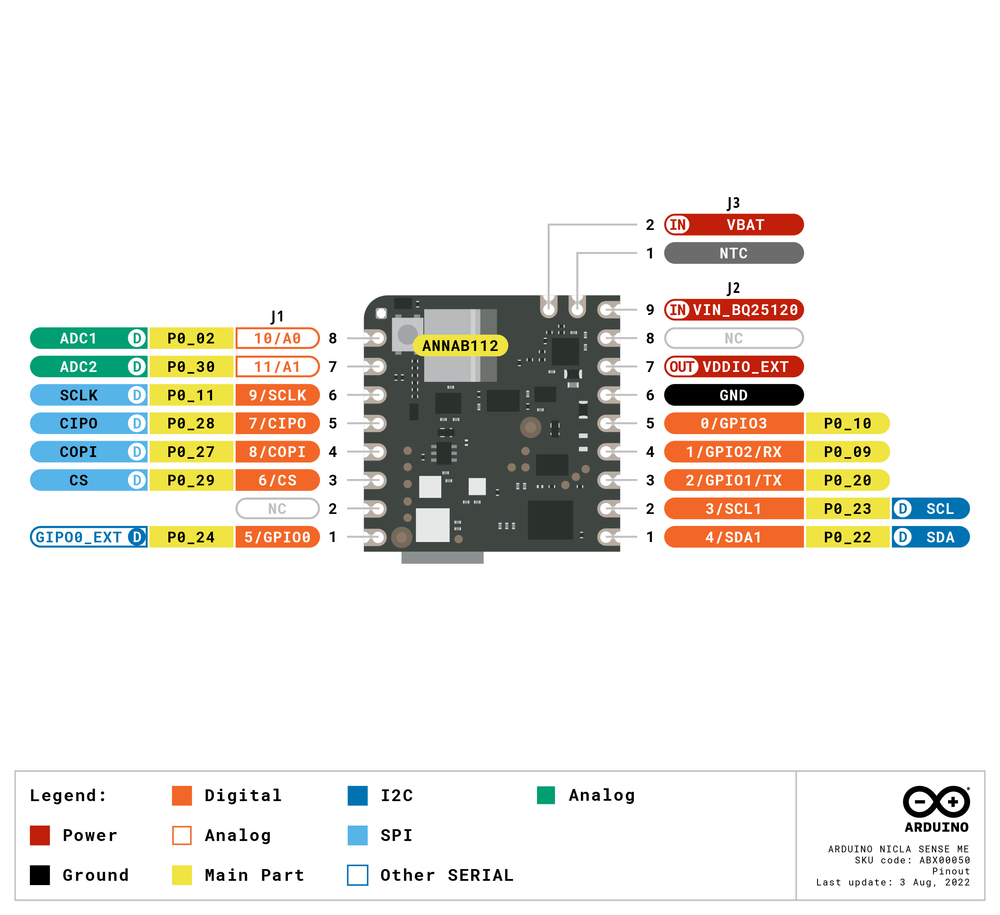
What the Nicla Sense Me Actually Is
The Nicla Sense Me is an Arduino-compatible sensor board packed with more sensing capability than most projects actually need. It has an NXP i.MX 8M Nano processor, an ICM-42688-P IMU, an MPS20N0040D pressure sensor, a BME680 for gas/temperature/humidity, and an OPT3002 ambient light sensor. All of that runs off a coin cell or USB-C. The point of a cheat sheet is just to stop you from googling register addresses and pin mappings every time you need something. The most useful versions circulate as PDFs and GitHub gists. The official Arduino documentation page has a reference section, and several maker communities host their own condensed one-page references. Search for "Nicla Sense Me pinout pdf" or check the Arduino forums. I keep mine pinned in a browser tab because the examples scatter the relevant information across three different documentation pages. I don't read the cheat sheet cover to cover. I use it to resolve two things: which pins are accessible when a peripheral is active, and which library function maps to which sensor. The Nicla Sense Me shares pins between SPI peripherals, so you can't just assume the IMU and the BME680 coexist without checking the pin allocation table. My first project using this board I wired the gas sensor and pressure sensor to the same SPI bus expecting them both to respond. Neither did. The board doesn't break out separate chip select lines for every sensor by default, and the Arduino wrapper abstracts that away, but when you drop into low-level register access the collision is immediate.
The workaround I settled on is straightforward. Use the Nicla_Sensors library for everything except what genuinely requires timing precision. The library handles the SPI multiplexing internally. If you need sub-millisecond sampling from the IMU while also polling the BME680, you run into conflicts because the library initializes all sensors on boot by default. I solve this by disabling unused sensors in the initialization block and only enabling the ones I need. That alone cuts startup time from roughly eight seconds down to about two, which matters when you are running on a CR2032.
Pinning and Power Realities
The board exposes only a limited set of GPIO through the breakout pins. What looks like extra pins on the schematic often aren't actually routed to the header. I learned this the hard way when I tried to use pin D5 for a digital input and spent forty minutes troubleshooting a floating reading before realizing the pin wasn't connected to anything on the PCB. Power consumption is the bigger issue. The Nicla Sense Me draws somewhere between 3mA in idle and 80mA during active sensor polling depending on configuration. If you are building a long-lived IoT node, you need to understand the sleep modes. The board supports deep sleep with the real-time clock keeping time, and wake-on-motion from the IMU. Getting the deep sleep sequence right requires understanding the reset behavior. A soft reset does not clear all peripheral state, so if your code crashes mid-sensor-read the next boot cycle can inherit corrupted buffer state. I add an explicit sensor deinitialization step to my setup routine now. It costs me three lines of code and has prevented at least half a dozen mysterious reboots.
Get the Full Details
Sensor Calibration Notes
The BME680 gas sensor is the one most people get wrong. The raw resistance value means almost nothing on its own. You need to run the gas sensor in heated mode, allow the heater to stabilize, then sample. The library provides helper functions for this but the default parameters in the example sketches are tuned for lab conditions, not for field deployment. If you are measuring indoor air quality, you need to baseline the sensor over several hours in your actual environment before the readings are remotely meaningful. I typically run a 24-hour baseline collection before trusting any alert thresholds. The IMU needs a proper calibration too. Factory calibration is adequate for crude motion detection but if you are building anything that estimates orientation, the bias drift will accumulate fast. The Nicla_Sensors library includes a calibration routine that takes about thirty seconds. Run it once per board, store the offsets in EEPROM, and skip it on subsequent boots. That trims angular drift from maybe five degrees per minute down to under one.
Common Library Gotchas
The Arduino Nicla_Sensors library has changed its API twice since launch, and the examples on the official site haven't always kept up. The biggest friction point is how the library handles sensor objects. You don't instantiate each sensor separately anymore. You create a single Nicla_Sensors object and query individual sensors through it. If you find older code online that calls BME680.begin() directly, it will not compile on current releases. Check your library version first. Anything below 2.0.0 is effectively obsolete for new projects. Another issue is the default SPI clock speed. The library runs the bus at 1MHz by default, which is conservative and safe. The sensors support higher speeds, and bumping the clock to 4MHz cuts sampling latency noticeably without introducing errors. I set this in the begin call with the optional speed parameter.
When This Board Fails You
The Nicla Sense Me is not a universal solution. It struggles in two specific scenarios. First, if you need Bluetooth Low Energy central mode and simultaneous high-rate sensor logging, the radio and SPI bus contend for the same internal bandwidth. You will see dropped packets or missed sensor readings. I solved this by offloading the BLE stack to a separate nRF52 module and keeping the Nicla focused on sensing only. Second, the board has no analog-to-digital converter exposed for external sensors. If your project requires reading a simple analog voltage from a resistive sensor, you need to route that through an external ADC. The board does not have a built-in option, and there is no workaround other than adding another chip. For projects that only need the onboard sensors, this limitation is irrelevant, but it catches people off guard when they assume the board is more flexible than it actually is.
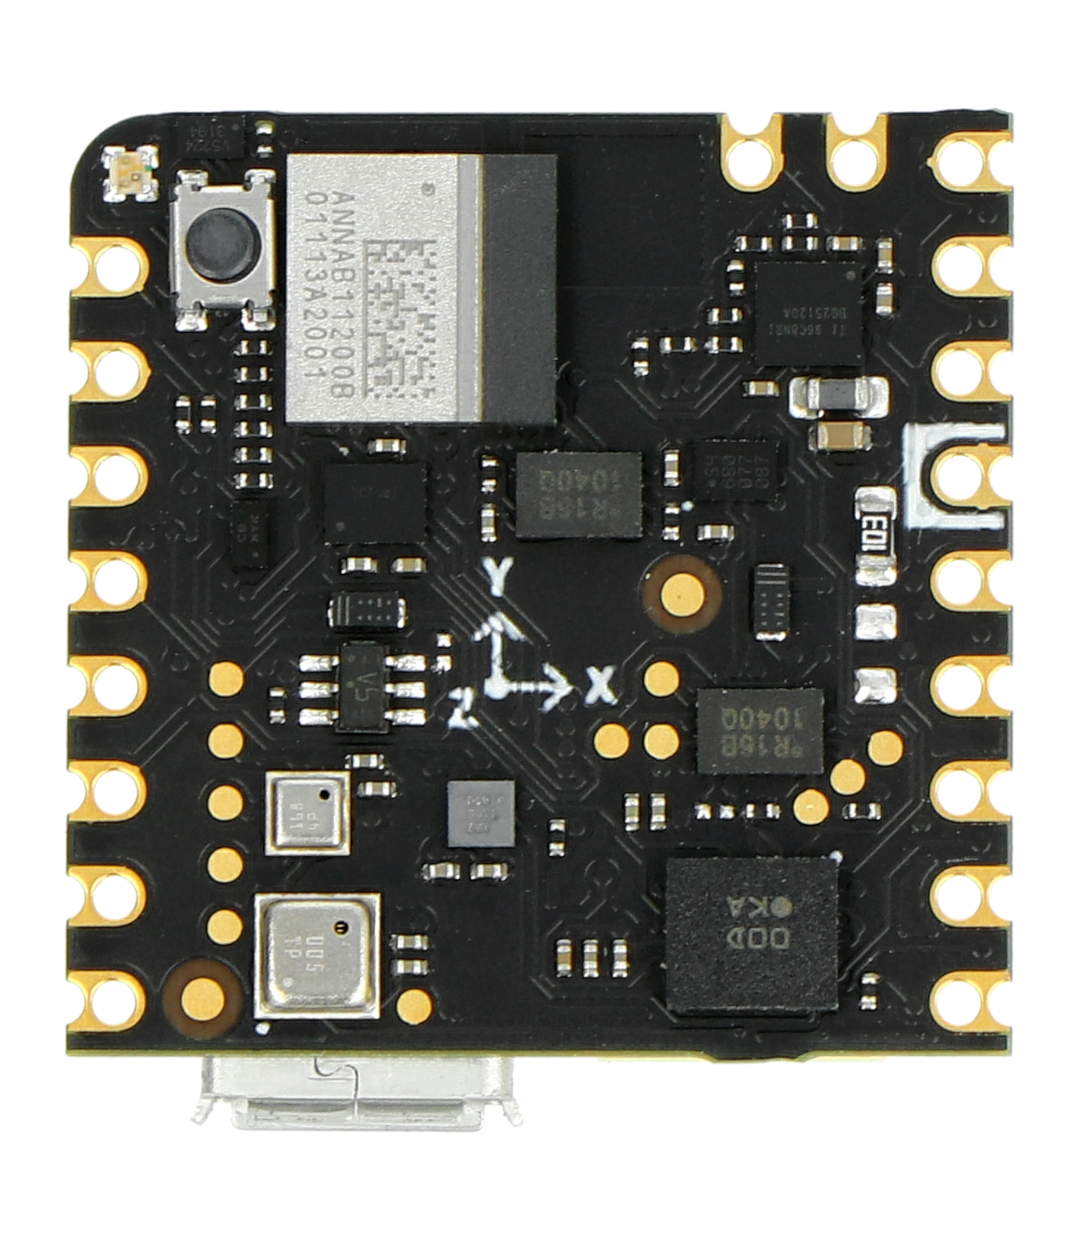
Quick Reference Values
Here are the numbers I find myself returning to most often. IMU full-scale ranges: ±2, ±4, ±8, ±16g. Default is ±4g. Use ±2g for precision work, ±16g if you expect hard impacts. BME680 heater stages: the sensor uses a multi-stage heating profile. The default is three stages at 200°C, 220°C, and 240°C. For basic temperature and humidity that is overkill. Two stages at lower temperatures extend battery life significantly with minimal accuracy loss.
Deep sleep current: approximately 5µA with RTC enabled, 1.5µA with RTC disabled. Motion wake-up adds about 200µA during the wakeup transition. USB programming: the board uses the Native USB port, not a separate programming port. Do not plug into the power-only USB-C port if you want to upload code. Only the programming port works for flashing. The cheat sheet I reference covers all of this in condensed form along with the full pin mapping and library function index. Keep it open while you work. You will save more time than you expect just from not second-guessing which function initializes which sensor.