Building a Robot Hand from Scratch
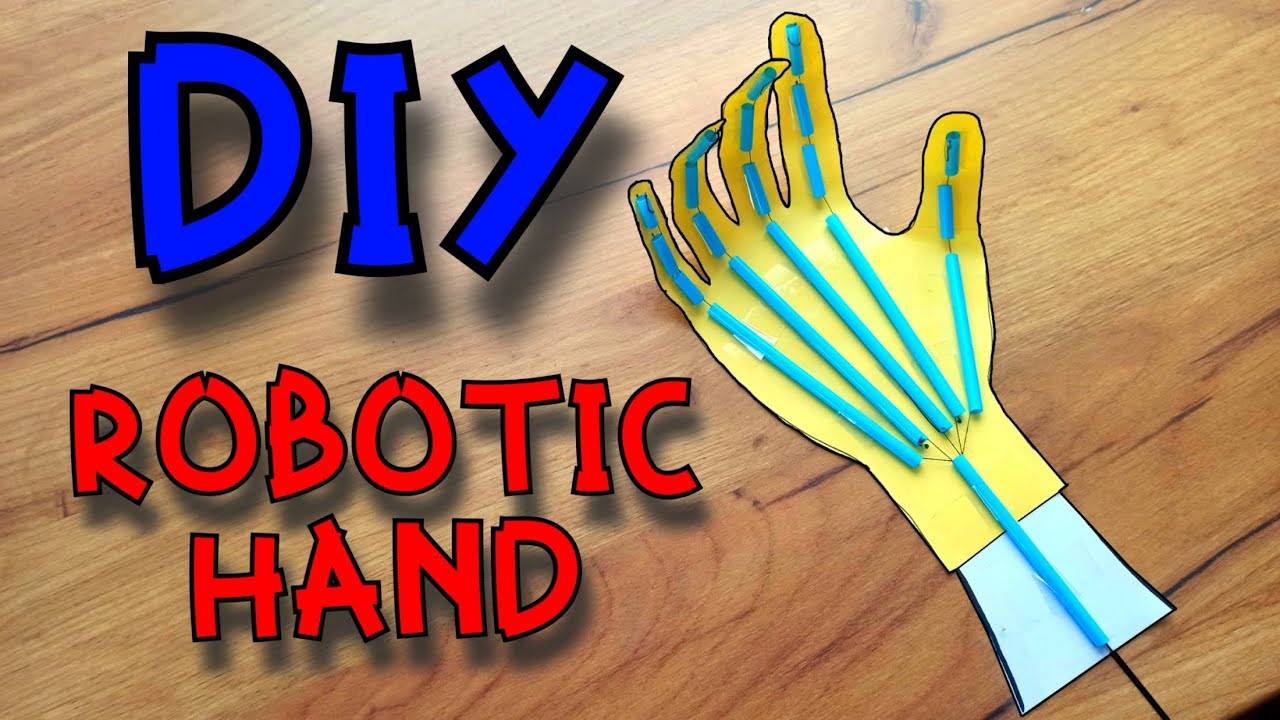
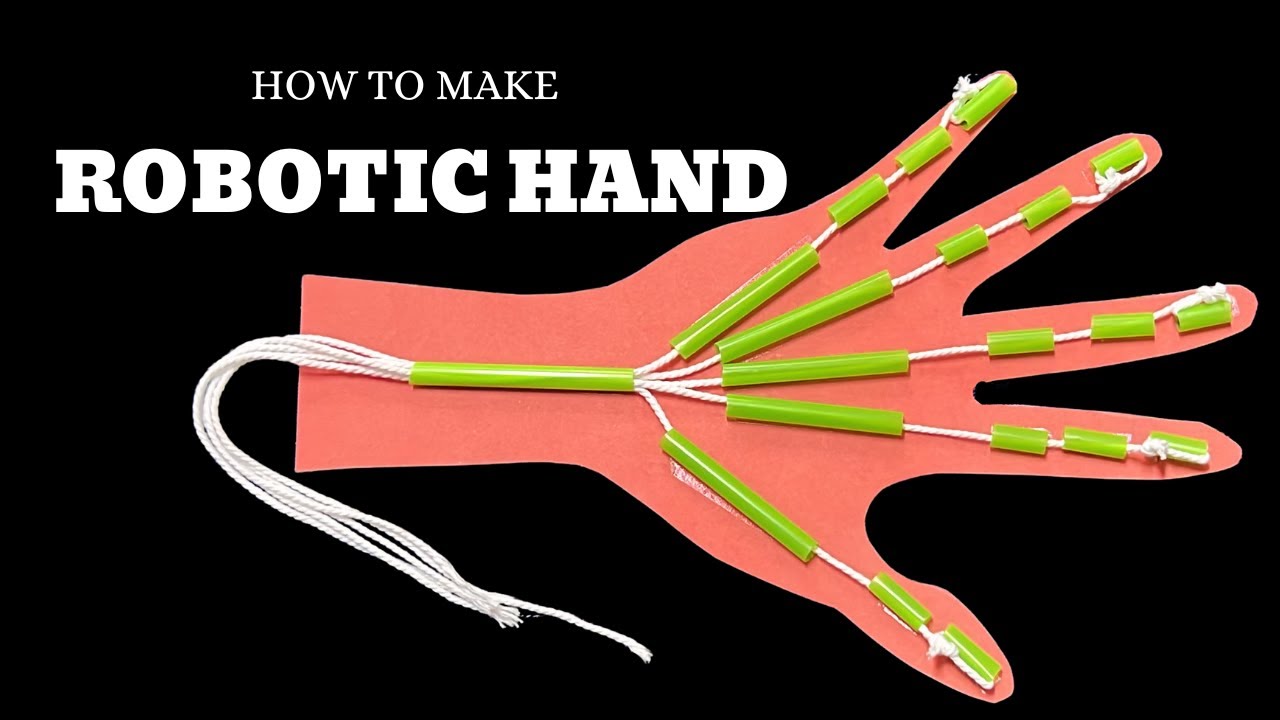
You pick up some silicone tubing, a few servos, and a microcontroller. Then you figure out the rest. The Robot Hand Science Project sounds straightforward until you try to make the fingers curl without snapping the tendons or stalling the motors. I built three of them over the past couple years, and they all taught me something I hadn't expected. The basic anatomy isn't hard. Five digits, a palm base, flexor tendons that pull when servo motors rotate. Each finger usually has one or two servos, and the thumb gets its own mechanism because it opposes the other fingers differently. The tendons are typically nylon string or fishing line threaded through small holes drilled into what serves as phalanges. You can use 3D-printed parts, balsa wood, or even hot glue and cardstock if you are working on a tight timeline and don't mind the parts degrading over time.
Robot Hand Science Project Wiring and Code Basics
The electronics side is where most people get stuck, not the mechanical design. I used an Arduino Nano and a PCA9685 servo driver board. The Nano alone cannot drive multiple servos reliably because the 5V line collapses under load when more than two or three motors move at once. The PCA9685 handles the PWM signals independently and draws power from a separate 5V source, which keeps the logic board stable. A single 5V 4A wall adapter is plenty for five to six micro servos depending on your torque requirements. For the code, start simple. Map each servo to a finger using the servo library, write functions that set them to open and closed positions, then add a potentiometer or flex sensor for input. The flex sensor approach gives you something closer to a real prosthetic feel, but it requires calibration because every sensor's resistance curve is different. I stopped trying to generalize calibration between sensors and just accept that each finger needs its own offset and scale values stored in EEPROM. That way you change the sensor and the hand still works without rewriting the whole sketch. The mechanical tendon routing deserves more attention than it gets in most tutorials. If you pull the string from the servo directly to the fingertip in a straight line, the finger will bend but the tip won't curl tightly because the moment arm changes as the joint rotates. I learned this the hard way when my index finger would close halfway and then just vibrate against the stop. The fix was drilling a second anchor point partway along the finger segment so the tendon path creates a compound lever effect. I used Super Glue mixed with baking soda to secure the anchor points since hot glue peels off PLA after a few cycles of tension.
One thing nobody warns you about is servo gear stripping. Cheap SG90 and MG90S servos have plastic gears that fail under unexpected load. If a finger gets jammed while the motor is still commanded to close, the gear strips within seconds. I started adding a simple current limit in firmware by monitoring the servo supply rail with a voltage divider into an analog pin. When the current draw spikes beyond a threshold, the code cuts power to that channel immediately. This has saved me three stripped gearboxes already. Another counter-intuitive detail is that more servos do not equal a better hand. A five-servo configuration mapped one-to-one to fingers sounds logical, but the thumb becomes the problem. The thumb needs abduction and opposition movement, which a single servo cannot replicate cleanly. I switched to a four-servo design where the index through pinky each get one servo and the thumb is actuated by a cam mechanism powered by the index servo's spare range. It sacrificed some independent thumb control, but the overall grasp stability improved noticeably because the thumb no longer competed for PWM channels. Power management is another area that causes unexpected behavior. If you power the servos and the microcontroller from the same USB port, the microcontroller will brown out and reset whenever multiple servos start moving simultaneously. This looks like a code bug to beginners. It is not. Use a separate power rail for the servos with a common ground, and add a 1000 microfarad capacitor across the servo power input to smooth out the current spikes. The capacitor is cheap and it eliminates more mystery resets than any amount of debugging will.
Get the Full Details

Calibration for sensor-based control takes more time than the build itself. A flex sensor on the index finger might read 300 at rest and 800 when fully bent, but those numbers drift with temperature and aging. I settled on storing a two-point calibration per finger at startup, then using linear interpolation for the mapping. It is not perfect, but it is stable enough for a science project presentation and it does not require machine learning libraries that add unnecessary complexity. If you are running low on time, there is a quicker path that still demonstrates the core principles. You can buy a pre-made robot hand kit and modify it rather than building from scratch. The kits cost between thirty and eighty dollars depending on quality, and they come with the mechanical parts already engineered. The trade-off is less learning because you skip the structural design phase. For a classroom demo that needs to work on day one, the kit route is acceptable. For actual understanding of how the hand functions, building the components yourself is worth the extra weekend hours. The hardest part I encountered was making the hand grip objects of varying sizes without crushing them or letting them slip. A rigid silicone fingertip with a flat surface slides off round objects every time. I solved this by wrapping the fingertip in a small piece of silicone rubber tubing cut from a shower curtain, which added enough friction to hold a plastic bottle or a wooden block without needing adaptive grip algorithms. The modification took about ten minutes and made the difference between the hand working and not working.
Documentation matters more than people expect. If you are presenting this as a science project, the judges will ask about your design iterations and why you chose certain components. Keep notes on each version, including what failed and why. I kept a cheap notebook and sketched each prototype with measured dimensions and servo angles. This turned out to be the single most useful thing I had going into the evaluation, because it let me answer technical questions confidently instead of guessing.