Building a Robot Risk Assessment That Actually Works
The most common mistake I see when people ask for a Robot Risk Assessment Template Excel is that they buy or download a generic sheet and try to force it onto their machinery. It doesn't work that way. Risk assessment is procedural, not cosmetic. The template has to reflect your actual process, your actual hazards, and your actual regulatory environment. ISO 12100 is the baseline standard, but what matters far more is whether the document holds up when an auditor asks follow-up questions three weeks after you file it. I spent six months with a team trying to use a pre-made template for a collaborative robot cell. The template had columns for hazard identification, risk estimation, and control measures. Standard stuff. The problem was that it treated every risk category the same. Crushing, shearing, entanglement, thermal, electrical — they all had the same scoring weights. In reality, the severity of a crushing hazard on a robot wrist joint is fundamentally different from a thermal hazard on a nearby surface. When we tried to apply identical matrices across categories, the resulting risk rankings made no practical sense. A low-severity electrical hazard with high probability got scored higher than a moderate-severity crushing hazard with reasonable probability. The workaround was to build separate severity tables per hazard category. Instead of one generic score, each category had its own severity definition. For crushing, severity ranged from minor bruising to amputation. For thermal, it ranged from skin warming to second-degree burns. This changed the RPN calculations significantly and produced a result that matched what our safety team actually observed on the floor. The template itself became more complex, but the output was defensible.
The Actual Structure You Need
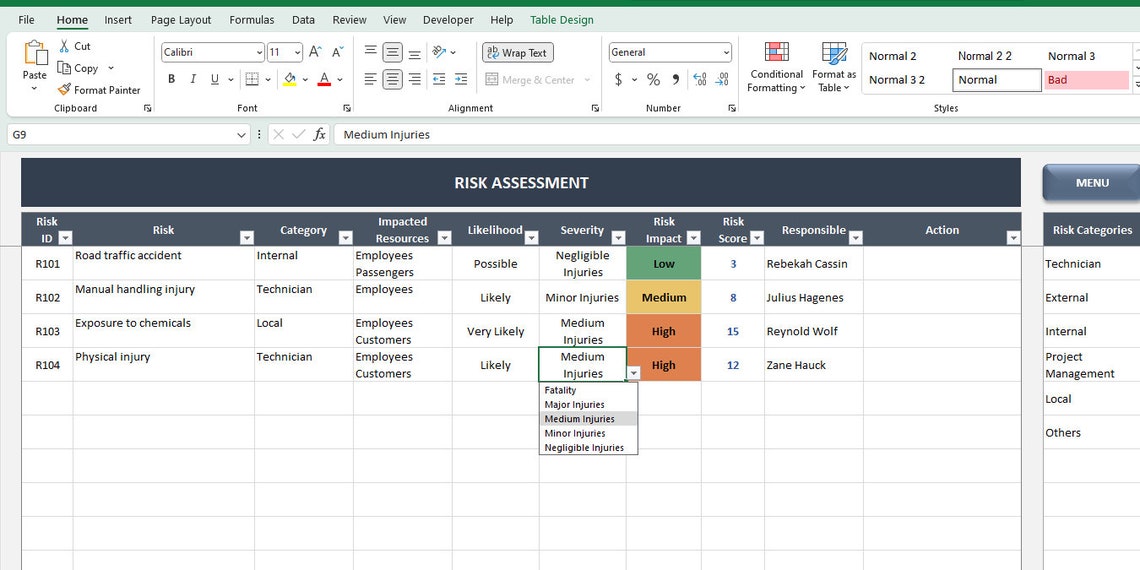
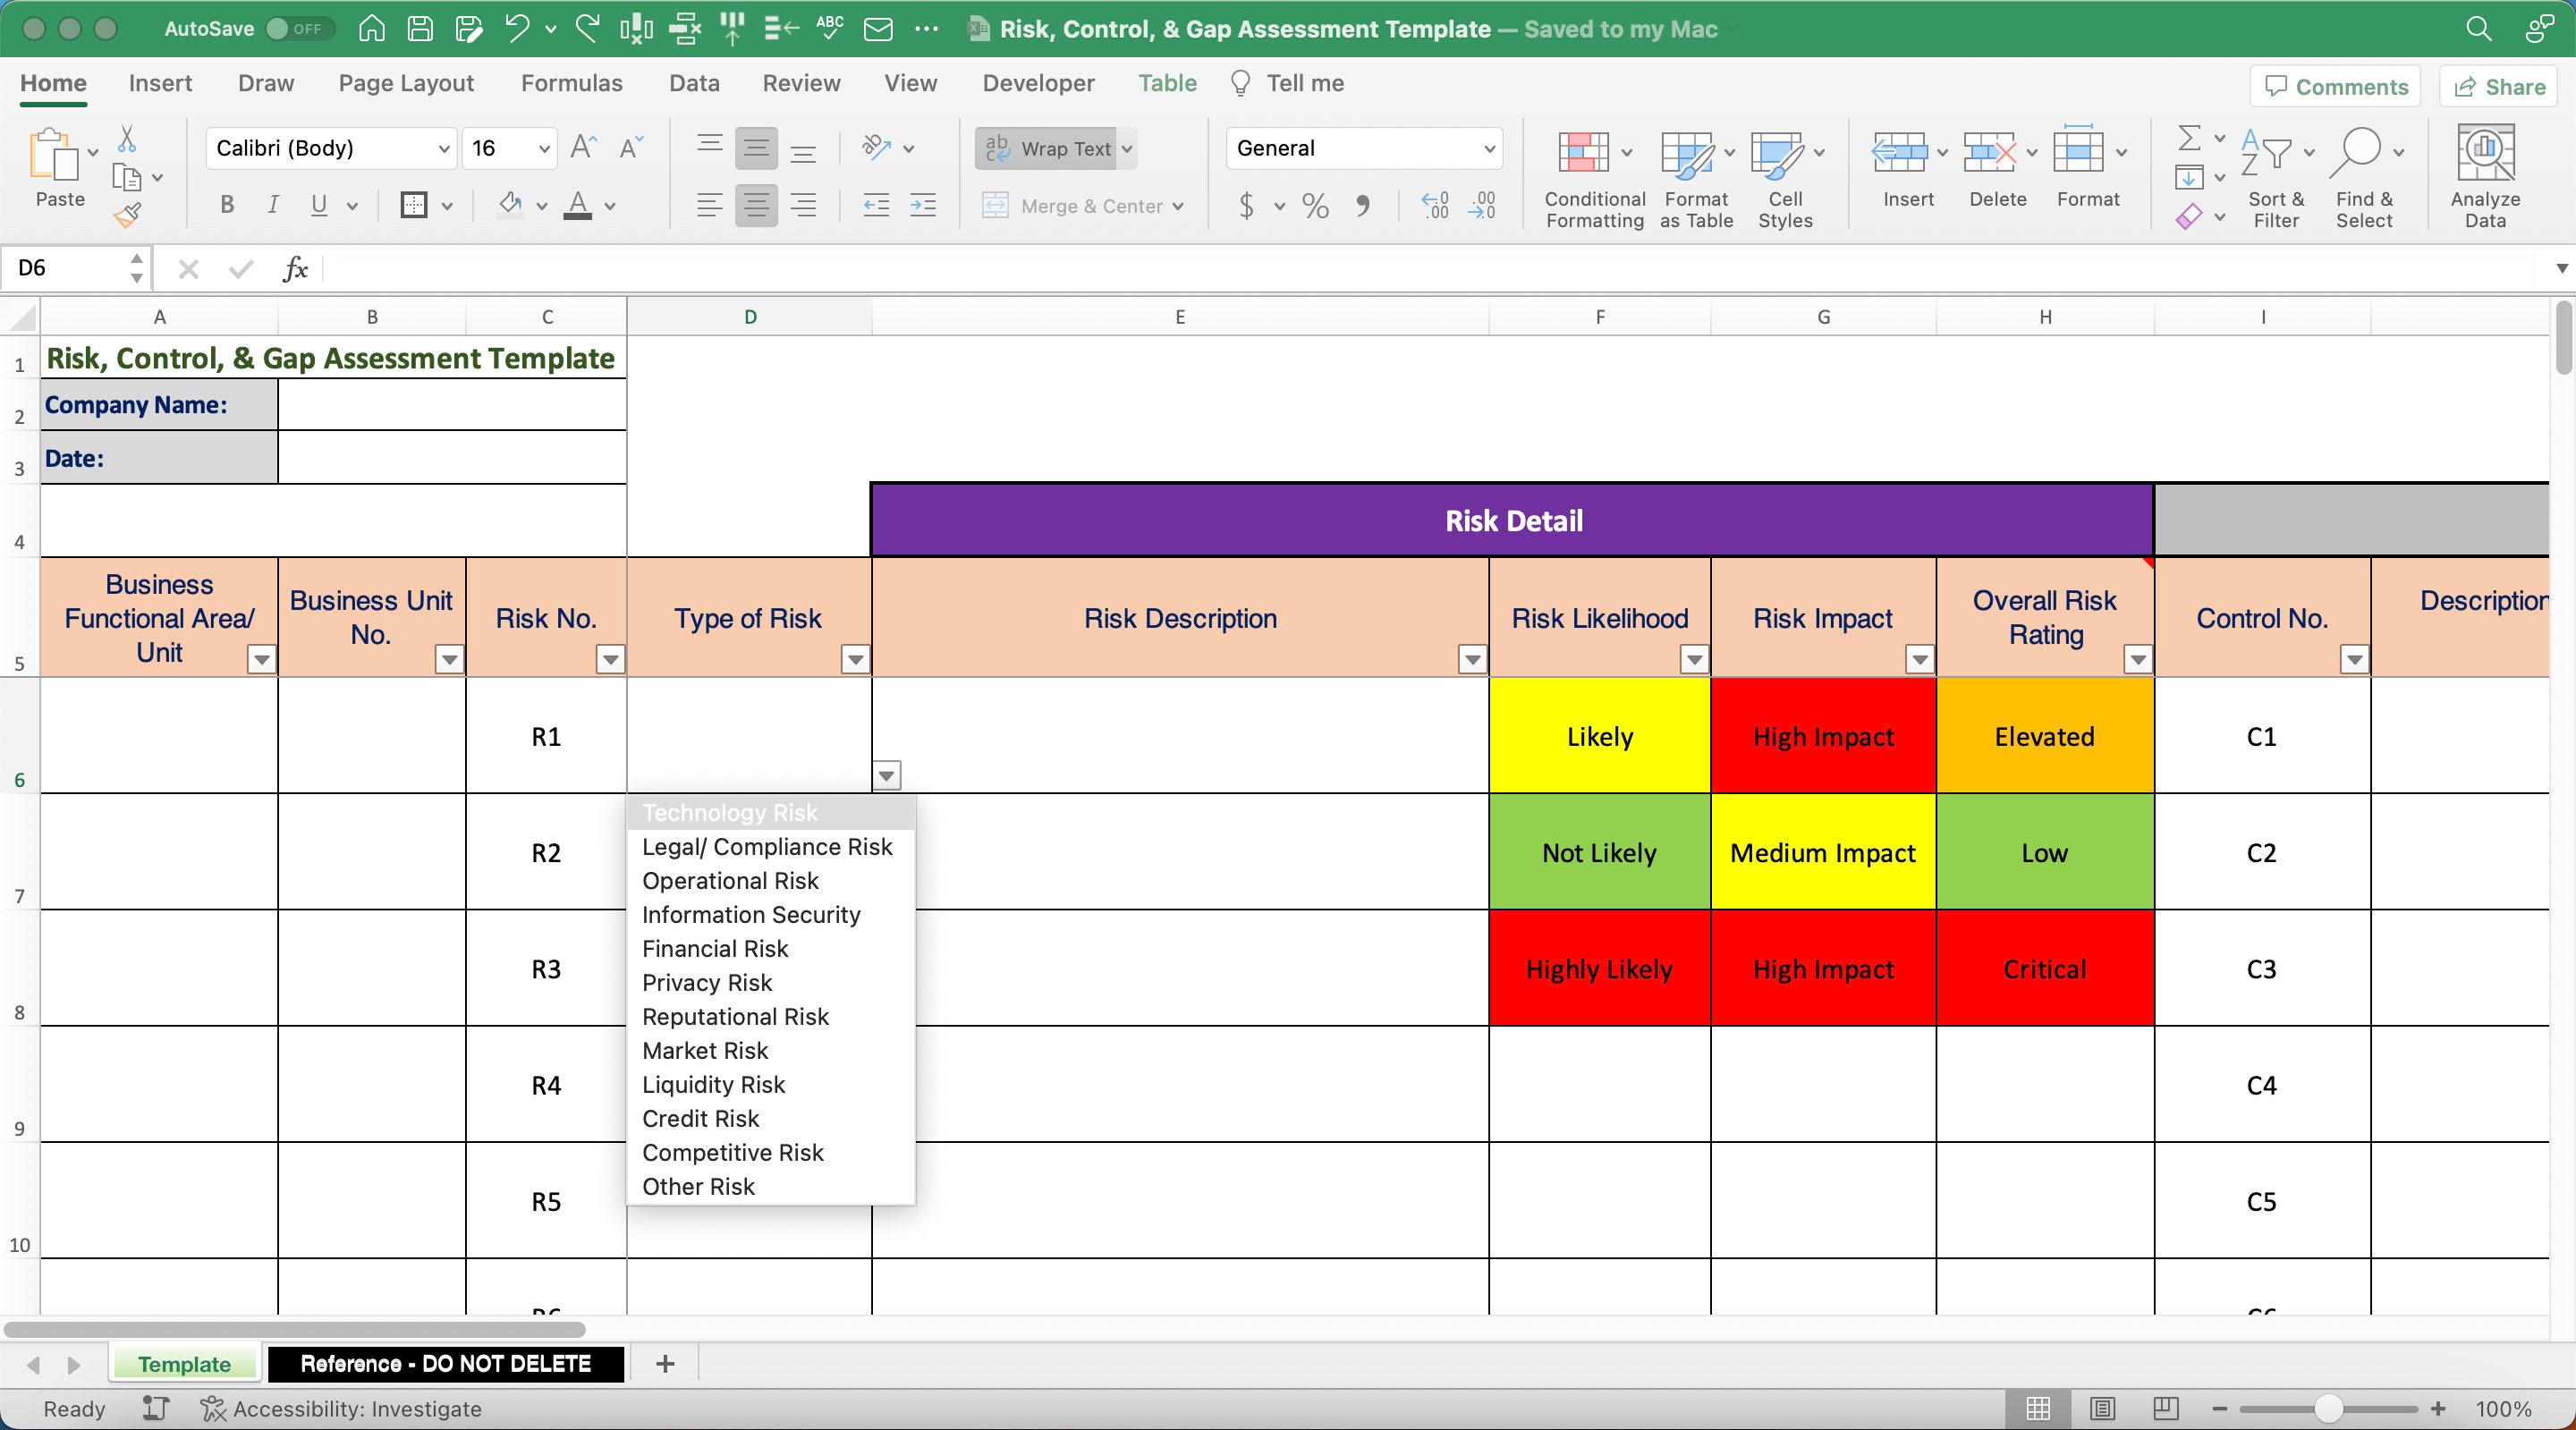
A functional Robot Risk Assessment Template Excel needs five interconnected sections. The first is a system inventory. This lists every robot cell, its make and model, workspace boundaries, payload capacity, and speed rating. Don't skip the speed rating. ISO 10218 and ISO/TS 15066 both use speed as a key variable in collaborative mode classification, and if you're not documenting it, you're missing something auditors will notice. The second section is hazard identification. This should be organized by hazard type and by zone within the cell. A single robot cell has multiple zones: the robot workspace itself, the teach pendant operating area, the component loading zone, the maintenance access area, and any adjacent shared pathways. Each zone has different risk profiles. The teach pendant area has different exposure scenarios than the robot workspace. Your assessment should reflect that separation. The third section is risk estimation. This is where most templates fail because they use static scoring. Risk estimation should account for exposure frequency and duration. A robot that runs at full speed for eight hours daily poses a different risk than one that runs at reduced speed for thirty minutes between cycles. If your template doesn't have a field for duty cycle or operational pattern, it's not useful for real assessment work.
Calculating Risk Priority Numbers in Excel
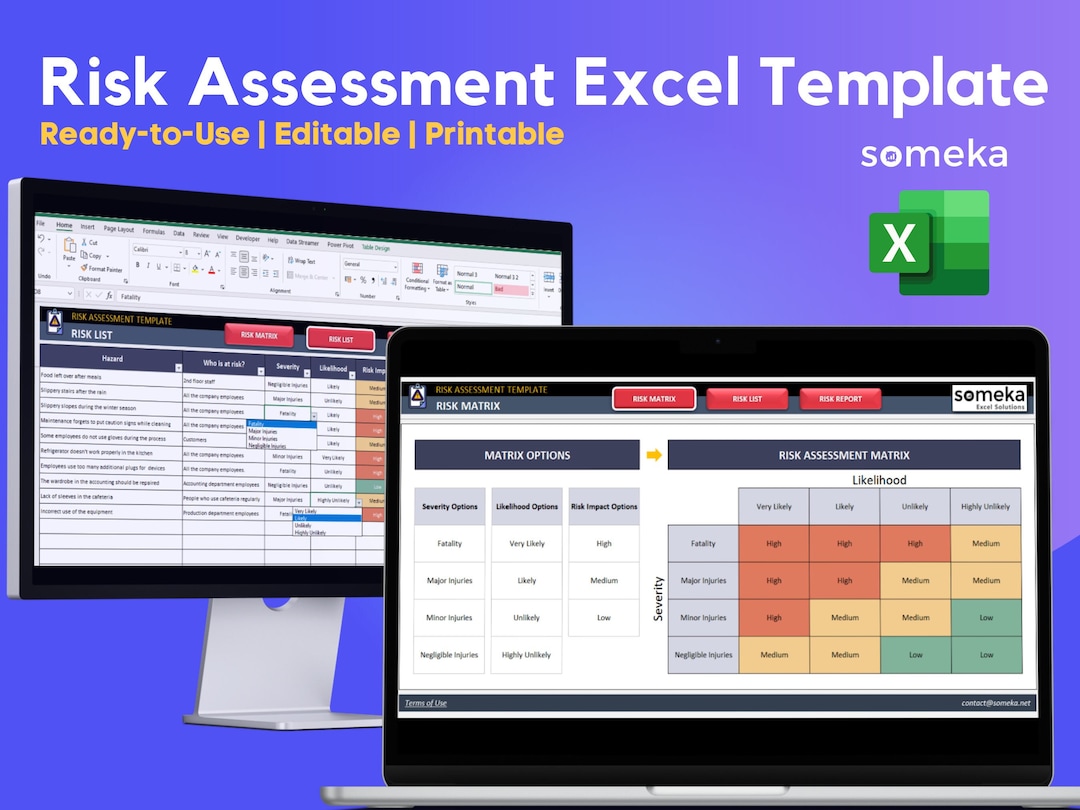
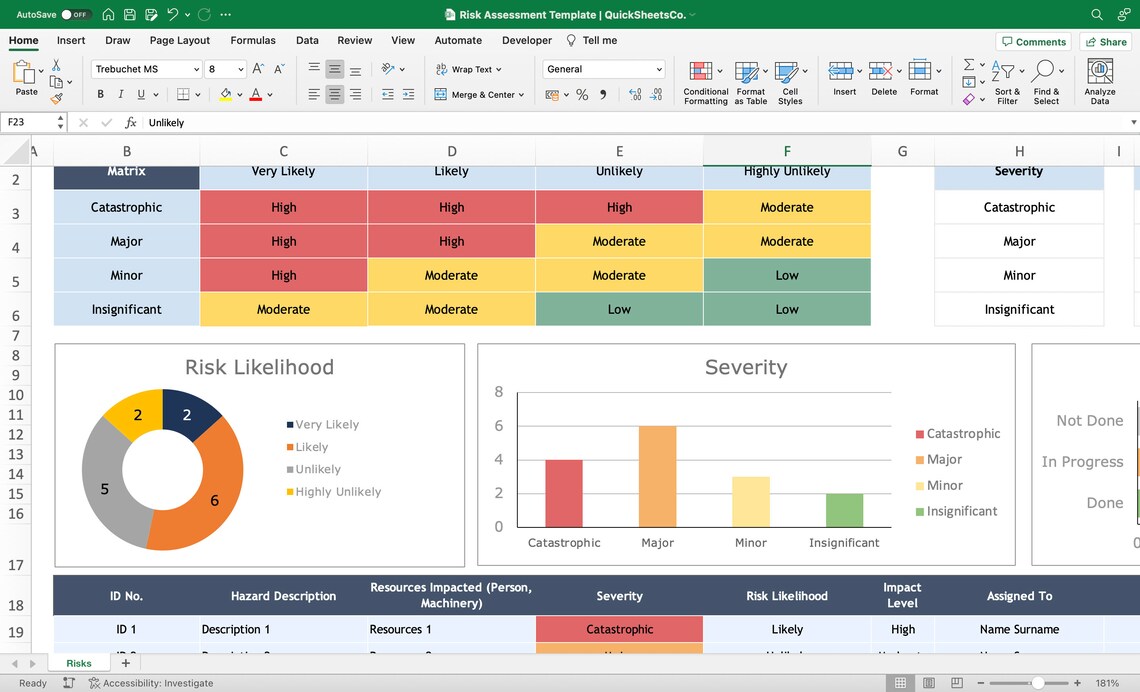
The formula is straightforward but requires careful parameter definition. RPN equals severity multiplied by occurrence multiplied by detection. Severity ranges from one to ten, occurrence from one to ten, and detection from one to ten where one means almost certain to detect and ten means virtually impossible to detect. The tricky part is defining occurrence and detection objectively. Most people default to guesswork here. I recommend anchoring occurrence to documented data where available. If your robot has logged collision events, use that. If the cell has safety-rated monitoring functions in place, reduce the occurrence score based on the proven performance level. Detection scoring should factor in whether safety functions are actively monitoring and whether they have a known response time. A safety PLC with a 50-millisecond response time is not the same as a simple light curtain with no monitoring integration. For a Robot Risk Assessment Template Excel, I'd structure the calculation so that each hazard row produces its own RPN, and then group them by zone and by control measure tier. This lets you see where the highest risks cluster and whether your current controls are sufficient. You should also calculate a residual risk score after controls are applied, because the whole point of the exercise is to demonstrate that residual risk is acceptable.
Get the Full Details
Common Pitfalls That Will Get You in Trouble
One issue I've seen repeatedly is treating speed and power limits as sufficient controls for collaborative robots. ISO/TS 15066 provides specific force and pressure limits, but those limits assume proper force monitoring is installed and calibrated. If your assessment documents the limits without documenting that the monitoring system is actively tested and maintained, an auditor will flag it. The control measure isn't the limit value itself. The control measure is the monitoring system that enforces it. Another pitfall is failing to address unexpected robot behavior. Most templates focus on normal operation. They don't account for what happens during a fault condition, a power loss recovery, or a manual override. A robot that resumes a program after an emergency stop may not be in the position the operator expects. This is a real hazard, and it should appear in your assessment. I once reviewed an assessment where a robot cell had zero documented risk for fault recovery because the template only covered steady-state operation. You also need to document who is exposed and how. Operators, maintenance personnel, cleanroom staff, visitors. Each group has different exposure patterns and different levels of training. A risk assessment that says "personnel" for every exposure category is too vague to be useful.
Building Your Own vs Using a Pre-Made Template
If you have access to Excel and understand the basic principles, building your own template takes roughly two to three hours for the first version. After that, individual assessments take about fifteen to twenty minutes per robot cell. A downloaded template might seem faster, but if it doesn't account for your specific setup, you'll spend more time modifying it than you would building from scratch. I've spent days editing someone else's template to make it usable. Building my own structure takes less effort overall. The downside of a custom template is that you have to maintain it yourself. If standards change, you update your template. If you're using a vendor's template, you're dependent on them updating it. With ISO standards getting revised periodically, this is a real consideration. ISO 12100 had a major revision, and any template that hasn't been updated to reflect it is already behind. For smaller operations with limited robot cells, a well-structured downloaded template can work if you adapt it carefully. The critical thing is that you actually adapt it. Copying and pasting hazard descriptions from a generic template without modifying them for your equipment is not an assessment. It's documentation theater, and it won't survive scrutiny.
What the Template Should Output
A good template produces a clear hierarchy of risks. At the top, you should have risks that require immediate action because they exceed acceptable thresholds even after existing controls. In the middle, risks that are borderline and benefit from additional measures. At the bottom, risks that are acceptable with current controls but should be monitored. This ordering matters for prioritizing your safety budget and your audit responses. The template should also produce a control measure register. This lists every safety function installed in your cell, its performance level or category per ISO 13849, its test interval, and its last test date. If a control measure appears in your assessment but not in your maintenance schedule, that's a gap. Auditors check for exactly this kind of disconnect. Finally, the template should generate a summary page. This is what you hand to management and what you show during an audit. It should list each robot cell, the number of hazards identified, the number exceeding acceptable risk, the key control measures, and the next review date. One page per cell is plenty. More than that, and you're overcomplicating the deliverable.

The template itself isn't the assessment. It's a tool for organizing your analysis. The value comes from how thoroughly you've actually examined your equipment, your processes, and your operating conditions. No spreadsheet will substitute for standing in the cell and watching how people interact with the robot during a full shift cycle.