Getting a Robot to Do Something Actually Useful at a Science Fair
The hardest part isn't building the robot. It's convincing the judges that your project is science and not just an Arduino kit from Amazon with some tape on it. I've sat through about forty science fairs over the years, and the ones that actually impress have one thing in common: they ask a question that takes real effort to answer. Robotic Science Fair Projects work best when you're testing a hypothesis, not just showcasing a cool machine. A robot that follows a line is a demo. A robot that tests whether different surface textures affect energy efficiency in locomotion is a project. The difference matters because the judges can smell "I made something move" from across the room.
Designing Robotic Science Fair Projects That Judges Take Seriously
Start with the question, not the parts. I see too many students grab a motor controller and a couple of servos and then spend three weeks figuring out what problem they're actually solving. Flip that. Pick something you're genuinely curious about. Maybe it's whether a specific gait pattern reduces power consumption on uneven terrain. Maybe it's whether sensor placement affects obstacle avoidance accuracy. Write the question down on an index card and tape it to your workspace. If you catch yourself forgetting what the card says, you've already started building before you were ready. From there, keep the variables manageable. The single most common mistake I've watched wreck perfectly good projects is introducing three independent variables when the time limit only allows for one. You need a control group, a test group, and enough repeated trials to make anyone with a statistics background nod approvingly. Four trials minimum. Six if the data is noisy. Eight if you want to be safe. The hardware side is where things get finicky. I built a project once where I was testing traction on different surfaces using a simple differential drive robot with a strain gauge on the axle. Everything worked perfectly until I connected the power supply. The moment the battery loaded under demand, the voltage sagged and threw off every reading on the force sensor. I spent an entire evening swapping between a bench power supply and a battery, then realized the fix was just isolating the sensor circuit from the motor circuit with a separate 5V regulator. That was the project's real lesson: power integrity matters more than any code optimization. The robot performed the same, but the data became reliable only after I stopped treating the power system as an afterthought.
The Build Process Nobody Talks About
Most people jump straight into coding and assume the mechanical side will hold together. It usually doesn't. I always build the frame and chassis first, verify the center of gravity, and only then start worrying about sensors. A robot that tips over at a five-degree incline doesn't care how elegant your PID loop is. For the coding, keep it simple and well-commented. Judges read documentation. If your code is a wall of unexplained function calls, you're handing them an excuse to dismiss your technical contribution. Name your variables something meaningful. Split your code into sections with clear headers. If you're using a library, note which version and why you chose it. This takes twenty extra minutes and often scores more points than a second sensor array ever will. Data collection is where most projects quietly fall apart. Set up a consistent logging system from day one. I use a simple CSV dump from the microcontroller to an SD card, and I write the readings to a spreadsheet the same night every session. The difference between collecting data ad hoc and collecting it on a schedule is the difference between clean charts and a desperate three-hour spreadsheet cleanup before the fair starts.
Get the Full Details

Common Pitfalls That Sink Good Projects
Overcomplicating the robot is the biggest one. Every extra sensor, every additional joint, every autonomous feature you add is a potential failure point on stage. Judges would rather see a simple robot that demonstrates a clean experimental method than a complex one that does everything poorly. The project is about the science, not the automation level. Another trap is the absence of error bars. Running an experiment once and presenting the results as fact is a fast track to a mediocre score. Even basic error bars — standard deviation, range, whatever your grade level calls for — show that you understand variability. It's a small addition that separates casual hobbyists from people who actually did an experiment. And don't skip the calibration step. I once watched a student present three weeks of data without ever calibrating their ultrasonic sensor against a ruler. The entire dataset was systematically off by about twelve percent. Calibration takes ten minutes. Skipping it can invalidate six weeks of work. Do it before you start collecting real data, and note in your report exactly how and when you calibrated. That's the kind of detail that makes reviewers take you seriously.
What to Bring on Presentation Day
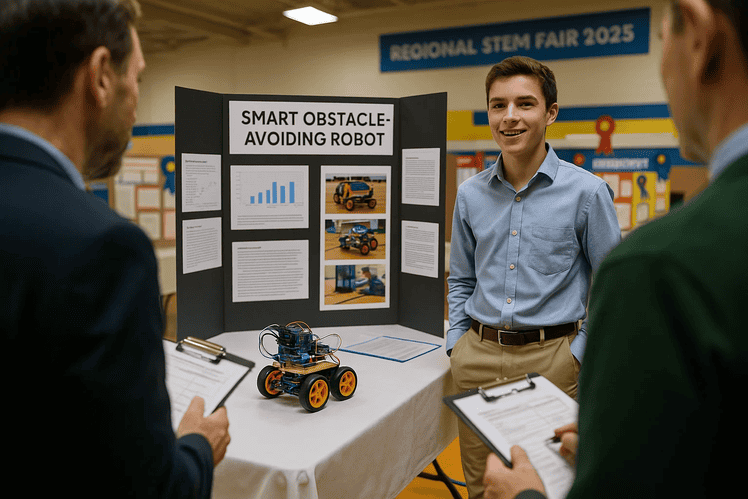
Bring a working model, a poster, and backup data on a USB drive. Your robot should run from start to finish without you touching it. If it needs manual intervention, demonstrate it once, then explain why the automatic process failed and what the data still shows. Honest failure is better than a staged success that wobbles under pressure. Practice your explanation out loud at least three times before the fair. You'll be surprised how many things sound fine in your head but come out tangled when spoken. Time yourself. Two minutes is usually the limit before the judges start checking their watches. The whole process from question to fair typically takes six to eight weeks if you're working on top of regular school commitments. Everything compresses badly in the final week. Start the build phase within the first two weeks. Leave the last ten days for data refinement and presentation practice. That pacing keeps you from panicking during the final stretch.