3D Running Animation Fundamentals
Working with real-time 3D character locomotion requires understanding how the engine handles skeletal animation, physics simulation, and input processing simultaneously. Most tools I've encountered follow similar pipelines regardless of their branding or marketing name. If you're looking at a project called Santa Run 3D or something similar, the underlying technique is usually standard polygonal character animation. You start with a rigged mesh, import an animation clip, and configure the state machine. That part is straightforward. The complications emerge when you try to blend locomotion cycles with environmental interaction. I spent three months debugging a character controller where foot sliding happened whenever the ground normal changed by more than fifteen degrees. The solution wasn't in the animation files — it was in the root motion extraction settings. Most documentation glosses over this. You have to disable root motion on the movement skeleton and apply translation separately through the transform component. Takes about ten minutes once you know what flag to change, but I lost two weeks chasing animation timing issues that had nothing to do with the clips themselves.
Frame Rate Targets and Interpolation
Running animations in real-time 3D environments need to handle variable frame pacing. If your target is sixty frames per second but the average drops to forty-five during complex scenes, animation playback speed becomes inconsistent unless you're using fixed timestep interpolation. Most engines allow you to separate physics updates from render updates. Set the physics timestep to a constant value — sixteen milliseconds is standard — and let the renderer run at whatever framerate it can achieve. This means your character runs at consistent speed regardless of visual frame rate. The tradeoff is input latency. Fixed timestep physics introduce roughly one physics frame of input delay. For a platformer this is negligible. For a precision action game you might notice it. I've seen teams switch to variable timestep with clamping as a compromise, which reduces latency to about five to eight milliseconds while keeping animation reasonable. Your mileage varies depending on the engine version.
Animation Blending and State Machines
Character controllers typically use layered animation blending. The base layer handles idle, walk, and run cycles. An upper body layer handles aiming or carrying objects. AIK blend trees smooth transitions between states instead of cutting abruptly between animation clips. Without blend trees you get the stuttering effect where characters appear to teleport between poses for a single frame. The standard approach uses a 2D blend tree with velocity X and velocity Z as the blend parameters. Map idle at zero velocity, walk at moderate speeds, run at higher thresholds. Set the blend duration to roughly three hundred milliseconds. Longer blends feel floaty. Shorter blends look robotic. I usually land around two hundred fifty to three hundred milliseconds for most third-person games. One thing beginners consistently miss: the transition conditions between states matter more than the states themselves. A transition from run to idle fires when velocity drops below a threshold. If that threshold is too low — below two units per second in most scale systems — the character briefly continues running animation after stopping. Set the exit time check to false and add a velocity threshold of zero point five. This forces immediate transition when movement stops.
Get the Full Details
Common Pitfalls in Locomotion Systems
Climbing or scaling geometry is where most running systems break. Characters either clip through surfaces or slide sideways along walls they should be able to climb. The fix involves raycasting ahead of the character at foot level to detect step height. If the step is below your configured max step height — usually around fifty centimeters in metric units — snap the character upward. If it's above that threshold, fall through. This prevents characters from climbing anything taller than a curbstomp while still handling normal terrain variation. Another issue: animation speed doesn't match traversal speed. When you're moving diagonal to the animation forward direction, characters appear to shuffle sideways. This happens because the run cycle is baked for forward movement only. Solution is to rotate the animation pose to match movement direction, or use a locomotion system that separates direction from animation playback. Many middleware solutions handle this automatically. Building from scratch requires quaternions to align the character's forward axis with the movement vector before applying the pose. When your character moves faster than the animation cycle can represent, you get the sliding feet problem again. The character model appears to be running in place while translating across the terrain. This is a projection issue. You're applying root motion position directly to the transform without accounting for the animation's inherent displacement. Extract the actual foot positions from the animation rig, compare them to where the feet should be based on movement speed, and add corrective translation. This is essentially inverse kinematics lite. Most full IK solutions cost thousands in licensing. The corrective translation approach gives you eighty percent of the visual quality for free.
Performance Considerations
Running animations on mobile or low-end hardware require level-of-detail management for skeletal transforms. Baking vertex animation into the mesh instead of using skeletal animation reduces CPU overhead significantly. The tradeoff is you lose blending capability. Characters can't transition between walk and run states smoothly. They play either the baked walk cycle or the baked run cycle with no in-between. A common compromise: use skeletal animation at close range and swap to baked vertex animation beyond a certain distance threshold. Six to eight meters is usually the breakpoint where players can't distinguish the difference. Test this on your target hardware. What looks fine on a development machine might drop thirty frames per second on an actual device.
When Santa Run 3D or similar tools fall short
Some platforms market simplified 3D animation tools that promise rapid character setup. These work fine for basic locomotion. They typically cannot handle variable terrain, animation blending beyond simple transitions, or physics-based movement corrections. If your project requires any of those features, you're better off learning the underlying engine directly rather than fighting the abstraction layer. I've seen projects delayed by weeks because the tool couldn't export the specific animation curve data needed for a custom state machine. The fundamental concepts — blend trees, fixed timestep physics, foot placement correction — apply regardless of which tool you use. Understanding them lets you work around limitations or know when to switch approaches. Most documentation covers the happy path. The edge cases where your character slides through walls or animates at wrong speed are rarely mentioned until someone spends a day debugging them. I still encounter issues with animation preview playback in editors being out of sync with runtime behavior. The editor shows sixty frames per second. The compiled build runs at thirty due to shader compilation overhead on first launch. This isn't a game logic problem. It's the rendering pipeline warming up. Check your profiler in a built executable, not the editor, when benchmarking animation performance. Editor frame rates are unreliable for this purpose.
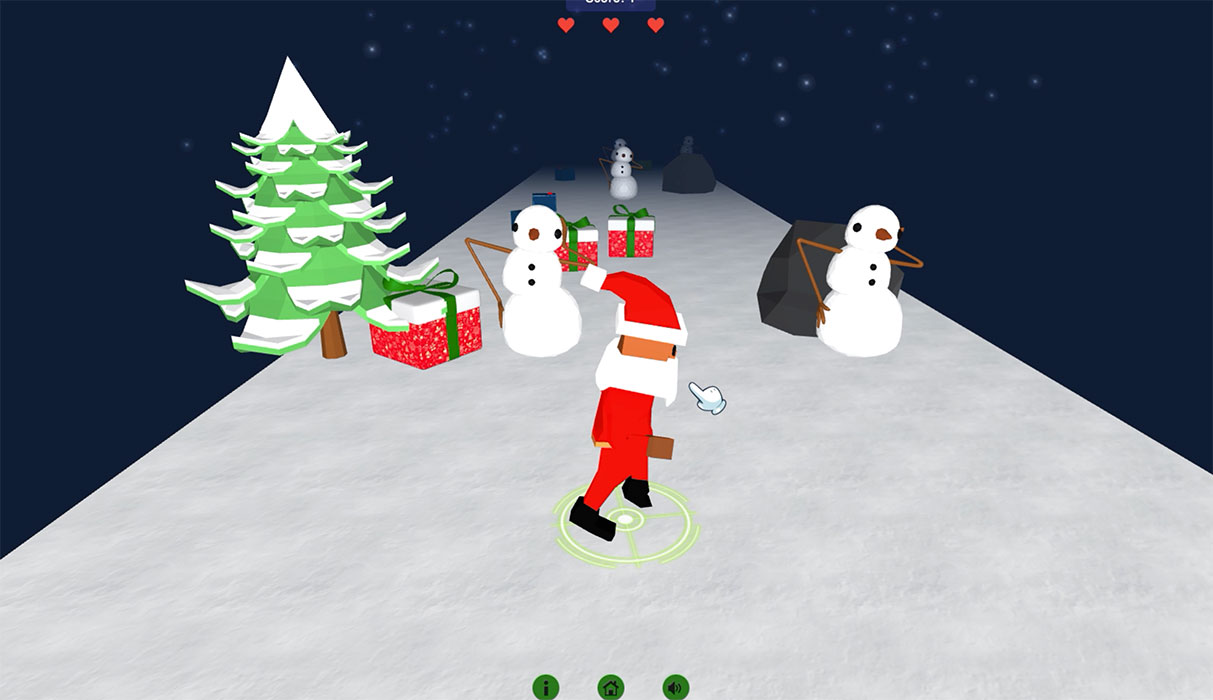
Character controllers in 3D are fundamentally about managing expectations between what the animation shows and what the physics engine calculates. When those two systems disagree, players notice. The animation might show a foot planting on the ground while the collision system places the character slightly above the surface. That half-centimeter gap is enough to break immersion without being obvious enough to investigate. Sync point positioning to the animation frame timing and recalculate collision responses only when they deviate by more than a centimeter from expected position. This reduces unnecessary physics recalculations while keeping feet planted correctly.