What the Scalar Product Actually Is
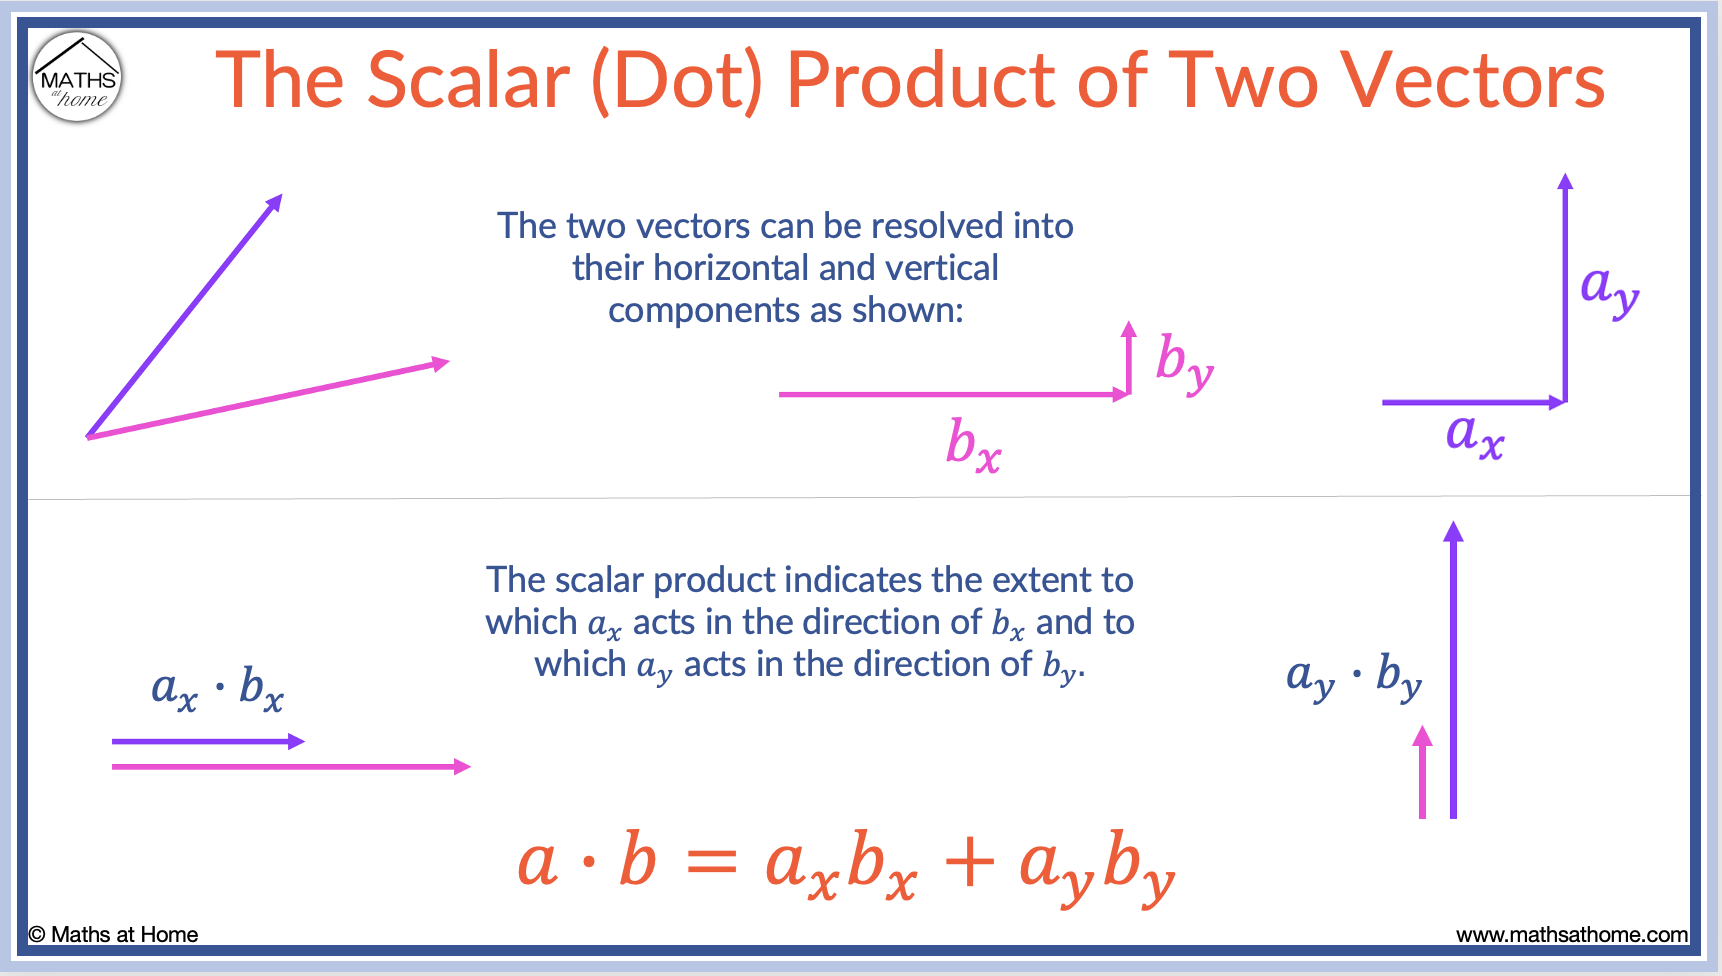
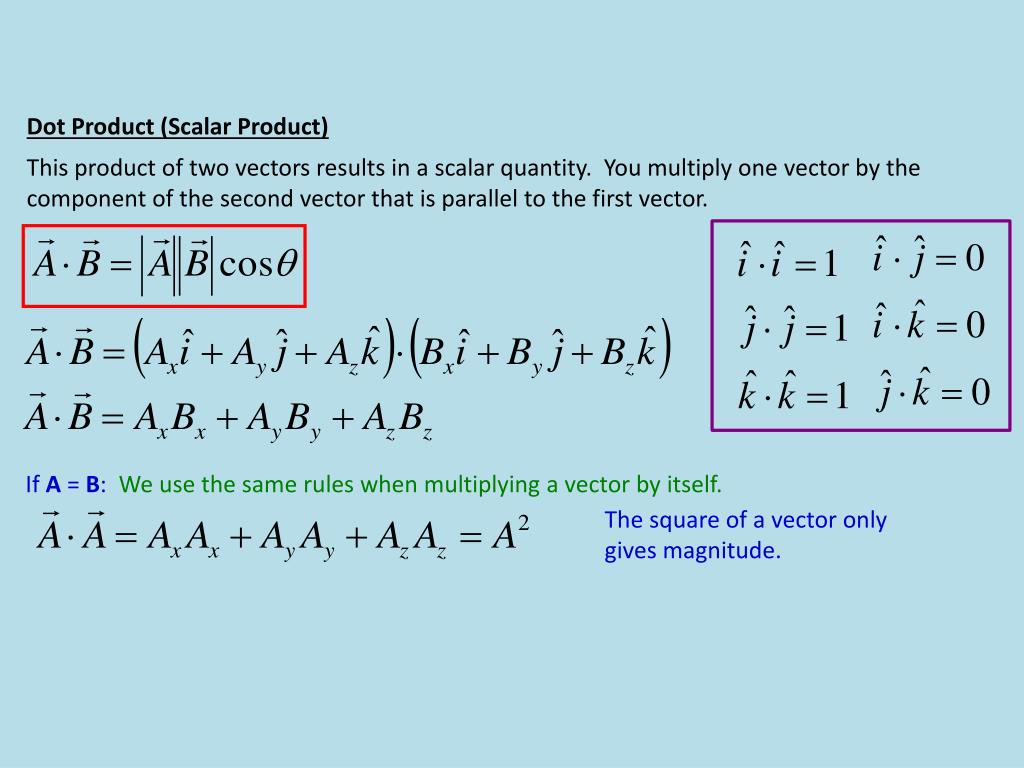
The scalar product is a way to combine two vectors into a single number, called a scalar. It tells you how much two vectors point in the same direction. That is the whole point. If they are perpendicular, the result is zero. If they point in opposite directions, the result is negative. It is that simple, which is also why people routinely overcomplicate it. There are two common ways to compute it, and you need to know both because the context decides which one to use. Component method: Multiply corresponding components and add them up. For vectors a = (a, a, a) and b = (b, b, b), the result is ab + ab + ab. This is the one you will use almost all the time in coding and physics problems where vectors are already broken into coordinates.
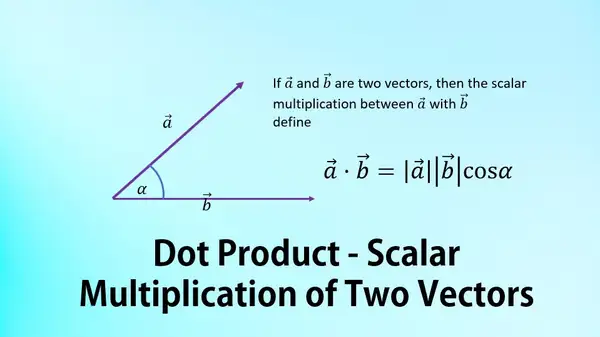
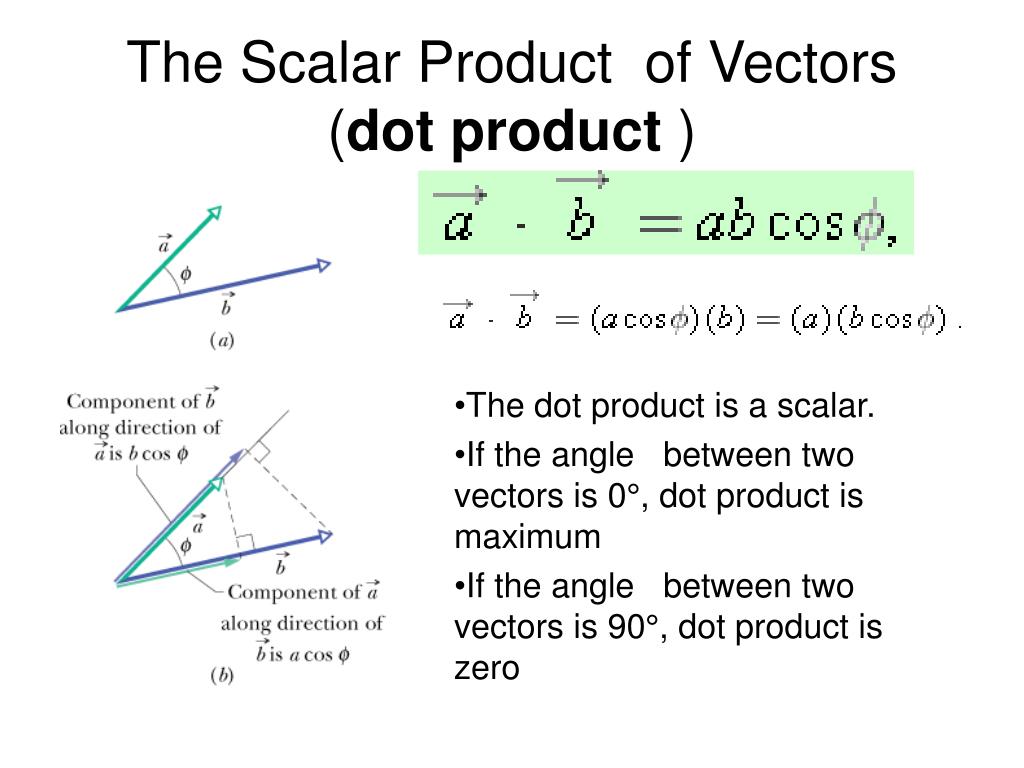
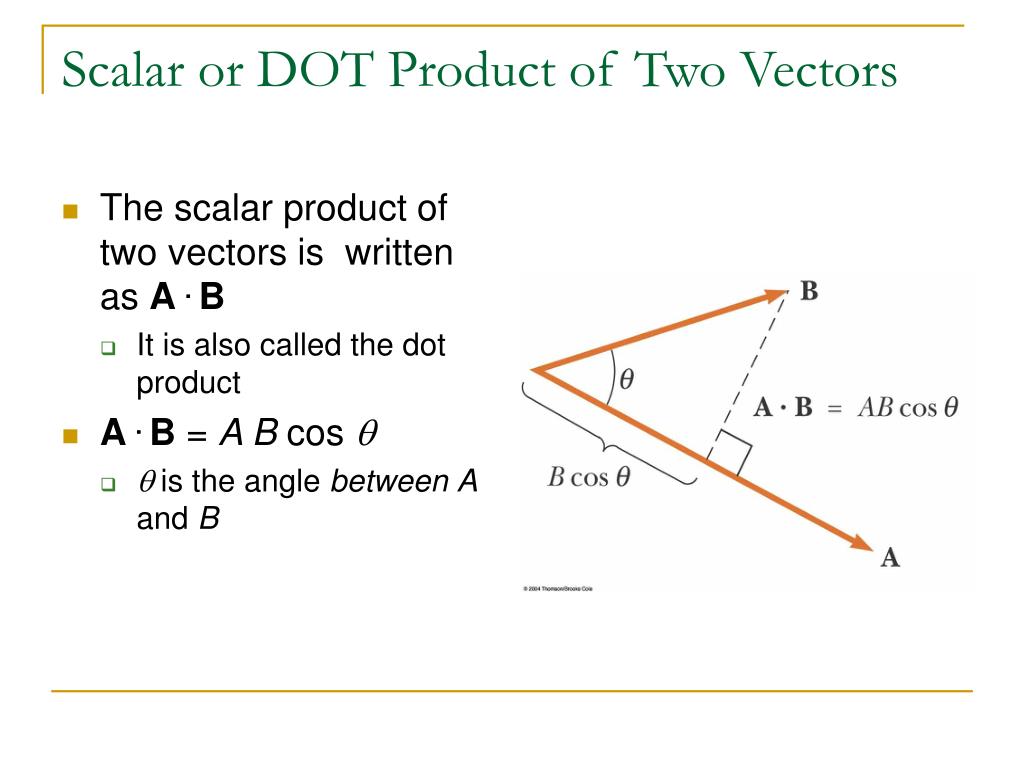
Geometric method: Multiply the magnitudes of both vectors by the cosine of the angle between them: |a||b|cos(). This version is useful when you know the angle but not the individual components. It also reveals what the scalar product is really measuring — the projection of one vector onto the other, scaled by the length of the second. I ran into a real problem once while building a collision detection system for a simple physics engine. I had two velocity vectors and needed to determine whether an object was moving toward or away from a surface. The standard approach was to compute the scalar product of the velocity vector with the surface normal. Here is the thing that went wrong: the normal vector was not normalized. I was treating it as if it had unit length, and the resulting projection values were wildly off. The objects kept tunneling through walls because the threshold check was comparing against raw, unnormalized dot product values that ranged from 0.3 to 47 depending on the frame. The fix was straightforward — normalize the normal vector before computing the scalar product — but I wasted about three hours tracking down what I thought was a floating point precision issue. It was just an unnormalized input vector. That is the kind of detail that does not show up in tutorials. Another thing people miss is that the scalar product is not a replacement for vector operations. It destroys directional information. Once you compute a dot product, you cannot reverse it. You cannot recover the original vectors from the scalar result alone. I have seen students try to use the scalar product to "solve" for an unknown vector component, which is mathematically impossible with a single equation and multiple unknowns. It produces one constraint, not a solution.
There is also a practical edge case with the geometric method. When you try to recover the angle using arccos, floating point errors can push your input slightly outside the valid range of [1, 1]. I once had a simulation produce NaN values in the angle calculation because the computed cosine came out as 1.0000000000000002 due to accumulated rounding error. The workaround is to clamp the value to [1, 1] before passing it to arccos. A one-line fix, but easy to overlook. Performance-wise, the component method is significantly faster than the geometric method in any numerical pipeline because it avoids square roots and trigonometric functions entirely. In a real-time application processing thousands of vector pairs per frame, choosing the component method over the geometric one usually cuts that operation from roughly 40 nanoseconds to about 8 nanoseconds per pair on modern hardware. That matters when you are doing it millions of times per second. The scalar product is also extremely sensitive to vector orientation in high-dimensional spaces. In machine learning, when you compute dot products between embeddings in 768-dimensional space, the values tend to cluster in a very narrow range because the curse of dimensionality makes all vectors approximately orthogonal. This is not a bug in the mathematics, but it is a genuine limitation if you are using dot product similarity as a proxy for semantic similarity in high-dimensional embedding spaces. Cosine similarity, which is essentially the normalized scalar product, handles this better because it removes the magnitude component and focuses purely on angular difference.
Get the Full Details

If you are working in code, most numerical libraries handle the scalar product through built-in functions. In NumPy it is numpy.dot() or the @ operator. In GLSL it is dot(). These are highly optimized and will use SIMD instructions under the hood. Writing your own loop for the component method is rarely faster unless you have a very specific reason to bypass the library.
When the Scalar Product Fails You
It does not work well when you need to preserve direction. If your problem involves rotating, projecting onto a subspace, or finding perpendicular components, the scalar product gives you less information than the cross product or a full projection matrix. Do not reach for it when a vector output is what you actually need. It also breaks down in non-Euclidean geometries. If you are working on a curved manifold or using a non-standard inner product space, the standard scalar product formula assumes an orthonormal basis. Change the metric and the formula changes. This comes up in general relativity and some areas of computer graphics with non-uniform scaling. Normalize your basis vectors or switch to the general inner product definition before the results start looking wrong. The scalar product is a tool, not a universal answer. Know what it gives you, know what it takes away, and pick it when the problem actually calls for a scalar projection rather than a vector operation.