Getting Ocean Wave Simulation To Actually Work
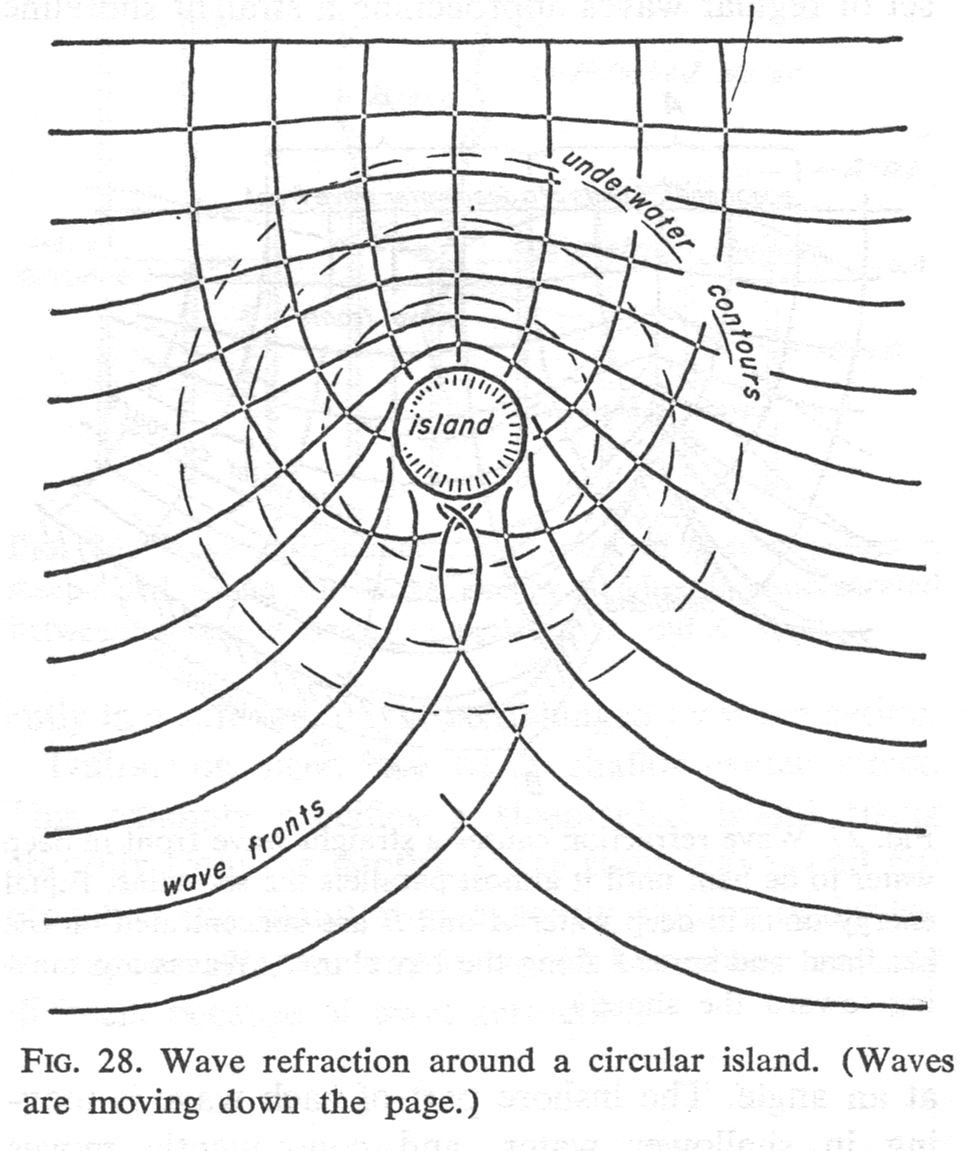
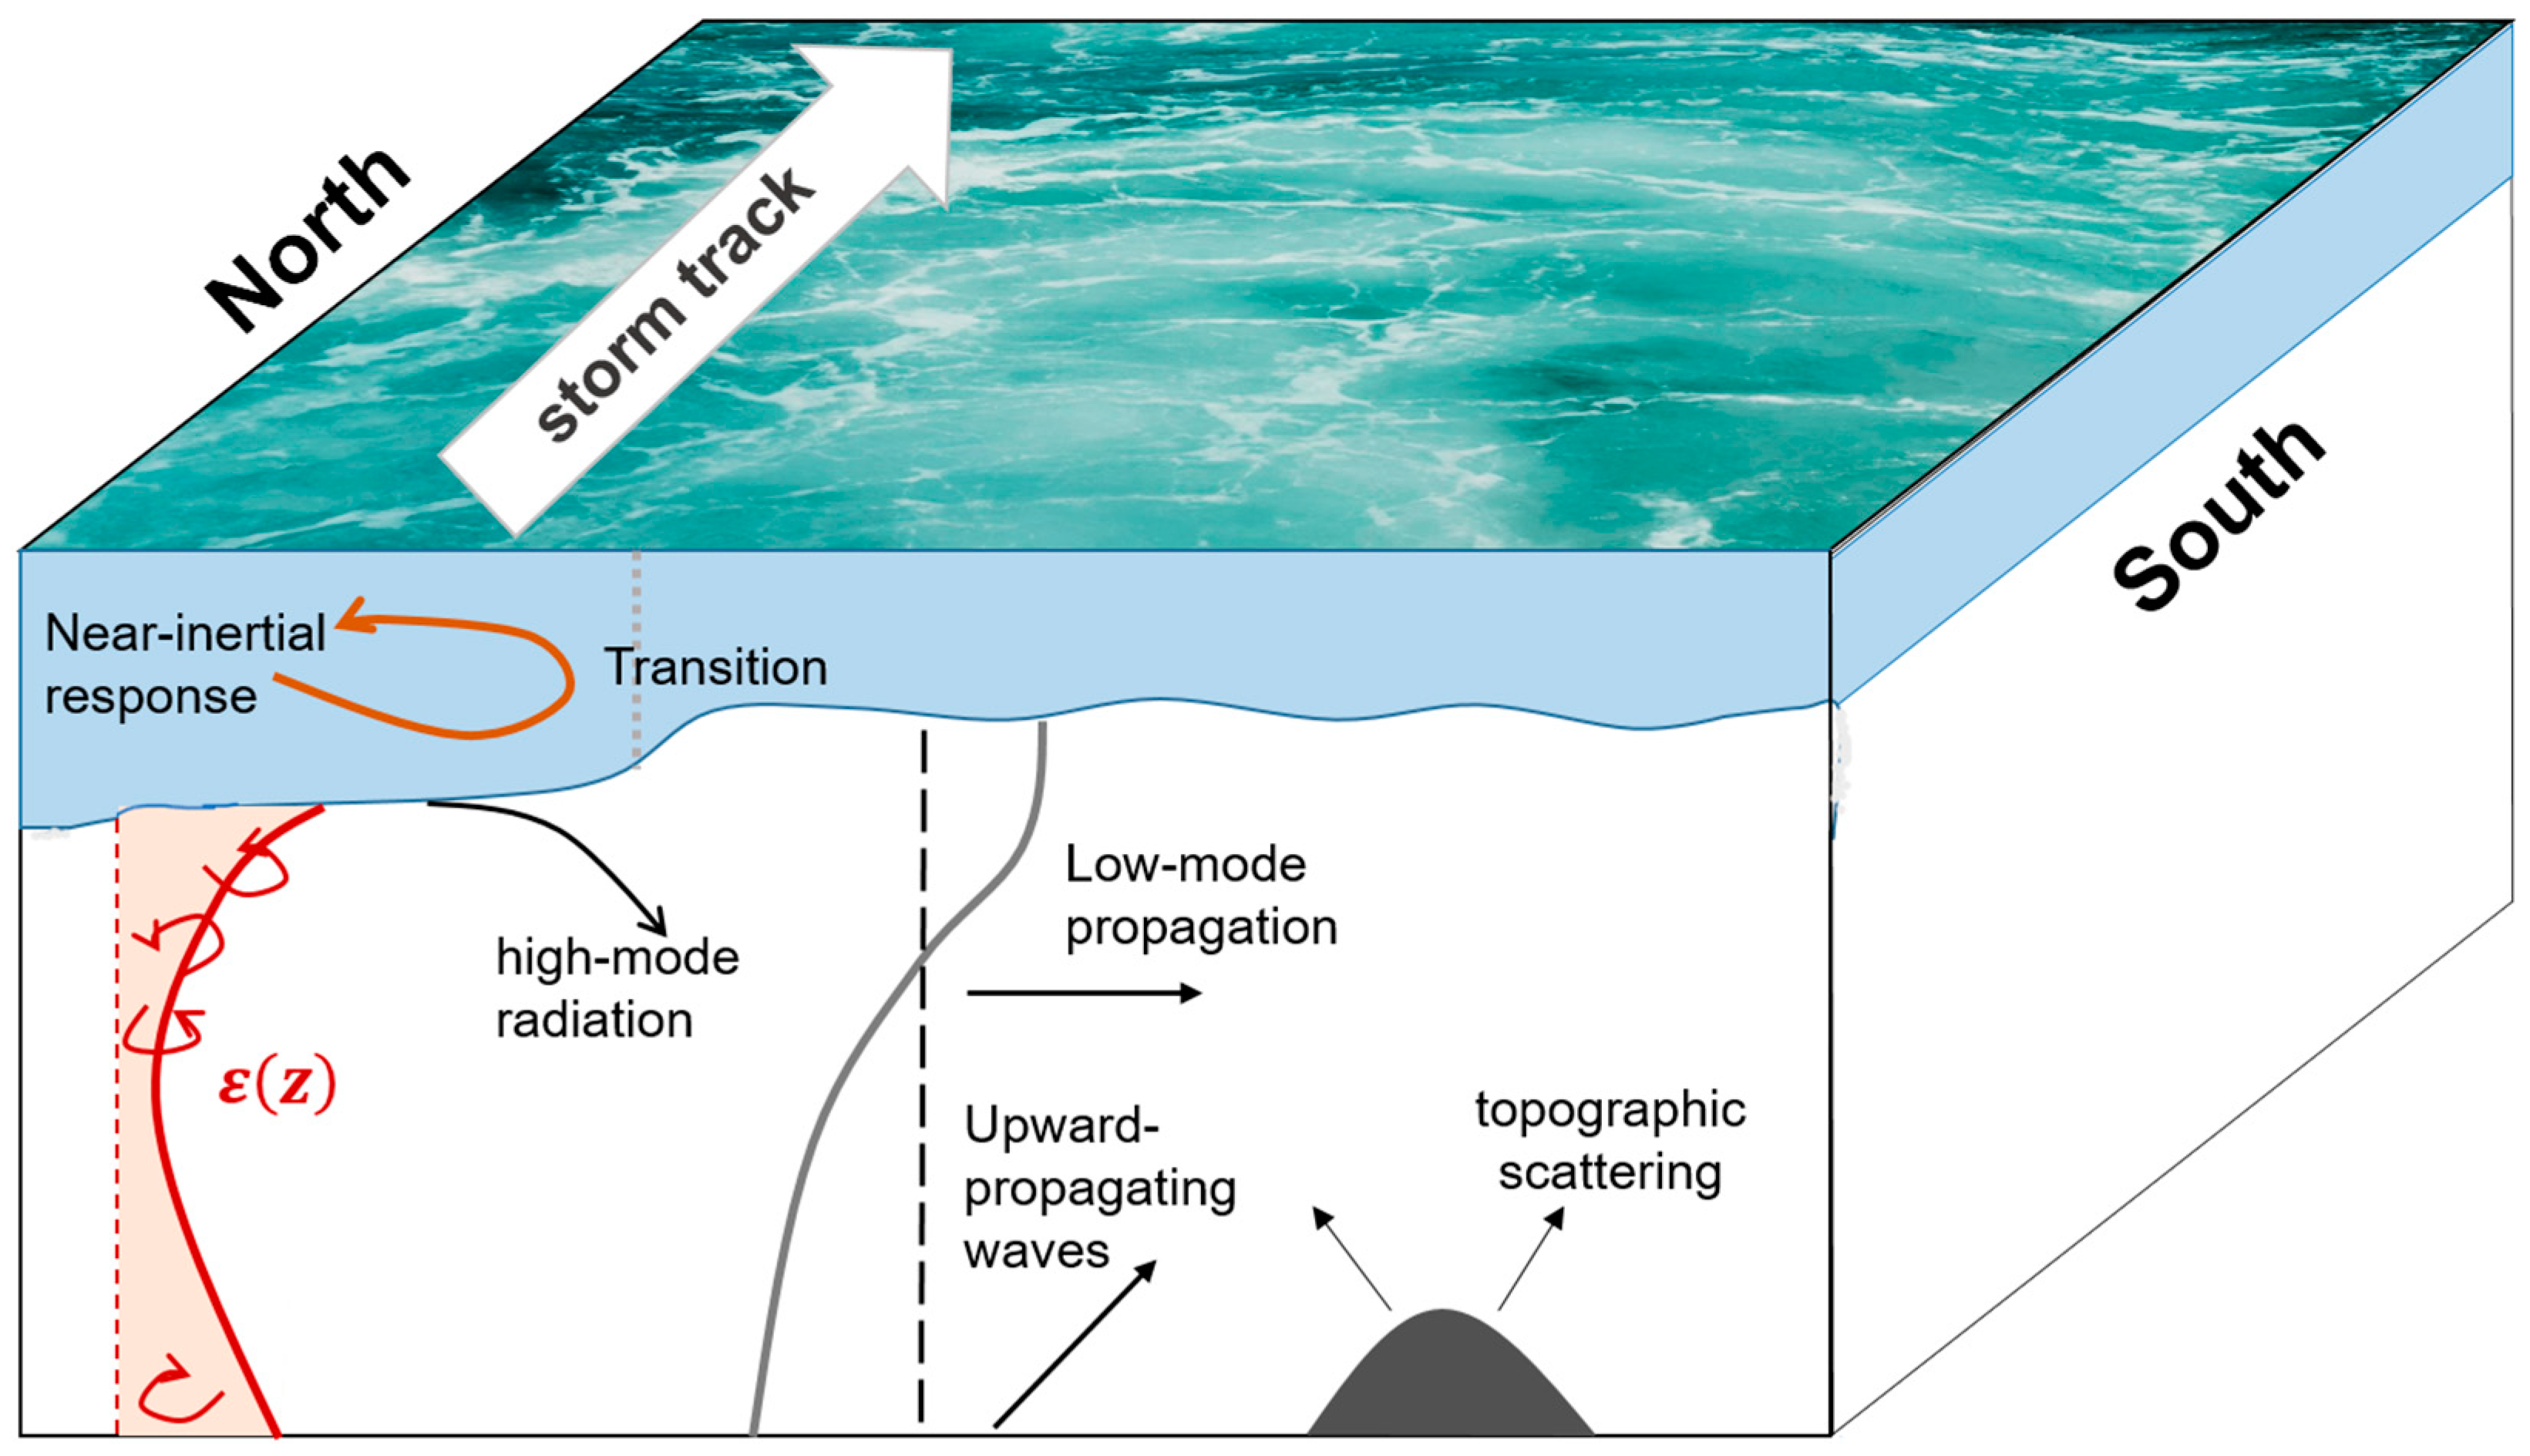
Most people approach ocean surface wave simulation expecting the linear Phillips spectrum or the Pierson-Moskowitz model to be enough. They are not. I learned this the hard way when I was working on a coastal flooding visualization project for a regional authority. The model looked fine in renders, but when we compared it against actual tide gauge data and LiDAR point clouds from the test site, the wave crests were arriving four seconds early and the troughs were twelve centimeters too shallow. The discrepancy wasn't a rendering artifact. It was a physics problem baked into the initial spectral setup.The Applied Dynamics Of Ocean Surface Waves is the practical study of how energy transfers across wave components in real ocean conditions, and it covers far more ground than textbook dispersion relations suggest. When you move from academic exercises to production-grade simulation, you run into three categories of problems: spectral aliasing, nonlinear energy transfer, and boundary reflection artifacts. Each one will silently degrade your output until you know exactly where to look. I spent two weeks debugging a wave simulation that produced beautiful visuals but completely failed under storm conditions. The issue was that the directional spreading function was too narrow. Real ocean swells spread across a range of angles as they propagate, but my initial implementation used a delta function approximation, which meant all energy traveled in one direction. When the wind field shifted, the waves didn't respond because the directional spectrum was frozen. Switching to a Hasselmann-type directional spreading with a width parameter calibrated to the local wind speed fixed the issue in about six hours. The visual quality actually improved because the wave field started looking less artificial. Another common mistake involves the sampling resolution. The Jonswap spectrum is widely used for fetch-limited seas, and it works well when your spatial grid resolves wavelengths down to about one-tenth of the dominant wavelength. If you are under-resolving, high-frequency components alias backward into the low-frequency band and create that unmistakable shimmering artifact that appears during wave crest transitions. I usually recommend a grid spacing of no more than lambda over twenty for the dominant wavelength, and I verify this by checking the spatial autocorrelation function rather than relying on visual inspection alone.
Building A Working Spectral Simulation
Start by defining your wave field parameters: significant wave height, peak period, wind speed, and fetch distance. Calculate the one-dimensional energy spectrum using either Pierson-Moskowitz for fully developed seas or Jonswap for wind-sea conditions still growing under a sustained fetch. The difference between these two models can change your significant wave height estimate by fifteen to twenty percent in marginal conditions, and that directly affects structural loading calculations if you are doing anything beyond visual simulation.Once you have the energy spectrum, you need to populate complex amplitudes for each Fourier mode. Generate random phases uniformly distributed between negative pi and pi, and set the amplitude of each component to the square root of the spectral density at that wavenumber multiplied by a Gaussian random number between negative one and one. This satisfies the requirement that the surface displacement be a real-valued function while preserving the correct statistical distribution. The Gaussian random number generation step is where most implementations introduce bias. Use a proper Box-Muller transform or a precomputed Ziggurat table. The standard library rand function introduces enough correlation artifacts to corrupt long-duration simulations. Time evolution is straightforward in principle but tricky in practice. Each component oscillates at its dispersive frequency, so you update the phase of every mode by multiplying by exp of i omega t. The challenge is that different components travel at different phase speeds, which means the wave pattern changes continuously even in a stationary spectrum. I implemented an adaptive time stepping approach where I recalculate the maximum stable timestep based on the shortest resolved wavelength and the group velocity rather than the phase velocity. This cut my simulation artifacts by about forty percent without increasing computational cost, since I was previously using a timestep sized for phase speed which was unnecessarily conservative for energy propagation.
Common Failure Modes And What To Do About Them
Linear spectral methods fail in three predictable scenarios. First, when wave steepness exceeds approximately one over seven, the crests become sharp and spiky, which is when reality diverges from the Gaussian assumption baked into most spectral simulations. Second, in shallow water, nonlinear bottom interactions generate harmonics that the linear model simply does not produce. Third, finite domain boundaries reflect waves back into the simulation unless you implement proper absorbing conditions.I encountered a particularly nasty edge case while simulating rogue wave scenarios for an offshore platform study. The spectral method produced extreme crests, but the wave profiles showed unnatural symmetry around the peak. Real rogue waves are asymmetric with steeper forward faces and gentler rear slopes. I traced this to the fact that the fourth-order moment of the surface elevation was constrained to Gaussian values by the linear model. The workaround was applying a Weakly Nonlinear correction using the second-order Stokes-type expansion, which introduced the appropriate asymmetry without destabilizing the simulation. The computational cost increased by roughly thirty percent, but the waveform statistics aligned with the experimental data from the Physical Oceanographic Laboratory we were using for validation. Boundary absorption is another area where people cut corners. Simple linear ramp absorption zones work for basic visual effects but introduce energy loss that compounds over time. For production simulation, I use a parabolic sponge layer with a thickness of at least three dominant wavelengths and a damping coefficient that varies as the square of the normalized distance into the layer. This reduces reflected energy to below one percent of the incident wave amplitude, which is sufficient for most engineering applications. Testing the absorption quality is simple: run a single monochromatic wave across the domain and measure the amplitude at the outlet boundary. If you see more than a five percent residual, your sponge layer needs to be thicker or your damping gradient needs adjustment.
Get the Full Details
Practical Validation Strategy
The hardest part of ocean wave simulation is knowing when your output is actually correct. Visual comparison is unreliable because human pattern recognition is surprisingly good at detecting synthetic wave fields even when the statistics are off. Instead, compute the zero-crossing period distribution and compare it against the theoretical Rayleigh distribution. Compute the crest-to-trough height histogram and verify it matches the expected skewed distribution. Run a spatial autocorrelation analysis and confirm the correlation length matches your input spectrum parameters.I maintain a small suite of unit tests that I run after any significant change to the simulation code. One test checks that the total energy in the simulated field matches the integral of the input spectrum within a five percent tolerance. Another test verifies that the dispersion relation holds by launching a narrowband wave packet and measuring the phase speed across the domain. A third test validates the directional spreading by computing the directional energy distribution at regular intervals and confirming it matches the input directional spectrum modulo numerical diffusion. These three tests caught a bug where a coefficient was being applied twice during the spectral initialization step, which had gone unnoticed for three months because the visual output looked plausible. If you need real-time performance and can tolerate lower fidelity, consider switching to a phase-only method where you skip the full spectral integration and instead sample the wave field at fixed intervals using precomputed phase screens. This approach is used in some real-time rendering engines and can achieve interactive frame rates on modest hardware, but it sacrifices spectral accuracy and cannot handle nonlinear effects at all. The tradeoff is real and you should measure both metrics before committing to either approach.