What We're Actually Dealing With
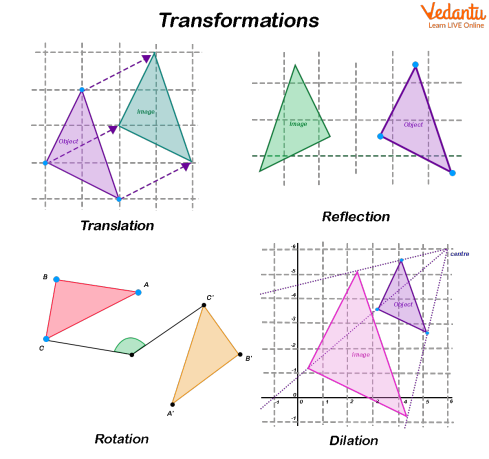
Transformations in math are just functions that move points around on a coordinate plane. That's it. You take an input, you apply a rule, and you get a new position. People overcomplicate this because they try to memorize without understanding what each operation does geometrically. When you understand the geometry, the algebra follows naturally. The four basic types you'll encounter are translations, reflections, rotations, and dilations. Every complex transformation is just a composition of these. I've seen students spend weeks stuck on problems because they treated each type as a separate island instead of seeing how they chain together.
Getting The Types Of Transformations In Math Straight
I ran into a problem last year working with a composite transformation where a reflection over y = x was followed by a rotation of 90 degrees counterclockwise about the origin. The issue wasn't the individual steps - those were fine. The issue was the order. Applying them in the reverse order gave a completely different result, and the standard textbook approach wasn't covering this edge case clearly. My workaround was to track a single test point through every step instead of trying to compose the transformation matrices mentally. Pick a point like (1, 0) or (0, 1), run it through each transformation sequentially, and see where it lands. It takes longer for complicated problems but eliminates the sign errors that usually happen when you're tracking multiple points at once. A translation slides every point the same distance in the same direction. The formula is straightforward: if you translate by vector (a, b), every point (x, y) becomes (x + a, y + b). The shape doesn't change size or orientation. It just moves. Here's what beginners miss: translations commute. Order doesn't matter. Translating left then up gives the same result as translating up then left. This only works because the transformation rule doesn't depend on where the point currently is - it's always adding the same constants. That property goes away the moment you introduce anything else into the mix.
I've noticed people sometimes confuse translations with general linear transformations. A translation is not linear in the strict mathematical sense because it doesn't map the origin to itself. It's affine. This distinction matters if you're moving into linear algebra territory later on, but for most pre-calc and geometry work, it doesn't change how you solve problems.
Get the Full Details
Reflections
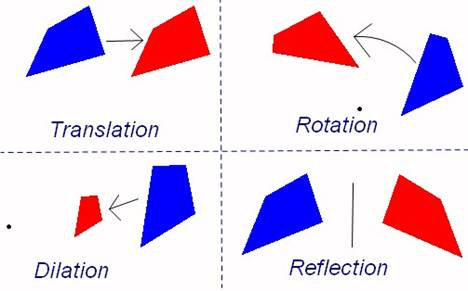
A reflection flips a figure across a line. That line is called the line of reflection or the mirror line. Points on the line stay fixed. Everything else moves to the opposite side at the same perpendicular distance. The common reflections you need to know cold: - Over the x-axis: (x, y) (x, -y)
- Over the y-axis: (x, y) (-x, y) - Over the line y = x: (x, y) (y, x) - Over the line y = -x: (x, y) (-y, -x)
Reflections are their own inverse. Reflect twice and you're back where you started. That's useful because it means every reflection is invertible, which matters when you're working with transformation groups or trying to reverse a sequence of operations. The tricky case is reflecting over an arbitrary line like y = 2x + 3. Standardized tests will try to make you do this. The actual method involves finding the perpendicular projection of each point onto the line, then extending the same distance on the other side. There's a matrix form for this using the angle of the line, but honestly, I usually just work it out point by point for the specific vertices of the figure. The formula-based approach is elegant but slows you down when you're doing it by hand under time pressure.
Rotations
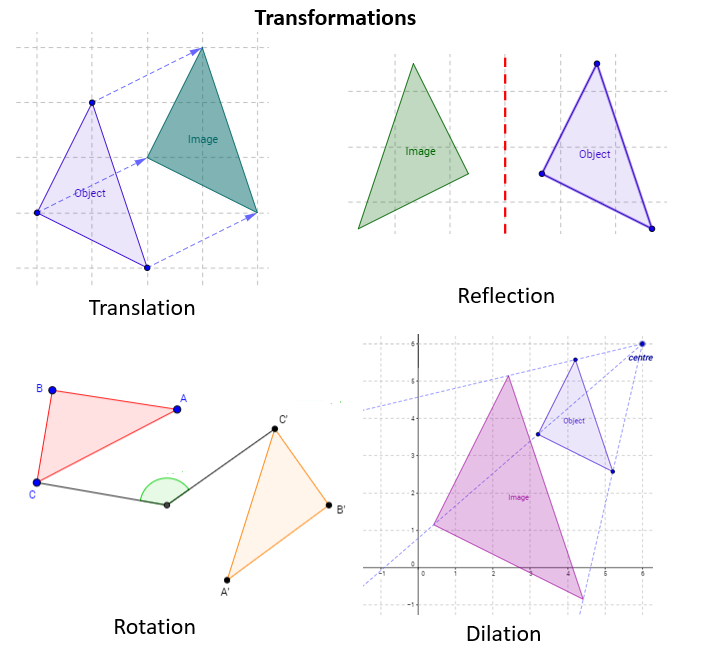
A rotation turns every point around a fixed center by a specified angle. The center point stays fixed. Everything else moves along a circular arc centered at that point. Direction matters: positive angles are counterclockwise, negative are clockwise. This convention is universal in mathematics but it trips up people who've only ever worked with angles in the context of triangles where direction never came up. The standard rotation formulas about the origin are: - 90° counterclockwise: (x, y) (-y, x)
- 180°: (x, y) (-x, -y) - 270° counterclockwise (or 90° clockwise): (x, y) (y, -x) When the center of rotation isn't the origin, you have to translate the whole plane so the center lands at the origin, apply the rotation, then translate back. I've seen students skip the translation steps and just apply the origin rotation formula directly to a figure centered elsewhere. That gives the wrong answer every time. The rotation point is absolutely critical - rotating around (0, 0) versus (3, -2) for the same angle produces entirely different results.
Rotation matrices are worth learning if you're going further into this. A rotation by angle about the origin uses the matrix [[cos , -sin ], [sin , cos ]]. Multiplying this by your point vector gives you the new coordinates. The matrix approach scales much better when you're composing multiple transformations because you can multiply matrices together first and then apply the result once. Manual point-by-point calculation doesn't have that advantage.

Dilations
A dilation resizes a figure by a scale factor relative to a fixed center point. If the scale factor is greater than 1, the figure grows. Between 0 and 1, it shrinks. Negative scale factors flip the figure through the center point while resizing - this is the part most students overlook. The formula with the origin as center is simple: (x, y) (kx, ky) where k is the scale factor. With a different center (h, k), you translate to shift the center to the origin, apply the dilation, then translate back. Dilations preserve angles and the shape of figures. They don't preserve distances or area. Area scales by k². This is important - I've seen multiple-choice questions specifically test whether students remember the area relationship versus the linear relationship. Perimeter scales linearly with k, area with k². Memorize that distinction because it comes up repeatedly.
One thing that people get wrong: dilations with different center points produce different results even when the scale factor is identical. A dilation of factor 2 about the origin is not the same transformation as a dilation of factor 2 about the point (5, 3). The center defines where the scaling happens from. This isn't obvious until you actually plot it out.
Composing Transformations
This is where things get real. A single transformation is rarely enough for the problems you'll encounter. Most useful work involves applying two or more transformations in sequence. The order matters enormously here. Doing transformation A then B is almost never the same as B then A. Take a reflection over the x-axis followed by a 90° rotation about the origin. Start with point (1, 2). After reflection: (1, -2). After rotation: (2, 1). Now reverse the order. Rotate (1, 2) first to get (-2, 1). Then reflect over the x-axis to get (-2, -1). Completely different result. The order is part of what defines the composite transformation. The standard approach is to apply transformations right-to-left when using function notation. T T means apply T first, then T. This notation convention matches how function composition works generally and causes confusion when it's introduced without explanation. Remember: the rightmost transformation is the first one applied.

For matrix-based approaches, you multiply the transformation matrices in the same right-to-left order. The first transformation's matrix goes on the right. This is a common source of error - people multiply left-to-right and get the wrong composite matrix. Write out the order explicitly before you start multiplying.
What I Wish I'd Known Earlier
First, transformations preserve certain properties depending on the type. Translations, reflections, and rotations are all isometries - they preserve distances and angles. Dilations are not. If a problem asks whether a transformation preserves congruence, only isometries qualify. This distinction matters for proof-based work. Second, every transformation has an inverse except for non-invertible dilations. A dilation with scale factor 0 maps everything to a single point and that information is irreversibly lost. You can't get the original back. Scale factor 0 is essentially a degenerate case that shows up in trick questions. Third, the group structure of isometries in the plane is more interesting than most courses cover. The composition of any two isometries is an isometry. The composition of two rotations is either a rotation or a translation depending on whether the angles sum to a multiple of 360°. This classification isn't usually required but it helps you recognize patterns in complex problems.
Common Mistakes
Sign errors dominate every transformation type. Flipping a negative when reflecting over the y-axis, mixing up the rotation direction, forgetting that a negative scale factor both flips and scales - these are the errors that cost points, not conceptual misunderstandings. Slow down on the arithmetic. Write out each coordinate change explicitly rather than trying to do it all in your head. Another frequent issue is assuming that transformations commute. They don't, in general. Only translations commute with each other. Rotations about different centers don't commute. Reflections over different lines don't commute. The exception is rotations about the same center - those do commute with each other. But even then, a rotation and a reflection about a line through that center generally won't commute. People also misidentify the center of rotation. The center isn't necessarily a vertex of the figure. It can be anywhere in the plane. Problems will sometimes give you the center implicitly by describing the motion rather than stating coordinates. Read carefully.

Practice Approach
Start by graphing every single transformation. Don't skip the visual step. When you see (x, y) (y, x), draw it. Watch what happens to a triangle. The pattern becomes obvious quickly and it sticks better than any formula you memorize. I still visualize transformations when I'm working with them at a high level because the geometric intuition catches mistakes that algebra alone misses. Work through compositions slowly at first. Track one point through each step on paper. Once you're comfortable, move to tracking all vertices simultaneously. The transition from single-point to multi-point tracking is where most students feel confident and then get burned on a test. The skill gap appears under pressure when they revert to sloppy tracking. For a reference sheet, the core formulas are compact enough to fit on a single index card. Translation by (a,b): add. Reflection x-axis: negate y. Reflection y-axis: negate x. Reflection y=x: swap. Reflection y=-x: negate both and swap. Rotation 90° CCW: (-y,x). Rotation 180°: (-x,-y). Rotation 270° CCW: (y,-x). Dilation from origin by k: multiply both. That's it. Everything else is just applying these building blocks in sequence.
The subject gets more powerful when you connect it to linear algebra properly. Every isometry about the origin is a linear transformation and has a 2×2 matrix representation. Dilations are scalar multiples of the identity matrix. Reflections correspond to orthogonal matrices with determinant -1. Rotations correspond to orthogonal matrices with determinant 1. When you reach that level, transformations stop being a collection of separate tricks and become a coherent algebraic structure. But that's a conversation for another time.
