Setting Up a Ring Barrier Controller in Vissim
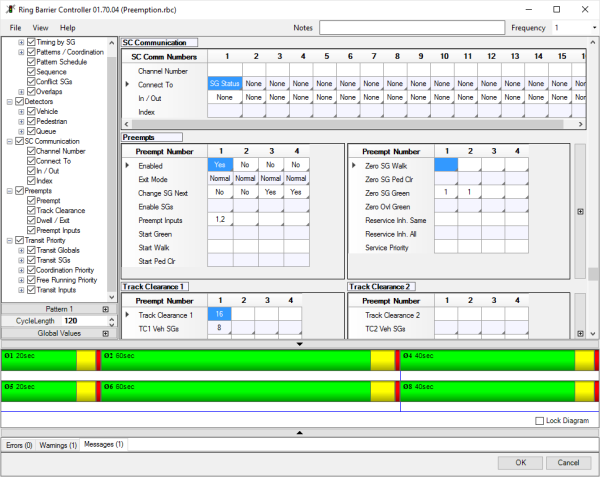
The Ring Barrier Controller in Vissim is one of those features that sounds straightforward on paper and drives you mildly insane when it doesn't behave like you expect. It's designed to simulate controlled traffic flow through a ring or circular path with entry and exit points managed by barriers or gates. Commonly used for events, toll plazas, or any situation where you need to enforce a specific sequence of vehicle passage. You find it under the Traffic Management section when you're building your network. You draw a ring element first, then attach a Barrier Controller to it. The controller needs an input lane where vehicles queue, the ring itself as the path, and an output lane where they leave. Simple enough on the surface. The tricky part is the signal logic. By default, the controller operates in a timed cycle, but most real-world ring barriers aren't purely time-based. They respond to presence detectors. I spent three days once troubleshooting a model where vehicles were stacking past the ring entry because the barrier controller's detector placement was just wrong. The detector needs to be placed before the queue area, not after. If you put it inside the ring or downstream, the controller thinks the ring is clear when it's actually blocked and keeps feeding vehicles into a bottleneck. You'll see cars teleporting or vanishing in the simulation, which is Vissim's way of telling you something is broken.
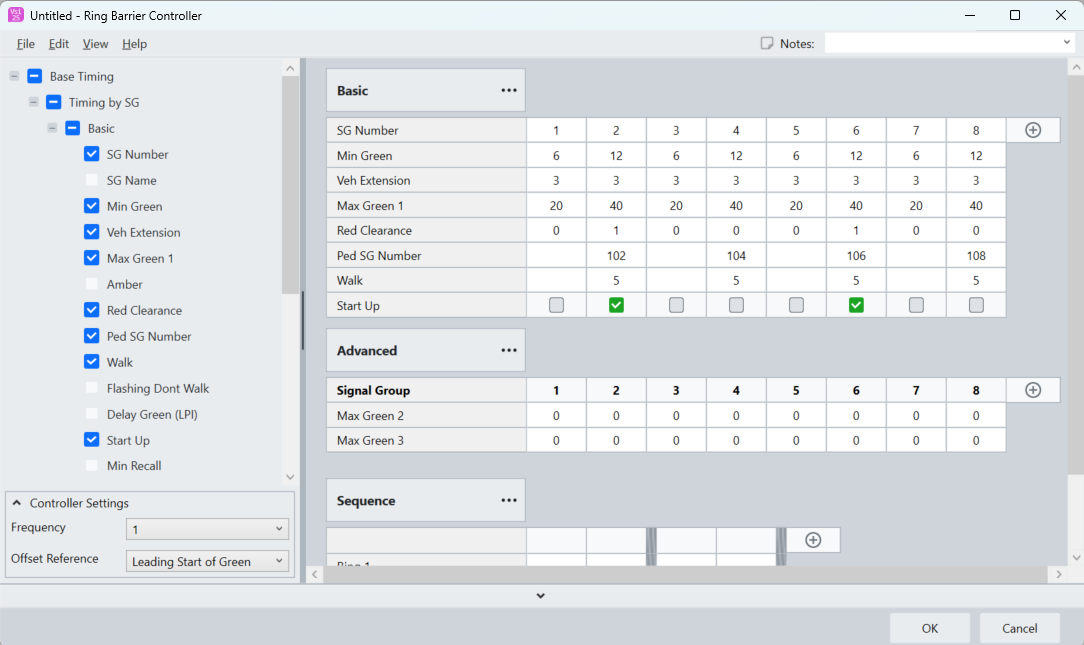
Here's how I usually approach it. Draw your ring element with the proper radius and width. Add your barrier controller and connect the incoming and outgoing lanes. Set up the signal phases - typically you want alternating entry and exit control so vehicles don't collide on the ring. Configure the timing parameters. Start with a simple fixed-time cycle and validate it visually before moving to sensor-based control. The simulation runs noticeably slower when you enable dynamic barrier control with multiple phases, so keep your phase count reasonable unless you actually need it. One thing nobody seems to mention in the documentation: the Ring Barrier Controller doesn't handle lane changes well inside the ring if you have multiple lanes. Vehicles will sometimes just drift through each other or get stuck in a deadlock. If your ring needs multiple lanes, consider splitting it into separate single-lane rings and managing them as independent controllers. It's more setup work but it runs stable. For downloading or accessing the component, it's built into PTV Vissim starting from version 2020 or so. You don't download it separately. Make sure your Vissim installation is up to date though, because earlier versions had a bug where the barrier controller would occasionally ignore the red phase and let vehicles through anyway during long simulations. I hit that in a project last year and the workaround was just to split the simulation into shorter runs and stitch the results together, which added about twenty minutes to an already tedious process.
The biggest limitation I've run into is that the Ring Barrier Controller treats all vehicles identically regardless of type unless you manually filter them. A truck and a motorcycle trigger the same detector and get the same treatment. If your model involves mixed vehicle types with different lengths or speeds, you need to add manual logic or use multiple controllers with different detector zones to approximate realistic behavior. Otherwise your queue lengths will be off and the throughput numbers won't match anything close to reality. If you're doing something more complex than a simple controlled entry point, you might be better off building the ring barrier manually using signal-controlled junctions and stop lines instead. It takes more time to set up, maybe an hour instead of fifteen minutes, but you get full control over every aspect of the behavior and you're not fighting the built-in controller's assumptions the whole way through.
Get the Full Details