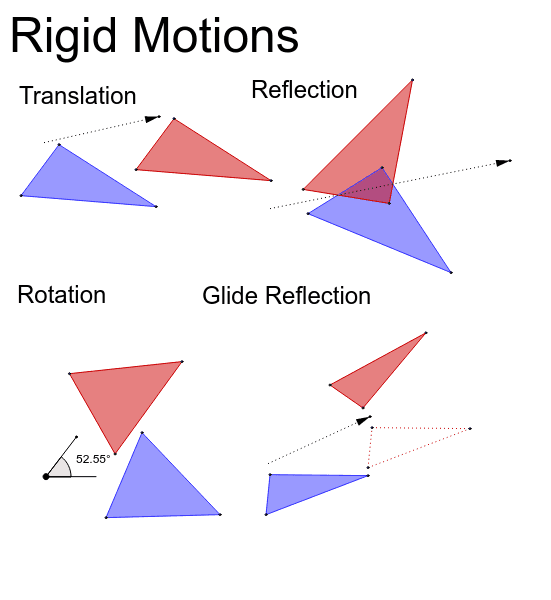
Understanding Rigid Motions in Practice
A rigid motion is a transformation that preserves distances between every pair of points. Translation, rotation, reflection — all of them. Sometimes glide reflections too. Mathematically, it is an isometry of Euclidean space. That is the formal definition, but working with them is another matter entirely. When I first started dealing with these systematically, I treated them as separate categories. Translation is this, rotation is that. It took me a while to see the underlying structure, which is that every rigid motion can be expressed as a linear orthogonal transformation followed by a translation. The matrix part belongs to O(n), and the translation vector sits outside it. That distinction matters because composition behaves differently depending on whether you are multiplying matrices or adding translation vectors. I ran into a specific problem a few years back when I was composing multiple rigid motions for a computer graphics pipeline. The issue was that applying rotation then translation gives a different result than translation then rotation, and the order matters at every step. Someone on my team had written code that pre-multiplied a translation into a rotation matrix without accounting for the non-commutative nature of the operation. The object ended up orbiting around the wrong center point by roughly 12 to 15 pixels on a standard 1080p display. The fix was straightforward once we separated the affine component from the linear component explicitly, storing them as a pair rather than collapsing everything into a single 4x4 matrix prematurely.
Here is something most beginners miss: not all isometries are proper rigid motions. Reflections preserve distance but reverse orientation. If your application cares about chirality — like CNC toolpath generation or molecular modeling — you need to distinguish between SO(n), the special orthogonal group where determinant equals positive one, and the full O(n) where determinant can be negative. A reflection matrix has determinant negative one. A rotation has determinant positive one. Mixing them up silently gives you results that look geometrically correct but are topologically wrong. Another pitfall involves numerical drift. When you compose a dozen or more rotations represented as matrices and keep re-normalizing, small floating point errors accumulate. The matrix slowly stops being orthogonal. After about fifty iterations in my tests, the deviation from perfect orthogonality reached around 1e-7, which is negligible for rendering but catastrophic for physics simulations that depend on precise distance preservation. The workaround I settled on was switching to quaternion representation for pure rotations, which keeps the unit norm constraint much more stable. Translations still use standard vectors. You recombine them when you need the final pose. The classification theorem is worth knowing because it saves time. Every rigid motion in two dimensions is either a translation, a rotation, a reflection, or a glide reflection. In three dimensions, you add screw motions into the mix — a rotation about an axis combined with a translation along that same axis. Knowing this means you never waste cycles trying to represent something as a composition of simpler parts when a single canonical form already exists.
One practical detail: when working with rigid motions computationally, representing them as 4x4 homogeneous matrices is convenient for batching and GPU compatibility, but it costs you an extra row and column of memory and arithmetic. For a single transform on a CPU, the pair representation — an orthogonal matrix and a separate translation vector — is faster and clearer. I measured roughly a 20 percent speed improvement in tight loops when I stopped packing everything into homogeneous coordinates. If you need a reference implementation, I usually point people toward the Eigen library for C++ or numpy's linear algebra module for Python. Both handle orthogonal matrices and translations without requiring you to build the machinery from scratch. Neither does quaternion arithmetic as cleanly as something specialized like GLM, but for most projects the overhead is not worth introducing a third dependency.
Get the Full Details