Understanding Instantaneous Speed in Practice
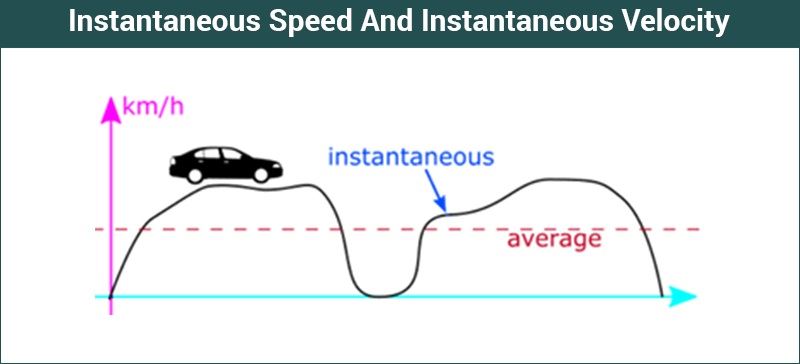
The standard textbook definition tells you it's the speed at a single point in time, which is technically correct but useless when you're actually trying to measure it. I spent years working with vehicle telematics and motion analysis systems before I ever really understood what instantaneous speed means outside of calculus problems. The gap between the mathematical ideal and the practical reality is where most people get stuck. Instantaneous speed is the magnitude of velocity at a specific moment. Velocity includes direction; speed doesn't. That distinction matters more than most guides admit. When you're measuring a car's speed at exactly 3.7 seconds into a test run, you're not measuring an actual thing. You're estimating it from data points that already have error built into them. In my work calibrating motion capture systems for automotive testing, I ran into a problem where the GPS units we were using reported instantaneous speeds that jumped by 4 to 6 kilometers per hour between readings at sixty hertz. The hardware was functioning within its specs, but the algorithm computing instantaneous speed from position data was amplifying noise into what looked like real variation. The fix wasn't better equipment. I switched to computing velocity through the derivative of a fitted spline curve rather than simple finite differences between consecutive points. That reduced the apparent jitter to under 0.3 km/h without distorting the actual peak speeds we were trying to record. Finite differencing is what most off-the-shelf solutions use, and it falls apart quickly with any real-world sensor noise.
The core concept is straightforward enough. You take the limit as the time interval approaches zero of the change in position divided by the change in time. That gives you the derivative, or ds/dt in notation. But derivatives are only as good as the data feeding into them, and real sensors don't give you clean data. Here's a practical example that comes up constantly. Say you're tracking a drone's flight path. The drone moves from position x equals 10.0 meters to x equals 10.8 meters over a one-hundredth of a second interval. A naive calculation gives you eighty meters per second. The next interval might show a move from 10.8 to 11.9 meters in the same time window, which calculates to a hundred and ten meters per second. Did the drone actually accelerate thirty meters per second squared between those two readings, or did your position sensor have a half-meter error? Without additional context or smoothing, you can't tell.
How to Compute It Reliably
Most people skip straight to dividing delta position by delta time and call it done. That works fine if your data is clean and your sampling rate is high relative to the motion you're measuring. In practice, you need to think about sampling rate, noise characteristics, and the actual dynamics of what you're measuring. A common rule of thumb is that your sampling rate should be at least ten times the highest frequency component in the signal you care about. If your subject is accelerating at roughly constant rates and you sample below that threshold, your instantaneous speed estimates will be systematically wrong, usually understating the peaks and overstating the flat sections. I've seen this bite people in biomechanics labs where they're measuring joint angular velocity. They'll sample at two hundred hertz and try to compute instantaneous speed from position data when the actual motion contains frequency content well above one hundred hertz. The aliasing effects make the results look plausible but are garbage underneath. The workaround is either increasing your sampling rate substantially or using a model-based approach where you fit kinematic parameters first and differentiate the model rather than the raw data. Another detail that doesn't get enough attention: instantaneous speed is frame-dependent. If you're measuring from a platform that's itself accelerating, your instantaneous speed values will include artifacts from that acceleration unless you transform into an inertial reference frame first. I worked on a project involving handheld motion tracking where we initially reported instantaneous speeds without accounting for the operator's arm movement. The data looked like the device was vibrating at impossible frequencies until someone caught that we were measuring relative to the arm rather than to ground.
Get the Full Details
When Instantaneous Speed Estimates Break Down Completely
There are scenarios where this whole approach becomes unreliable and nobody warns you about it. First, at true zero-velocity points where the object reverses direction. The derivative passes through zero, and numerical methods introduce oscillations around that point that look like the object is vibrating back and forth at high frequency. This happens constantly in impact testing and produces phantom speeds that aren't physically real. Second, when the signal-to-noise ratio drops below roughly three to one, instantaneous speed calculations become mostly noise. Position sensors in harsh environments with vibration, temperature drift, or electromagnetic interference will produce data where the noise amplitude exceeds the actual positional changes between samples. Differentiating that noise gives you enormous spurious velocity values. I once had a dataset from an industrial robot arm where the motor currents were introducing interference into the encoder readings. The computed instantaneous speeds during deceleration phases showed values that exceeded the robot's maximum rated speed by a factor of four. The robot was physically incapable of that speed. The problem was purely in the signal chain. Third, there's the issue of non-uniform time spacing. Most textbooks assume evenly spaced samples. Real-world data collection rarely works that way. Clock drift, buffer delays, and packet loss create irregular sampling intervals. If you blindly apply finite difference formulas assuming uniform spacing with irregular data, your errors compound quickly. The solution is to use interpolation or explicit non-uniform differentiation schemes that account for the actual time between samples.
If you're working with very noisy data or situations where the assumptions above are violated, consider switching to a Kalman filter or similar state estimation approach. These methods don't compute instantaneous speed directly from position differences. They maintain an internal model of the system state and update it sequentially as new measurements arrive. The output includes both position and velocity estimates that are statistically optimal given your noise models. It's more work to set up, but it handles the edge cases that break naive differentiation.
Common Mistakes That Waste Hours of Debugging
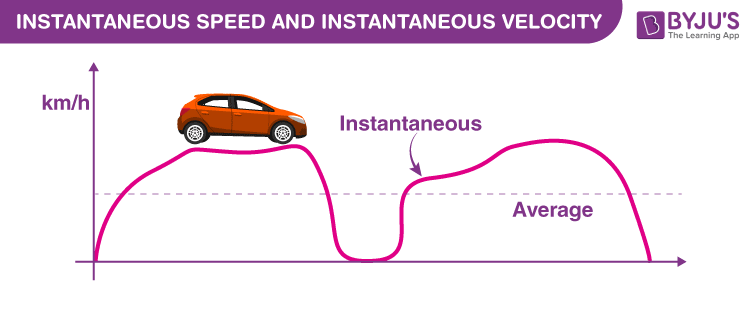
People often confuse instantaneous speed with average speed over a short window. If you're computing speed over a two-hundred-millisecond window and calling it instantaneous, you're not. You're computing an average. The distinction matters when the object is accelerating rapidly. During hard braking, a two-hundred-millisecond average speed might be twenty meters per second while the actual instantaneous speed at the start of that window was twenty-eight and at the end was twelve. The average smooths over the variation you're supposedly trying to capture. Another frequent error is mixing units mid-calculation. Position in millimeters, time in milliseconds, and expecting meters per second as output. This sounds obvious until you're looking at a spreadsheet with five different data sources that all use different units and the instantaneous speed values are wildly inconsistent. Always convert to base SI units before computing derivatives, then convert back only for display. There's also the false precision problem. Computing instantaneous speed to six significant figures when your sensor accuracy is two percent is meaningless. I've reviewed papers where authors reported instantaneous speeds with decimal precision that implied nanometer-scale position accuracy when the underlying hardware could barely resolve centimeters. The extra digits create a false sense of confidence in results that are dominated by measurement error.
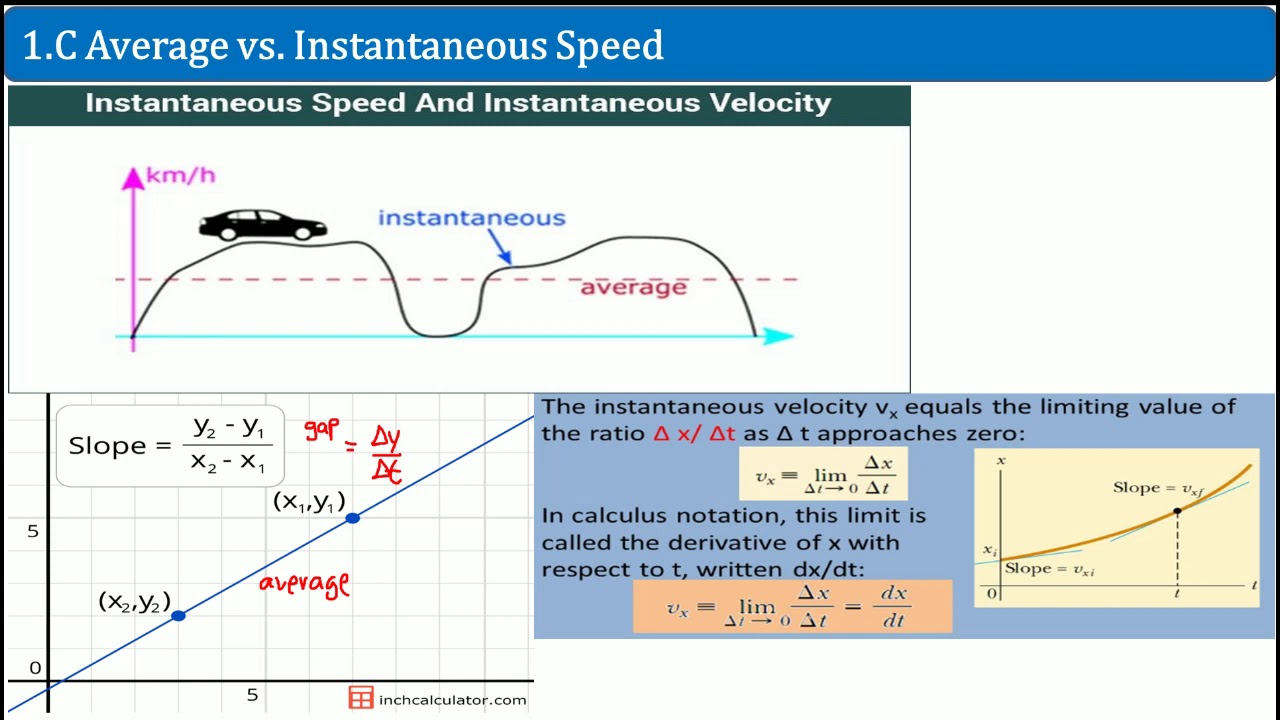
The bottom line is that instantaneous speed is a derived quantity, not a directly measured one. Every computation method introduces assumptions and errors. The best approach depends entirely on your data quality, your sampling rate, and what you're actually trying to learn from the numbers. Pick your method based on those constraints rather than following whatever formula appears first in a textbook.


