What Adaptive Control Actually Means in Practice
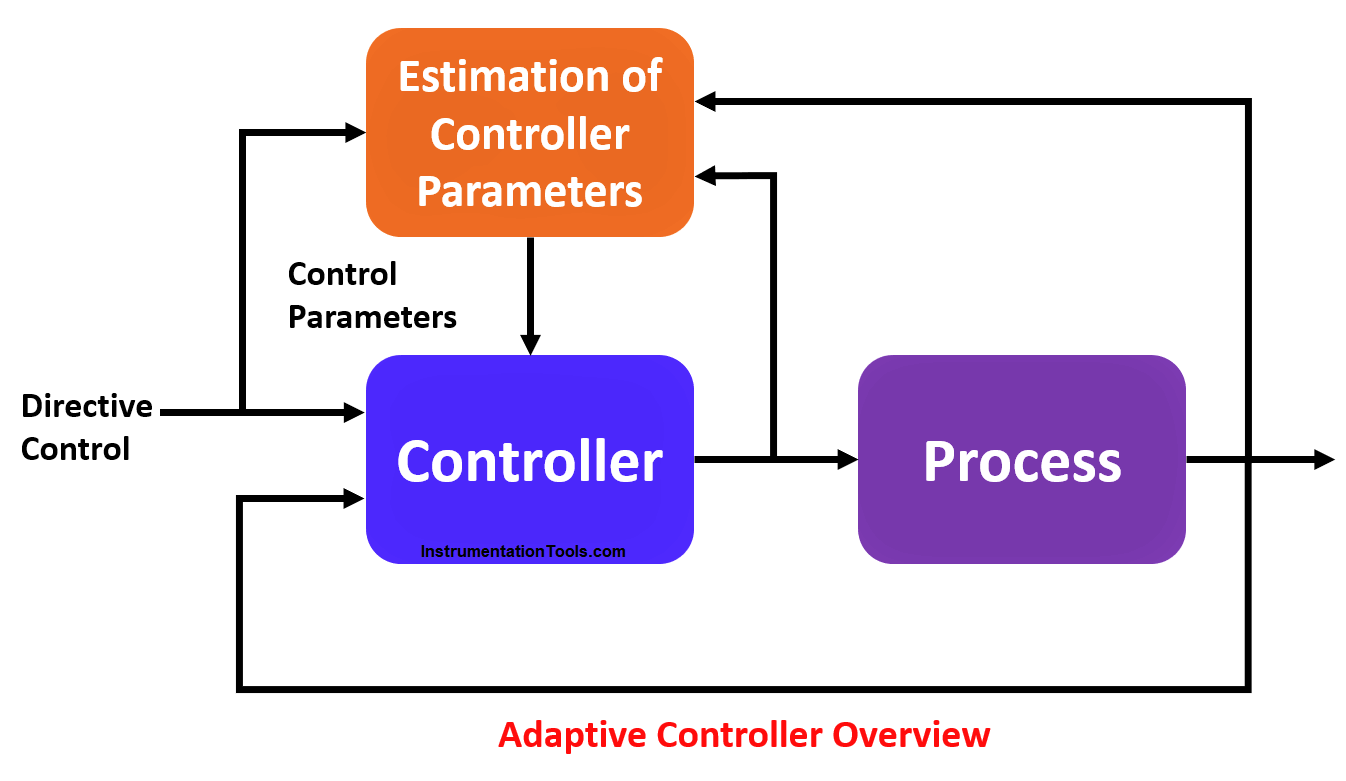
Adaptive control is one of those terms that sounds impressive until you try to tune a real system and watch it oscillate for three hours. The basic idea is straightforward: a controller that adjusts its own parameters in response to changes in the plant or process. You design it, you think it will help, and then you spend the weekend figuring out why your gain schedule keeps drifting into territory that makes the actuator saturate. I ran into this directly when working through materials from Backendgeeks. Their adaptive control solution manual covers the theory, but the gap between the equations and actually getting a system to track a reference signal with acceptable overshoot is where most people stumble. The manual walks you through MRAC and self-tuning regulators, but it doesn't always spell out the practical gotchas like parameter drift under persistent excitation requirements or how to handle unmodeled high-frequency dynamics.
Adaptive Control Solution Manual Backendgeeks
The resource itself is structured around standard graduate-level adaptive control topics: Lyapunov-based design, gradient and least-squares estimators, robustification techniques like dead zones and projection operators. It's solid as a study guide. If you need a reference while working through problems, it covers the derivations adequately. Where it falls short is in the implementation side. Getting from a stable transfer function to working simulation code is a different skill set entirely, and the manual doesn't bridge that gap as smoothly as it could. I found myself having to reverse-engineer several of the examples. The continuous-time gradient adaptation examples work cleanly on paper because they assume ideal conditions. In practice, when you discretize with a fixed step size and add quantization effects, the parameter estimates can wander unless you're careful with the adaptation gain and the excitation signal. I spent a couple evenings tweaking a discrete MRAC implementation where the closed-loop response degraded after about 40 seconds of simulation. The issue was a combination of insufficient persistent excitation and a discretization step that was too large for the fastest time constant in the plant. Halving the step size and adding a normalization term to the gradient algorithm stabilized it.
Common Pitfalls When Working Through This Material
One thing the manuals rarely emphasize enough is the difference between theoretical convergence and practical stability. You can prove global stability under persistent excitation, but that doesn't mean your controller will behave well during the transient. The initial parameter estimates matter more than textbooks often suggest. When I first ran through the self-tuning regulator examples, I initialized the covariance matrix with a high value thinking it would speed up learning. Instead, the controller became wildly aggressive in the first few seconds, driving the control signal to saturation and almost destabilizing the system before the estimates settled down. Switching to a more conservative initialization and ramping the adaptation gain over the first 10 seconds fixed the issue without affecting long-term performance. Another area where things get tricky is robust adaptive control. The basic formulations assume matched uncertainty and no unmodeled dynamics. Real systems have both. The manual touches on modification terms and dead zones, but the tuning intuition for when to apply them isn't always clear. A projection operator prevents parameter estimates from leaving a known bounding set, which is useful when you have physical constraints on parameters. A dead zone around the tracking error prevents adaptation when the error is dominated by unmodeled dynamics rather than parameter mismatch. Using both together usually helps, but you need to size them relative to your noise floor and highest expected disturbance amplitude. Too large a dead zone and adaptation stalls entirely. Too small and you're back to square one with drift.
Get the Full Details
What Actually Works When the Theory Gets Stuck
If you're working through the Backendgeeks material and hitting walls, here's the pragmatic approach I ended up settling on. Start by simulating the nominal case with perfect knowledge. Get the baseline controller working before you add adaptation. Then introduce parameter variation slowly and watch what breaks. The order in which you add complexity matters. Don't throw discretization, noise, saturation, and parameter drift at the system all at once. Each one interacts with the others in ways that aren't obvious. For the estimation part, I recommend comparing gradient, recursive least squares, and projection-based methods side by side on the same problem. They converge at different rates and have different sensitivity to noise. Gradient is simplest but noisy. RLS is faster but more prone to covariance windup. Projection adds stability guarantees but requires you to know bounds on your parameters. Your choice depends on what you're actually dealing with. The manual also assumes a certain level of mathematical comfort with Lyapunov analysis. If you're still getting familiar with the machinery, the derivations can feel opaque. I found it helpful to go through a simpler PID-with-adaptive-gain example first, just to see the Lyapunov argument in a less intimidating context. Once you've traced through that proof yourself, the more complex MRAC and STR derivations follow a very similar pattern. The structure is almost identical; only the state vectors and parameter error definitions change.
There's no way around putting in the time. Adaptive control looks elegant in a textbook because the examples are clean and the simulations run for ten seconds. Real applications demand more patience. But the concepts in the Backendgeeks manual are sound, and working through the derivations yourself will pay off when you actually need to design a controller that handles varying conditions without constant re-tuning.