Why the equation actually looks the way it does
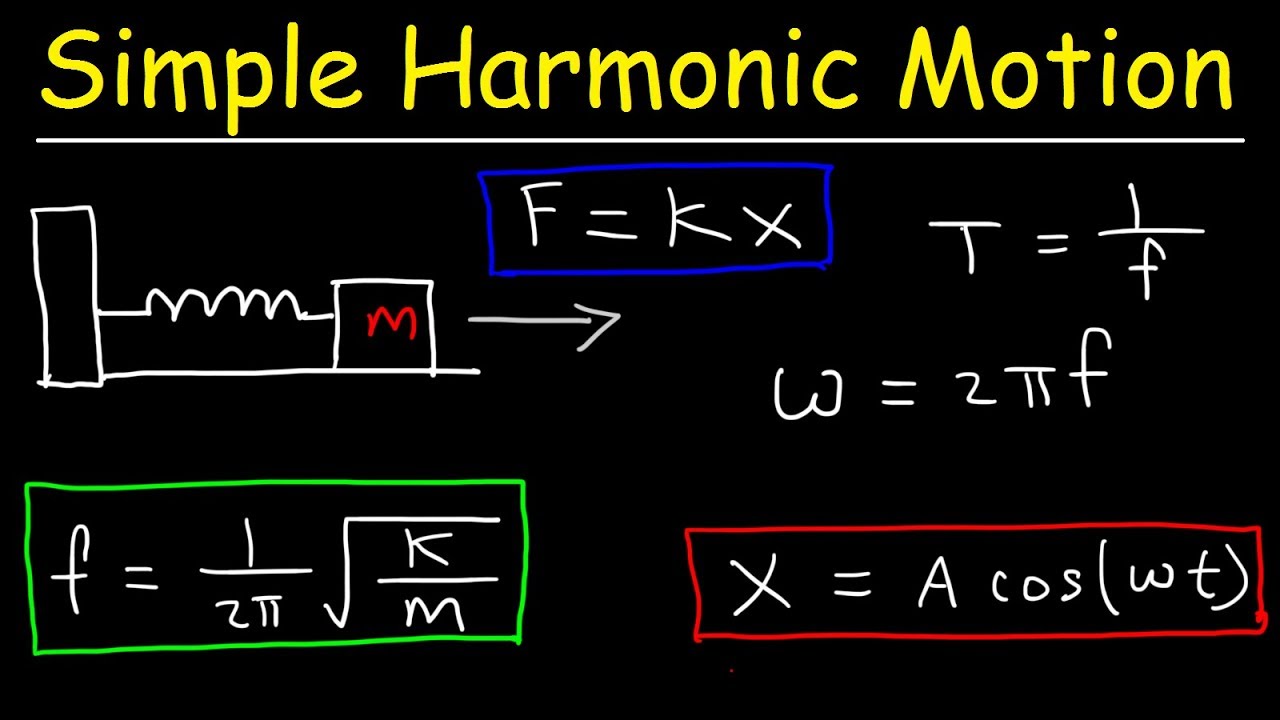
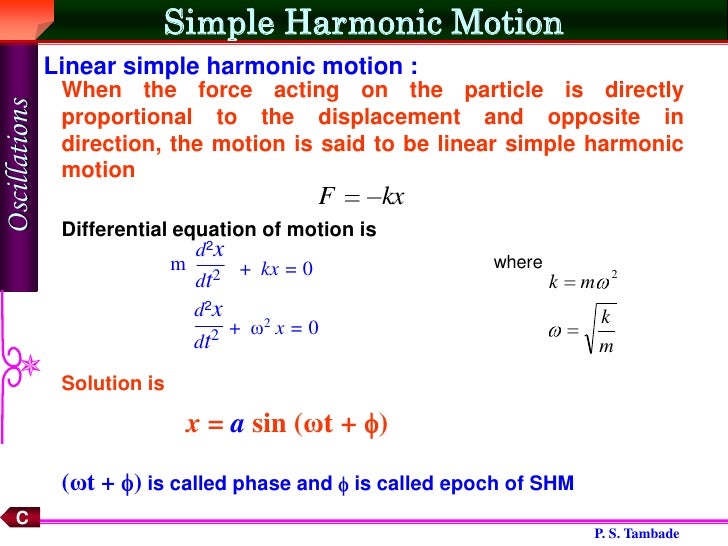
The differential form is what most people miss when they're first learning this. Everyone writes x(t) = A cos(t + ) immediately, but that's the solution, not the physics. The physics lives in d²x/dt² = -²x. You need to see that first because it tells you something critical: acceleration is proportional to displacement and always directed toward equilibrium. That negative sign isn't decoration. It's the entire reason the motion repeats instead of blowing up exponentially. Here's the thing that caught me off guard early in my work. When you're dealing with coupled oscillators or systems where itself depends on position, plugging directly into the standard SHM equation gives garbage results. I spent three days debugging a simulation where a mass-spring system kept producing trajectories that looked nearly correct but drifted over time. Turns out the spring wasn't Hookean at large displacements. The force was better modeled as F = -kx - x³, which is a Duffing oscillator, not simple harmonic motion. The standard equation assumes the restoring force is purely linear. When that assumption breaks, you need numerical integration or perturbation methods. The analytical solution just doesn't exist in closed form.
Understanding the Simple Harmonic Motion Equation
The general solution x(t) = A cos(t + ) contains three parameters that each mean something specific. Amplitude A is the maximum displacement from equilibrium. Angular frequency equals sqrt(k/m) for a spring-mass system or sqrt(g/L) for a pendulum under the small-angle approximation. Phase constant sets where in the cycle the motion starts at t=0. These aren't arbitrary choices, they're determined by initial conditions. If you release the mass from rest at displacement x, then A = x and = 0. If you push it from equilibrium with velocity v, then A = v/ and = -/2. Getting the phase wrong is the most common error I see in student lab reports. It's also the easiest to fix once you know it's happening. The period and frequency relations follow directly. T = 2/ and f = /2. For a spring, T = 2 sqrt(m/k). For a pendulum, T = 2 sqrt(L/g). Notice the pendulum period doesn't depend on mass. That's not intuitive to people who haven't thought about it, but it follows from the fact that both gravitational force and inertial resistance scale linearly with mass, so mass cancels out. The small-angle approximation limits this to angles below roughly 15 degrees. Beyond that, the period increases measurably and you need elliptic integrals to get an accurate answer. Energy is another lens that makes the equation easier to work with in practice. The total mechanical energy E = ½kA² stays constant throughout the motion. At any point, KE = ½mv² and PE = ½kx², and they add to the same total. I use energy conservation instead of the position equation whenever I need velocity at a specific displacement. Solving ½mv² + ½kx² = ½kA² for v gives v = ± sqrt(A² - x²). That's usually faster than differentiating the cosine function and evaluating it, especially when you're doing repeated calculations in a spreadsheet or script.
One practical pitfall with real systems: damping. The undamped SHM equation assumes no energy loss, but every physical oscillator loses energy to friction, air resistance, or internal material hysteresis. The equation becomes d²x/dt² + 2 dx/dt + ²x = 0, where is the damping ratio. Underdamped systems ( < 1) still oscillate but with exponentially decaying amplitude. Critically damped ( = 1) returns to equilibrium fastest without overshooting. Overdamped ( > 1) creeps back slowly. The standard SHM equation doesn't account for any of this, and if you're modeling a real suspension system or a vibrating structure, ignoring damping will give you results that diverge from reality within a few cycles. The workaround I use is to measure the logarithmic decrement from actual decay data and back-calculate , then fit the damped solution instead of the ideal one.
Get the Full Details
When to reach for the equation and when to step back
The SHM framework applies whenever a system has a stable equilibrium and the restoring force is approximately linear near that point. That covers springs, pendulums at small angles, LC circuits, molecular vibrations at low energies, and a bunch of other systems you wouldn't immediately recognize as oscillators. The key word is approximately. Linearity is an assumption, not a law of nature. Most real restoring forces are only linear in a narrow neighborhood around equilibrium. Once you displace the system far enough, nonlinear terms dominate and the sinusoidal solution stops working. For quick estimates and classroom problems, the ideal equation is perfectly adequate. I've used it to size vibration isolators for sensitive equipment, estimating natural frequency from estimated stiffness and mass. That process took about twenty minutes for a system where a full finite-element modal analysis would have taken two days. The trick is knowing the boundary between "good enough" and "way off." As a rule of thumb, if your maximum displacement is less than 10 percent of a characteristic length scale in the system, the linear approximation usually holds within a few percent. Beyond that, test it against a more detailed model or experimental data before trusting the numbers. There's also the question of forcing and resonance. The basic SHM equation describes free, unforced oscillation. Add a periodic driving force and you get a completely different problem with a steady-state solution that depends on the driving frequency relative to the natural frequency. Near resonance, the amplitude grows until damping limits it. Away from resonance, the response follows a predictable curve. If you're designing anything that will experience periodic forces—engines, motors, wind loads on structures—you need the forced response equation, not the free oscillation one. Using the free equation in those scenarios is how buildings collapse during earthquakes and bridges fail in wind.