Wiring the Terminator X Controller — What Actually Works
I spent three days last month untangling a Terminator X I2C and analog wiring job for a custom CNC bridge build. The datasheet diagrams look clean on paper, but once you have a real controller in front of you, things behave differently. This is what matters when you're building a Terminator X inputs and outputs wiring diagram for actual use, not for a textbook example. Start with the power section. The Terminator X runs on 5V logic but accepts 24V or higher on its input channels depending on which variant you bought. I found that mixing 5V pull-ups on a 24V input line without confirming the exact board revision caused intermittent float states. Check your board silkscreen for the REV number first, then decide whether your optocouplers need separate logic and load supplies. It takes about two minutes but prevents an hour of debugging later.
Terminator X Inputs And Outputs Wiring Diagram Reference
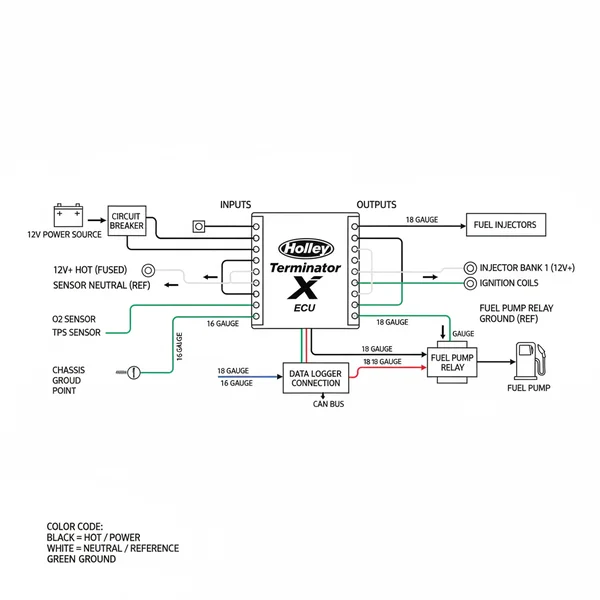
The core layout breaks into four zones: power input, digital inputs, analog inputs, and relay outputs. Each zone has its own common reference point, and that is where most people go wrong. For digital inputs, wire your switch or sensor between the channel pin and ground. Enable the internal pull-up through software if you are reading dry contacts, but do not skip adding a 100nF capacitor across the switch terminals if the signal looks noisy on an oscilloscope. The noise comes from relay arcing or stepper motor interference, and a small RC snubber fixes it before it reaches the ADC. Analog inputs share a different ground path than the digital section. I learned this the hard way when a probe reading drifted by 15 percent every time a 48V spindle drive turned on. Separating the analog ground from the digital ground at a single star point near the power connector stopped the drift immediately. Do not daisy chain the grounds.
Relay outputs are rated differently depending on load type. The resistive load rating is roughly twice the inductive load rating on these boards. If you are switching a 12V solenoid, derate the expected current by half to be safe. I have burned one relay contact set on a 3A inductive load because the datasheet did not call out the inrush current for a specific brand of linear actuator. The workaround was adding a flyback diode across the actuator leads, which costs about forty cents per channel and prevents the whole output stage from degrading over time. Here is a practical way to map the pins on a typical Terminator X board: Power input: Vin connects to your 5V regulator input, GND goes to system ground. Keep this wire thick enough for your total load, usually 18 AWG minimum if you are running multiple relays simultaneously.
Get the Full Details
Digital input channels: CH0 through CH7 map to GPIO pins with optional interrupt capability on CH0 and CH1. Each channel accepts either a 5V logic high or a 24V input depending on how you configure the jumper blocks. The jumpers sit near each channel pin and are clearly labeled. Analog input channels: A0 through A3 are 12-bit ADC inputs referenced to the analog ground plane. The input impedance is around 100k ohms, so high impedance sensors work fine but low impedance sources will read low unless you buffer them with an op-amp stage first. Relay output channels: REL0 through REL3 are the main switching outputs. Each has COM, NO, and NC terminals. Wire your load between COM and NO for normally open operation. The common terminal connects internally to the Vrelay supply pin, which is separate from the logic Vcc pin.
Communication lines: I2C uses SDA and SCL with built-in pull-up resistors already on the board, usually 4.7k ohms. If you add devices to the bus, measure the actual pull-up current before assuming the onboard resistors are sufficient. SPI uses MOSI, MISO, SCK, and CS pins that are clearly marked near the connector block. One edge case that nobody mentions in the quick-start guide: the reset pin. It is active-low and shares a net with the programming header. If you add a capacitor larger than 100nF on the reset line to debounce a faulty ground, the board will never boot past the bootloader. I had a prototype sitting on a bench for two days because someone installed a 1uF ceramic cap across reset and GND thinking it would stabilize voltage dips during relay switching. Remove that cap or reduce it to 10nF max. Testing procedure that actually saves time: after wiring, do not plug in the main load immediately. Power the logic section only first by disconnecting the relay load supply if your board has separate terminals for that. Verify each digital input reads high when open and low when grounded. Check analog readings with a known voltage divider instead of a floating probe. Then connect the load supply and watch for voltage sag under relay actuation. If the sag exceeds 0.5V on the logic rail, you need a bulk capacitor near the power entry point, typically 470uF electrolytic in parallel with a 100nF ceramic.
Board revision differences matter more than the official documentation suggests. Revision 2.x boards moved the analog ground star point to a different location than 1.x boards, which changes where you should terminate your sensor ground wires. If you are retrofitting an older design onto a newer board, trace the ground planes with a multimeter in continuity mode before committing to the wiring layout. It takes about ten minutes and prevents mismatched references that cause sporadic measurement errors. For the relay output side, always wire the load return to the same ground reference that the control circuitry uses. Splitting the load ground from the logic ground creates a ground loop that couples noise back into the analog inputs through the shared power supply impedance. I measured a 200mV offset on A0 caused exactly by this mistake on a test rig, and it disappeared once I tied both grounds together at the power supply negative terminal. If your application involves high-current loads above 5A per relay, consider adding external solid state relays driven by the Terminator X output channels instead of using the onboard relays directly. The onboard relay contacts are fine for lighting circuits, small motors, and low-power sensors, but they degrade noticeably after a few thousand cycles at higher current. External SSRs cost more upfront but last significantly longer in industrial cycling scenarios.
The complete wiring sequence I follow now: power ground first, then logic ground, then digital input grounds, then analog ground star point, then relay commons, then load returns. Follow that order and you will rarely see ground-related anomalies during commissioning. Deviate from it and you will spend hours chasing phantom interference problems.